Related Experiment Video

Updated: Aug 10, 2026
Video-oculography in Mice
09:43

Video-oculography in Mice

Published on: July 19, 2012

Derivation of the angle of torsion of the eye

The British Journal of Physiological Optics
|January 1, 1975
PubMed

Related Concept Videos

Torque01:10

Torque

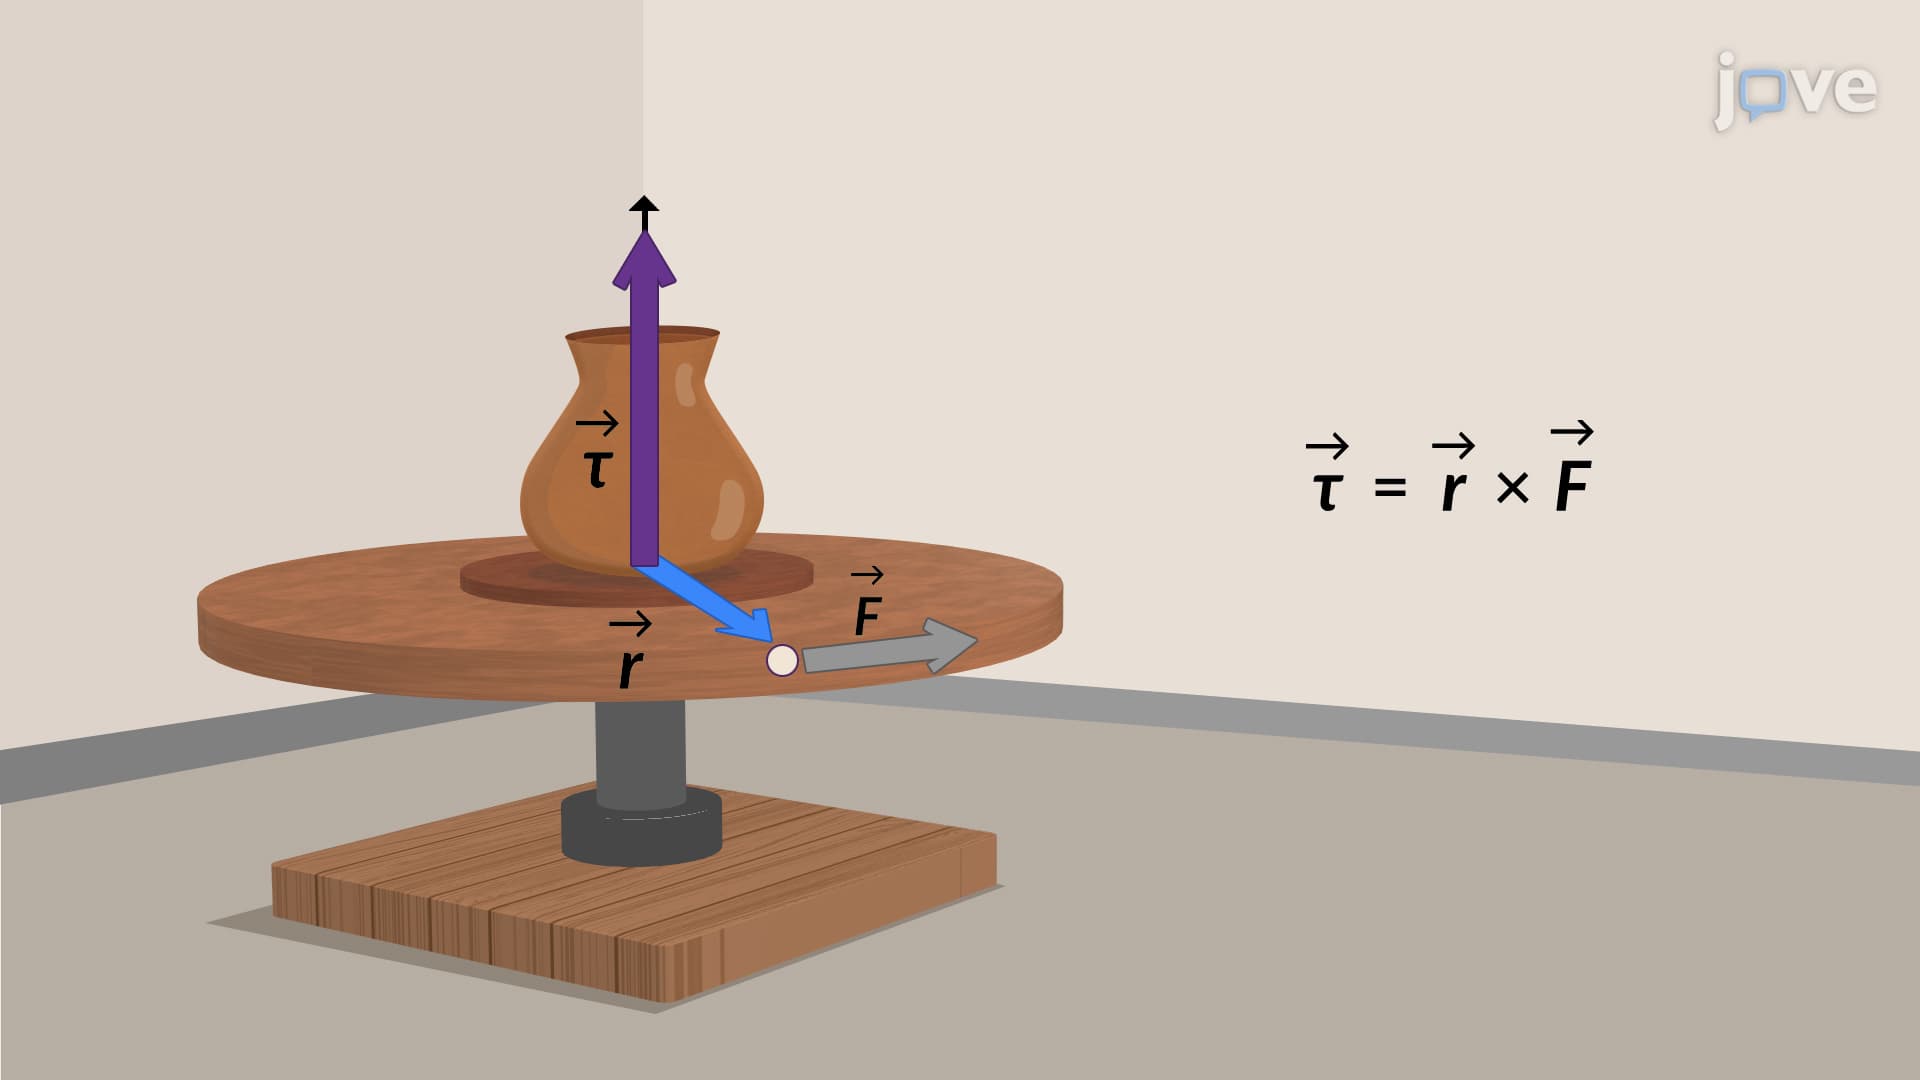
Torque is an important quantity for describing the dynamics of a rotating rigid body. We see the application of torque in many ways in the world, such as when pressing the accelerator in a car, which causes the engine to apply additional torque on the drivetrain. Here, we define torque and provide a framework to create an equation to calculate torque for a rigid body with fixed-axis rotation.
Torque can be considered as the rotational counterpart to force. Since forces change the translational...
Equation of Rotational Dynamics01:08

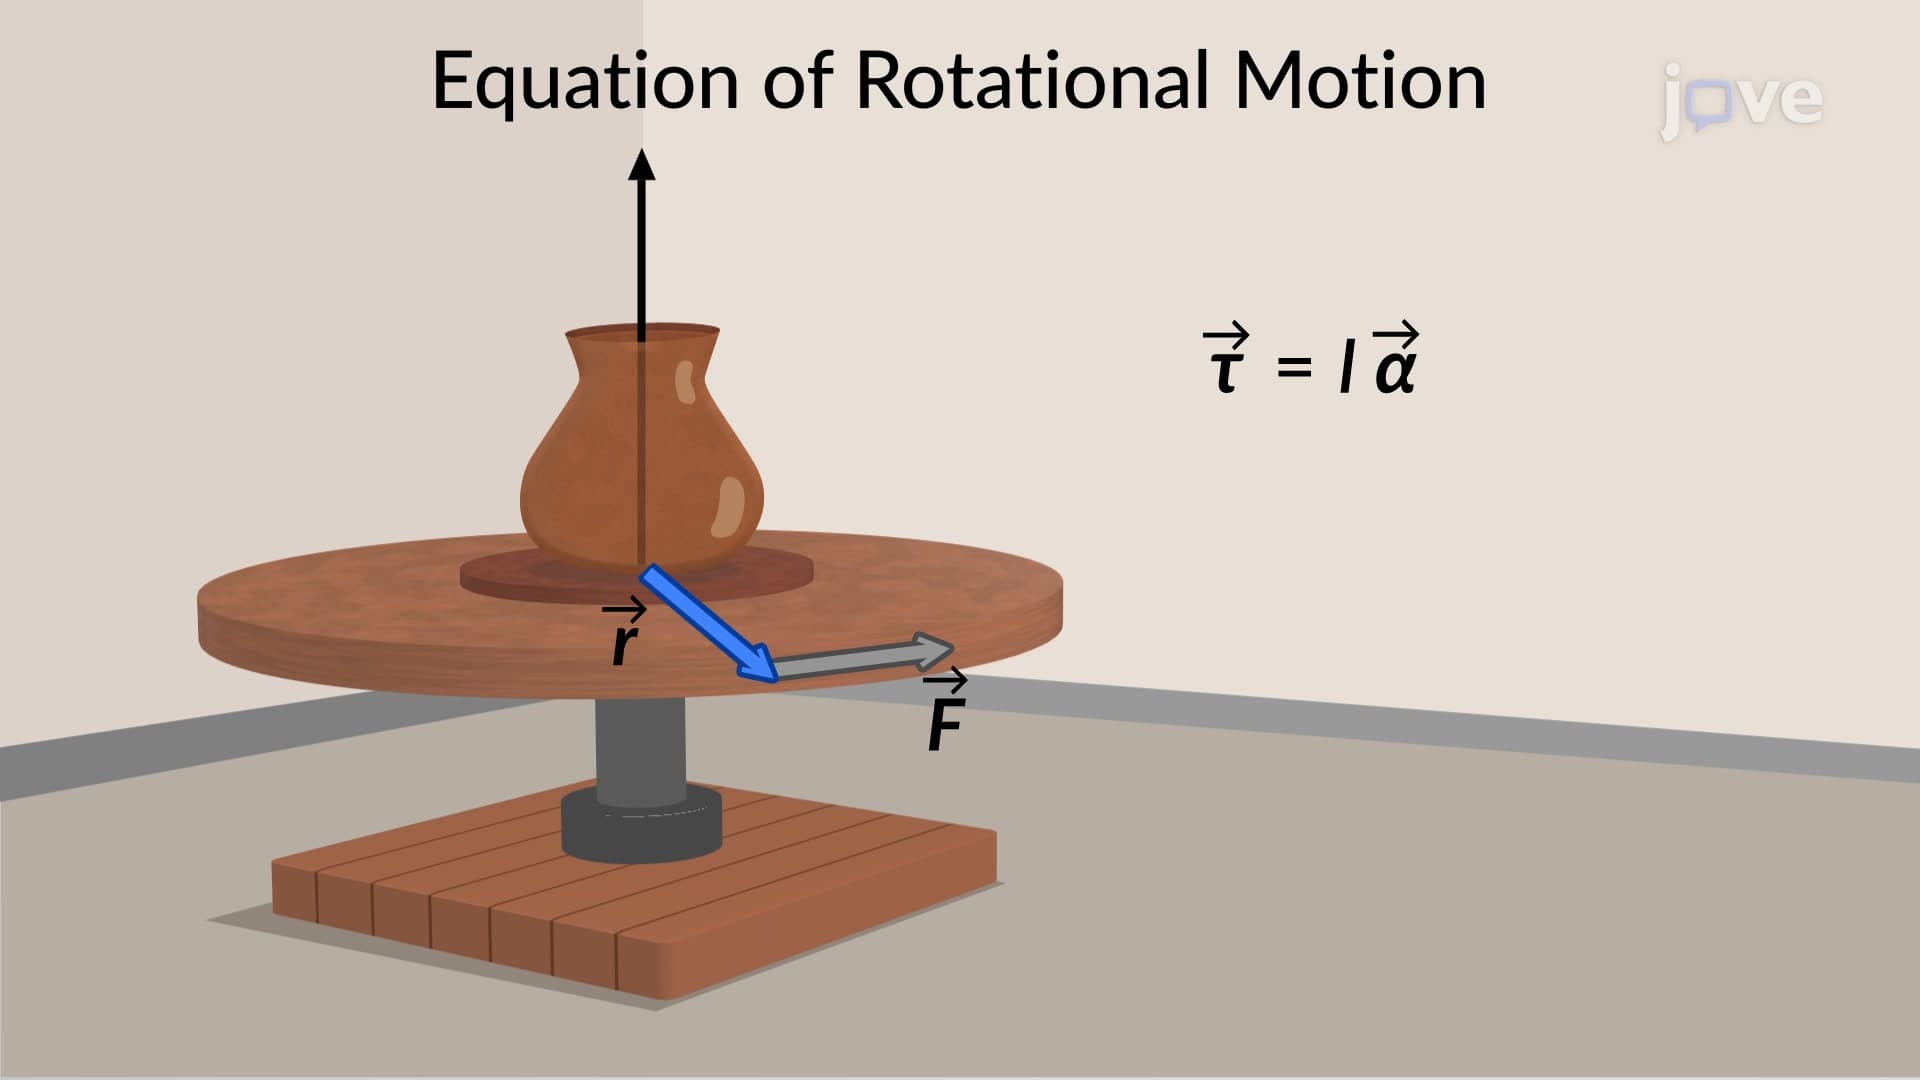
Equation of Rotational Dynamics

Angular variables are introduced in rotational dynamics. Comparing the definitions of angular variables with the definitions of linear kinematic variables, it is seen that there is a mapping of the linear variables to the rotational ones. Linear displacement, velocity, and acceleration have their equivalents in rotational motion, which are angular displacement, angular velocity, and angular acceleration. Similar to the rotational variables, a mapping exists from Newton's second law of motion...
Accessory Structures of the Eye01:17

Accessory Structures of the Eye

Optical perception, or vision, is an extraordinary sense dependent on converting light signals received via the ocular organs. These organs, known as eyes, are securely positioned within the bony cavities of the skull, called orbits. The orbits serve a dual purpose: a protective shield for the ocular globes and a stable attachment point for the soft ocular tissues. The eye's external protective mechanisms include the eyelids, which are edged with lashes that act as a barrier against foreign...
Angle of Twist - Elastic Range01:13

Angle of Twist - Elastic Range

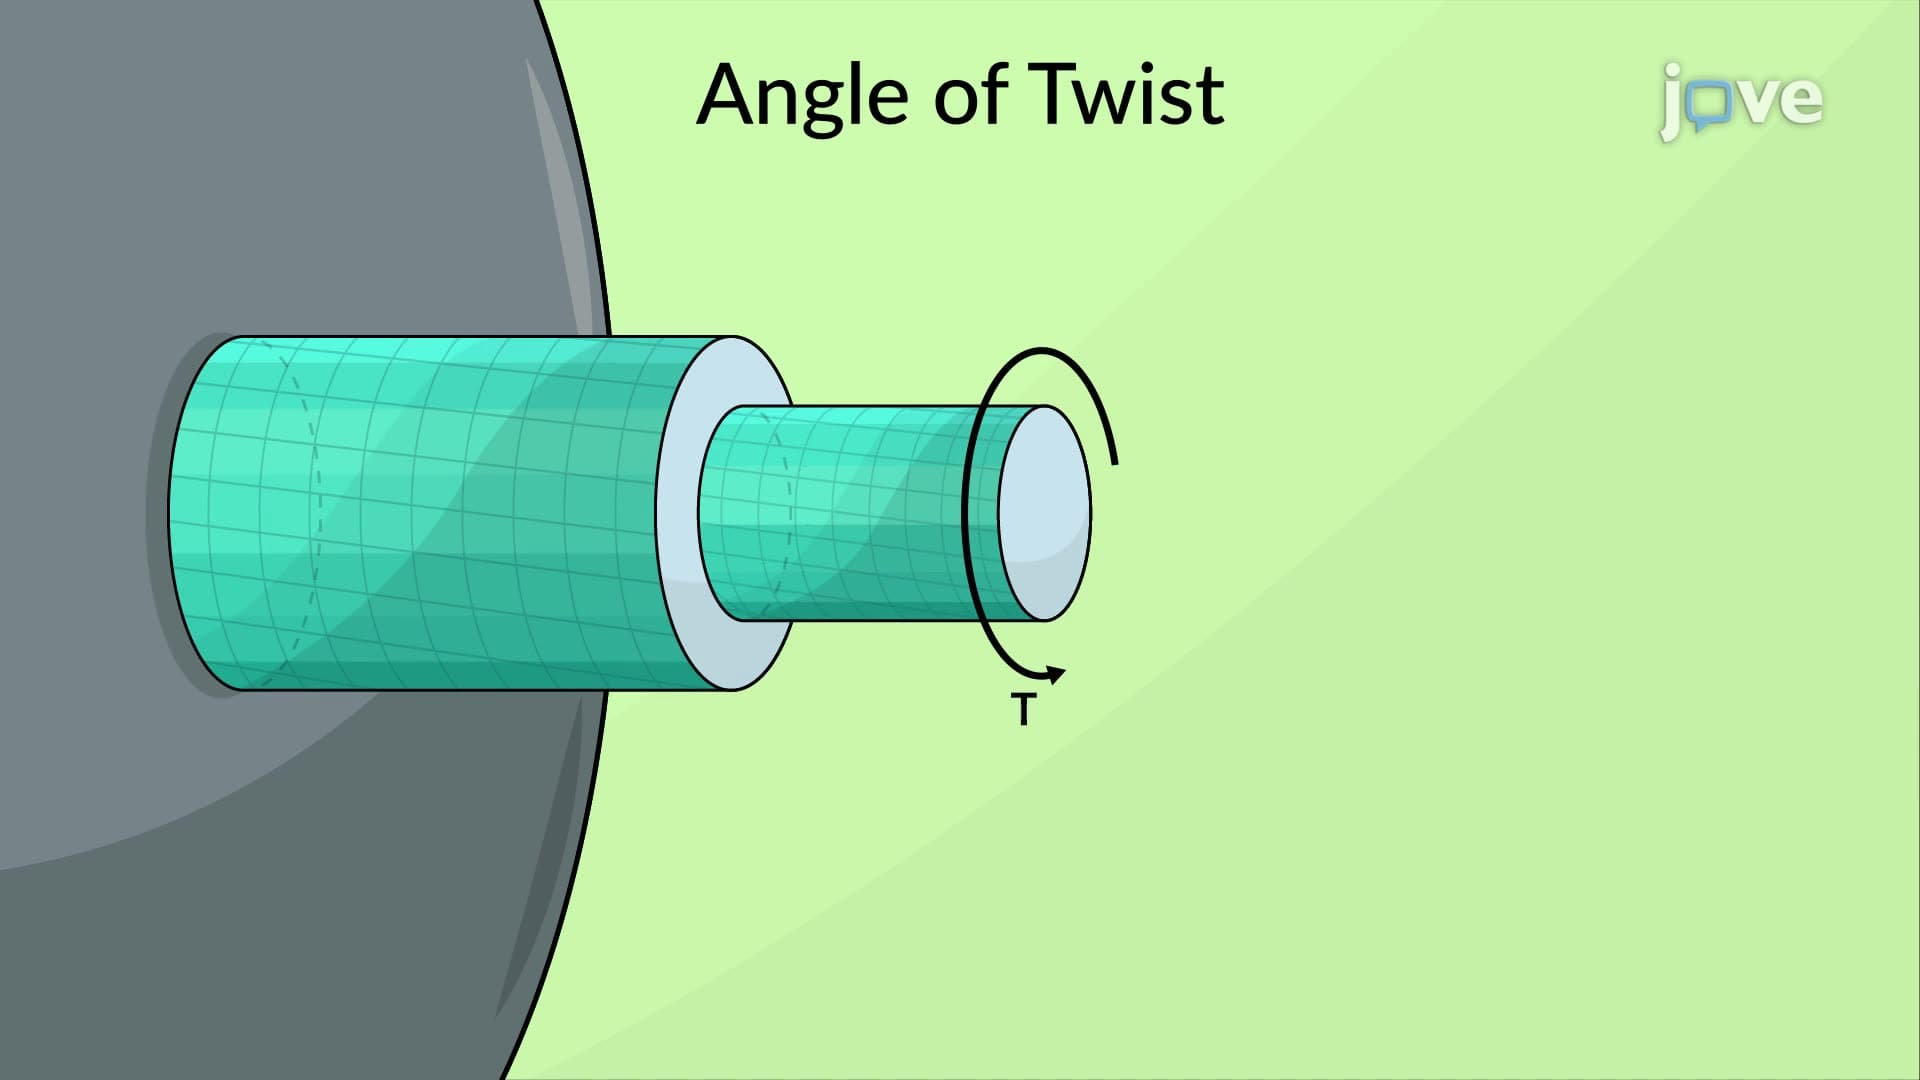
Consider a cylindrical shaft with a length denoted by L and a consistent cross-sectional radius referred to as r. This shaft undergoes a torque at the free end. The highest shearing strain within the shaft is directly proportional to the twist angle and the radial distance from the shaft axis. When the shaft behaves elastically, this shearing strain can be articulated using variables such as the applied torque, radial distance, the polar moment of inertia, and the modulus of rigidity. By...
Angle of Twist: Problem Solving01:13

Angle of Twist: Problem Solving

An electric motor applies a torque of 700 N·m to an aluminum shaft, triggering a stable rotation. Two pulleys, B and C, are subjected to torques of 300 N·m and 400 N·m, respectively. The modulus of rigidity is provided as 25 GPa. With the knowledge of the length and diameter of each segment, the twist angle between the two pulleys can be computed. First, a section cut is made between pulleys B and C, and the cut cross-section is analyzed using a free-body diagram. Given that the torque exerted...
Torsion in Vector Calculus01:20

Torsion in Vector Calculus

A toy train ascending a winding track that curves and tilts offers an intuitive view of torsion, a key geometric concept in the study of space curves. While curvature measures how sharply a path bends, torsion captures how the path twists out of the plane of bending. This twisting behavior is crucial in understanding three-dimensional motion and is precisely described using the Frenet–Serret framework.At each point along a space curve, the Frenet–Serret frame consists of three orthogonal unit...