Neural adaptive control of nonlinear multivariable systems with application to a class of inverted pendulums
Related Experiment Video
Updated: Sep 28, 2026
Online Virtual Reality Networked Control Laboratory Applied in Control Engineering Education
Published on: February 23, 2024
1Department of Electrical and Computer Engineering, The Pennsylvania State University at Erie, Erie, PA 16563-1701, USA. sxh63@psu.edu

Abstract:
In this paper multilayer neural networks (MNNs) are used to control the balancing of a class of inverted pendulums. Unlike normal inverted pendulums, the pendulum discussed here has two degrees of rotational freedom and the base-point moves randomly in three-dimensional space. The goal is to apply control torques to keep the pendulum in a prescribed position in spite of the random movement at the base-point. Since the inclusion of the base-point motion leads to a non-autonomous dynamic system with time-varying parametric excitation, the design of the control system is a challenging task. A feedback control algorithm is proposed that utilizes a set of neural networks to compensate for the effect of the system's nonlinearities. The weight parameters of neural networks updated on-line, according to a learning algorithm that guarantees the Lyapunov stability of the control system. Furthermore, since the base-point movement is considered unmeasurable, a neural inverse model is employed to estimate it from only measured state variables. The estimate is then utilized within the main control algorithm to produce compensating control signals. The examination of the proposed control system, through simulations, demonstrates the promise of the methodology and exhibits positive aspects, which cannot be achieved by the previously developed techniques on the same problem. These aspects include fast, yet well-maintained damped responses with reasonable control torques and no requirement for knowledge of the model or the model parameters. The work presented here can benefit practical problems such as the study of stable locomotion of human upper body and bipedal robots.

Related Concept Videos
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length, the...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:27
Real-World Applications of Power Series
 01:09
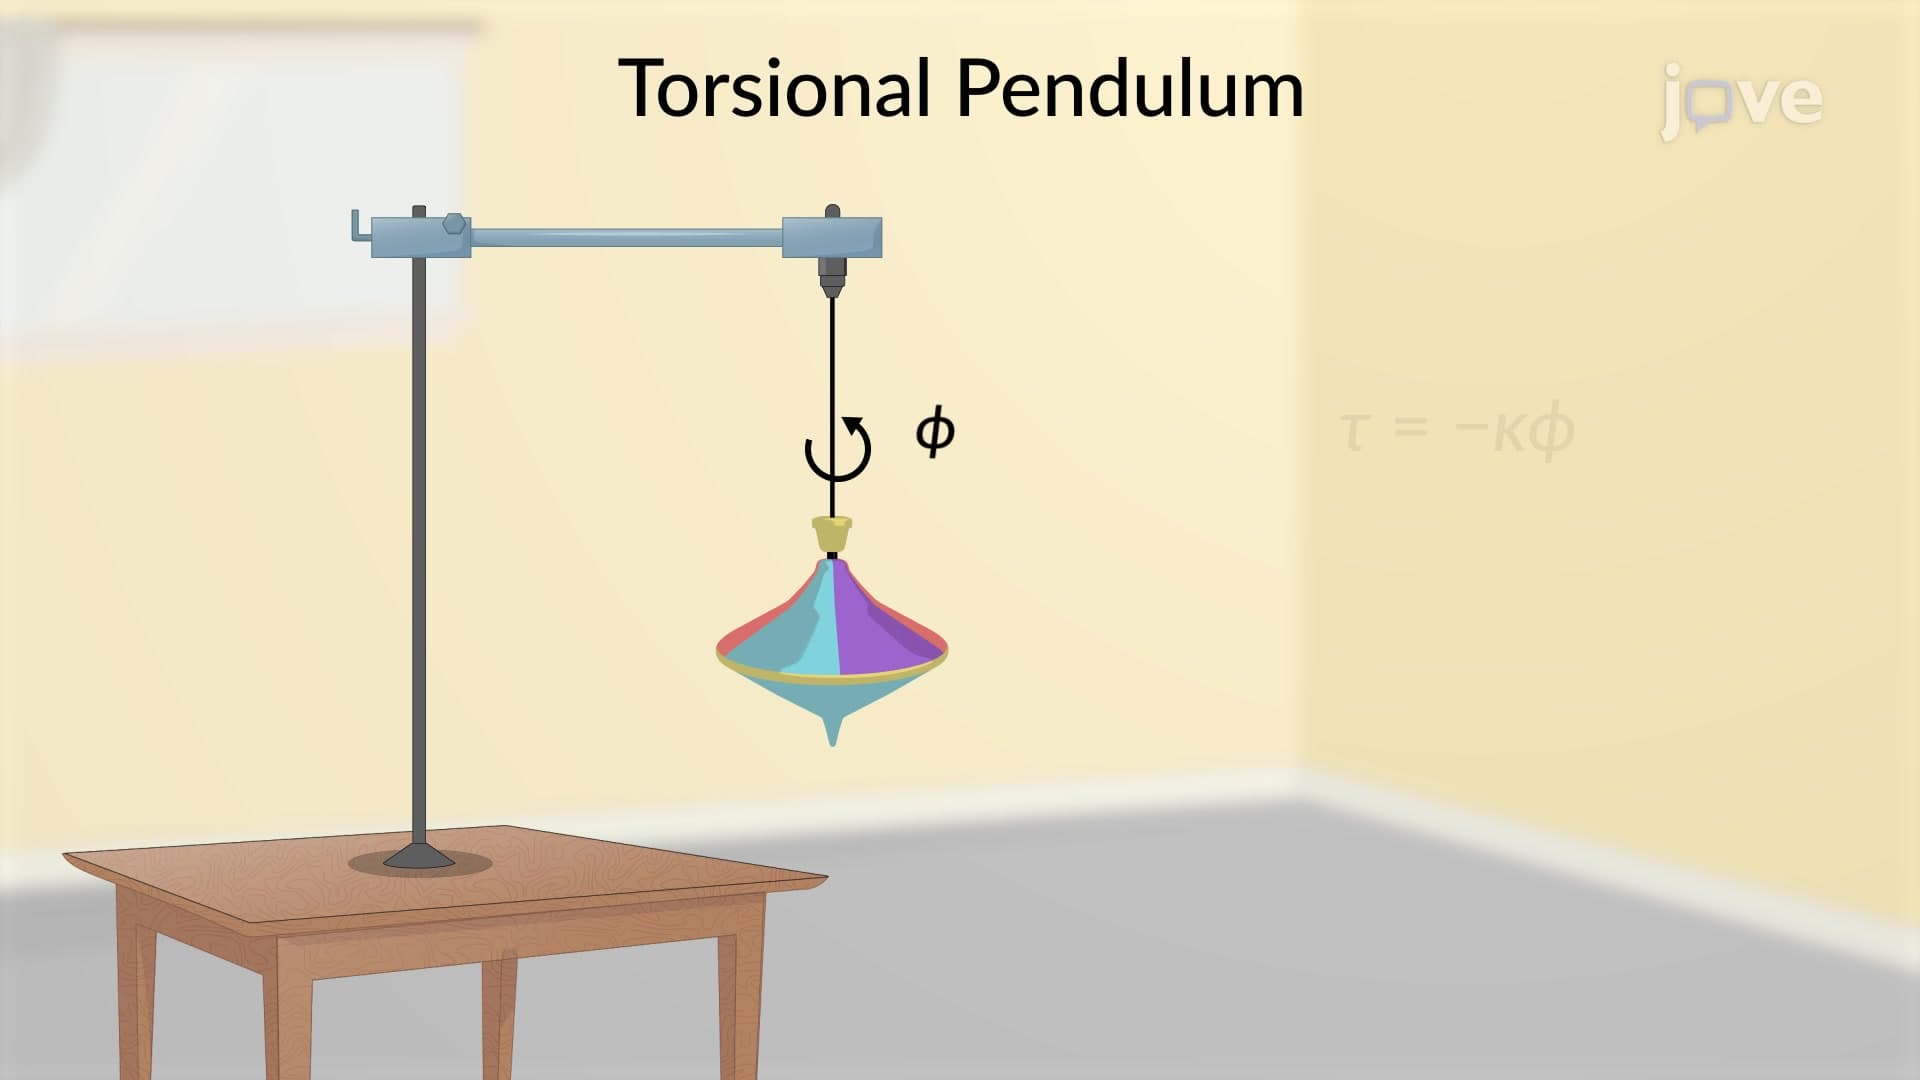
Torsional Pendulum
As long as the rigid body's angular displacement is small, its oscillation can be modeled as a linear angular oscillation. The amplitude of the oscillation is an angle. The role of mass is played by the...
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal and...
 01:10
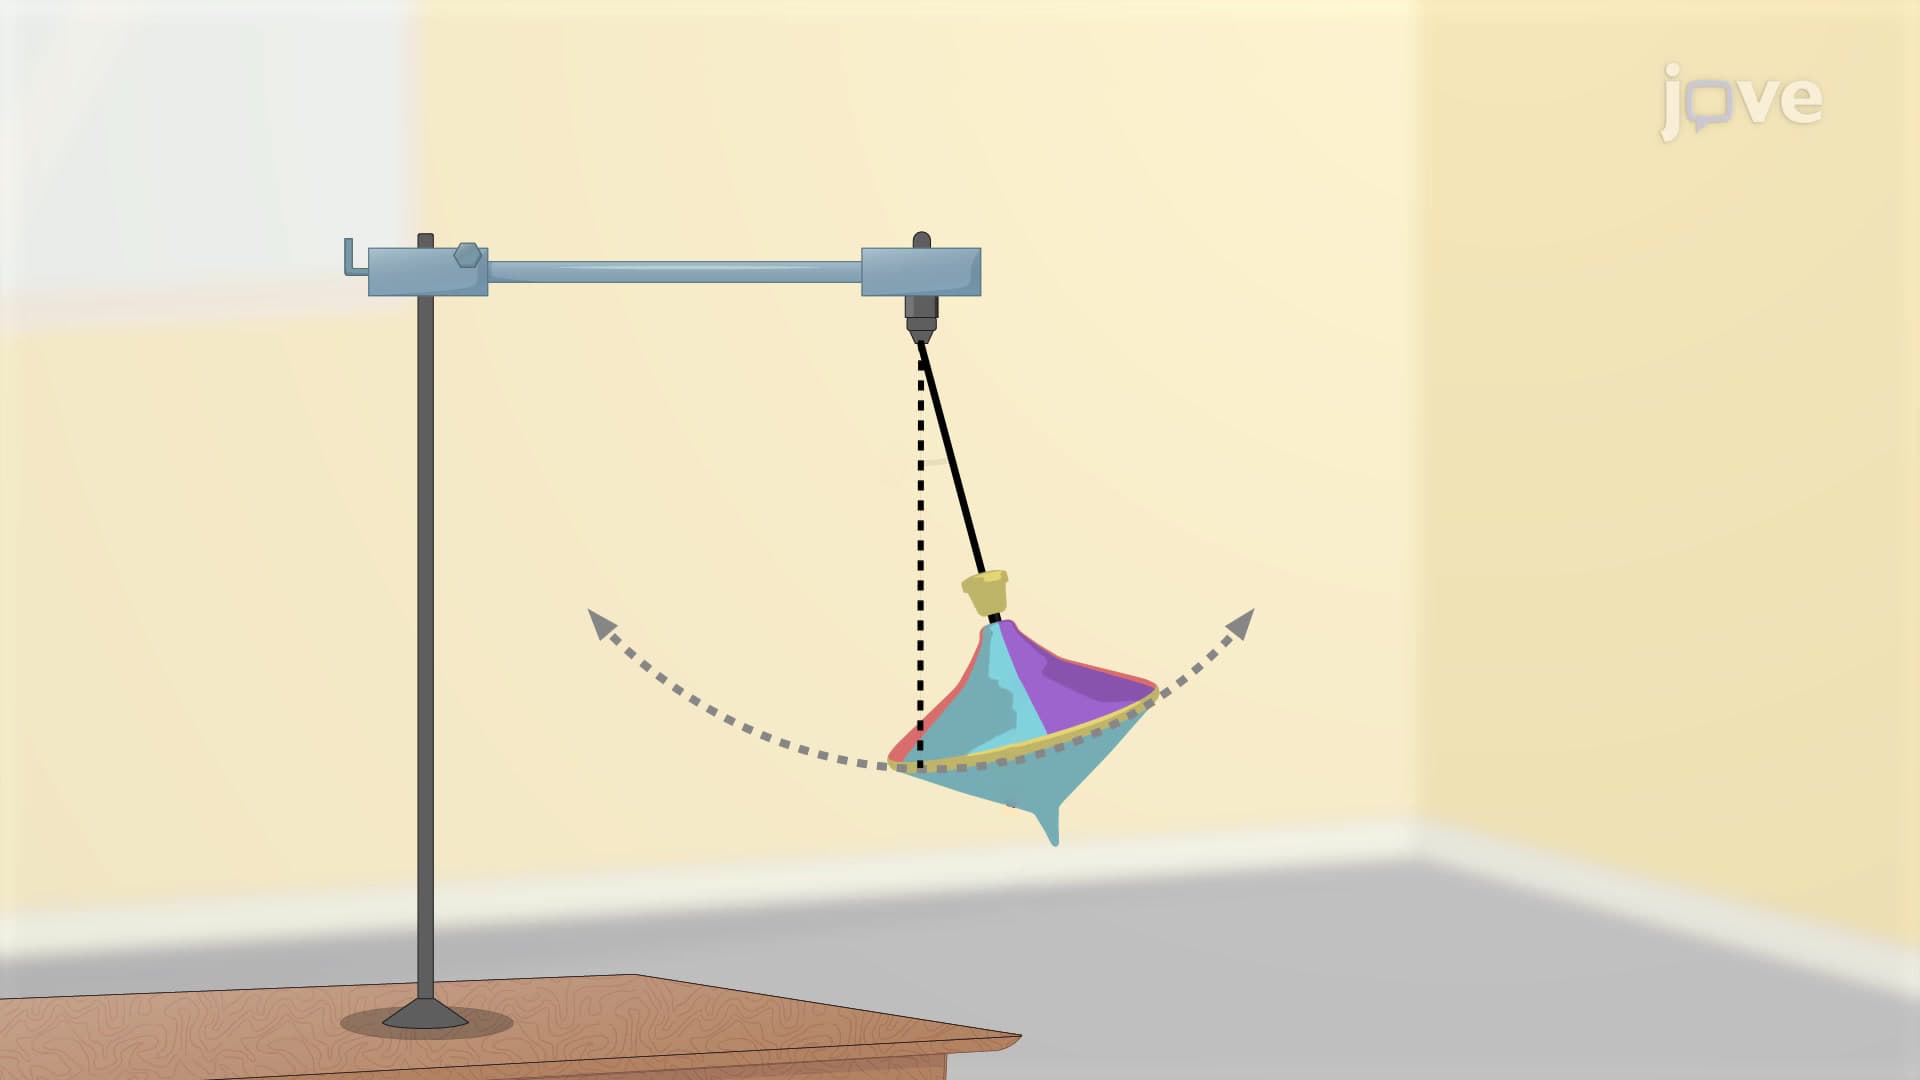
Simple Pendulum
The period of a simple pendulum depends on two factors: its length and the acceleration due to gravity. The period is completely independent of any other factors, such as mass or maximum displacement. For small displacements, a pendulum is...