Dimensionality and the dynamics of human unstable equilibrium
Related Experiment Video
Updated: Sep 28, 2026
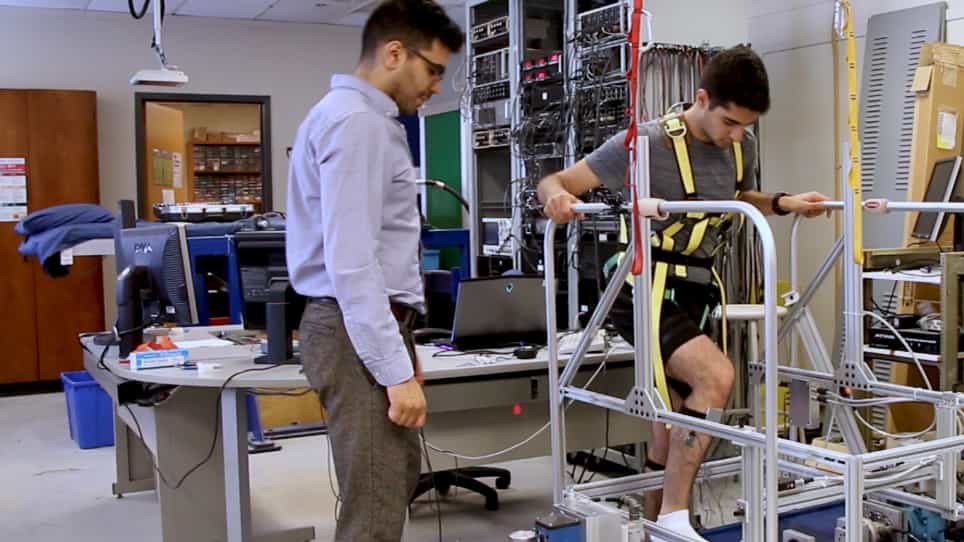
Experimental Methods to Study Human Postural Control
Published on: September 11, 2019
Fabrice Mégrot1, Benoît Bardy, Gilles Dietrich
1Research Center in Sport Sciences, University of Paris Sud XI, Batiment 335, 91405, Orsay, France.

Abstract:
Maintaining an unstable equilibrium requires that multiple joints be coordinated so that the center of mass is kept above the base of support. The authors' aim in the present study was to discover the underlying dynamics of local (foot, hip, or head) and global (center of mass) components involved in balance control and how those dynamics are affected by changes in the available information. Participants (N = 6) had to maintain their balance on an unstable platform. Using dimensional analyses (largest Lyapunov exponent and correlation dimension), the authors examined the active degrees of freedom involved in balance control. Results indicated a similarity in dimension between local (joints) and global (center of mass) components, between a fixed point and a limit cycle. The behavior of the center of mass was found to be more predictable than the behavior of its local constituents. In addition, the available visual information affected the predictability of the postural behavior, which suggests that vision is used in the stabilization of the low-dimensional dynamics underlying balance control.
More Related Videos
Related Concept Videos
 01:04
Oscillations about an Equilibrium Position
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:23
Stability of Equilibrium Configuration
A stable equilibrium occurs when a system tends to return to its original position when given a small displacement, and the potential energy is at its minimum. An example of a stable equilibrium is when a cantilever beam is fixed at one end and a weight is attached to the other end. If the weight...
 01:28
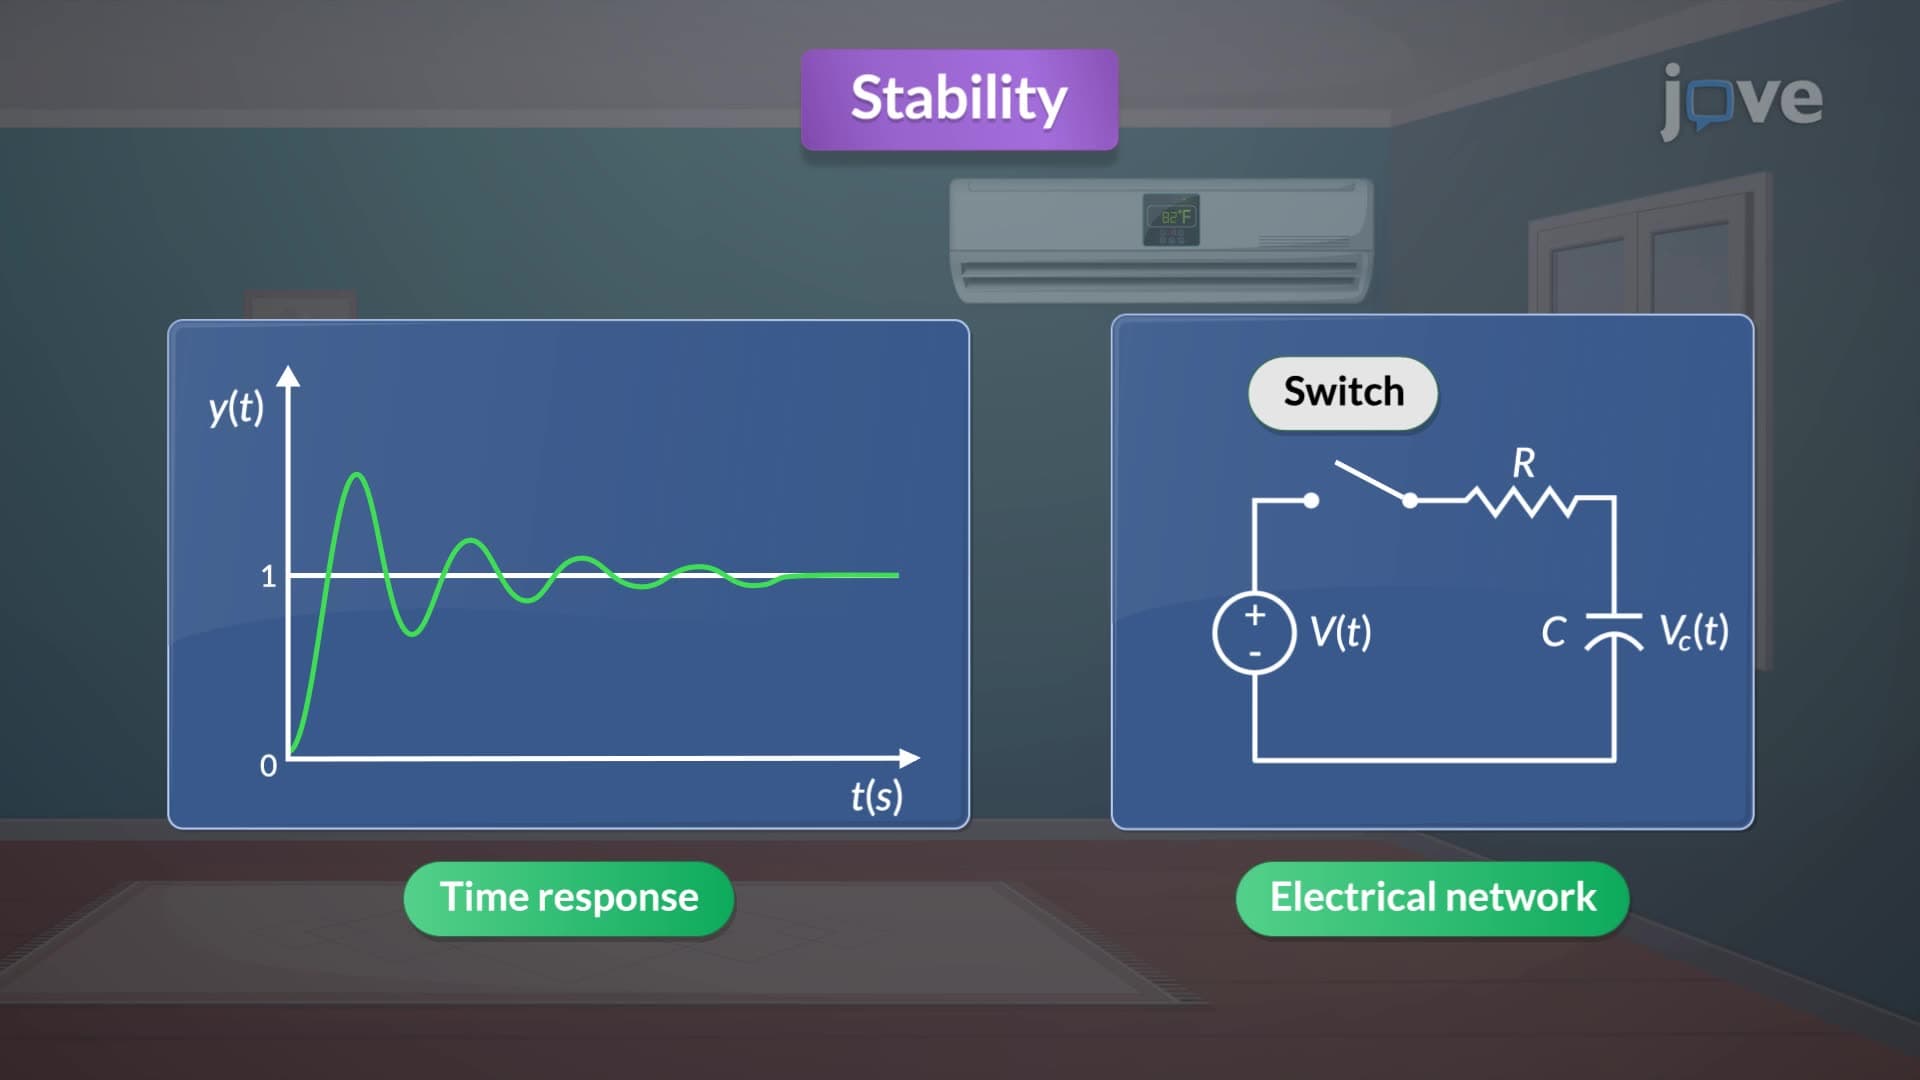
Stability
The stability of an LTI system is determined by the roots of its characteristic equation, known as poles. A system is stable if it produces a bounded...
 01:13
Stability of Equilibrium Configuration: Problem Solving
Problem-solving in the context of the stability of equilibrium configuration...
 01:07
Static Equilibrium - II