[Development of a compact, semi-robotic platform for an electronic surgical microscope]
Related Experiment Video
Updated: Sep 28, 2026

Design and Implementation of a Bespoke Robotic Manipulator for Extra-corporeal Ultrasound
Published on: January 7, 2019
W Lauer1, M Esser, K Radermacher
1Institut für Biomedizinische Technologien, RWTH Aachen, Aachen, Deutschland. lauer@hia.rwth-aachen.de

Abstract:
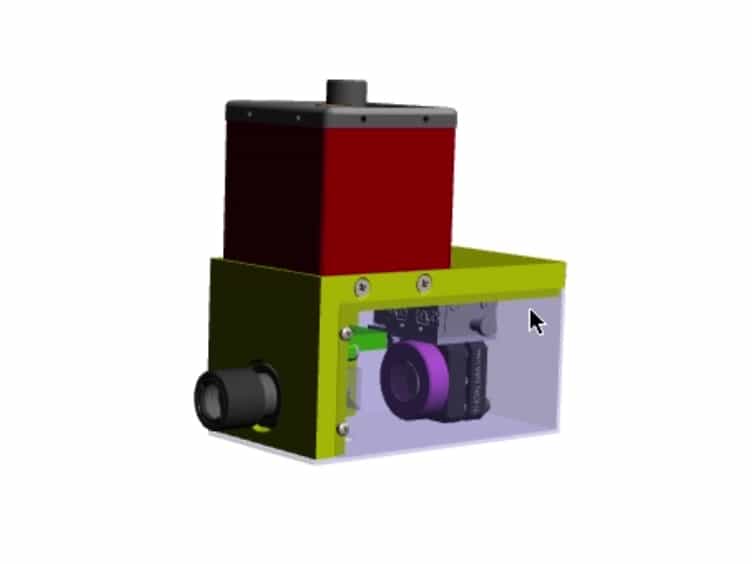
In the context of the development of a new, electronic microscope for surgical interventions a semirobotic motion platform for the spatial placement and fixation of a stereoscopic camera is currently being developed. Based on an inquiry about the medical, technical and user-requirements, different phases and characteristics concerning frequency, workspace, speed and accuracy of camera movement during an intervention have been specified. To meet these requirements, a differentiated concept for the platform has been developed including a serial structure for manual pre-positioning, a parallel robot for motor-movement during surgical work and different user-interfaces for suitable robot-control.