Related Experiment Video
Updated: Sep 28, 2026

3D Kinematic Gait Analysis for Preclinical Studies in Rodents
Published on: August 3, 2019
Coordination Dynamics of the Bipedal Galloping Pattern
1a Center for the Ecological Study of Perception and Action University of Connecticut.

Abstract:
A motion equation in relative phase was developed that incorporates the spatial-temporal pattern of the bipedal gallop along with the more commonplace patterns of the bipedal jump and walk-run. In 3 experiments, human participants (N = 6 per experiment) simulated the bipedal gait patterns through the rhythmic motions of hand-held pendulums. Predictions of the motion equation for coordination equilibria and their respective degrees of stability were confirmed. In particular, the gallop pattern was less stable than the fundamental in-phase and antiphase patterns but changed in qualitatively similar ways to those gaits as a function of limb asymmetry and movement frequency. The relation between the modeled coordination dynamics and the kinematic characteristics of real bipedal galloping is discussed.
More Related Videos

Related Concept Videos
 01:17
Kinematic Equations - II
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
 01:24
Muscle Coordination and Action
Agonists
Agonist muscles, often called prime movers, are the primary muscles responsible for producing a specific movement.
 01:15
Kinematic Equations: Problem Solving
 01:18
Kinematic Equations - III
Using the kinematic equations,...
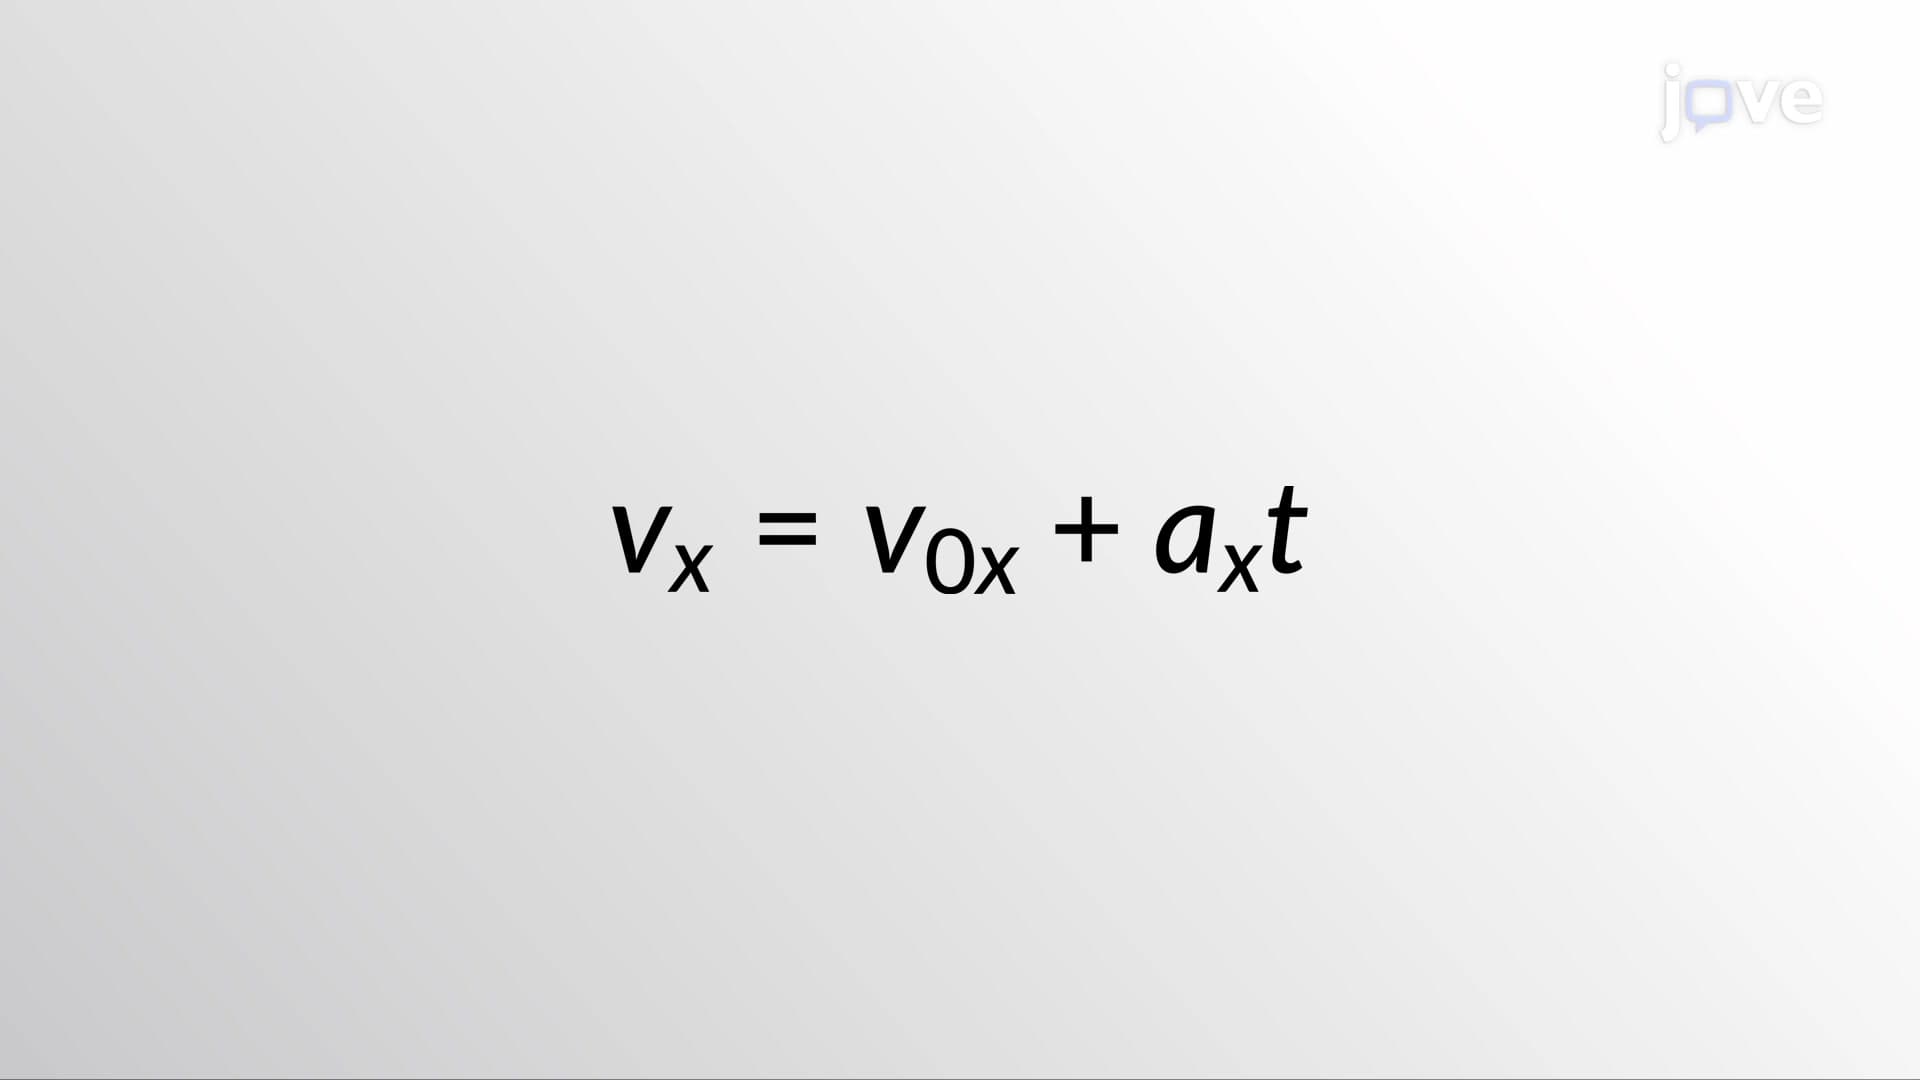 01:26
Kinematic Equations - I