Related Experiment Video
Updated: Sep 28, 2026
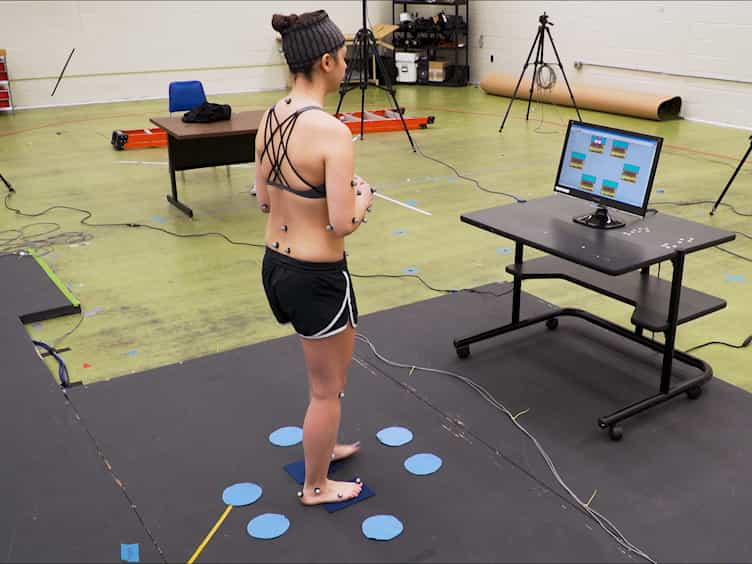

The "Motor" in Implicit Motor Sequence Learning: A Foot-stepping Serial Reaction Time Task
Published on: May 3, 2018
Isotropic sequence order learning using a novel linear algorithm in a closed loop behavioural system
1Department of Psychology, University of Stirling, Stirling, UK.

Abstract:
In this article, we present an isotropic algorithm for sequence order learning. Its central goal is to learn the causal relation between two (or more) inputs in order to react to the earliest incoming signal after successful learning (like in typical classical conditioning situations). We implement this algorithm in a behaving system (a robot) thereby creating a closed loop situation where the learner's actions influence its own sensor inputs to the end of creating an autonomous agent. Autonomous behaviour implies that learning goals are internally defined within the organism's capabilities. Standard learning models for sequence learning (e.g. temporal difference (TD)-learning) need an externally defined reward. This, however, is in conflict with the requirement of an implicitly defined internal goal in autonomous behaviour. Therefore, in this study we present a system in which the external reward is replaced by a reflex loop. This loop explicitly includes the environment. Every reflex loop has the inherent disadvantage, which is that its re-actions occur each time just after a reflex-eliciting sensor event and thus 'too late'. However, a reflex can serve as the internal reference for sequence order learning, which has the task of eliminating this disadvantage by creating earlier anticipatory actions. In our system learning is achieved by modifying synaptic weights of a linear neuron with a correlation based learning rule which involves the derivative of the neuron's output. All input lines are entirely isotropic. The synaptic weight change curve of this rule is strongly related to the temporal Hebb learning rule, which was found in spike timing experiments. We find that after learning the reflex loop is replaced in functional terms with an earlier anticipatory action (and pathway). In addition, we observed that the synaptic weights stabilise as soon as the reflex remains silent.

Related Concept Videos
 01:26
Classification of Systems-I
Homogeneity dictates that if an input x(t) is multiplied by a constant c, the output y(t) is multiplied by the same constant. Mathematically, this is expressed as:
 01:23
Linear time-invariant Systems
The input-output behavior of an LTI system can be fully defined by its response to an impulsive excitation at its input. Once this impulse response is known, the system's reaction to any other input can be calculated...
 01:24
Sequence Networks of Rotating Machines
Zero-sequence current induces a voltage drop across the generator's neutral impedance and other...
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length, the...
 01:20
Second Order systems I
By reinterpreting the system, one can derive the closed-loop transfer function, which...
 01:18
Second Order systems II
If ζ...