Related Experiment Video
Updated: Sep 11, 2026


Oscillation and Reaction Board Techniques for Estimating Inertial Properties of a Below-knee Prosthesis
Published on: May 8, 2014
Biomechanical and physiological aspects of legged locomotion in humans
Franco Saibene1, Alberto E Minetti
1Istituto Neuroscienze e Bioimmagini, Consiglio Nazionale delle Ricerche, Via Fratelli Cervi 93, 20090 Segrate, Milan, Italy. saibene@inb.mi.cnr.it

Abstract:
Walking and running, the two basic gaits used by man, are very complex movements. They can, however, be described using two simple models: an inverted pendulum and a spring. Muscles must contract at each step to move the body segments in the proper sequence but the work done is, in part, relieved by the interplay of mechanical energies, potential and kinetic in walking, and elastic in running. This explains why there is an optimal speed of walking (minimal metabolic cost of about 2 J.kg(-1).m(-1) at about 1.11 m.s(-1)) and why the cost of running is constant and independent of speed (about 4 J.kg(-1).m(-1)). Historically, the mechanical work of locomotion has been divided into external and internal work. The former is the work done to raise and accelerate the body centre of mass (m) within the environment, the latter is the work done to accelerate the body segments with respect to the centre of m. The total work has been calculated, somewhat arbitrarily, as the sum of the two. While the changes of potential and kinetic energies can be accurately measured, the contribution of the elastic energy cannot easily be assessed, nor can the true work performed by the muscles. Many factors can affect the work of locomotion--the gradient of the terrain, body size (height and body m), and gravity. The partitioning of positive and negative work and their different efficiencies explain why the most economical gradient is about -10% (1.1 J.kg(-1).m(-1) at 1.3 m.s(-1) for walking, and 3.1 J.kg(-1).m(-1) at between 3 and 4 m.s(-1) for running). The mechanics of walking of children, pigmies and dwarfs, in particular the recovery of energy at each step, is not different from that of taller (normal sized) individuals when the speed is expressed in dynamically equivalent terms (Froude number). An extra load, external or internal (obesity) affects internal and external work according to the distribution of the added m. Different gravitational environments determine the optimal speed of walking and the speed of transition from walking to running: at more than 1 g it is easier to walk than to run, and it is the opposite at less than 1 g. Passive aids, such as skis or skates, allow an increase in the speed of progression, but the mechanics of the locomotion cannot be simply described using the models for walking and running because step frequency, the proportion of step duration during which the foot is in contact with the ground, the position of the limbs, the force exerted on the ground and the time of its application are all different.

Related Concept Videos
 01:16
Bones of the Lower Limb: Femur and Patella
 01:10
Bones of the Lower Limb: Tibia and Fibula
 01:23
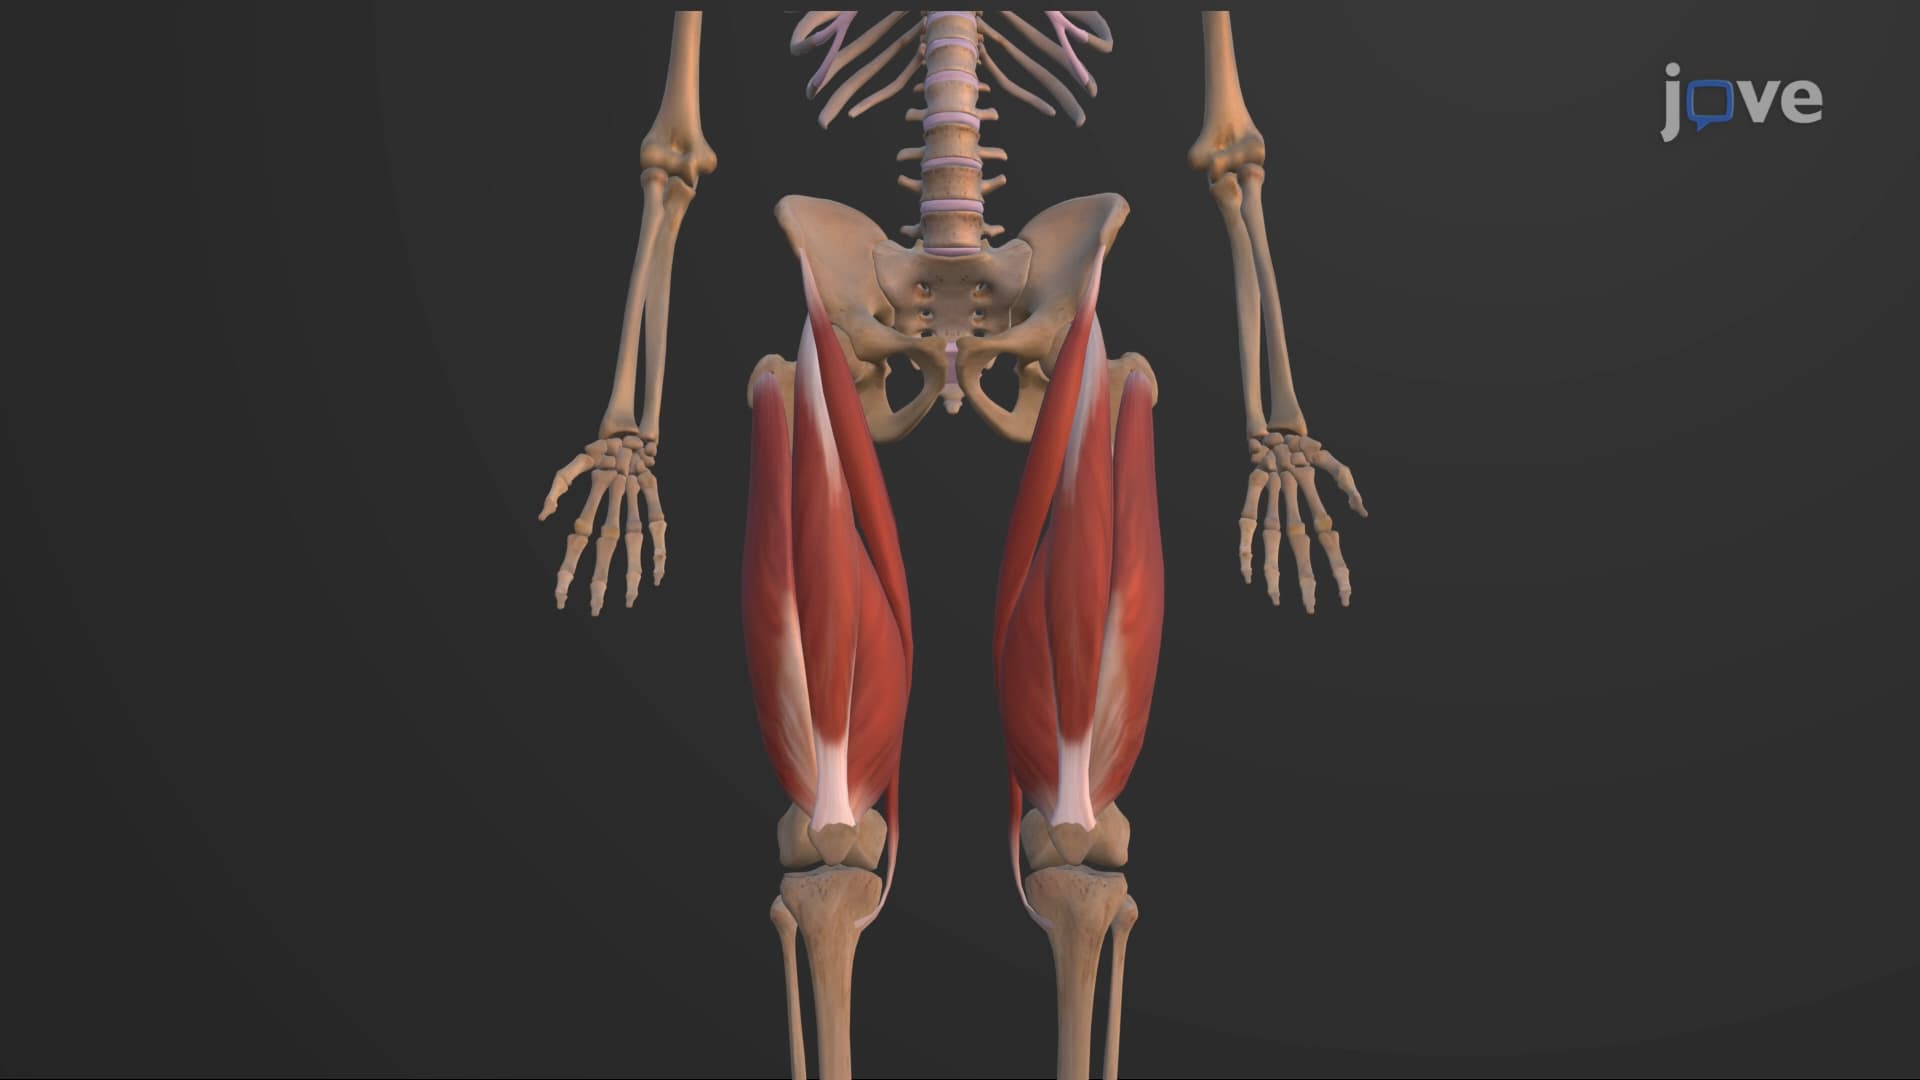
Muscles that Move the Leg
Anterior Compartment
The quadriceps femoris, the most visible muscle of the anterior compartment, is integral for leg extension and thigh flexion. It is formed by merging four distinct muscles — the vastus lateralis, vastus medialis, vastus intermedius, and rectus femoris. The quadriceps tendon, a shared tendon of the four quadriceps muscles, is affixed to...
 01:28
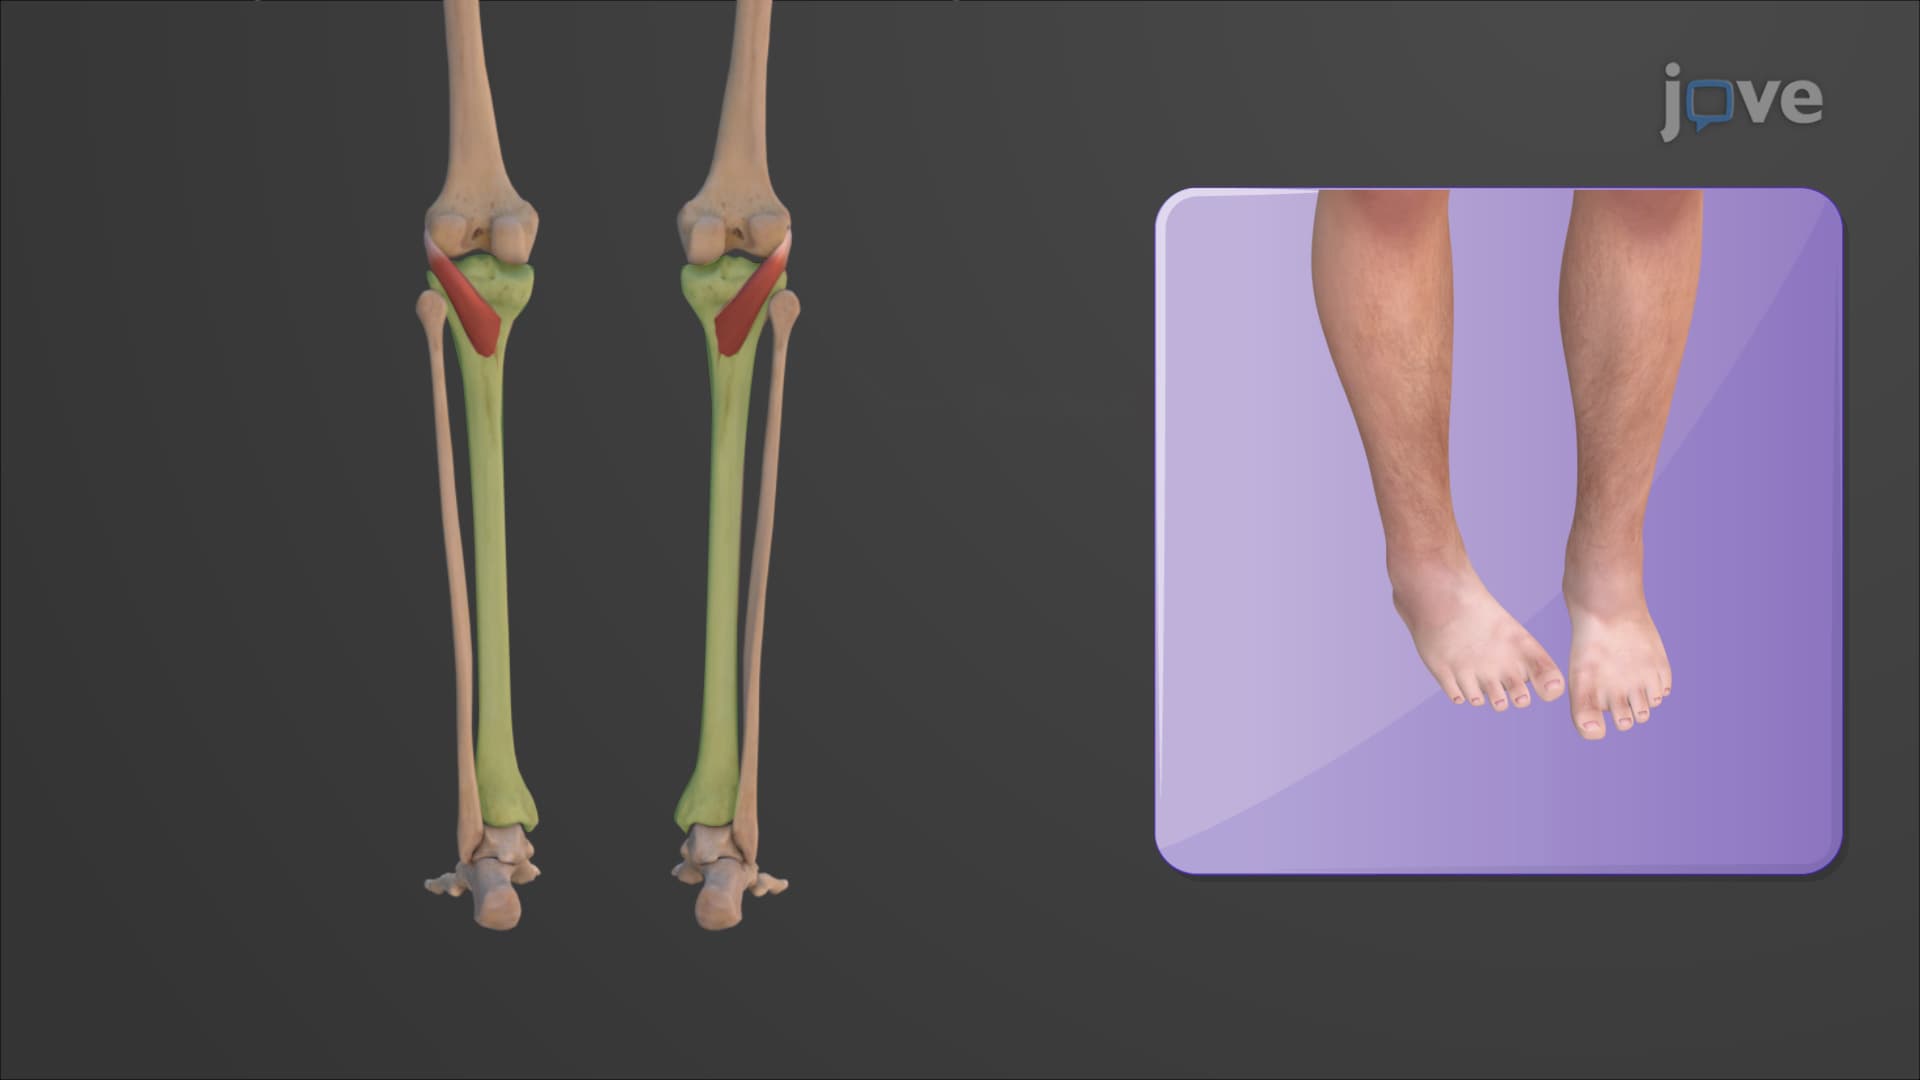
Muscles of the Leg that Move the Foot and Toes
Anterior Compartment
The anterior compartment includes muscles that contribute to the dorsiflexion of the foot. This compartment houses the tibialis anterior, extensor hallucis longus, and extensor digitorum longus muscles.