Achieving Coordination in Prehension: Joint Freezing and Postural Contributions
Related Experiment Video
Updated: Sep 27, 2026
Postural Organization of Gait Initiation for Biomechanical Analysis Using Force Platform Recordings
Published on: July 26, 2022
B. Steenbergen1, R. G. Marteniuk, L. E. Kalbfleisch
1School of Kinesiology Simon Fraser University, Burnaby, BC, V5A 1S6, Canada.

Abstract:
The focus of the present study was on the intersegmental relationships that emerge when both task and oganismic constraints are imposed upon the coordination system. Seven right-handed subjects were required to reach and grasp a cup (hand transport phase) and place it on a designated target (cup transport phase), using either their preferred or nonpreferred hand. The kinematics of the movement were examined as a function of task (grasping a full cup versus grasping an empty one) and organismic (preferred or nonpreferred hand) constraints. During the hand transport phase, a task constraint effect was revealed through an increase in the low-velocity phase for the full cup condition. This constraint coexisted with a decrease in angular motion of the shoulder and elbow joints, indicating subjects reduced the number of variables to be independently controlled in the final homing-in stage of the movement. Accompanying this decrease in angular change was an increase in the displacement of the trunk. During the cup transport phase, the trunk was shown to contribute significantly more to the movement in the full cup condition and for the left hand movements, thereby increasing the stability of the movement system. These findings are in agreement with Bernstein's (1967) notion of fixating parts of the body as an initial solution to a movement problem, and they lend support to the concept of a proximodistal organization of coordination.
Related Concept Videos
 01:24
Muscle Coordination and Action
Agonists
Agonist muscles, often called prime movers, are the primary muscles responsible for producing a specific movement.
 00:49
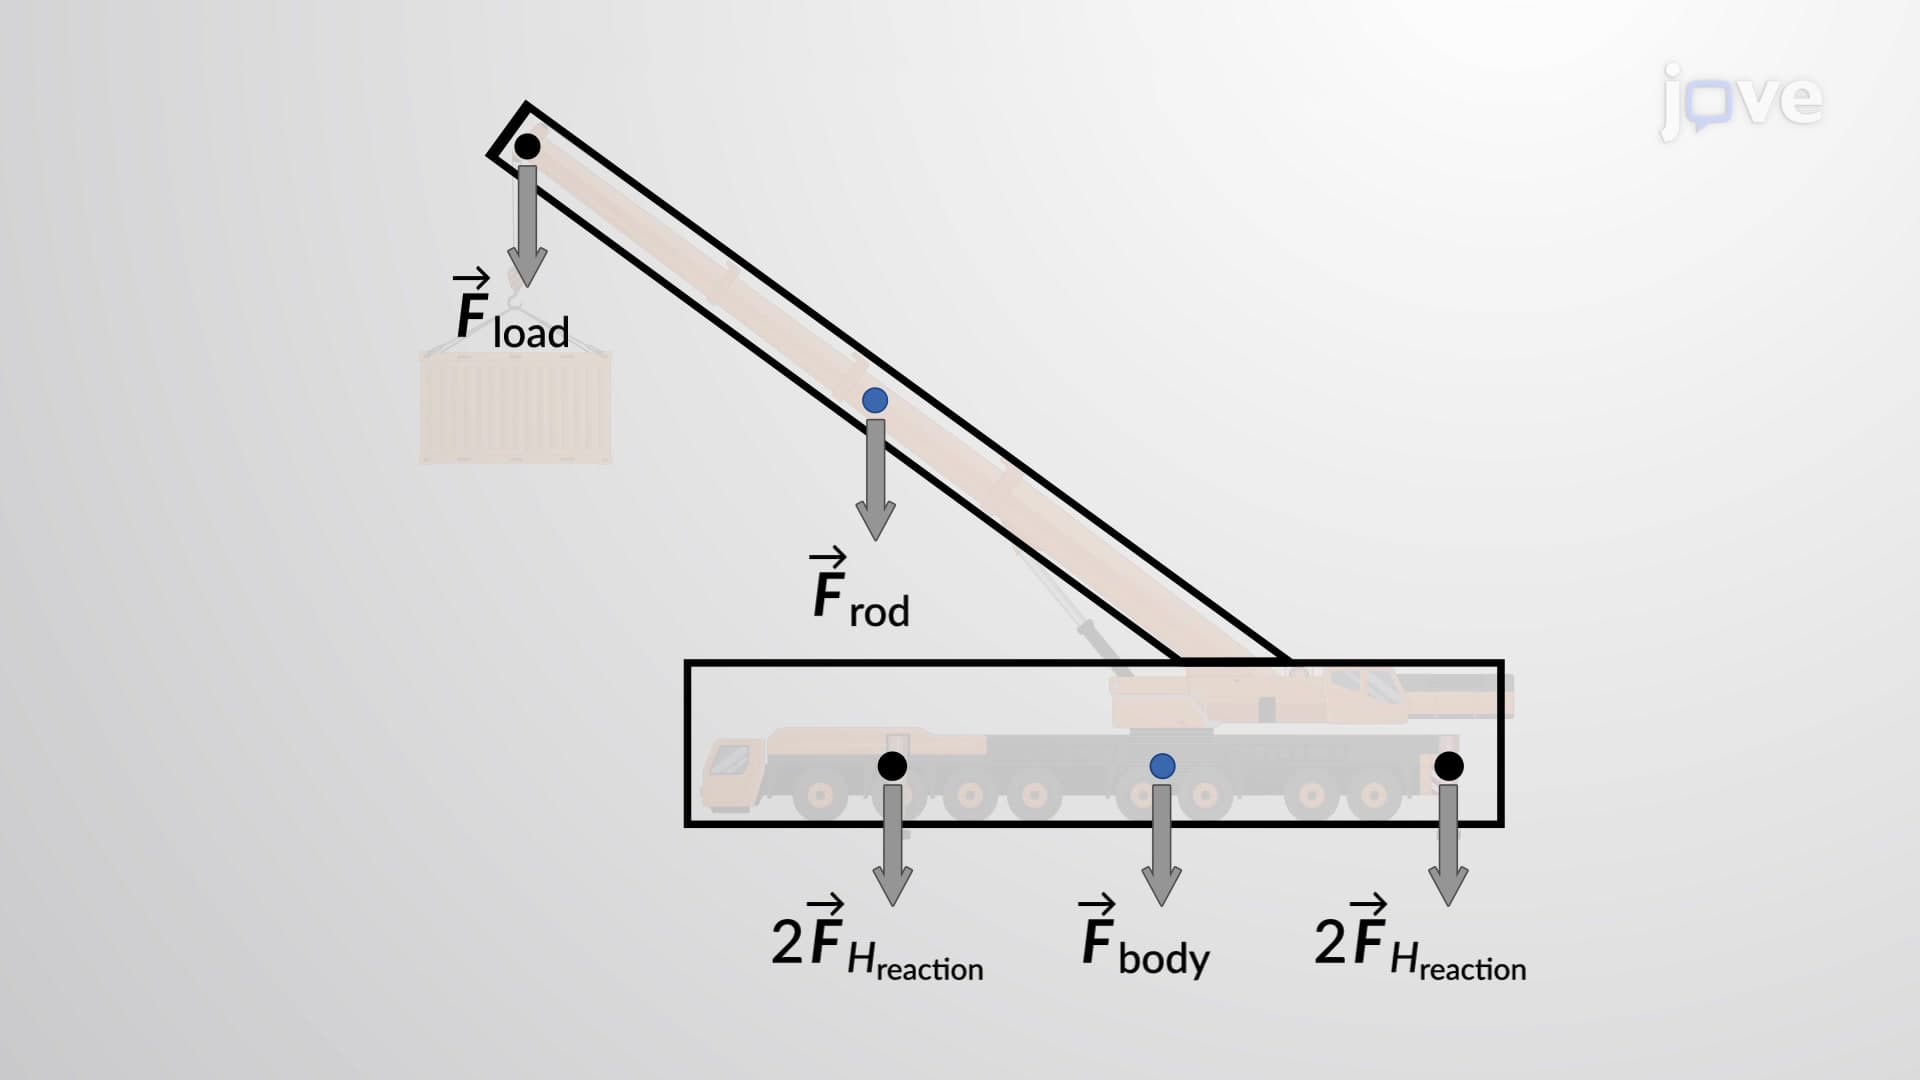
Rigid Body Equilibrium Problems - I
 01:21
Rigid Body Equilibrium Problems - II
Consider two children sitting on a seesaw, which has negligible mass. The first child has a mass (m1) of 26 kg and sits at point A, which is 1.6 meters (r1) from the pivot point B; the second child has a mass (m2) of 32 kg and sits at point C. How far from the pivot point B should the second child sit (r2) to balance the seesaw?
 01:30
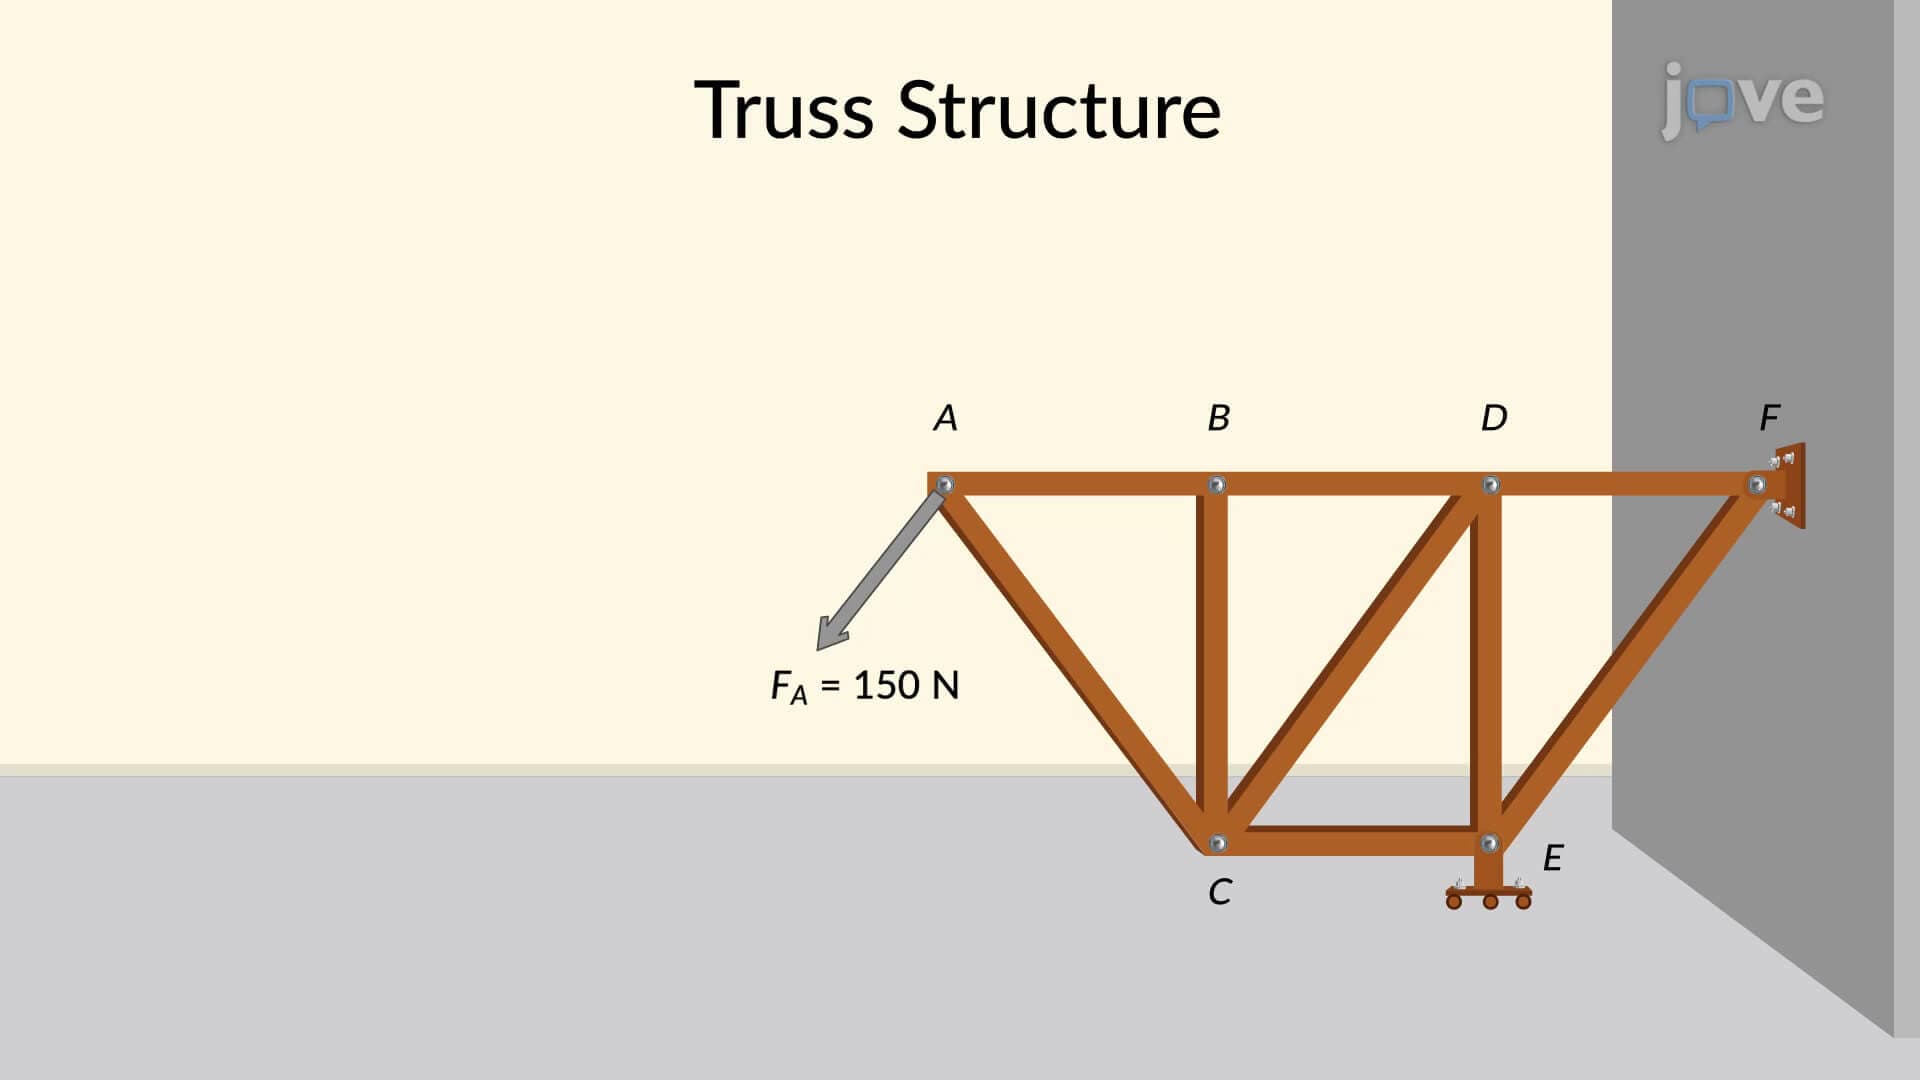
Method of Joints: Problem Solving II
 01:30
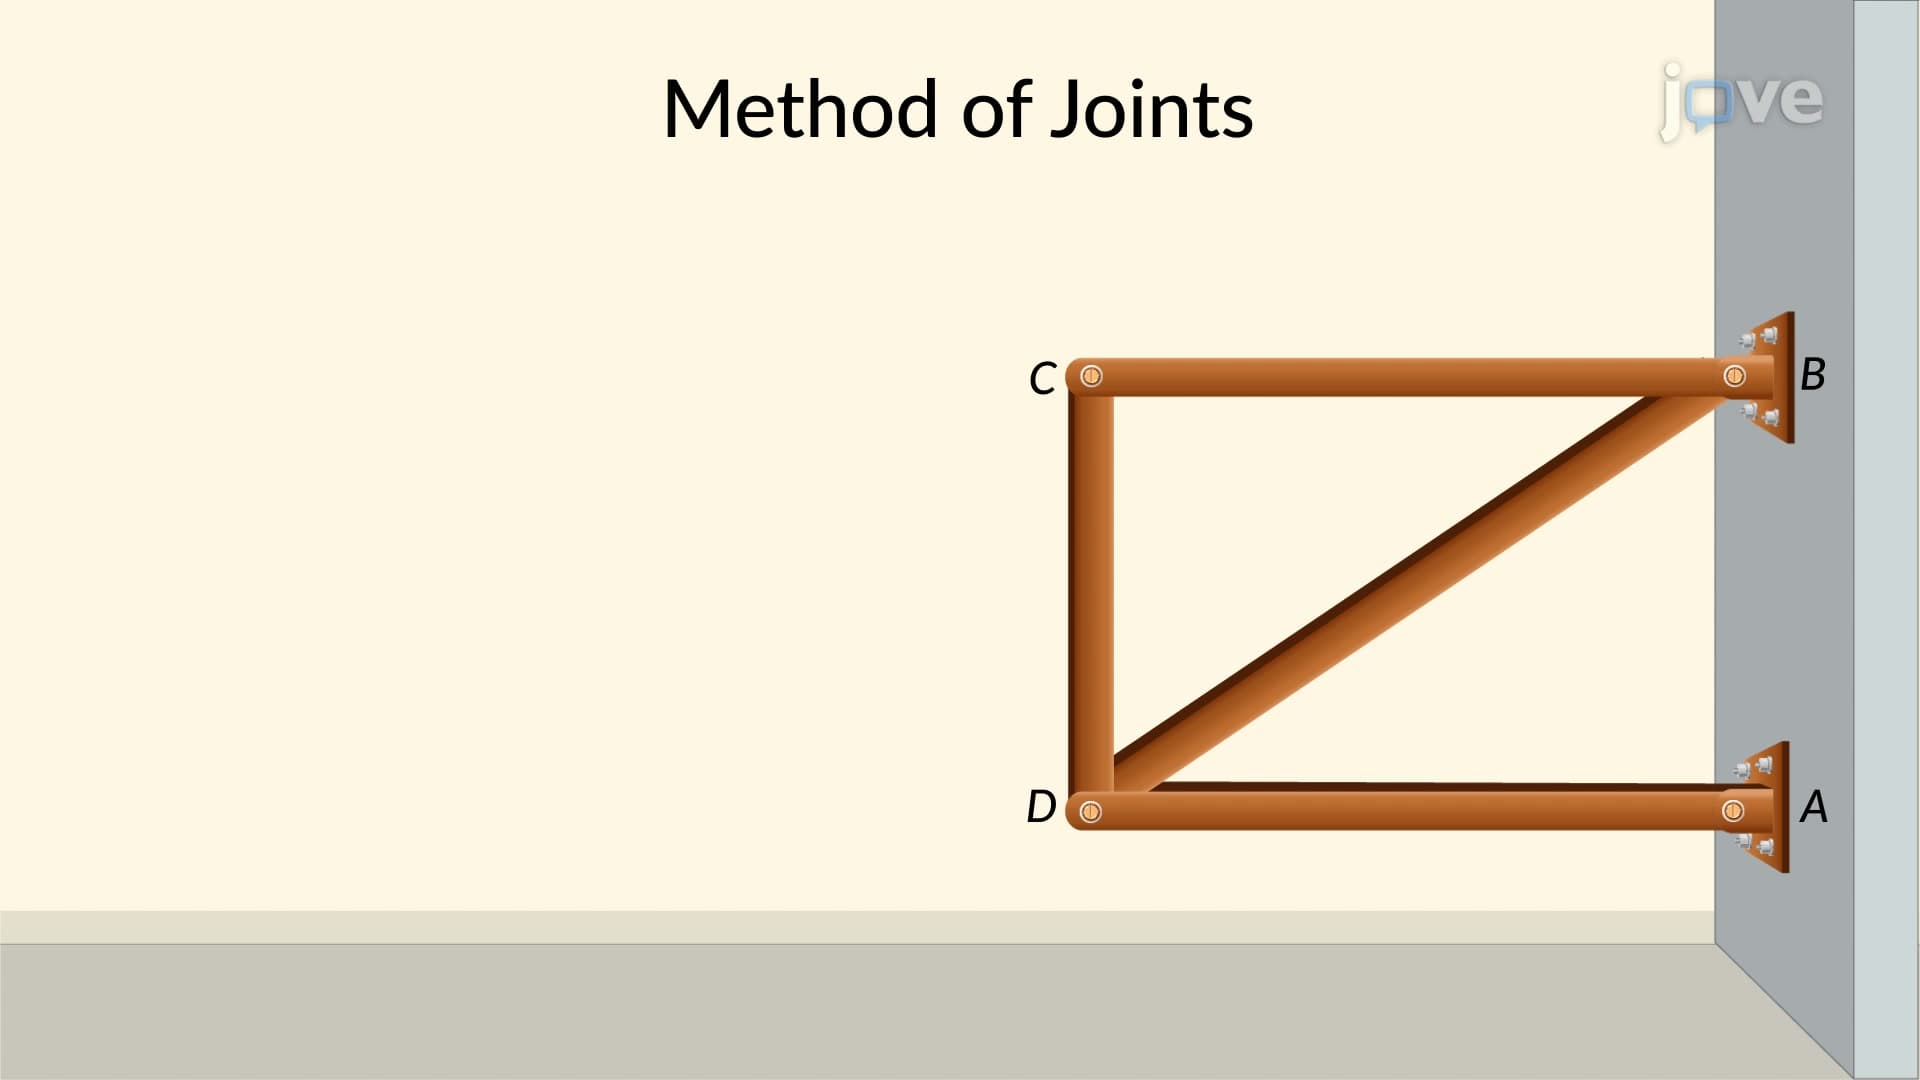
Method of Joints: Problem Solving I