[Theory and software of the hexapod external fixator]
Related Experiment Video
Updated: Sep 27, 2026
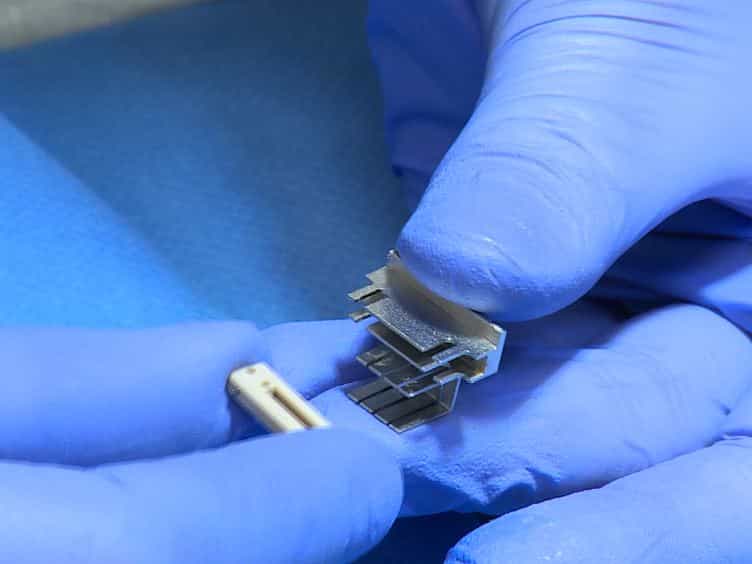
Adjustable Stiffness, External Fixator for the Rat Femur Osteotomy and Segmental Bone Defect Models
Published on: October 9, 2014
K Seide1, J Wolnack, N Weinrich
1Berufsgenossenschaftliches Unfallkrankenhaus Hamburg. k.seide@buk-hamburg.de

Abstract:
Using hexapod kinematics (Stewart platform), an external fixator was developed that can be adjusted in all six spatial degrees of freedom by means of six linear adjusting elements. With such a system, any desired three-dimensional bone movements, for example, fracture reduction or deformity correction, can be effected exactly, without having temporarily to compromise any stability already achieved or to rearrange the construction during treatment. Since the introduction of the hexapod principle by Stewart in 1965, computerized control has been deemed necessary for its application. This paper describes the mathematical basis and the software developed for clinical use. Mathematical procedures are needed for the calculation of the inverse and forward kinematics of the hexapod, and for the description of three-dimensional movements.
More Related Videos
 08:20
A Reliable and Reproducible Critical-Sized Segmental Femoral Defect Model in Rats Stabilized with a Custom External Fixator
Published on: March 24, 2019
 07:35
Creating Rigidly Stabilized Fractures for Assessing Intramembranous Ossification, Distraction Osteogenesis, or Healing of Critical Sized Defects
Published on: April 11, 2012
