Related Experiment Videos
Multistability analysis for recurrent neural networks with unsaturating piecewise linear transfer functions
1College of Computer Science and Engineering, University of Electronic Science and Technology of China, Chengdu 610054, People's Republic of China. elezy@nus.edu.sg

Abstract:
Multistability is a property necessary in neural networks in order to enable certain applications (e.g., decision making), where monostable networks can be computationally restrictive. This article focuses on the analysis of multistability for a class of recurrent neural networks with unsaturating piecewise linear transfer functions. It deals fully with the three basic properties of a multistable network: boundedness, global attractivity, and complete convergence. This article makes the following contributions: conditions based on local inhibition are derived that guarantee boundedness of some multistable networks, conditions are established for global attractivity, bounds on global attractive sets are obtained, complete convergence conditions for the network are developed using novel energy-like functions, and simulation examples are employed to illustrate the theory thus developed.
Related Concept Videos
 01:25
Multimachine Stability
In analyzing the system, the nodal equations represent the relationship between bus voltages, machine voltages, and machine currents. The nodal equation is given by:
 01:26
Linear Approximation in Frequency Domain
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear.
 01:24
Pole and System Stability
Simple poles are unique roots of the denominator polynomial. Each simple pole corresponds to a distinct solution to the system's characteristic equation, typically resulting in exponential decay terms in the system's response.
 01:21
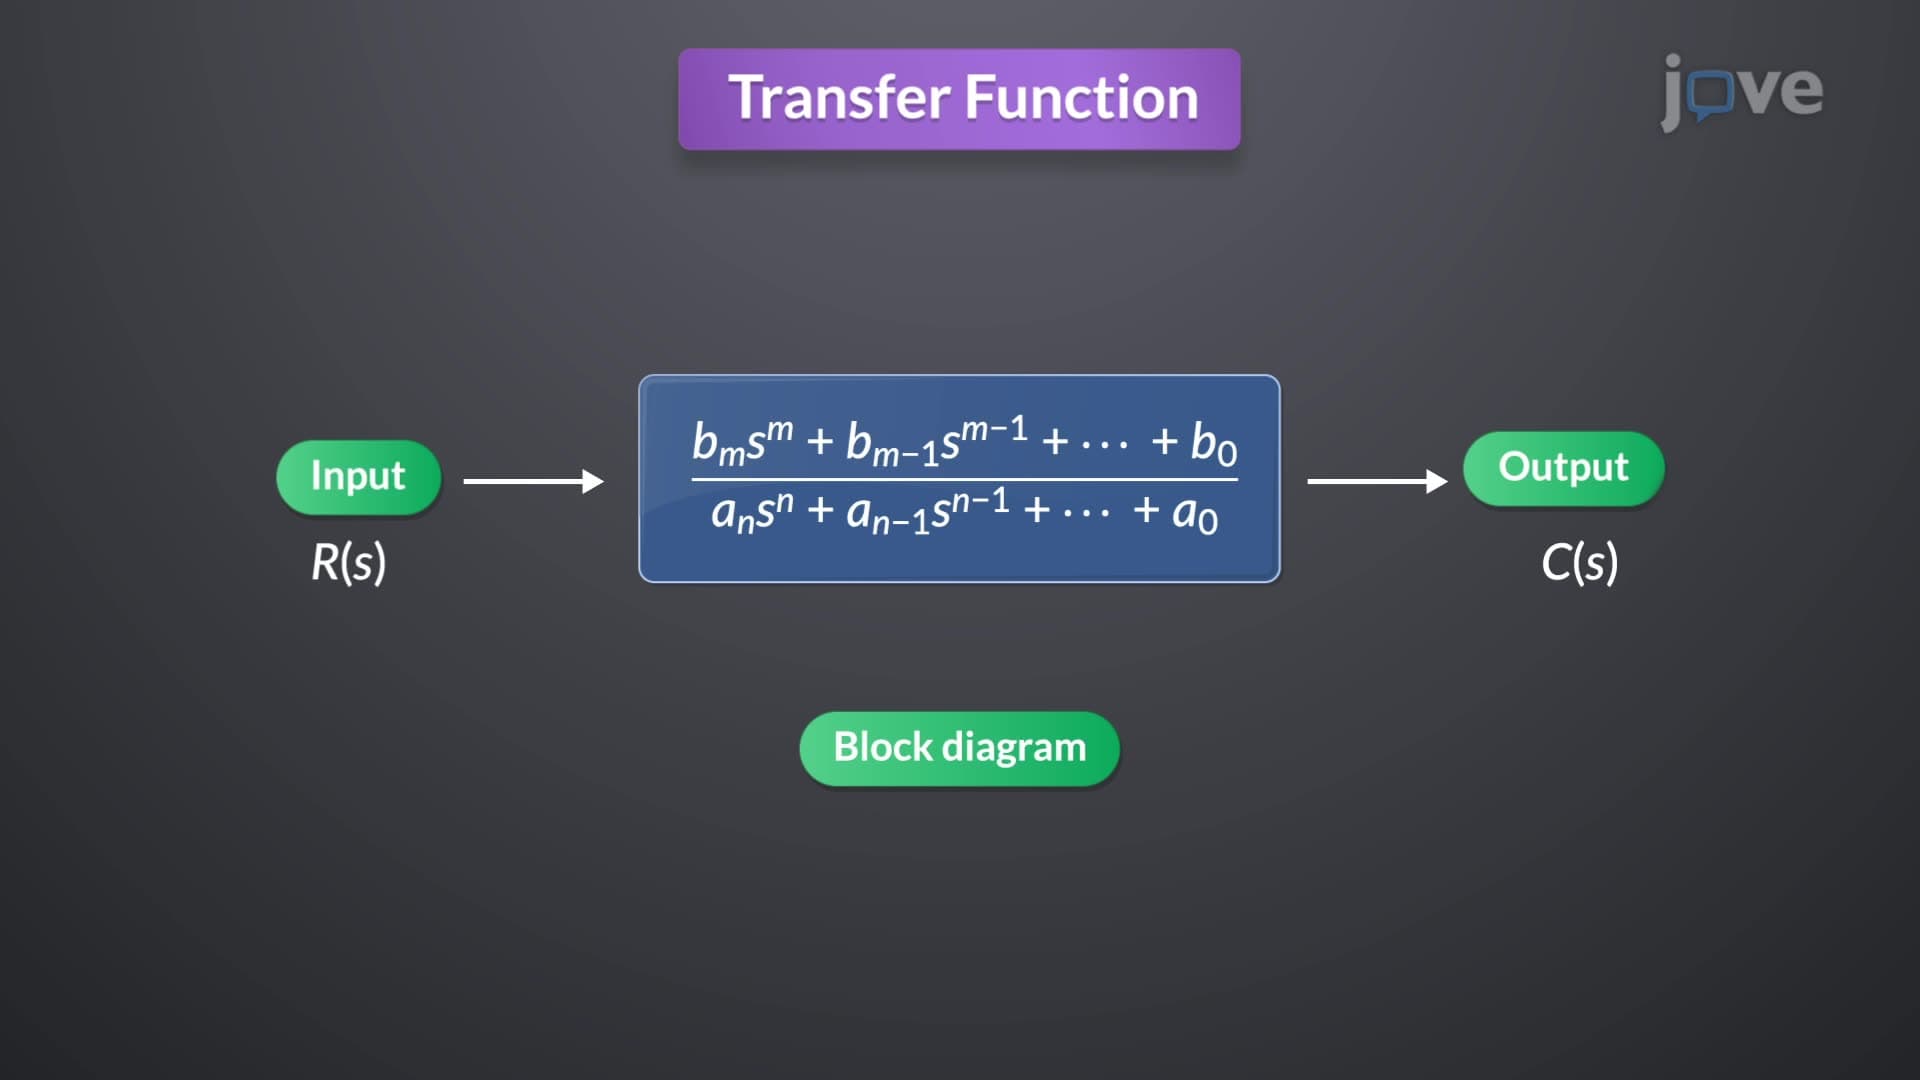
Transfer Function in Control Systems
To derive the transfer function, consider a general nth-order linear time-invariant...
 01:23
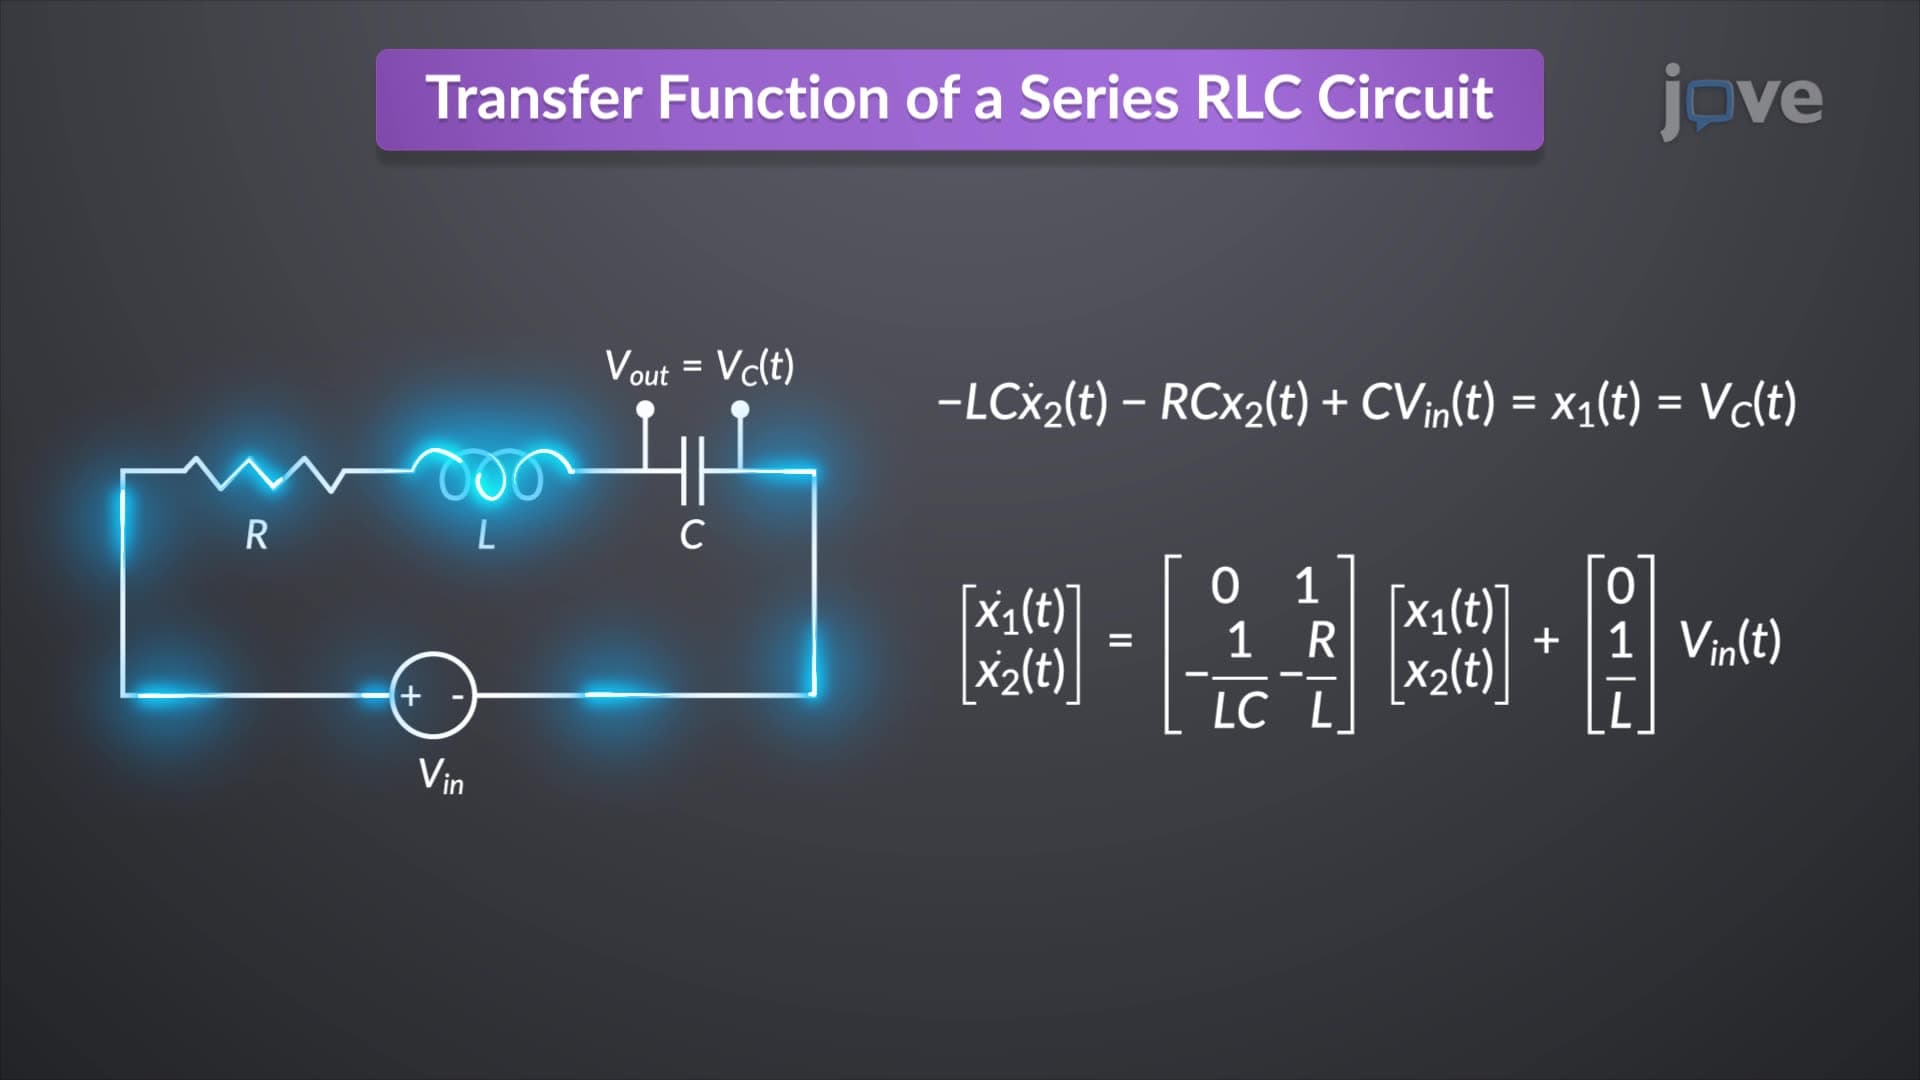
Transfer Function to State Space
In an RLC...
 01:18
Second Order systems II
If ζ...