Activity driven adaptive stochastic resonance

G Wenning1, K Obermayer

  • 1Department of Electrical Engineering and Computer Science, Technical University of Berlin, Franklinstrasse 28/29, 10587 Berlin, Germany.

Related Concept Videos

Concept of Resonance and its Characteristics01:19

Concept of Resonance and its Characteristics

If a driven oscillator needs to resonate at a specific frequency, then very light damping is required. An example of light damping includes playing piano strings and many other musical instruments. Conversely, to achieve small-amplitude oscillations as in a car's suspension system, heavy damping is required. Heavy damping reduces the amplitude, but the tradeoff is that the system responds at more frequencies. Speed bumps and gravel roads prove that even a car's suspension system is not immune...
Forced Oscillations01:06

Forced Oscillations

When an oscillator is forced with a periodic driving force, the motion may seem chaotic. The motions of such oscillators are known as transients. After the transients die out, the oscillator reaches a steady state, where the motion is periodic, and the displacement is determined.
Types of Damping01:20

Types of Damping

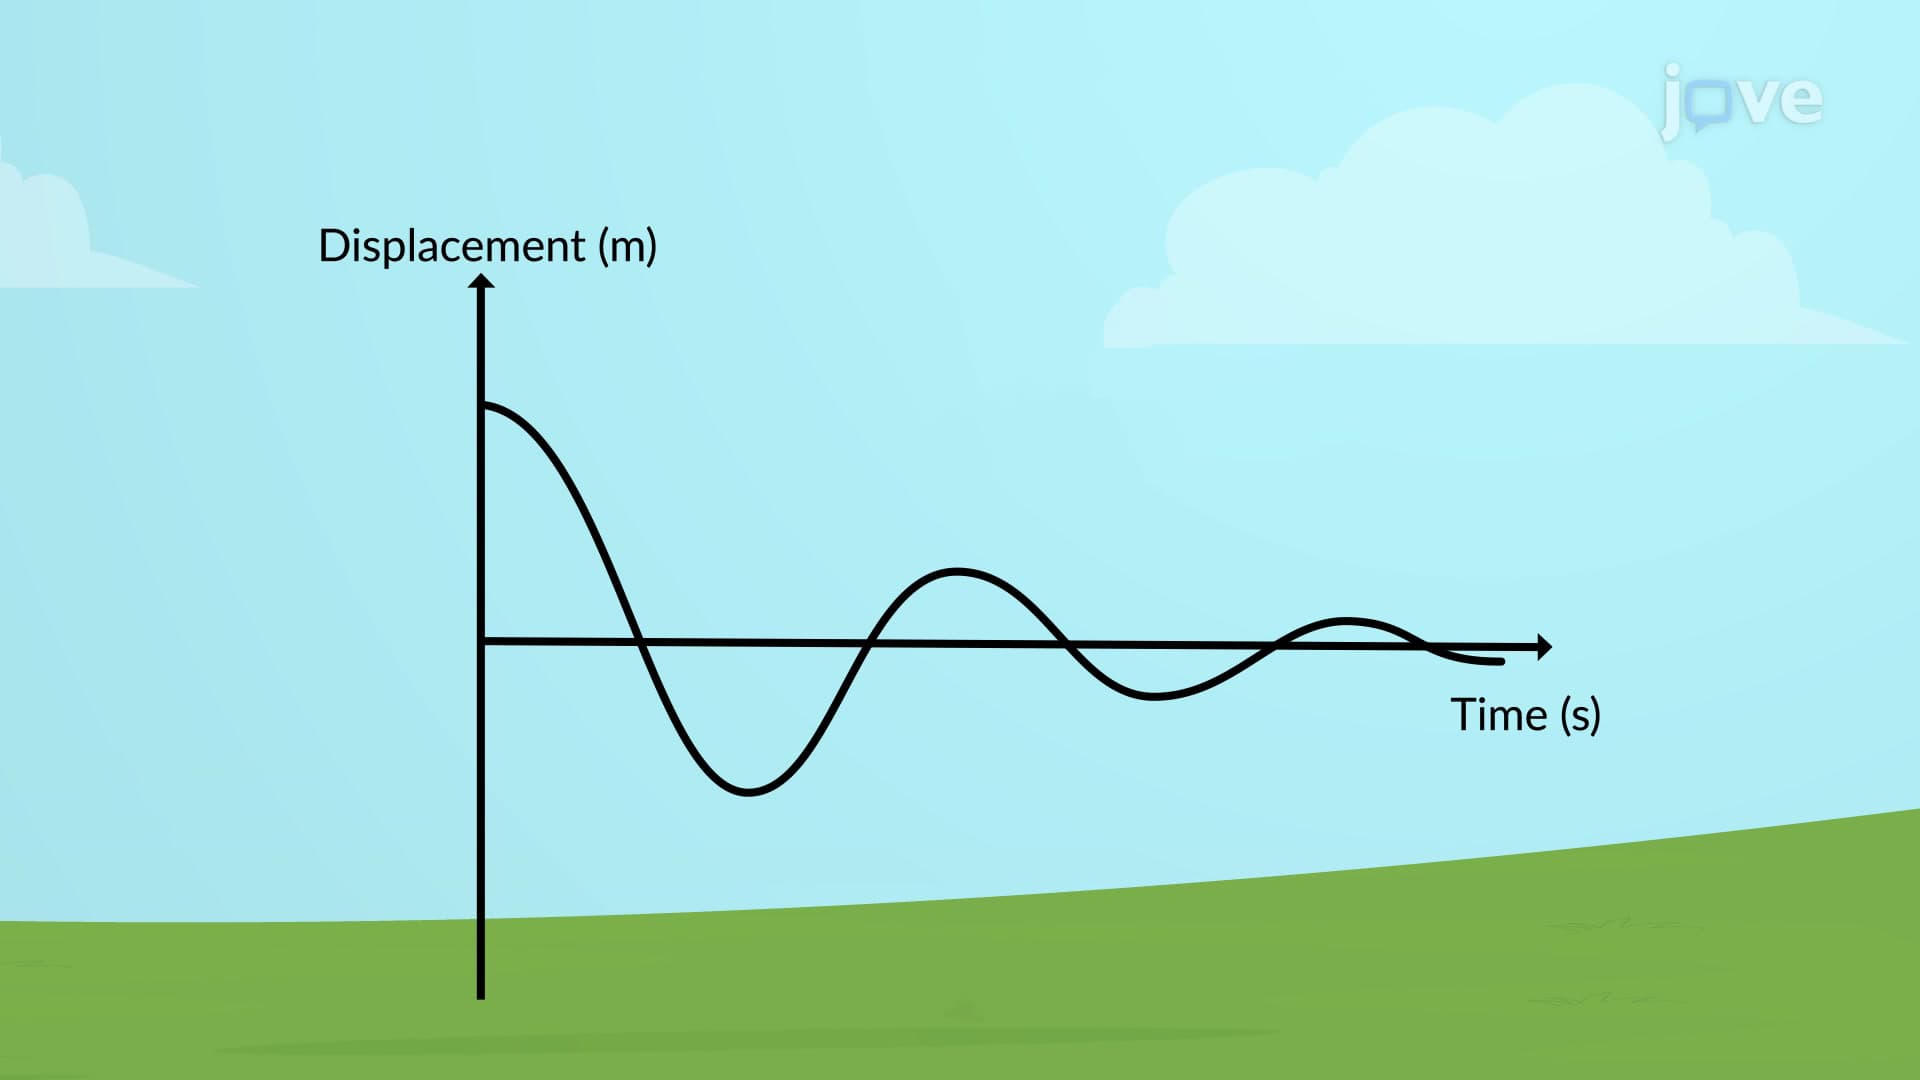
If the amount of damping in a system is gradually increased, the period and frequency start to become affected because damping opposes, and hence slows, the back and forth motion (the net force is smaller in both directions). If there is a very large amount of damping, the system does not even oscillate; instead, it slowly moves toward equilibrium. In brief, an overdamped system moves slowly towards equilibrium, whereas an underdamped system moves quickly to equilibrium but will oscillate about...
Muscle Stimulation Frequency01:22

Muscle Stimulation Frequency

The contraction strength of muscles is regulated by motor neurons, which modulate the frequency of action potentials dispatched to the motor units based on the body's requirements. This process of varying the muscle stimulation frequency allows muscles to contract with a force that is precisely tailored to the needs of the moment, whether lifting a feather or a heavy box.
Wave summation
At low firing rates, motor neurons induce individual twitch contractions in muscle fibers. These twitches...
State Space Representation01:27

State Space Representation

The frequency-domain technique, commonly used in analyzing and designing feedback control systems, is effective for linear, time-invariant systems. However, it falls short when dealing with nonlinear, time-varying, and multiple-input multiple-output systems. The time-domain or state-space approach addresses these limitations by utilizing state variables to construct simultaneous, first-order differential equations, known as state equations, for an nth-order system.
Consider an RLC circuit, a...
Active Filters01:25

Active Filters

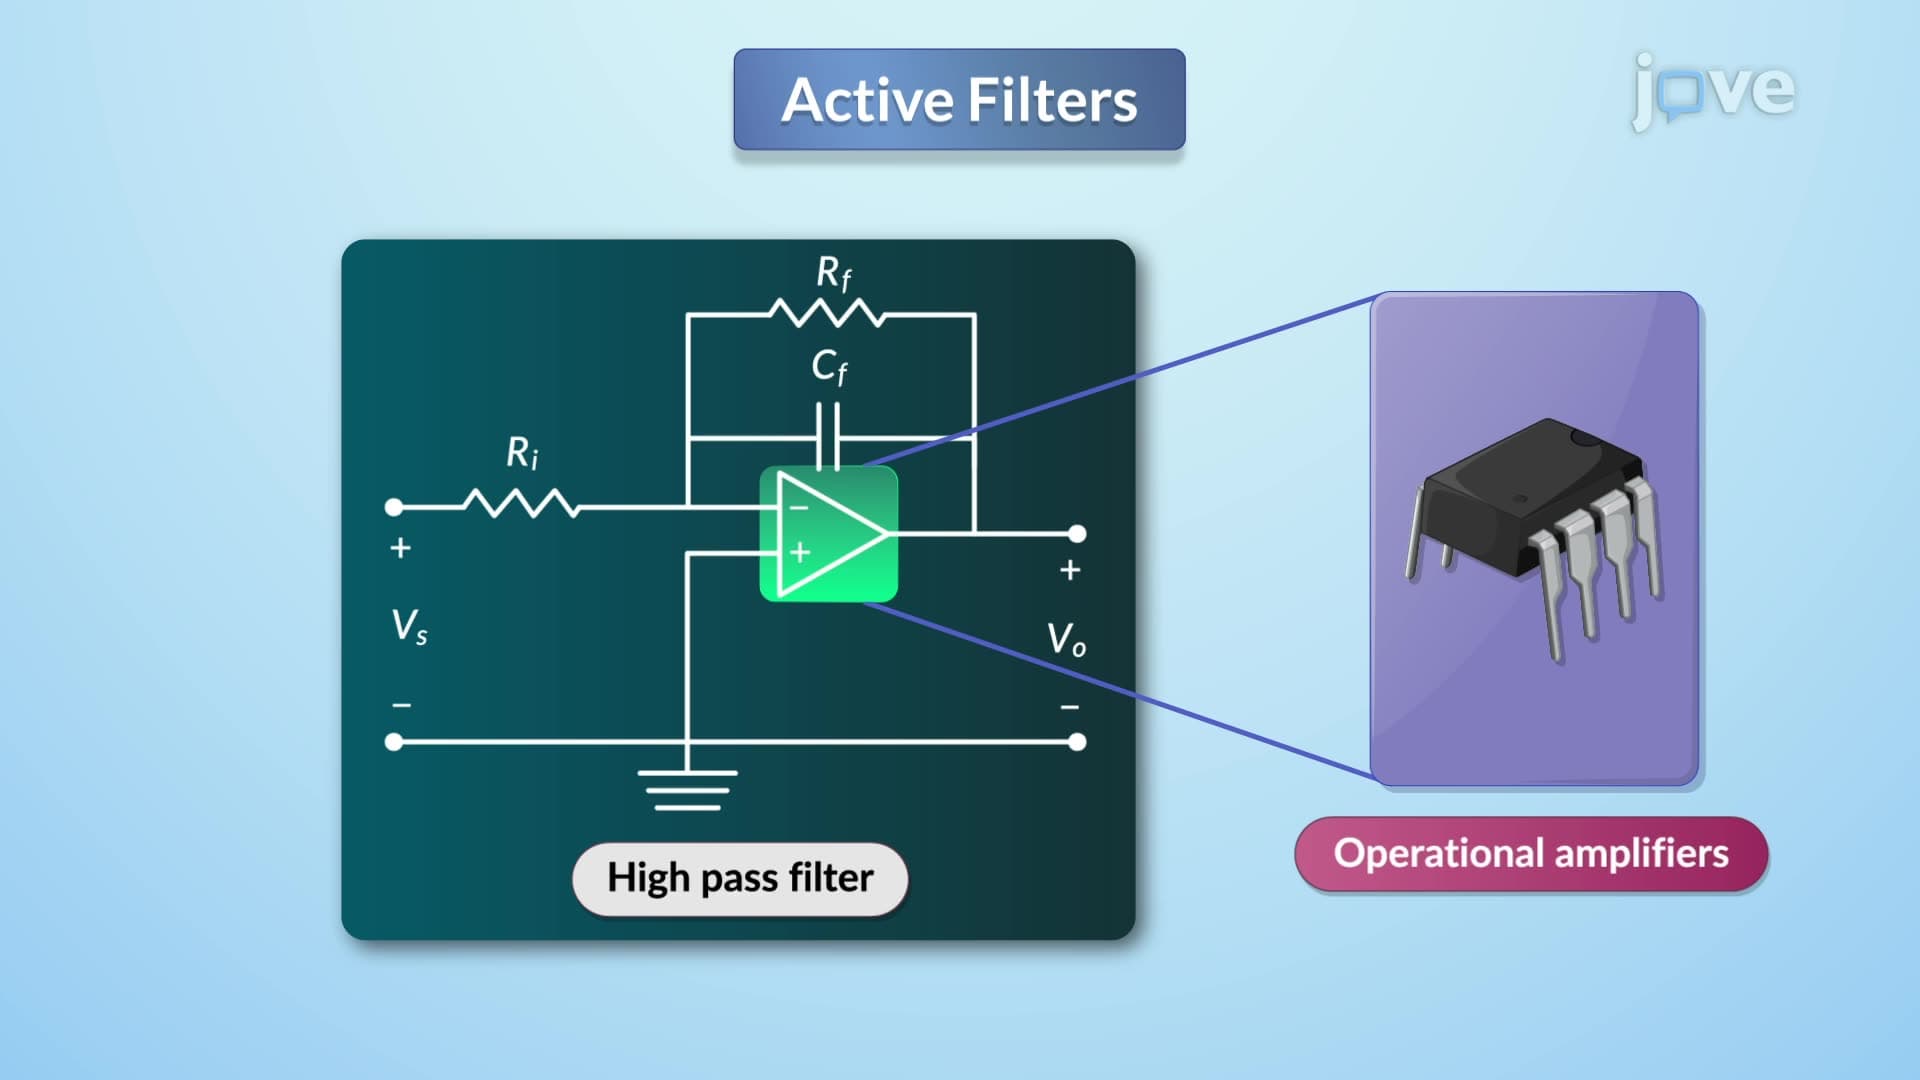
Active filters are electronic circuits that use operational amplifiers (op-amps), resistors, and capacitors to filter out unwanted frequency components from a signal. A first-order low-pass active filter is designed to pass signals with a frequency lower than a certain cutoff frequency and attenuate frequencies higher than that cutoff frequency. The transfer function for a first-order low-pass active filter is: