Visual development and the acquisition of motion velocity sensitivities
Related Experiment Video
Updated: Sep 26, 2026
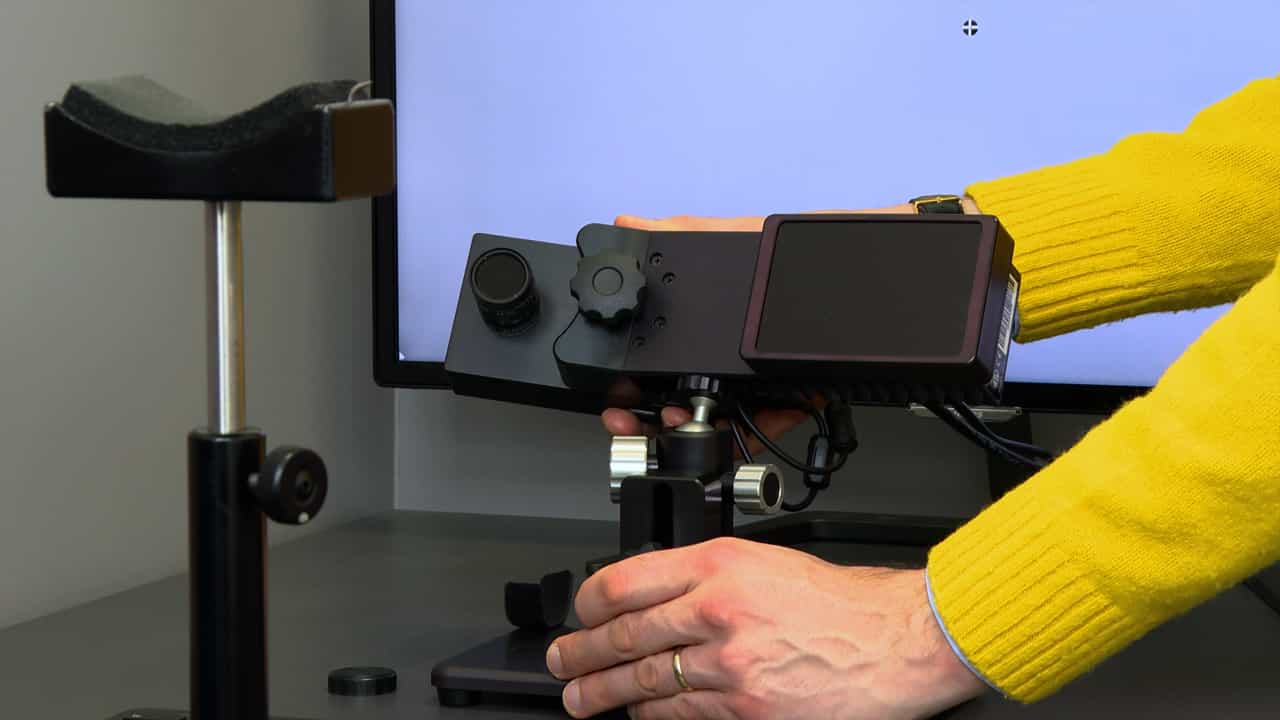
Motion-Acuity Test for Visual Field Acuity Measurement with Motion-Defined Shapes
Published on: February 23, 2024
Robert A Jacobs1, Melissa Dominguez
1Department of Brain and Cognitive Sciences, University of Rochester, NY 14627, USA. robbie@bcs.rochester.edu

Abstract:
We consider the hypothesis that systems learning aspects of visual perception may benefit from the use of suitably designed developmental progressions during training. Four models were trained to estimate motion velocities in sequences of visual images. Three of the models were developmental models in the sense that the nature of their visual input changed during the course of training. These models received a relatively impoverished visual input early in training, and the quality of this input improved as training progressed. One model used a coarse-to-multiscale developmental progression (it received coarse-scale motion features early in training and finer-scale features were added to its input as training progressed), another model used a fine-to-multiscale progression, and the third model used a random progression. The final model was nondevelopmental in the sense that the nature of its input remained the same throughout the training period. The simulation results show that the coarse-to-multiscale model performed best. Hypotheses are offered to account for this model's superior performance, and simulation results evaluating these hypotheses are reported. We conclude that suitably designed developmental sequences can be useful to systems learning to estimate motion velocities. The idea that visual development can aid visual learning is a viable hypothesis in need of further study.
Related Concept Videos
 01:24
Vision
 01:26
Visual System
Once through the pupil, the light passes through the lens, a...
 01:15
Depth Perception and Spatial Vision
 01:31
Motion in Space: Velocity and Acceleration
 01:24
Relative Motion Analysis - Velocity
When an external force is exerted, it sets the crank into a rotational movement. This, in turn, instigates the motion of the connecting rod, leading to what is referred to as a general plane motion. This process involves two key points - point A on the connecting rod...
 01:34
Velocity and Position by Graphical Method