Related Experiment Video
Updated: Sep 26, 2026
Optical Scatter Microscopy Based on Two-Dimensional Gabor Filters
Published on: June 2, 2010
Optical filter architecture for approximating any 2 X 2 unitary matrix
1Lucent Technologies, Bell Laboratories, Room 1D350, Murray Hill, New Jersey 07974, USA. cmadsen@lucent.com

Abstract:
A new optical filter architecture and a new design methodology are presented for approximating any frequency-dependent 2 x 2 unitary matrix that consists of two coupled phase and amplitude responses. Design examples are provided for the compensation of polarization mode dispersion (PMD) by approximating the inverse of a synthesized fiber's Jones matrix. Compensation of the channel PMD over the signal bandwidth is demonstrated, as required for demultiplexing channels in a polarization-multiplexed system.
Related Concept Videos
 01:25
Active Filters
 01:08
Vector Algebra: Method of Components
In many applications, the magnitudes and directions of...
 01:26
Linear Approximation in Frequency Domain
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear.
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length, the...
 01:27
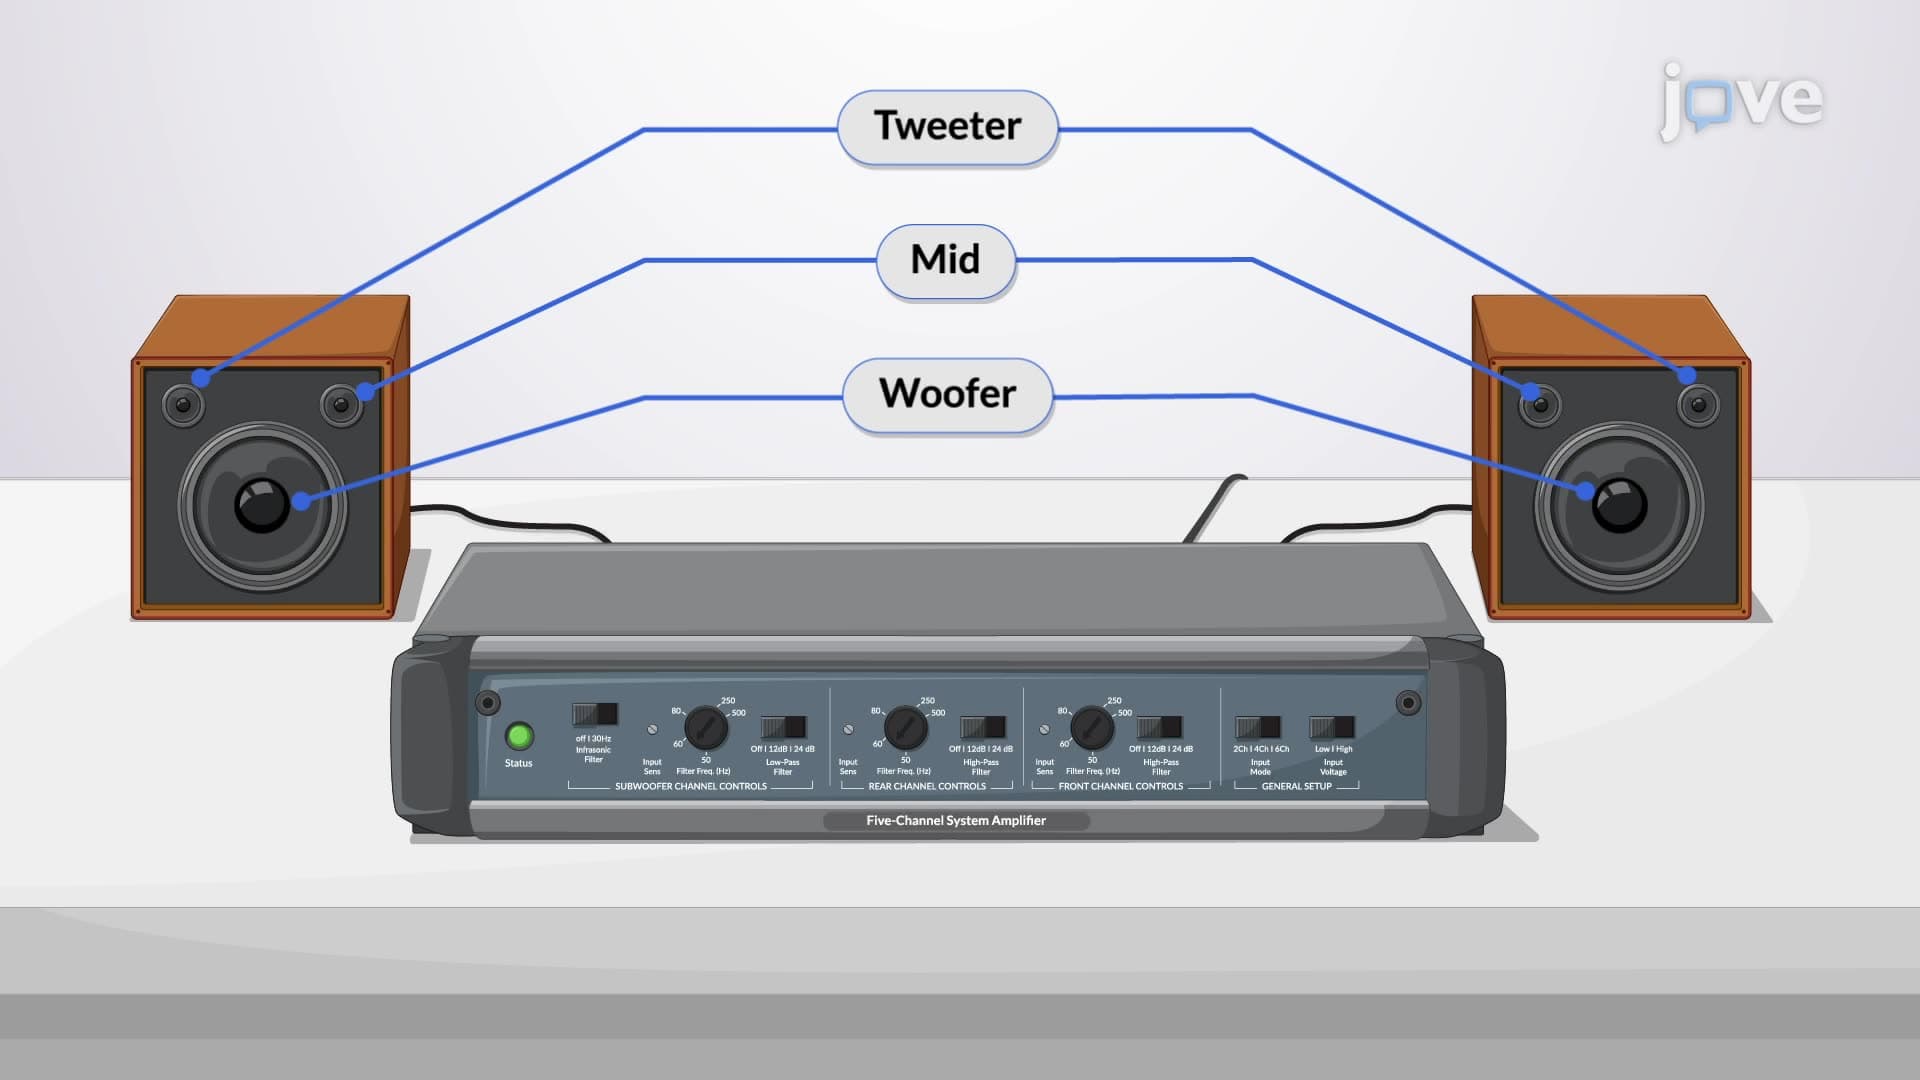
Passive Filters
Low-Pass Filters
Low-pass filters are designed to transmit signals with frequencies lower than the cutoff frequency, ωc, and attenuate those above it. The cutoff frequency...
 01:17
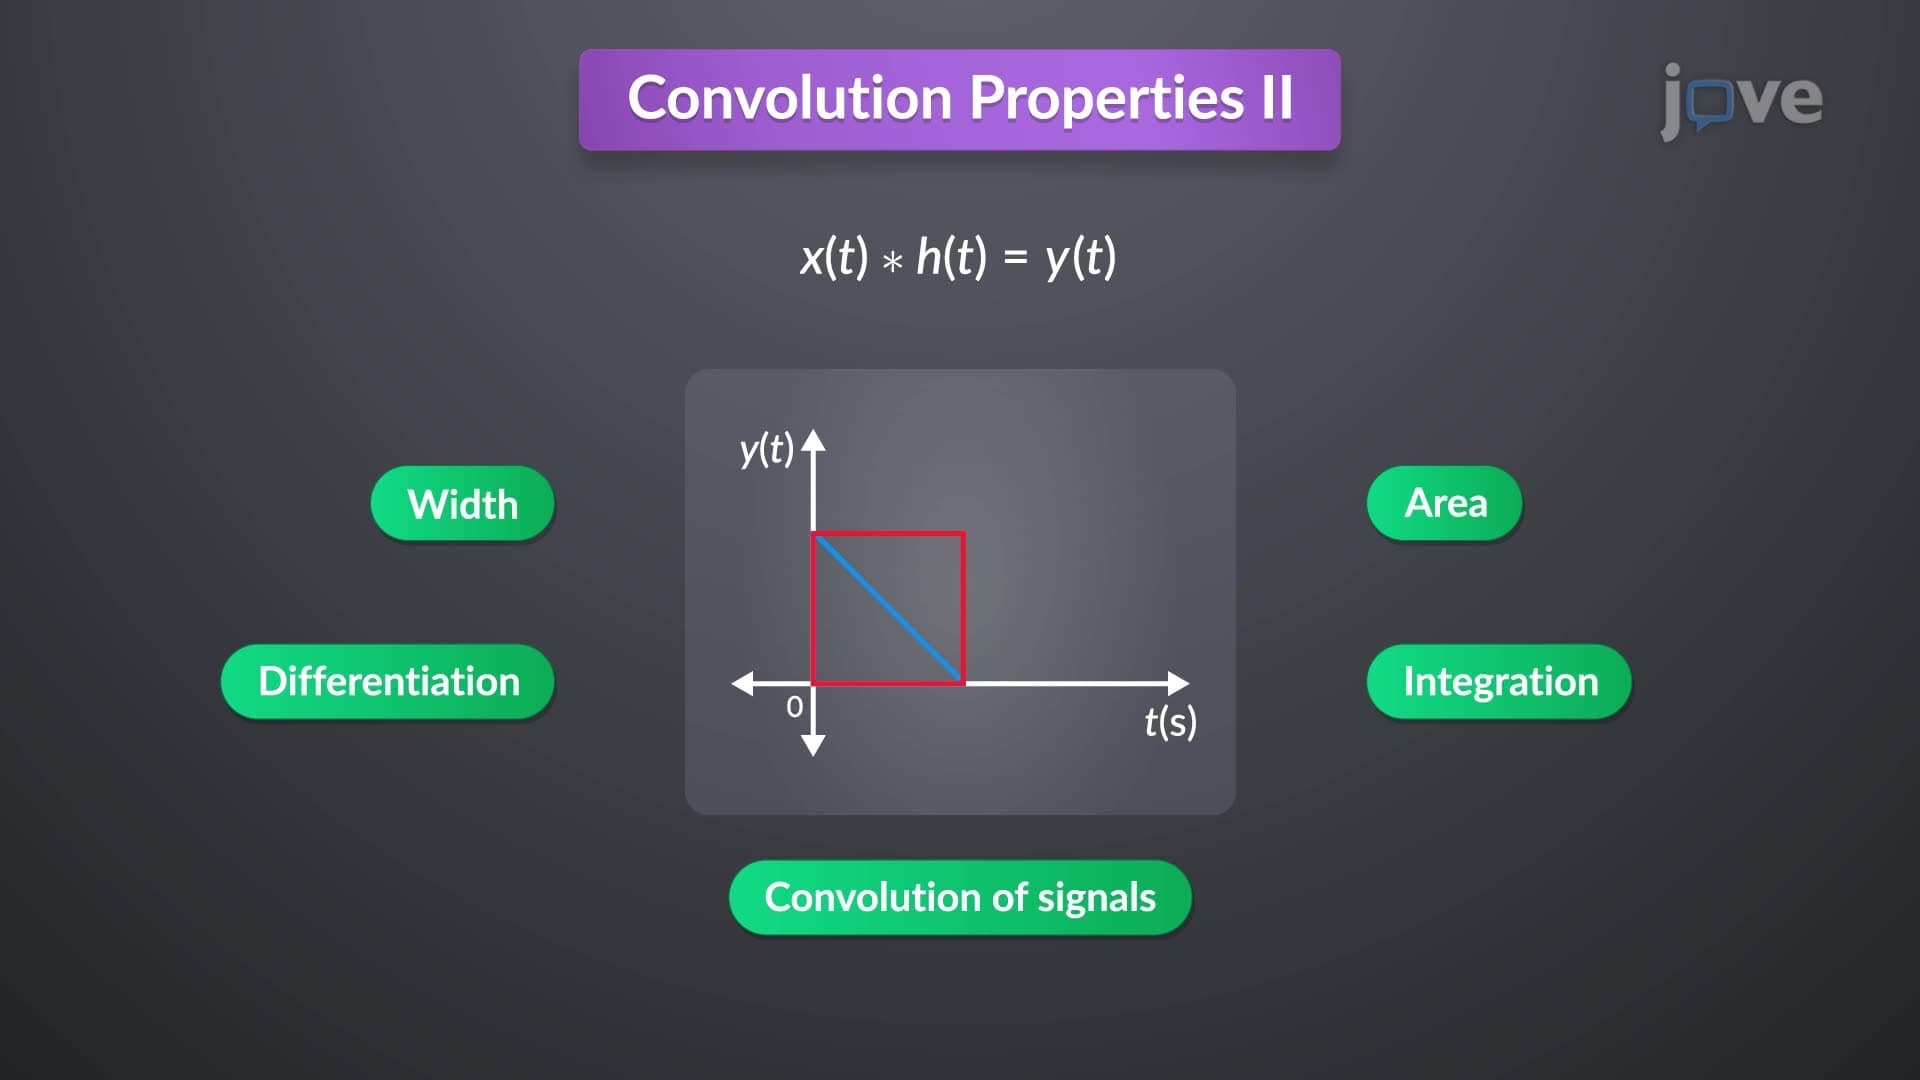
Convolution Properties II
The width property indicates that if the durations of input signals are T1 and T2, then the width of the output response equals the sum of both durations, irrespective of the shapes of the two functions. For instance, convolving two rectangular pulses with durations of 2 seconds and 1 second results in a function with a width of 3 seconds.
The area property asserts that the area under the...