Related Experiment Video
Updated: Sep 26, 2026
Simulation of Human-induced Vibrations Based on the Characterized In-field Pedestrian Behavior
Published on: April 13, 2016
Energetic Cost and Stability During Human Walking at the Preferred Stride Velocity
K J Holt1, S F Jeng, R Ratcliffe RR
1Department of Physical Therapy, Sargent College of Allied Health Professions, 635 Commonwealth Avenue, Boston, MA 02215, USA. HOLT@sarvx1.bu.edu

Abstract:
The possibility that preferred modes of locomotion emerge from dynamical and optimality constraints and the energetic and dynamical constraints on preferred and predicted walking frequency are explored in this article. Participants were required to walk on a treadmill at their preferred frequency, at a frequency predicted as the resonance of a hybrid pendulum-spring model of the legs, and at frequencies +/-15%, +/-25%, +/-35% of the predicted frequency. Walking at the preferred and predicted frequencies resulted in minimal metabolic costs and maximal stability of the head and joint actions. Mechanical energy conservation was constant across conditions. The head was more stable than the joints. The joints appeared to be in service of the head in maintaining a stable trajectory. The major findings of this study suggest a complementary relationship between energetic (physiological) and stability constraints in the adoption of a preferred frequency of walking. Multiple subsystems may be involved in constraining observed macroscopic behavior in intact biological systems. The approach and results of the study imply that a useful tack in understanding how dynamical control structures arise is to study the potential criteria that serve to act as constraints on skilled movement patterns in unimpaired and impaired populations.
More Related Videos
Related Concept Videos
 01:10
Energy Diagrams - II
The point in the energy diagram at which the system’s potential energy is the lowest is known as the local minima. The system tends to stay in this position indefinitely unless acted upon by a net force. The slope of the potential energy diagram at the local minima is zero, indicating that zero net force is acting on the system. The slope...
 01:14
Energy Diagrams - I
Take the example of a skater on a parabolic ramp. The potential energy at different points along the ramp will be proportional to the height of the ramp, which varies quadratically with the horizontal position on the ramp. As the skater moves down the ramp from the highest position,...
 01:10
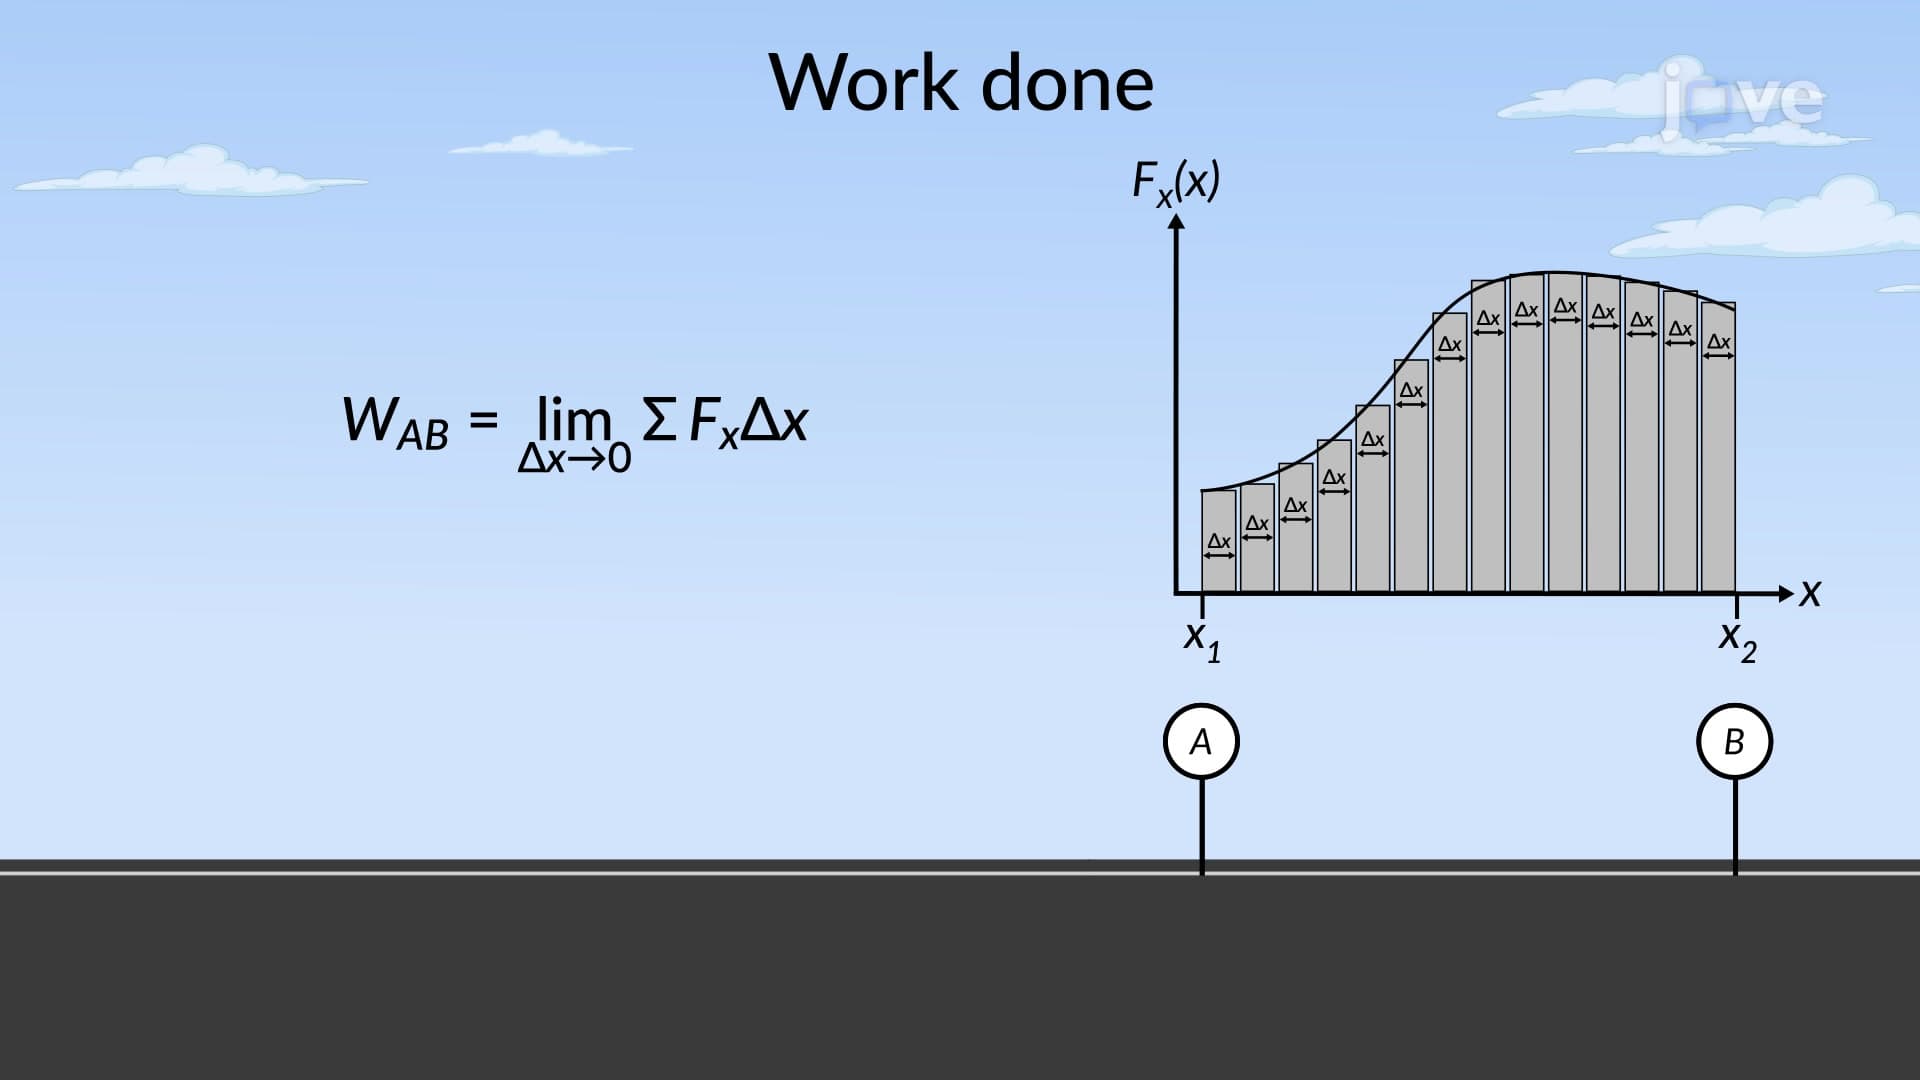
Work and Energy for Variable Forces