Related Experiment Video
Updated: Sep 25, 2026
Setting Limits on Supersymmetry Using Simplified Models
Published on: November 15, 2013
Quasi-periodicity, global stability and scaling in a model of Hamiltonian round-off
John Lowenstein1, Spyros Hatjispyros, Franco Vivaldi
1School of Mathematical Sciences, Queen Mary and Westfield College, Mile End Road, London E1 4NS, England.

Abstract:
We investigate the effects of round-off errors on the orbits of a linear symplectic map of the plane, with rational rotation number nu=p/q. Uniform discretization transforms this map into a permutation of the integer lattice Z(2). We study in detail the case q=5, exploiting the correspondence between Z and a suitable domain of algebraic integers. We completely classify the orbits, proving that all of them are periodic. Using higher-dimensional embedding, we establish the quasi-periodicity of the phase portrait. We show that the model exhibits asymptotic scaling of the periodic orbits and a long-range clustering property similar to that found in repetitive tilings of the plane. (c) 1997 American Institute of Physics.
Related Concept Videos
 01:04
Oscillations about an Equilibrium Position
 01:23
Stability of Equilibrium Configuration
A stable equilibrium occurs when a system tends to return to its original position when given a small displacement, and the potential energy is at its minimum. An example of a stable equilibrium is when a cantilever beam is fixed at one end and a weight is attached to the other end. If the weight...
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length, the...
 01:28
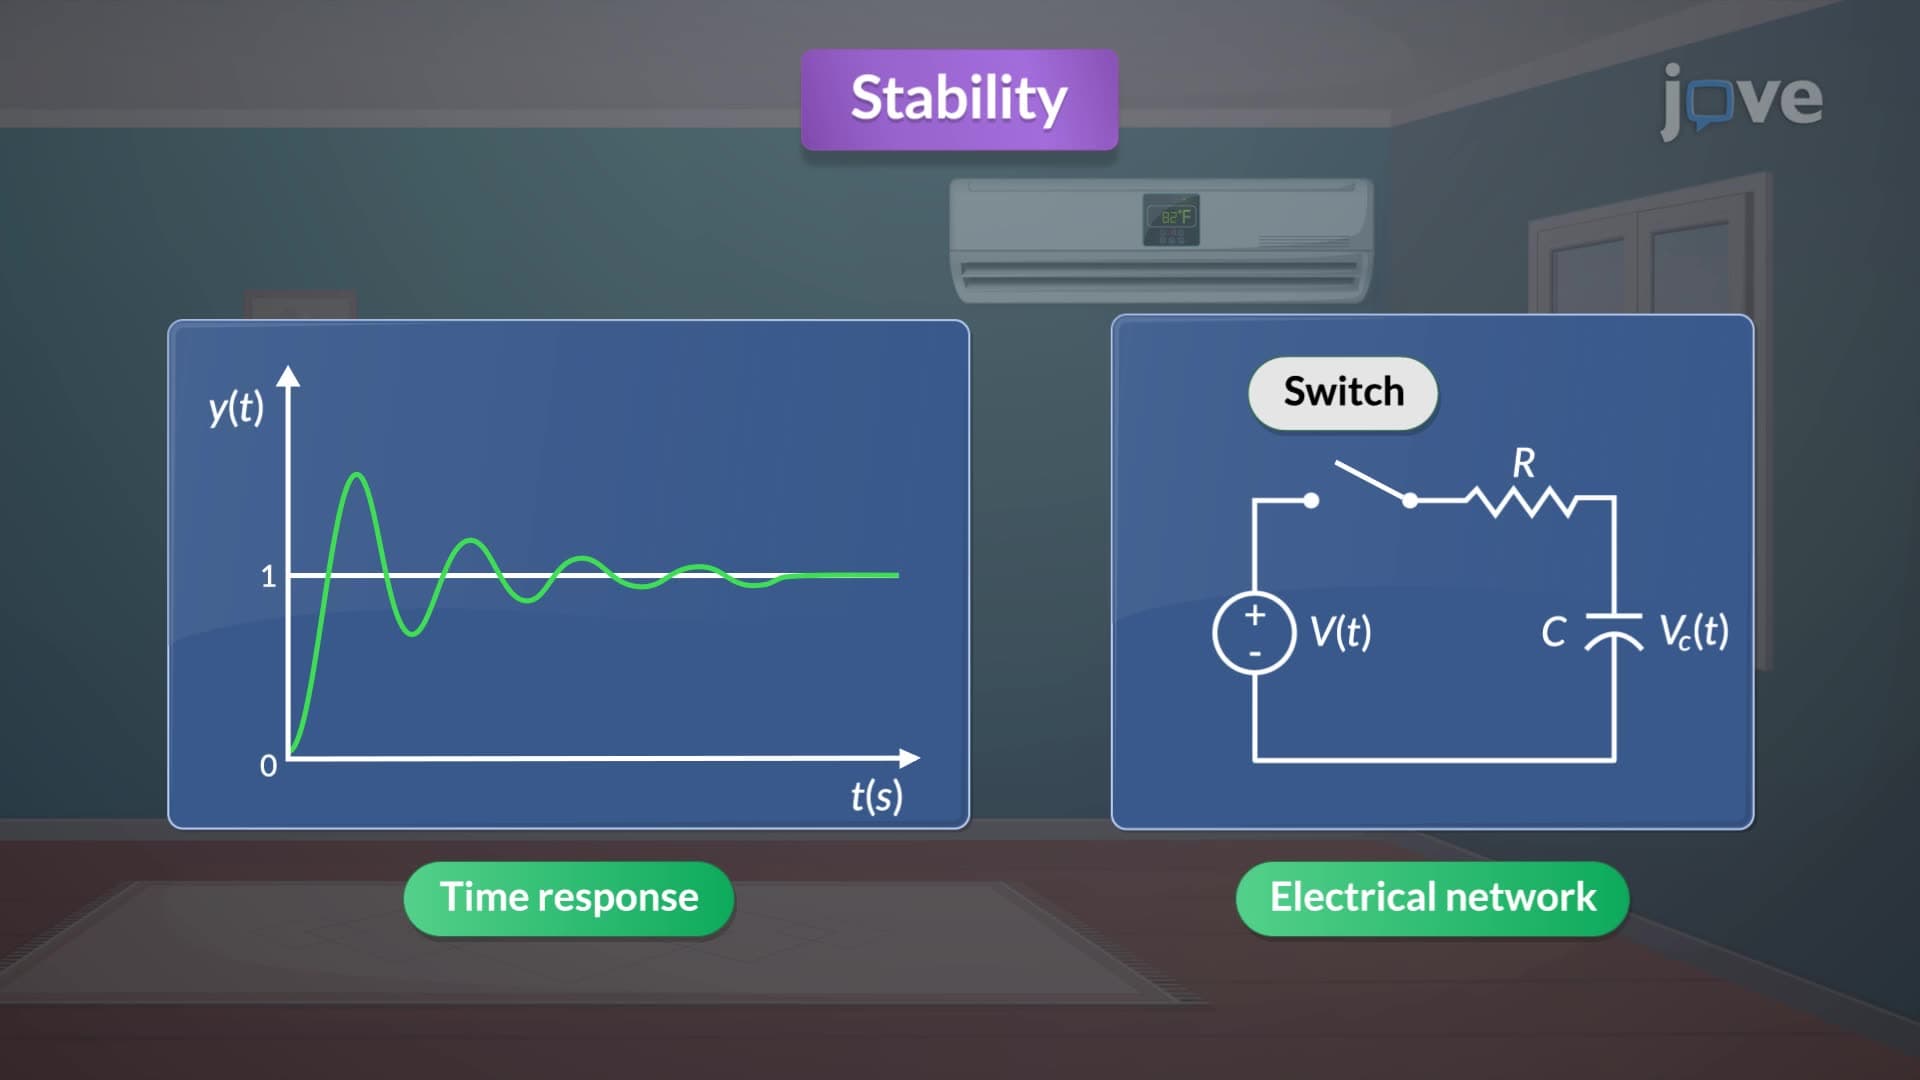
Stability
The stability of an LTI system is determined by the roots of its characteristic equation, known as poles. A system is stable if it produces a bounded...
 01:24
Pole and System Stability
Simple poles are unique roots of the denominator polynomial. Each simple pole corresponds to a distinct solution to the system's characteristic equation, typically resulting in exponential decay terms in the system's response.
 01:13
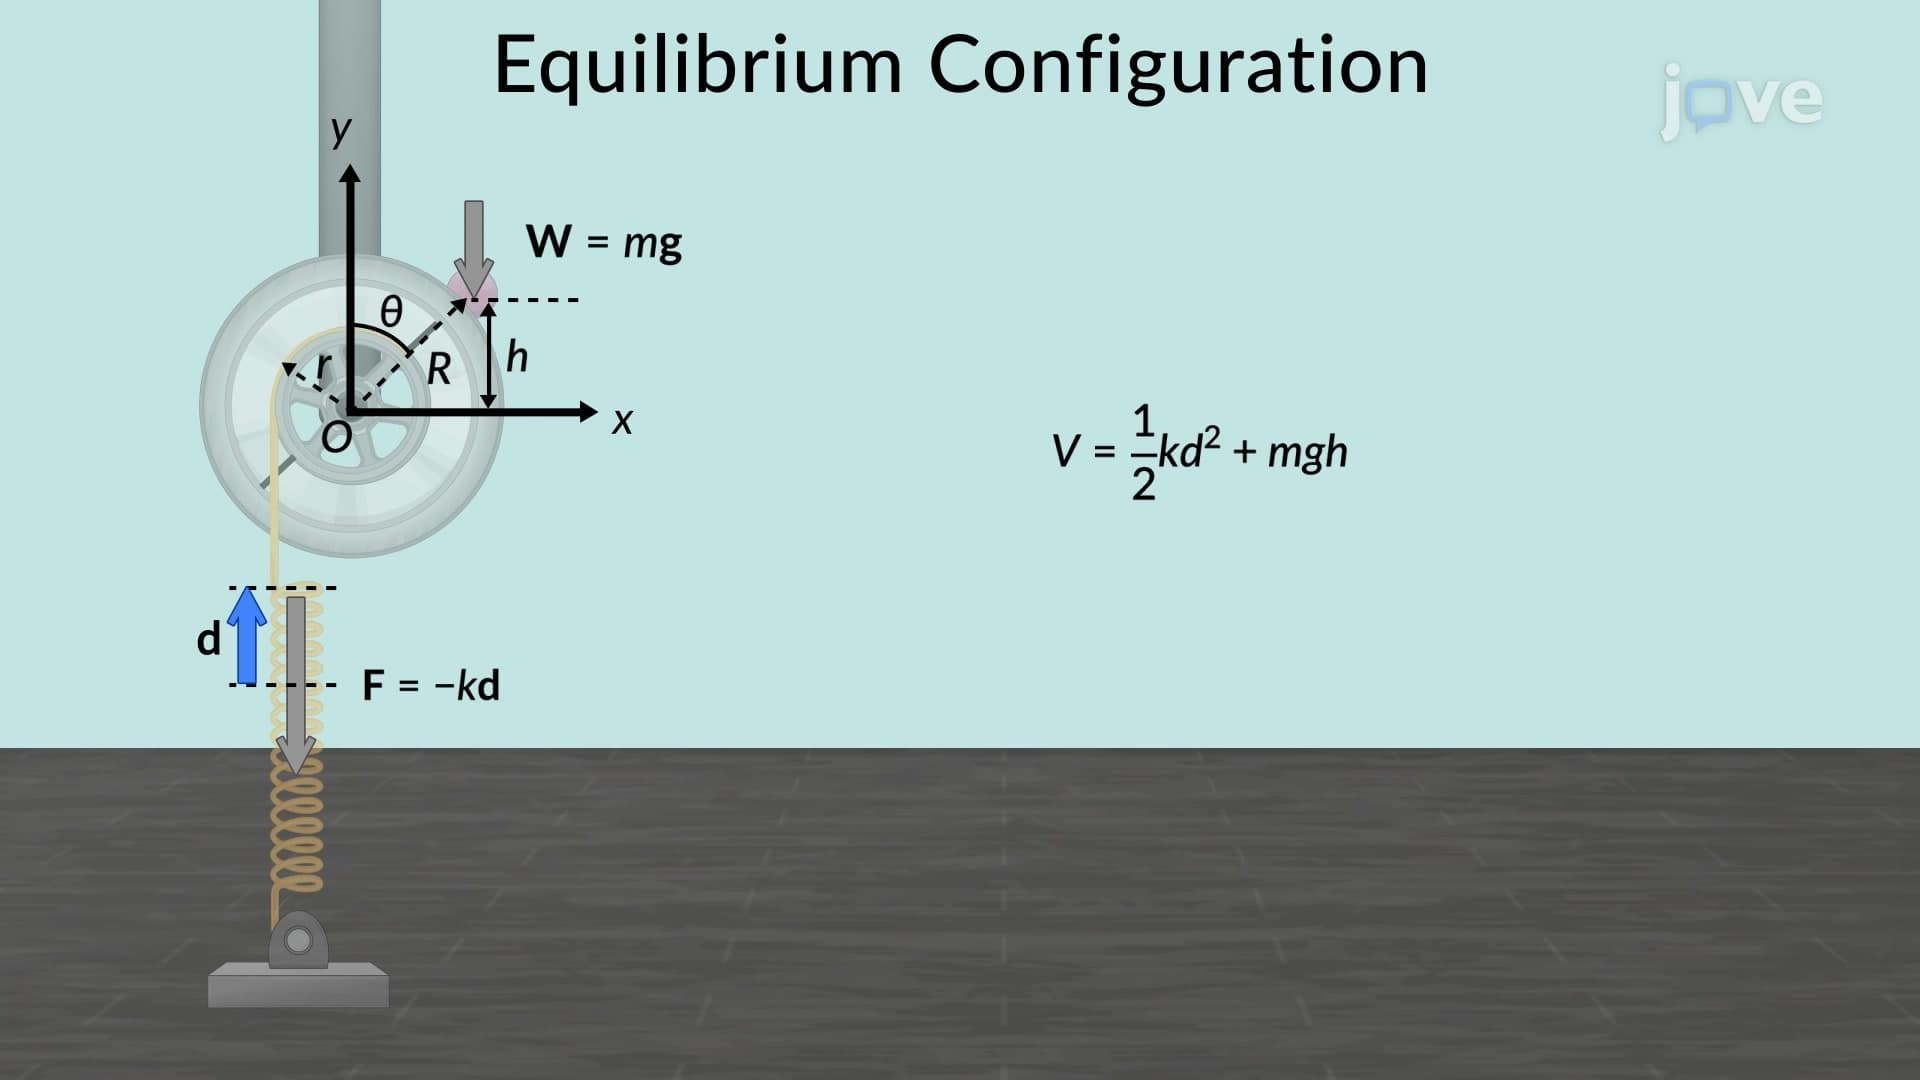
Stability of Equilibrium Configuration: Problem Solving
Problem-solving in the context of the stability of equilibrium configuration...