Related Experiment Video
Updated: Sep 23, 2026

Measuring Maxillary Posterior Tooth Movement: A Model Assessment using Palatal and Dental Superimposition
Published on: February 23, 2024
The value of the centre of rotation in initial and longitudinal tooth and bone displacement
Guy De Pauw1, Luc Dermaut, Hugo De Bruyn
1Department of Orthodontics, University of Ghent, Belgium.

Abstract:
Force application on teeth and bone structures results in orthodontic and orthopaedic movements. The effect of force application during different time intervals (initial and longitudinal displacements) can be evaluated by describing the displacement vectors or by constructing the centres of rotation of the displacements. The aim of this investigation was to review different experimental studies to compare the position of the centre of rotation (CR) with the displacement vectors of the object (tooth or bone) after force application. The results indicate that the measuring procedure and the use of the CR to describe the displacement are very sensitive: a large discrepancy in the position of the CR does not necessarily lead to a major change in the displacement vector of the object. Displacement vectors seem to be more appropriate in describing both initial and longitudinal tooth or bone displacements.
Related Concept Videos
 01:37
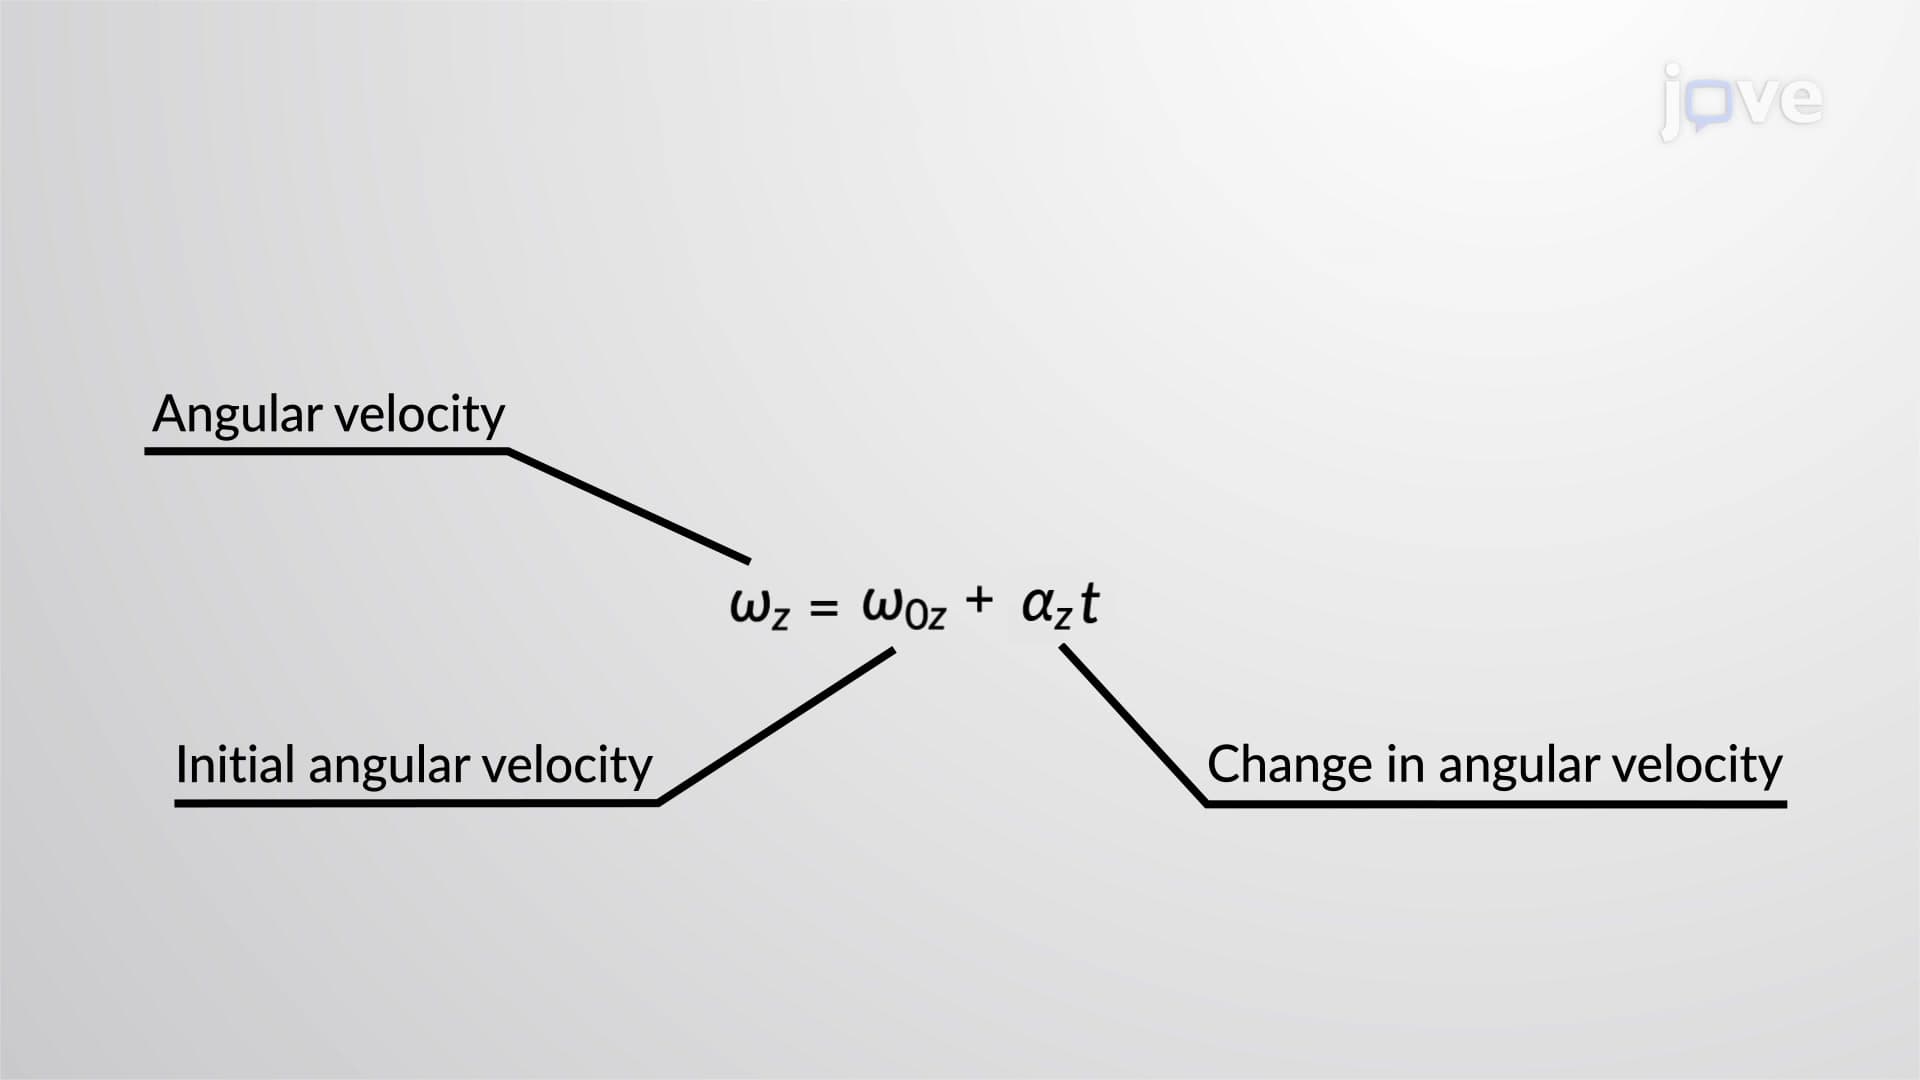
Rotation with Constant Angular Acceleration - I
Using our intuition, we can begin to see how rotational quantities such as angular displacement, angular velocity, angular acceleration, and time are related to one another. For example, if a flywheel...
 01:16
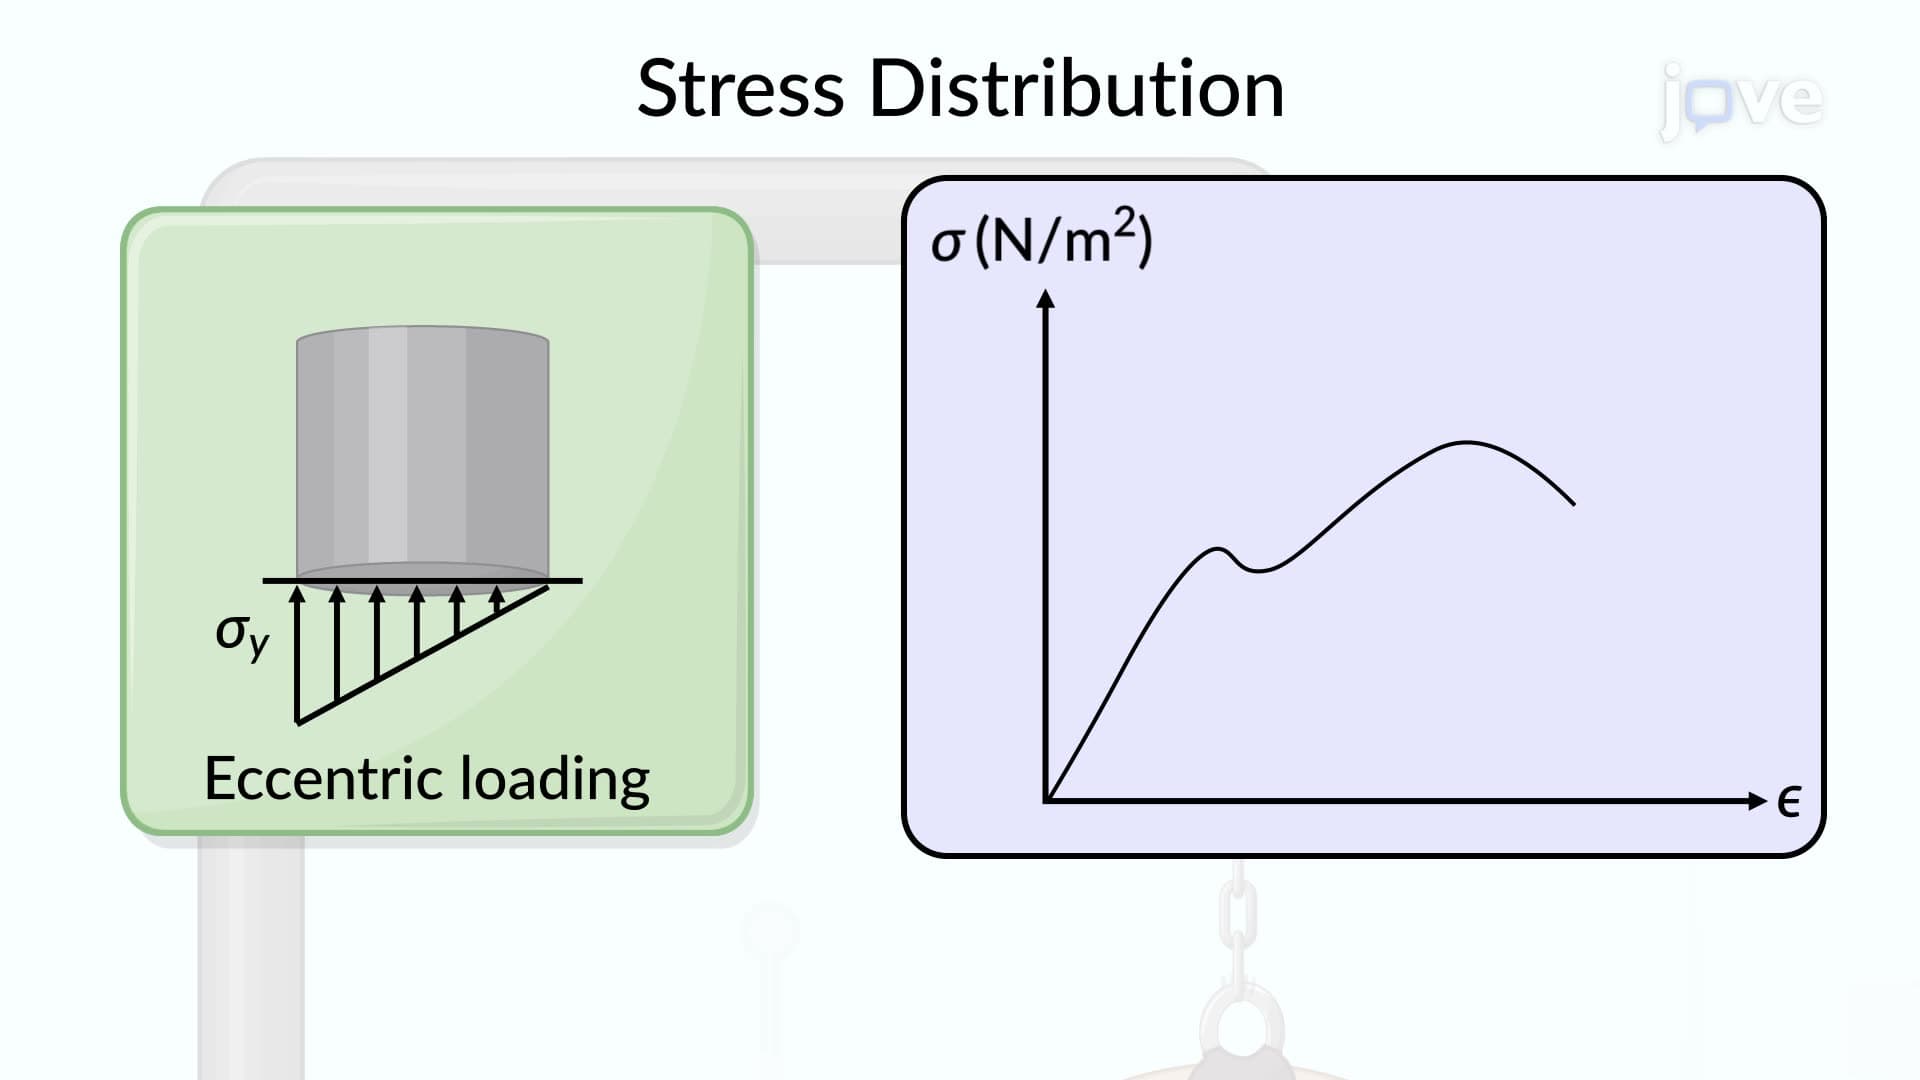
Eccentric Axial Loading in a Plane of Symmetry
 01:12
General Case of Eccentric Axial Loading
Consider a member subjected to equal and opposite forces that are applied along a line that does not coincide with the member's neutral axis. In unsymmetrical bending,...
 01:30
Applications of Integration to Find Centers of Mass
 01:30
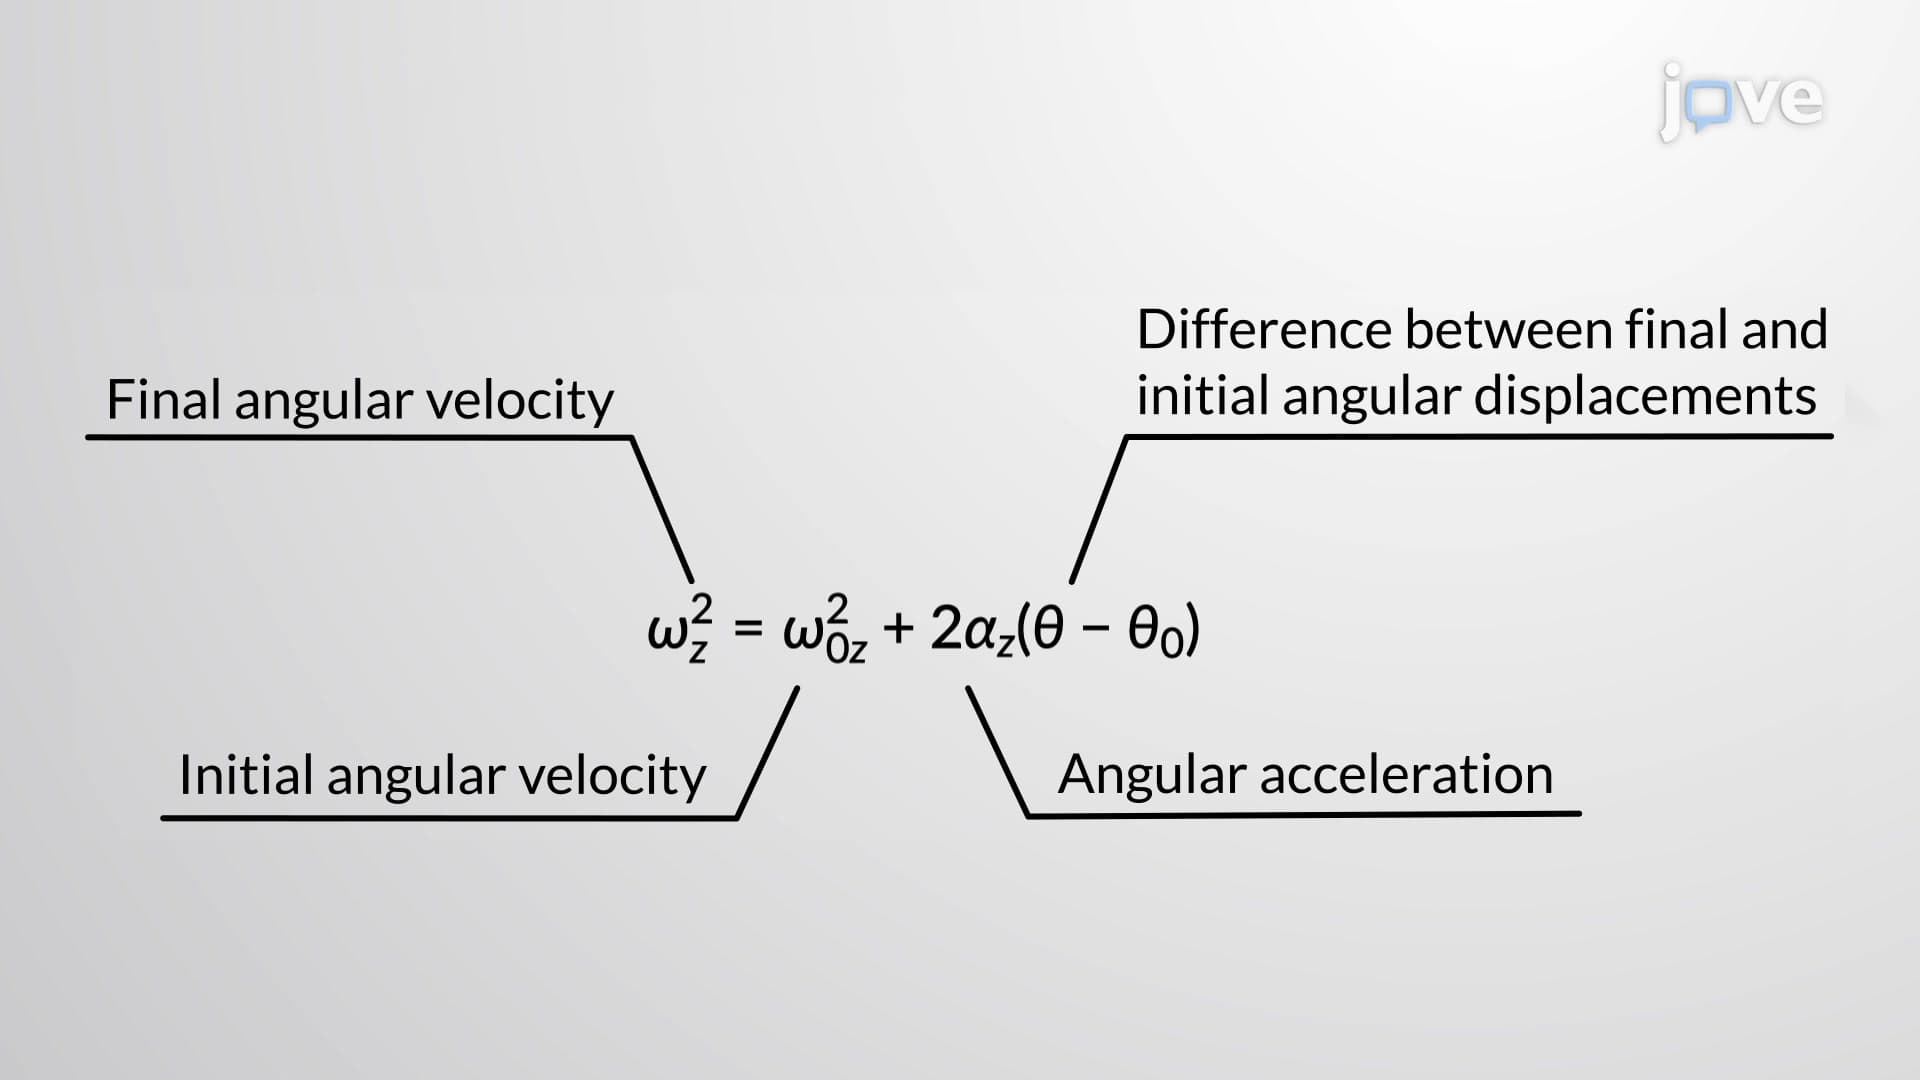
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
 01:16
Rotation with Constant Angular Acceleration - II
The first...