Sensorimotor adaptation to visual distortions with different kinematic coupling
Related Experiment Video
Updated: Jul 31, 2026

Visualizing Visual Adaptation
Published on: April 24, 2017
1Institute of Physiology, German Sport University, 50927, Köln, Germany. bock@dshs-koeln.de

Abstract:
We investigated the mechanisms of sensorimotor adaptation by sequentially exposing human subjects to different visual distortions. Subjects performed a manual tracking task, while the relationship between their actual finger movement and its visual feedback was manipulated either by a position-to-position (PP), or by a position-to-velocity (PV) transformation. The outcome confirmed previous findings, in that adaptation to PP facilitated the subsequent adaptation to a second, additional PP. More importantly, our present data documented that pre-exposure to PP interferes with the subsequent adaptation to PV, and vice versa. Thus, we observed anterograde interference between two transformations of common physical nature (i.e., visual), but different kinematic coupling. When previous work on sequential adaptation to visual and mechanical transformations is reconsidered in light of this finding, converging evidence is yielded in favor of a distributed adaptive mechanism, where the magnitude of interference between two successive adaptation sessions depends on the overlap of the involved neural structures.
More Related Videos
 07:12
A Gaze-Contingent Display Framework for Perceptual Learning Research with Simulated Central Vision Loss
Published on: April 11, 2025
 07:24
Using Eye-tracking to Assess the Relative Importance of Visual and Vestibular Input to Subcortical Motion Processing in the Roll Plane
Published on: August 22, 2025
Related Concept Videos
 01:17
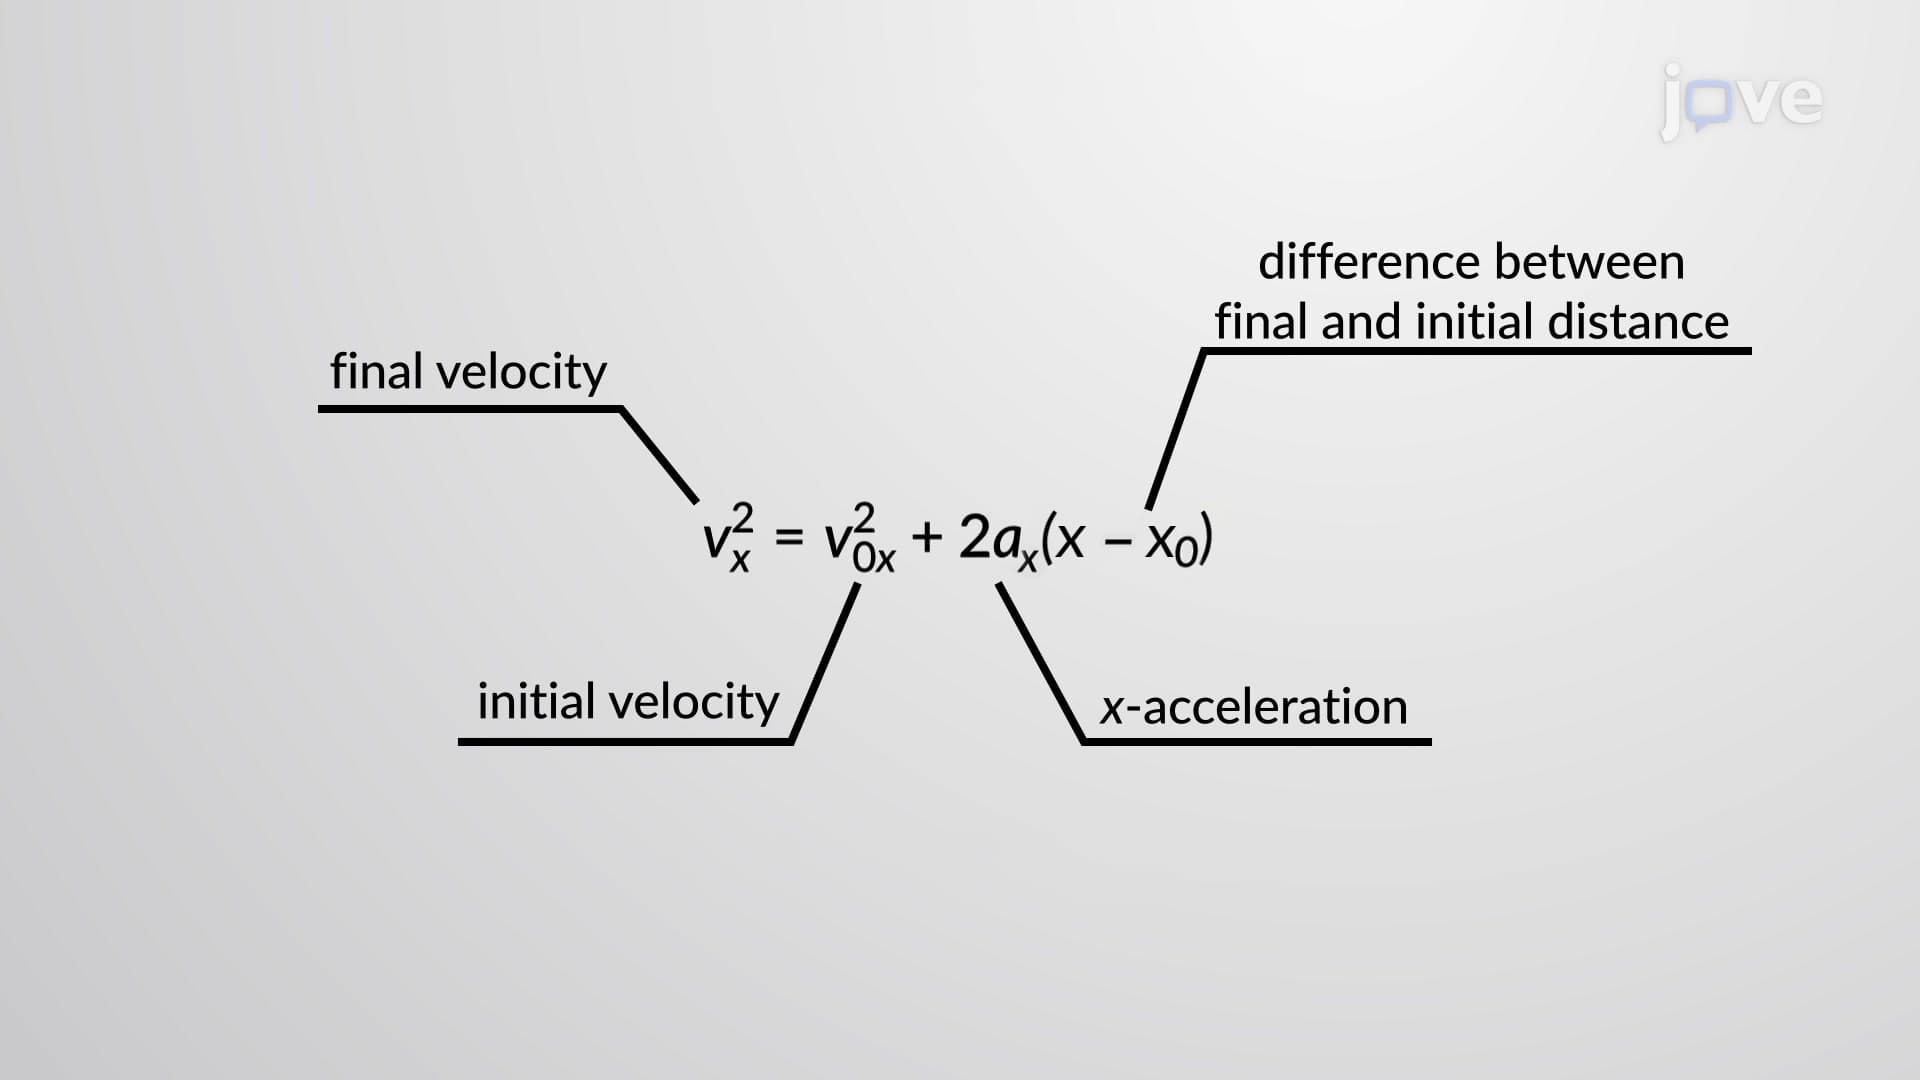
Kinematic Equations - II
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
 01:18
Kinematic Equations - III
Using the kinematic equations,...
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
 01:30
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
 01:22
Relative Motion Analysis using Rotating Axes - Acceleration
Time differentiation is...
 01:15
Depth Perception and Spatial Vision