Related Experiment Video
Updated: Aug 7, 2026
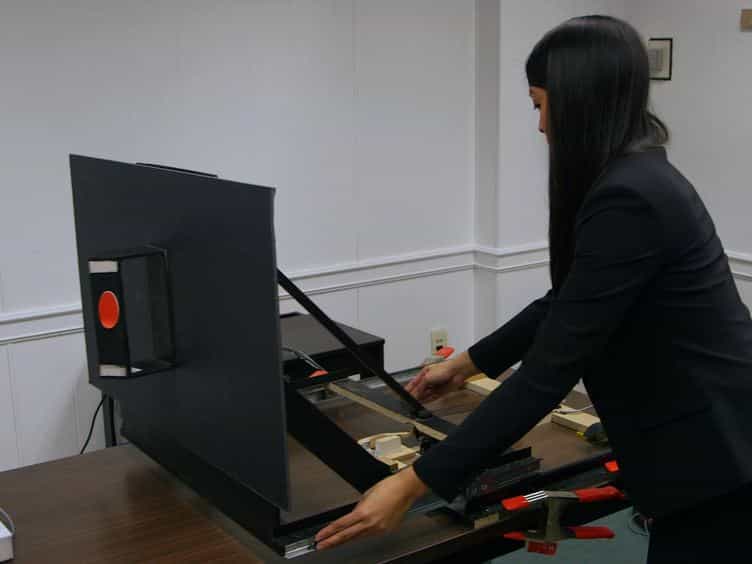

Methods to Explore the Influence of Top-down Visual Processes on Motor Behavior
Published on: April 16, 2014
Dynamic complexity of visuo-motor coordination: an extension of Bernstein's conception of the degrees-of-freedom
R E Ganz1, W H Ehrenstein, C R Cavonius
1Institut für Medizinische Psychologie, Universitätsklinikum Essen, Hufelandstrasse 55, D-45122 Essen, Germany.

Abstract:
Extending Bernstein's spatial conception of the degrees-of-freedom problem in the human motor system, we introduce a method developed from the theory of non-linear dynamics that allows one to quantify the spatio-temporal, i.e. dynamic, complexity of visuo-motor coordination. The correlation dimension D is used to measure the effective number of dynamic degrees of freedom in the coordination that a subject uses when performing a visuo-motor tracking task. The validity of the estimator employed is demonstrated. Visuo-motor coordination had a low-dimensional (mean D-SD=6.07 -0.82) dynamic structure, which was consistent with deterministic chaos rather than with pure stochastic noise. D correlated with tracking performance, P. Both D and P were closely related to the degree of visuo-motor compatibility that the task presented to the subject. However, for short periods of training P increased, but D did not. As these seemingly contradictory results suggest, our dynamic conception of the degrees-of-freedom problem may reveal far more intricate visuo-motor interactions than Bernstein could identify on the basis of his spatial analyses of bodily movement patterns and by the methods of evaluation that were available to him at the time.
Related Concept Videos
 01:15
Kinematic Equations: Problem Solving
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:18
Hierarchy of Motor Control
 01:30
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
 01:30
Vector Functions and Motion: Problem Solving