Related Experiment Video
Updated: Aug 30, 2026
Three-dimensional Super Resolution Microscopy of F-actin Filaments by Interferometric PhotoActivated Localization Microscopy (iPALM)
Published on: December 1, 2016
Scene-based nonuniformity correction for focal plane arrays by the method of the inverse covariance form
Sergio N Torres1, Jorge E Pezoa, Majeed M Hayat
1Department of Electrical Engineering, University of Concepción, Casilla 160-C, Concepción, Chile. storres@die.udec.cl

Abstract:
What is to our knowledge a new scene-based algorithm for nonuniformity correction in infrared focal-plane array sensors has been developed. The technique is based on the inverse covariance form of the Kalman filter (KF), which has been reported previously and used in estimating the gain and bias of each detector in the array from scene data. The gain and the bias of each detector in the focal-plane array are assumed constant within a given sequence of frames, corresponding to a certain time and operational conditions, but they are allowed to randomly drift from one sequence to another following a discrete-time Gauss-Markov process. The inverse covariance form filter estimates the gain and the bias of each detector in the focal-plane array and optimally updates them as they drift in time. The estimation is performed with considerably higher computational efficiency than the equivalent KF. The ability of the algorithm in compensating for fixed-pattern noise in infrared imagery and in reducing the computational complexity is demonstrated by use of both simulated and real data.
Related Concept Videos
 01:23
Curvilinear Motion: Rectangular Components
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the time...
 01:24
Area Computation by the Alternative Coordinate Method
 01:15
Distance Corrections
 01:20
Calibration Curves: Linear Least Squares
For data that follow a straight line, the standard method for fitting is the linear...
 01:27
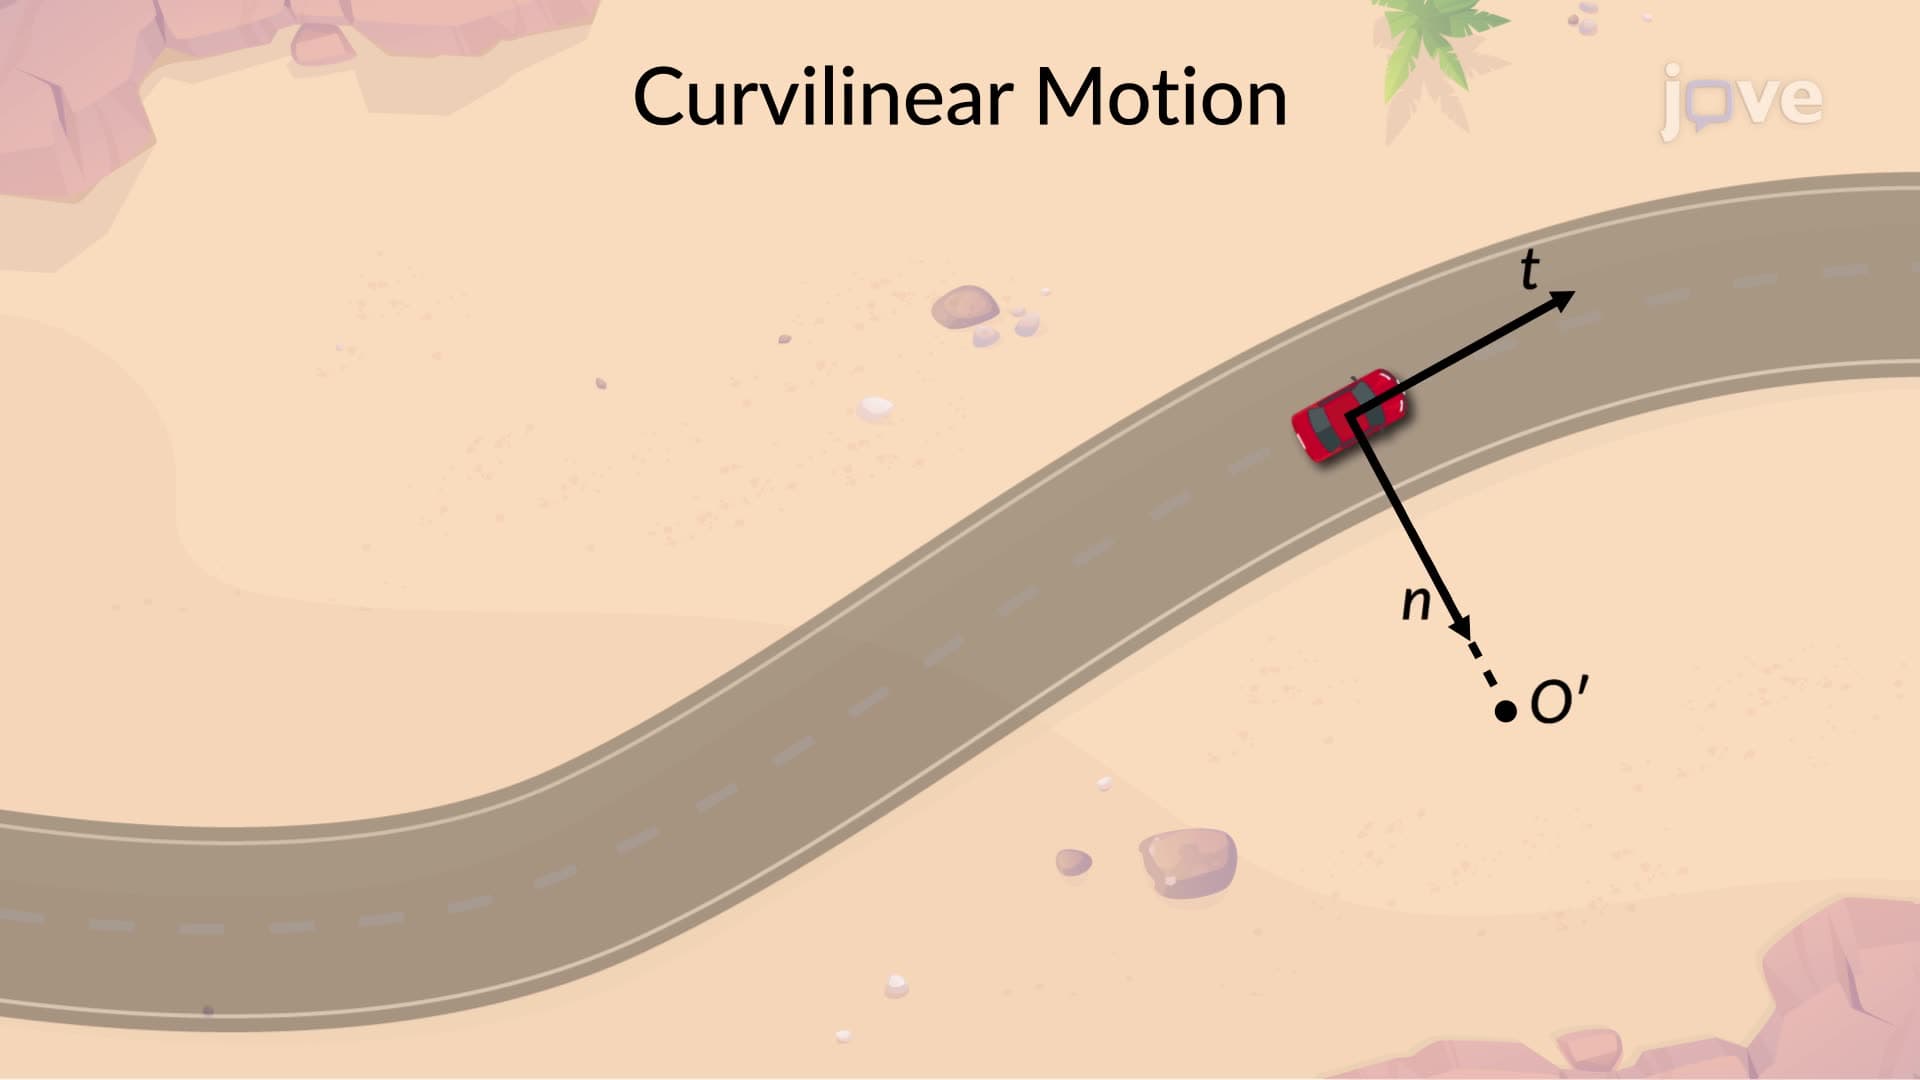
Curvilinear Motion: Normal and Tangential Components
The positive direction of the t-axis aligns with the increasing position of the car along the curved path, denoted by the unit vector ut. Simultaneously, the n-axis, perpendicular to the t-axis, dissects the curved path into differential arc segments, each forming the arc of a circle with a radius of...
 01:27
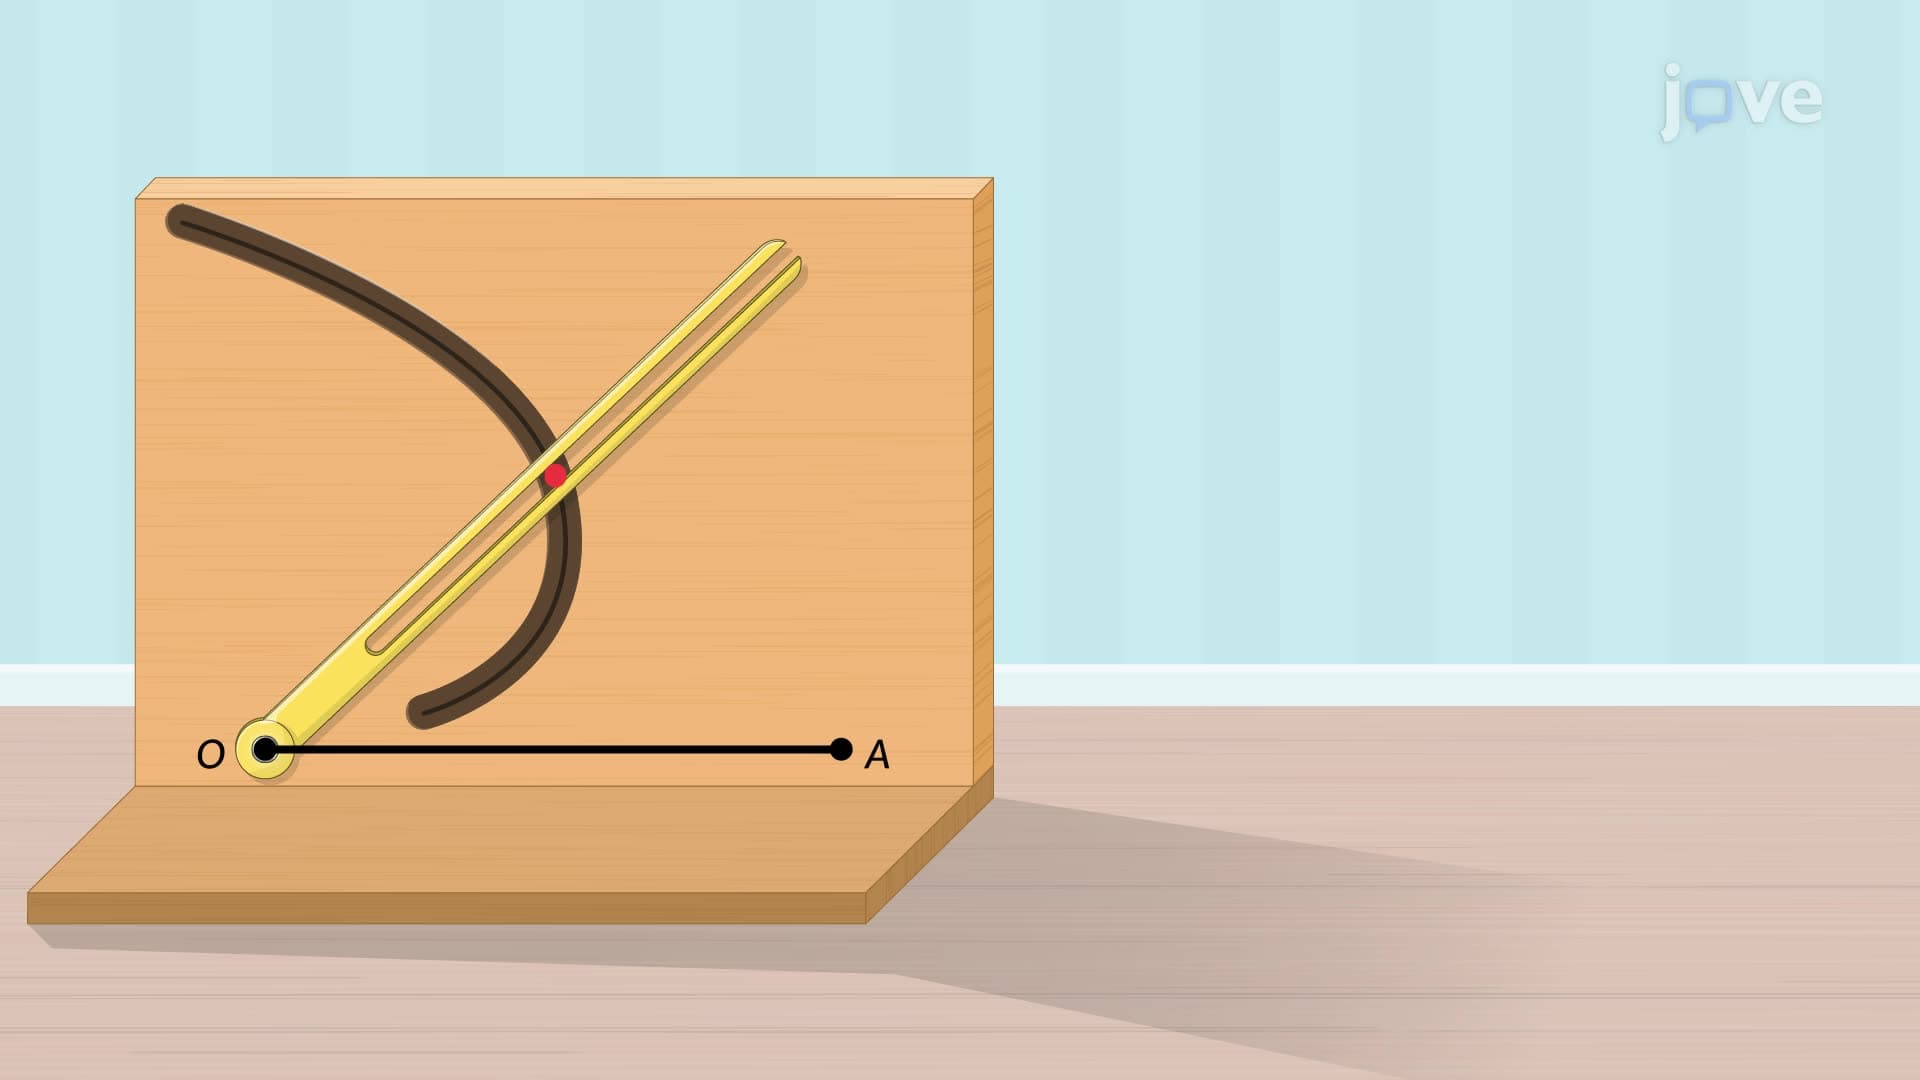
Curvilinear Motion: Polar Coordinates
The particle's location is described using a unit vector along the radial direction. Deriving the particle's position with respect to time...