A universal model for spike-frequency adaptation
Related Experiment Video
Updated: Aug 1, 2026

An Experimental Platform to Study the Closed-loop Performance of Brain-machine Interfaces
Published on: March 10, 2011
1Department of Physics, University of Ottawa, Ottawa, Ontario, K1N 6N5, Canada. j.benda@biologie.hu-berlin.de

Abstract:
Spike-frequency adaptation is a prominent feature of neural dynamics. Among other mechanisms, various ionic currents modulating spike generation cause this type of neural adaptation. Prominent examples are voltage-gated potassium currents (M-type currents), the interplay of calcium currents and intracellular calcium dynamics with calcium-gated potassium channels (AHP-type currents), and the slow recovery from inactivation of the fast sodium current. While recent modeling studies have focused on the effects of specific adaptation currents, we derive a universal model for the firing-frequency dynamics of an adapting neuron that is independent of the specific adaptation process and spike generator. The model is completely defined by the neuron's onset f-I curve, the steady-state f-I curve, and the time constant of adaptation. For a specific neuron, these parameters can be easily determined from electrophysiological measurements without any pharmacological manipulations. At the same time, the simplicity of the model allows one to analyze mathematically how adaptation influences signal processing on the single-neuron level. In particular, we elucidate the specific nature of high-pass filter properties caused by spike-frequency adaptation. The model is limited to firing frequencies higher than the reciprocal adaptation time constant and to moderate fluctuations of the adaptation and the input current. As an extension of the model, we introduce a framework for combining an arbitrary spike generator with a generalized adaptation current.
Related Concept Videos
 01:08
Determination of Expected Frequency
 01:22
Muscle Stimulation Frequency
Wave summation
At low firing rates, motor neurons induce individual twitch contractions in muscle fibers. These twitches...
 01:26
Scaling
 01:16
Basic Discrete Time Signals
The unit impulse or sample sequence is mathematically expressed as zero for all n values except at n=0, where it is one. The unit impulse sequence, denoted by δ(n), is the first difference of the unit step sequence, while the unit step sequence u(n) is the...
 01:26
Linear Approximation in Frequency Domain
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear.
 01:30
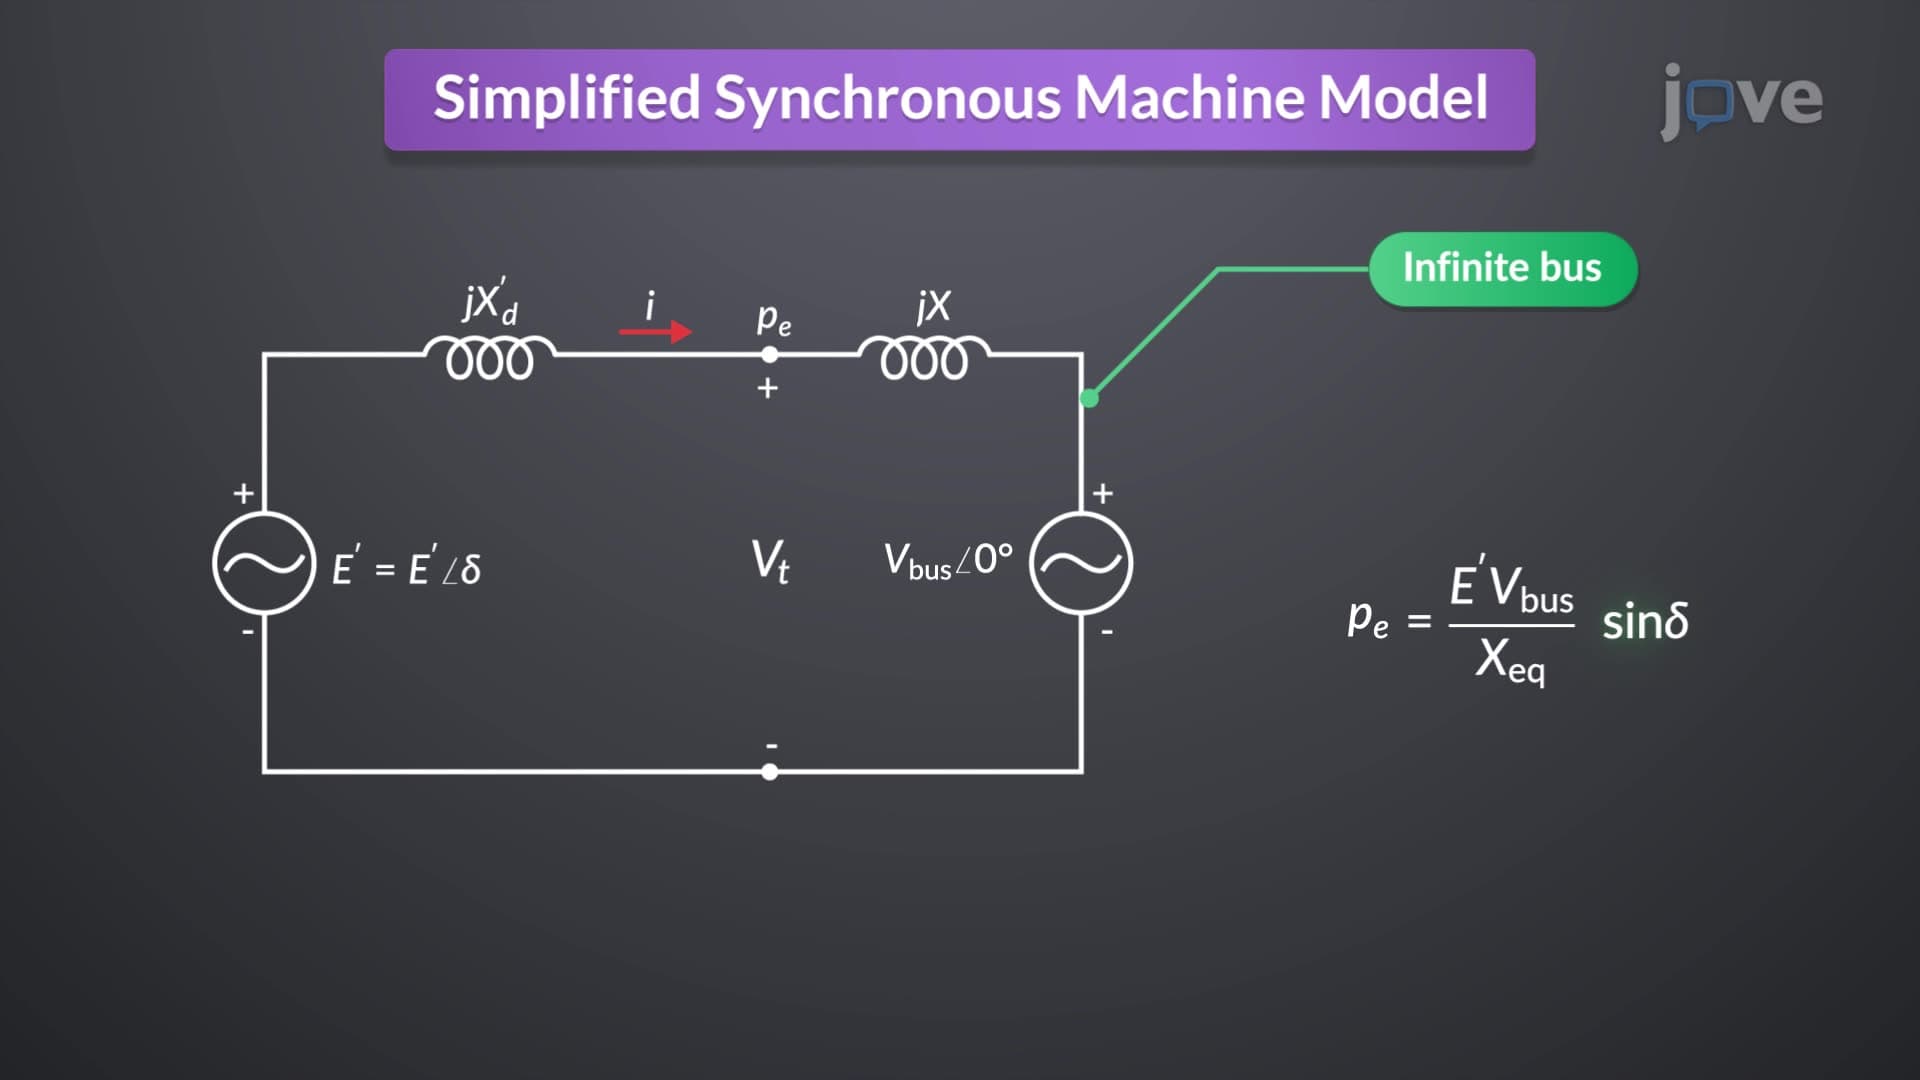
Simplified Synchronous Machine Model
In this model, each generator is connected to a...