Related Experiment Video
Updated: Aug 30, 2026

Real-Time DC-dynamic Biasing Method for Switching Time Improvement in Severely Underdamped Fringing-field Electrostatic MEMS Actuators
Published on: August 15, 2014
Hysteresis in response of nonlinear bistable interface to continuously varying acoustic loading
V Gusev1, B Castagnède, A Moussatov
1Université du Maine, Avenue O Messiaen, 72085 Cedex 9, Le Mans, France. vitali.goussev@univ-lemans.fr

Abstract:
In many experimental situations it is an equation of the forced relaxator and not of the forced oscillator that describes a variation in the acoustic field of the interface width (i.e. of a characteristic distance between the surfaces composing the interface). The developed theory predicts that some types of the nonlinear relaxators (depending on the structure of the nonlinear interaction force between the surfaces) exhibit hysteresis in their response to continuous acoustic loading of first increasing and then decreasing amplitude. Nonlinear (unharmonic) variation of the interface width starts at threshold amplitude of the incident sinusoidal acoustic wave, which is higher than threshold amplitude for returning to sinusoidal motion. This dynamic hysteresis (and accompanying it bistability) are possible, in particular, if the dependence of the effective interaction force on the interface width admits two quasi-equilibrium positions of the interface (bistable interface) or if the force itself is hysteretic (hysteretic interface). These theoretical predictions are relevant to some recent experimental observations on the interaction of powerful ultrasonic fields with cracks.
Related Concept Videos
 01:18
Second Order systems II
If ζ...
 01:26
Linear Approximation in Frequency Domain
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear.
 00:53
Sound Waves: Interference
 01:20
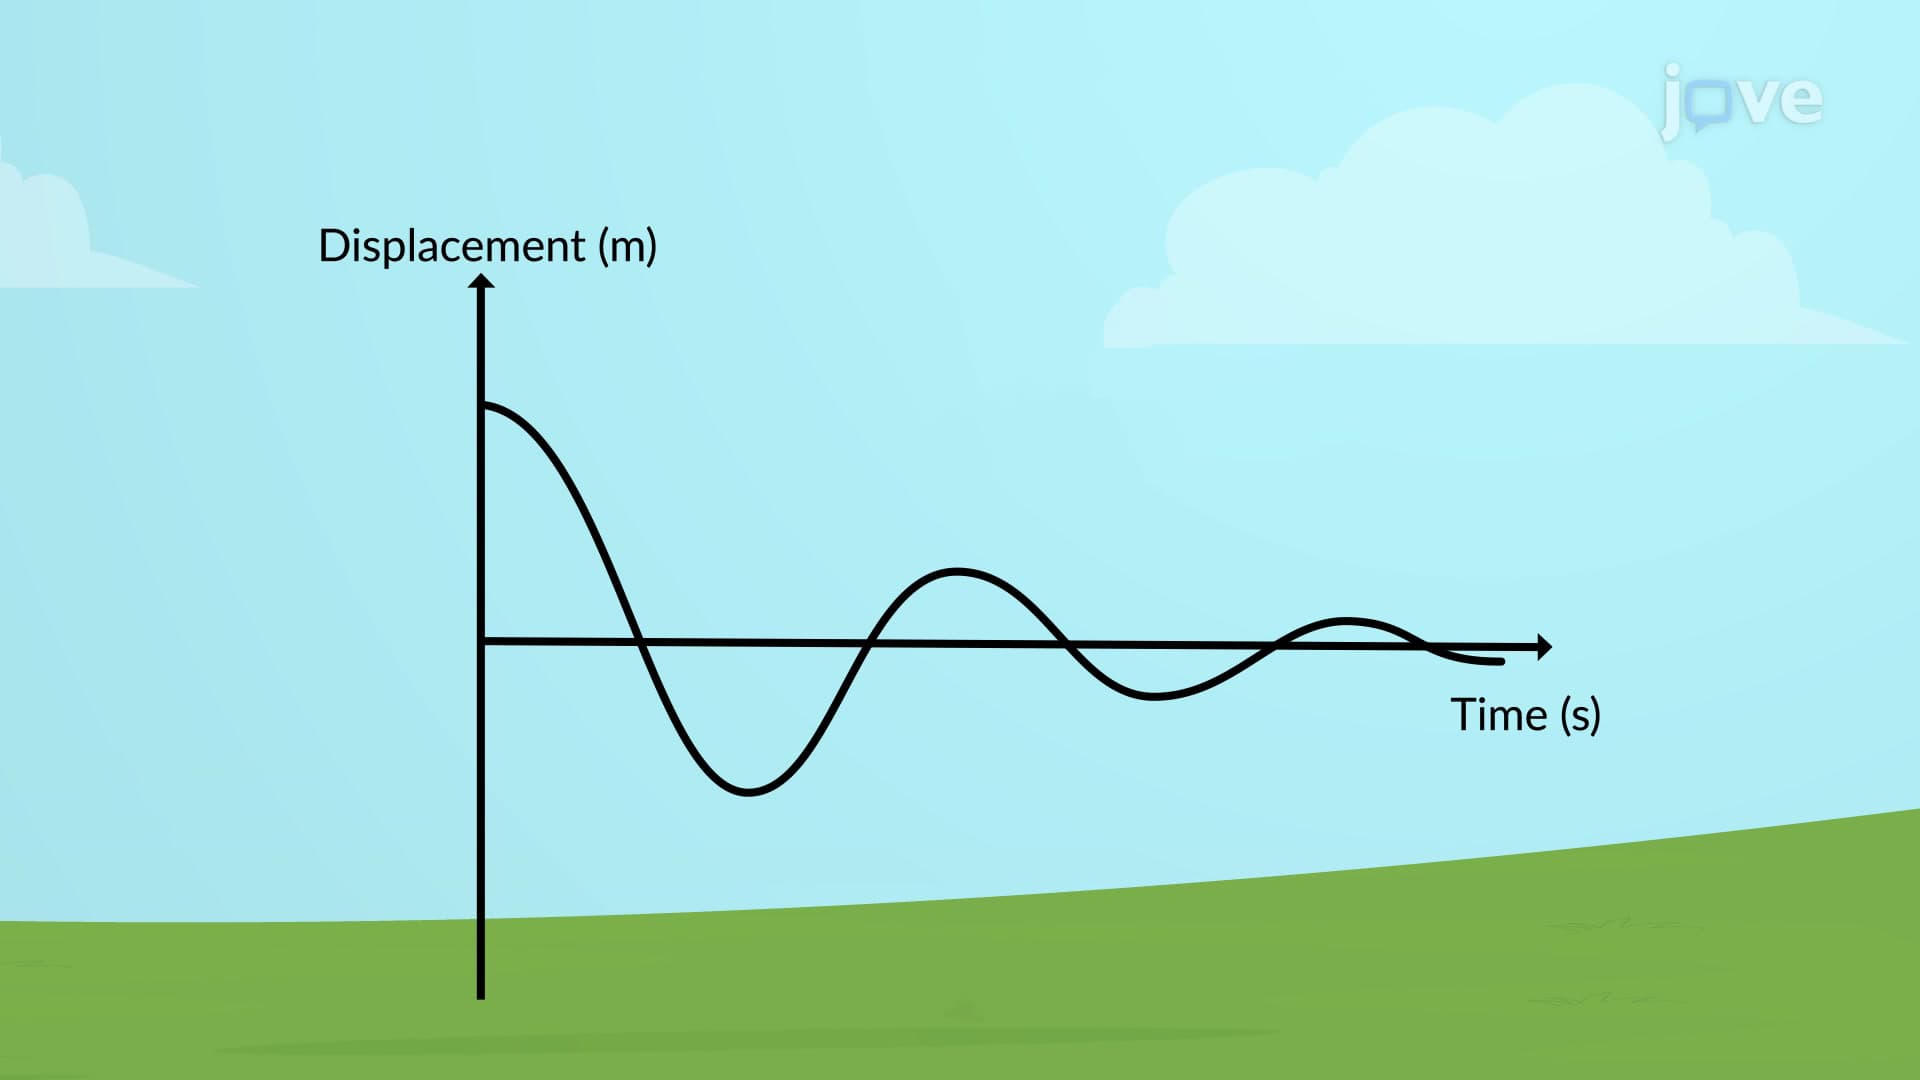
Types of Damping
 01:19
Second-order Op Amp Circuits
The analysis of such circuits follows a systematic approach, similar to the second-order RLC circuits. In practical scenarios, bulky inductors are rarely employed due to their size and weight. This means...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...