Related Experiment Video
Updated: Aug 30, 2026
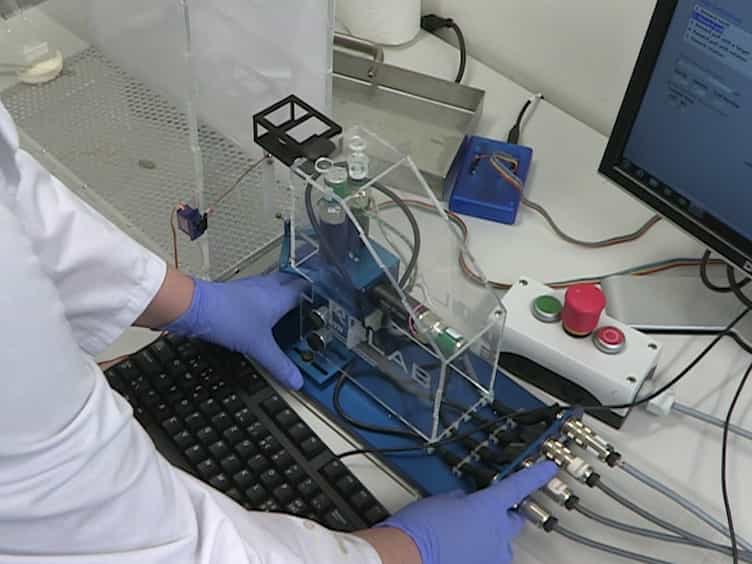

Investigating Motor Skill Learning Processes with a Robotic Manipulandum
Published on: February 12, 2017
A human motor control perspective to multiple manipulator modelling
C Kambhampati1, S Rajasekharan
1Neural, Emergent and Agent Technologies, Department of Computer Science, University of Hull, UK. c.kambhampati@dcs.hull.ac.uk

Abstract:
This paper describes the aspects involved in modelling a multi-robot system from a human motor control perspective. The human motor control system has a hierarchical and decentralised structure, and building a control system for a multi-robot system that attains human features would require a decomposable model. Decomposition of a complex robotic system is difficult due to the interactions between the subsystems, so these have to be first separated before the system is modelled. The proposed method of separating the interconnections is applied with the aid of fuzzy modelling to derive a fully decomposable model of two manipulator robots handling a common object.
Related Concept Videos
 01:13
Motor Units
Motor units come in different sizes, with smaller units...
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller aligns...
 01:24
Muscle Coordination and Action
Agonists
Agonist muscles, often called prime movers, are the primary muscles responsible for producing a specific movement.