Stiefel-manifold learning by improved rigid-body theory applied to ICA
Related Experiment Video
Updated: Aug 29, 2026

Deep-Learning Based Multi-Joint Synchronous Tracking for Objective Quantification of Hindlimb Locomotor Kinematics in Rats
Published on: April 3, 2026
1Faculty of Engineering, University of Perugia, Polo Didattico e Scientifico del Ternano, Loc. Pentima bassa, 21, I-05100 Terni, Italy. fiori@unipg.it

Abstract:
In previous contributions we presented a new class of algorithms for orthonormal learning of a linear neural network with p inputs and m outputs, based on the equations describing the dynamics of a massive rigid frame in a submanifold of R(p). While exhibiting interesting features, such as intrinsic numerical stability, strongly binding to the orthonormal submanifolds, and good controllability of the learning dynamics, tested on principal/independent component analysis, the proposed algorithms were not completely satisfactory from a computational-complexity point of view. The main drawback was the need to repeatedly evaluate a matrix exponential map. With the aim to lessen the computational efforts pertaining to these algorithms, we propose here an improvement based on the closed-form Rodriguez formula for the exponential map. Such formula is available in the p = 3 and m = 3 case, which is discussed with details here. In particular, experimental results on independent component analysis (ICA), carried out with both synthetic and real-world data, help confirming the computational gain due to the proposed improvement.
Related Concept Videos
 01:21
Rigid Body Equilibrium Problems - II
Consider two children sitting on a seesaw, which has negligible mass. The first child has a mass (m1) of 26 kg and sits at point A, which is 1.6 meters (r1) from the pivot point B; the second child has a mass (m2) of 32 kg and sits at point C. How far from the pivot point B should the second child sit (r2) to balance the seesaw?
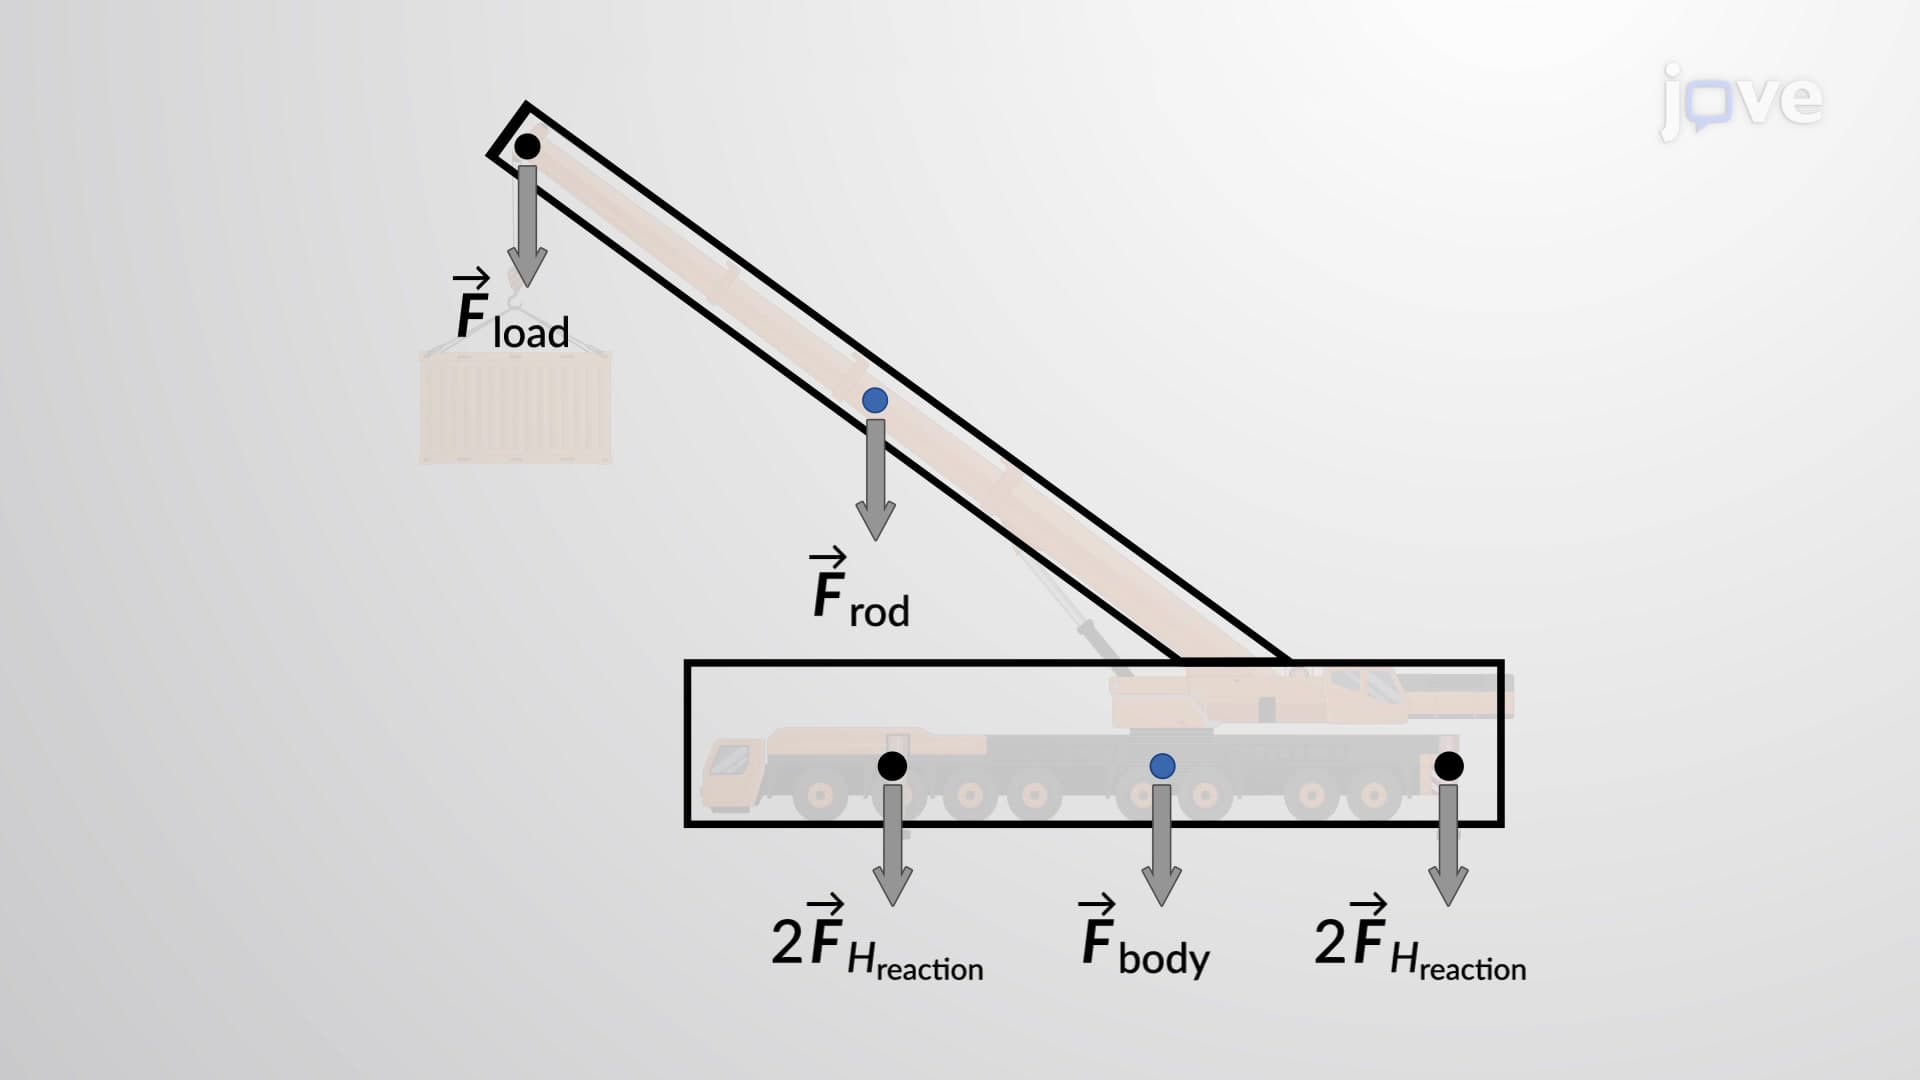 00:49
Rigid Body Equilibrium Problems - I
 01:06
Virtual Work for a System of Connected Rigid Bodies
Next,...
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:22
Planar Rigid-Body Motion
Planar motion is typically divided into three distinct categories. The first is rectilinear translation, demonstrated by a subway train that moves along...
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...