Related Experiment Videos
Nonlinear stochastic equations with calculable steady states
Rava A da Silveira1, Mehran Kardar
1Lyman Laboratory of Physics, Harvard University, Cambridge, Massachusetts 02138, USA.

Abstract:
We consider generalizations of the Kardar-Parisi-Zhang equation that accommodate spatial anisotropies and the coupled evolution of several fields, and focus on their symmetries and nonperturbative properties. In particular, we derive generalized fluctuation-dissipation conditions on the form of the (nonlinear) equations for the realization of a Gaussian probability density of the fields in the steady state. For the amorphous growth of a single height field in one dimension we give a general class of equations with exactly calculable (Gaussian and more complicated) steady states. In two dimensions, we show that any anisotropic system evolves in long time and length scales either to the usual isotropic strong coupling regime or to a linearlike fixed point associated with a hidden symmetry. Similar results are derived for textural growth equations that couple the height field with additional order parameters which fluctuate on the growing surface. In this context, we propose phenomenological equations for the growth of a crystalline material, where the height field interacts with lattice distortions, and identify two special cases that obtain Gaussian steady states. In the first case compression modes influence growth and are advected by height fluctuations, while in the second case it is the density of dislocations that couples with the height.
Related Concept Videos
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length, the...
 01:26
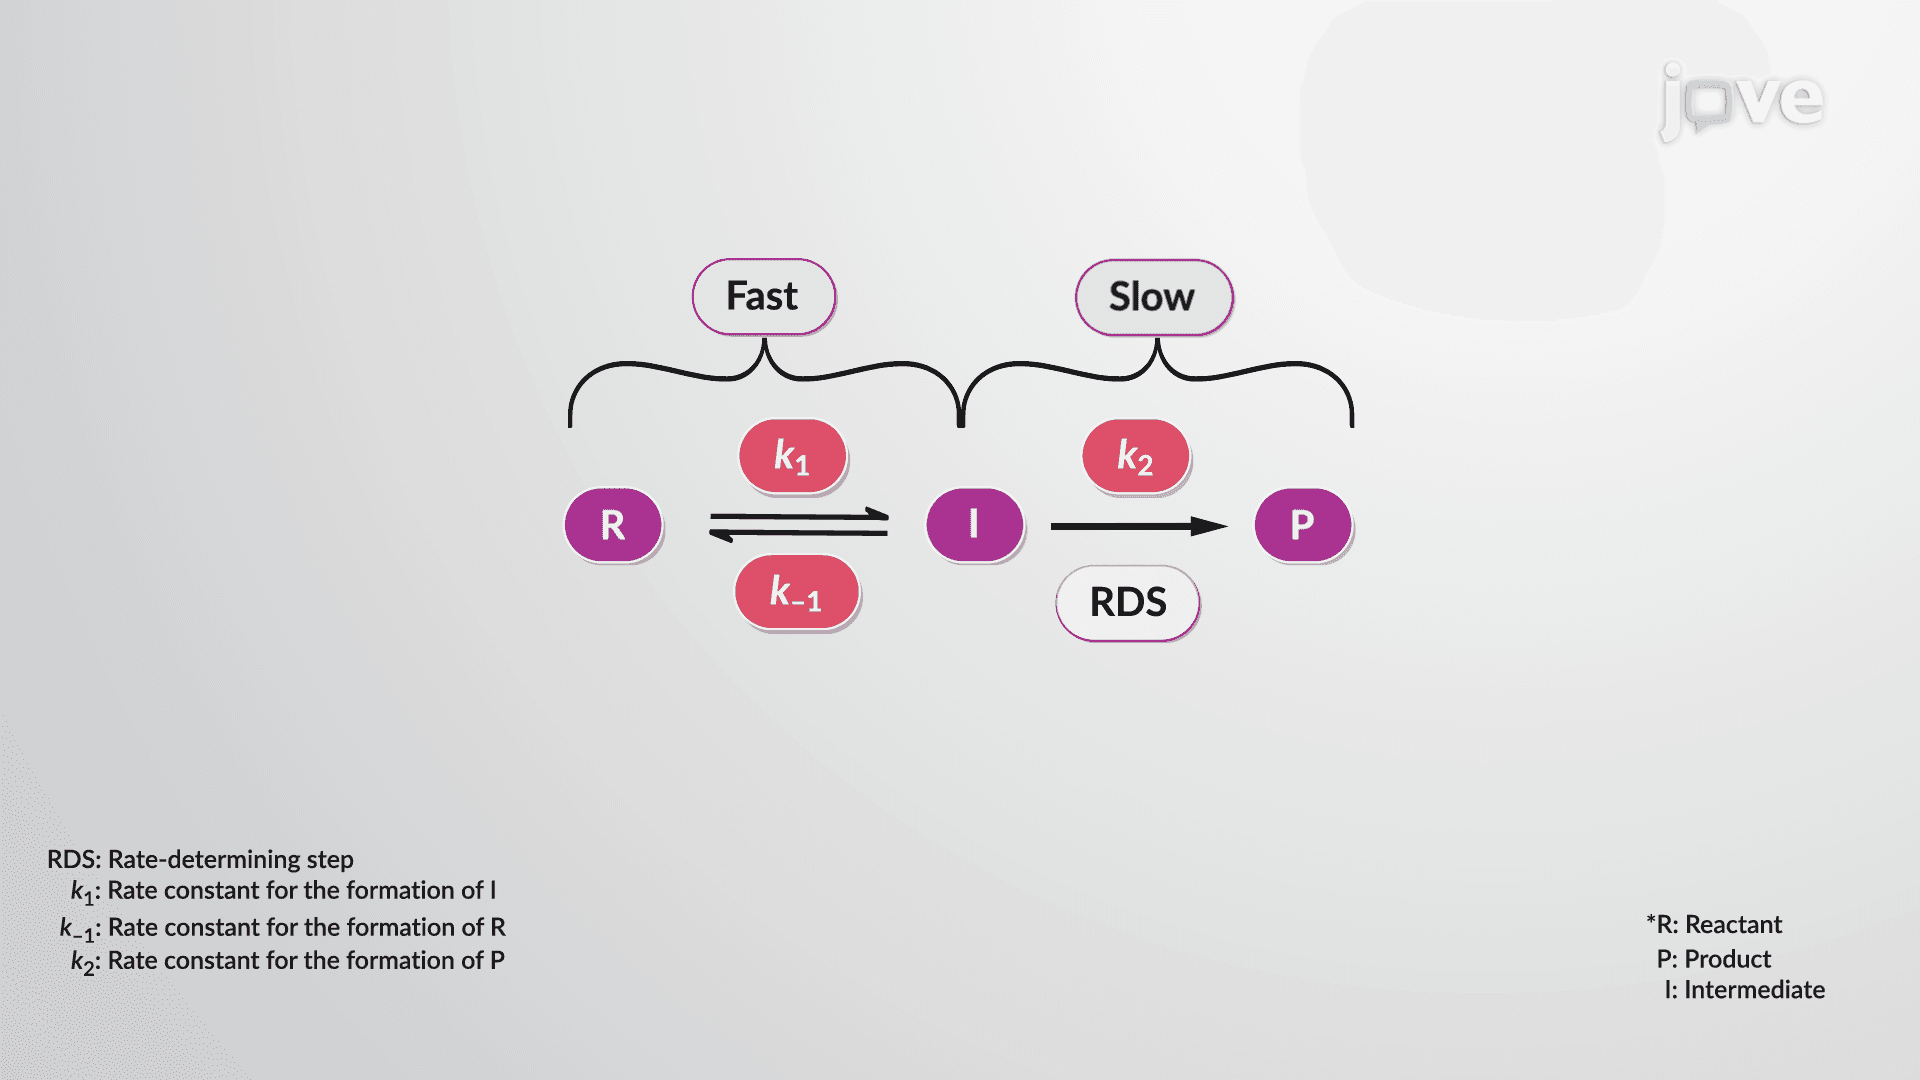
Reaction Mechanisms: The Steady-State Approximation
 01:26
Linear Approximation in Frequency Domain
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear.
 01:27
Linear Differential Equations
 01:27
State Space Representation
Consider an RLC circuit, a...
 01:25
Modeling with Differential Equations