Related Experiment Video
Updated: Aug 2, 2026

Reduced-gravity Environment Hardware Demonstrations of a Prototype Miniaturized Flow Cytometer and Companion Microfluidic Mixing Technology
Published on: November 13, 2014
Detection of rotating gravity signals
1Department of Neurology, University of Zürich, Switzerland.

Abstract:
It is shown in the preceding paper that neurons with two-dimensional spatio-temporal properties to linear acceleration behave like one-dimensional rate sensors: they encode the component of angular velocity (associated with a rotating linear acceleration vector) that is normal to their response plane. During off-vertical axis rotation (OVAR) otolith-sensitive neurons are activated by the gravity vector as it rotates relative to the head. Unlike "one-dimensional" linear accelerometer neurons which exhibit equal response magnitudes for both directions of rotation, "two-dimensional" neurons can be shown to respond with unequal magnitudes to clockwise and counterclockwise off-vertical axis rotations. The magnitudes of the sinusoidal responses of these neurons is not only directionally selective but also proportional to rotational velocity. Thus, responses from such "two-dimensional" neurons may represent the first step in the computations necessary to generate the steady-state eye velocity during OVAR. An additional step involving a nonlinear operation is necessary to transform the sinusoidally modulated output of these neurons into a signal proportional to sustained eye velocity. Similarly to models of motion detection in the visual system, this transformation is proposed to be achieved through neuronal operations involving mathematical multiplication followed by a leaky integration by the velocity storage mechanism. The proposed model for the generation of maintained eye velocity during OVAR is based on anatomical and physiological properties of vestibular nuclei neurons and capable of predicting the experimentally observed steady-state characteristics of the eye velocity.
Related Concept Videos
 01:24
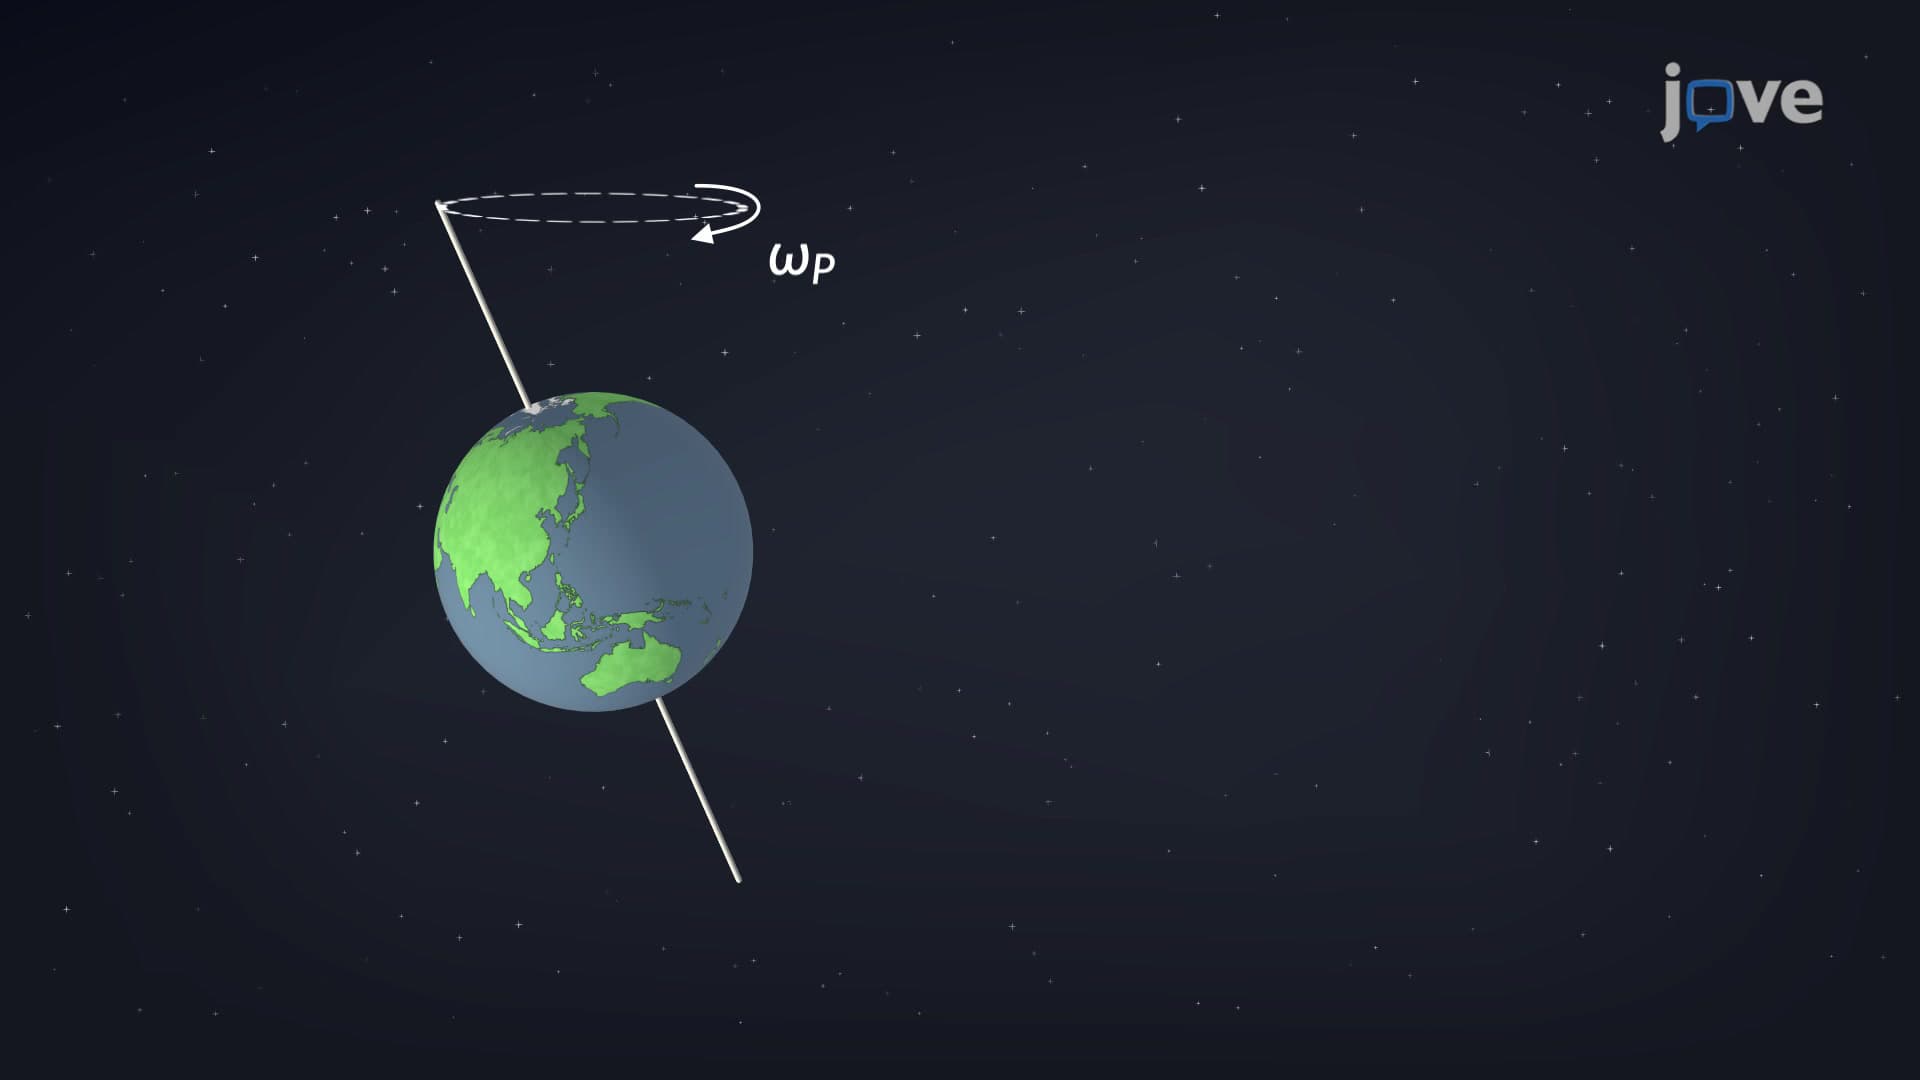
Gyroscope: Precession
 01:27
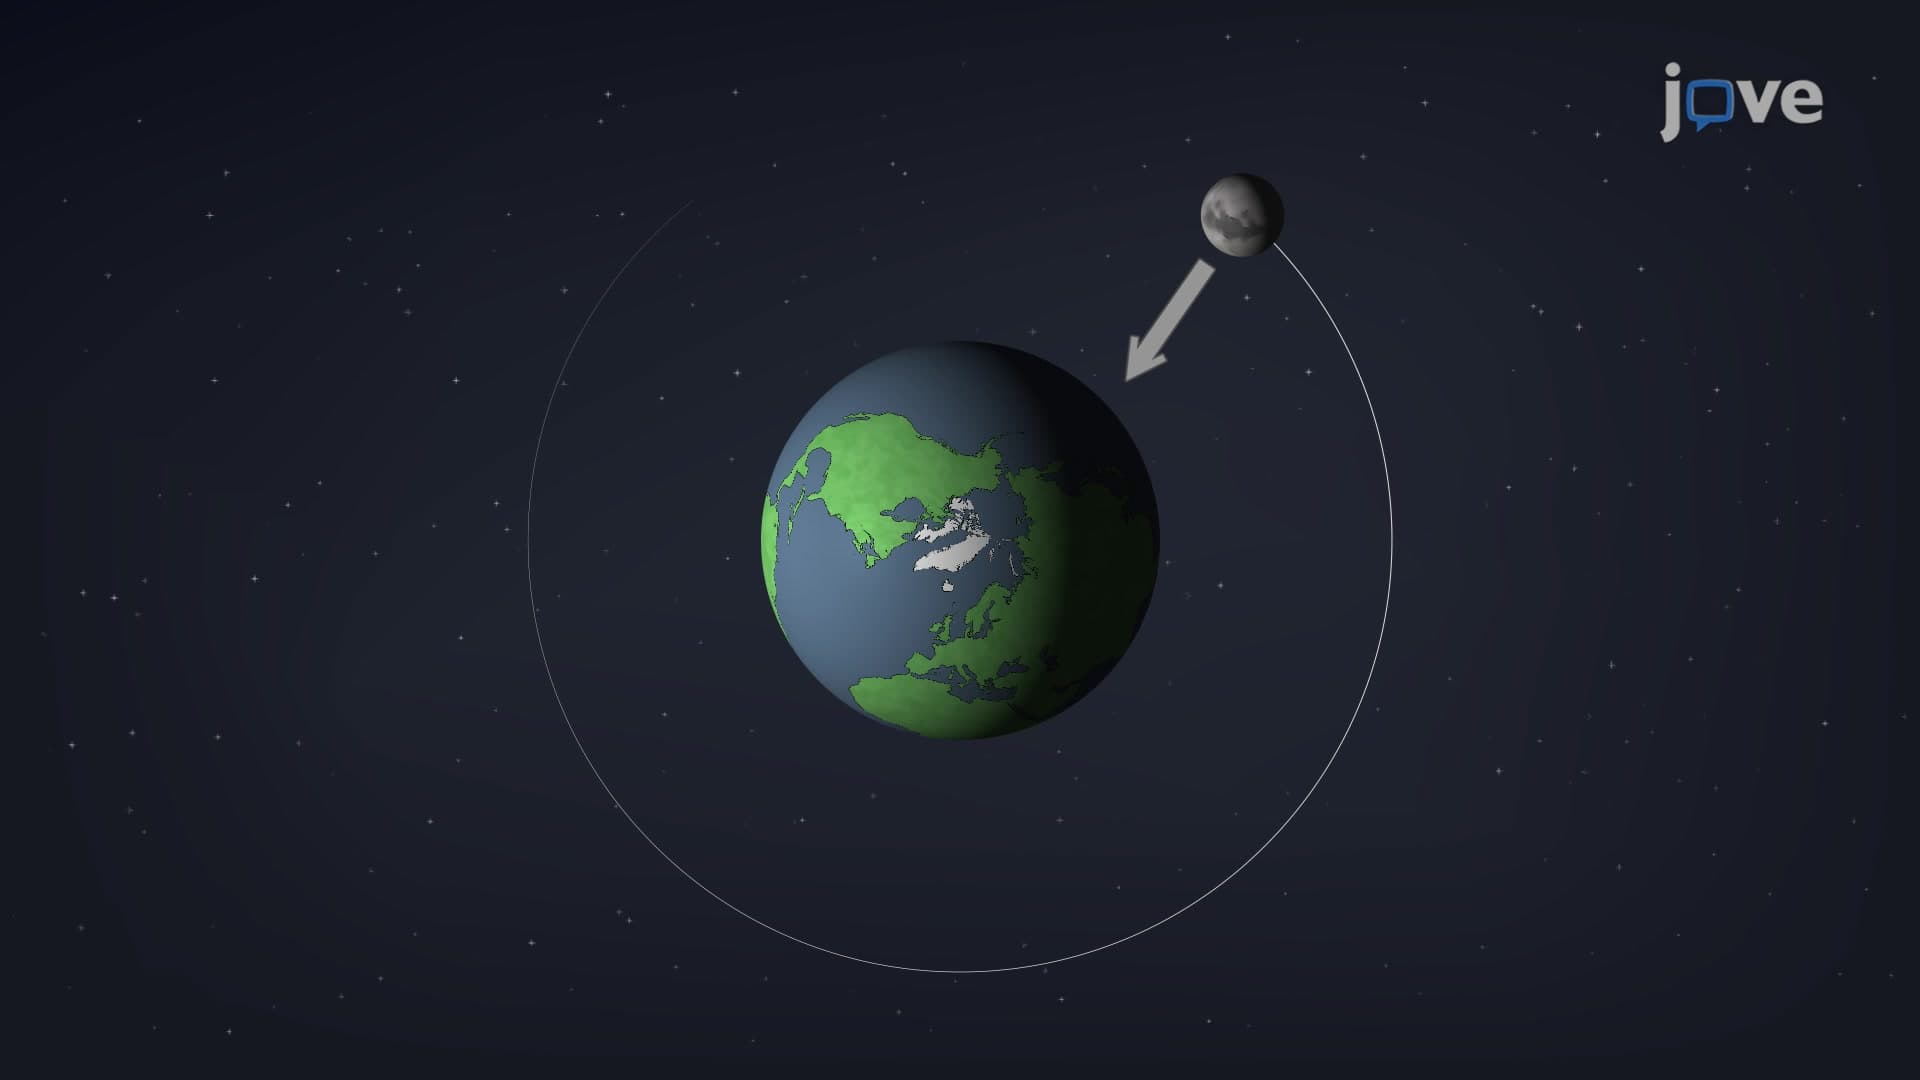
Gravity between Spherical Bodies
This assumption can be proved easily by showing that the expression for gravitational potential energy between a hollow sphere of mass (M) and a point mass (m) is the same as it would be for a pair of extended...
 01:20
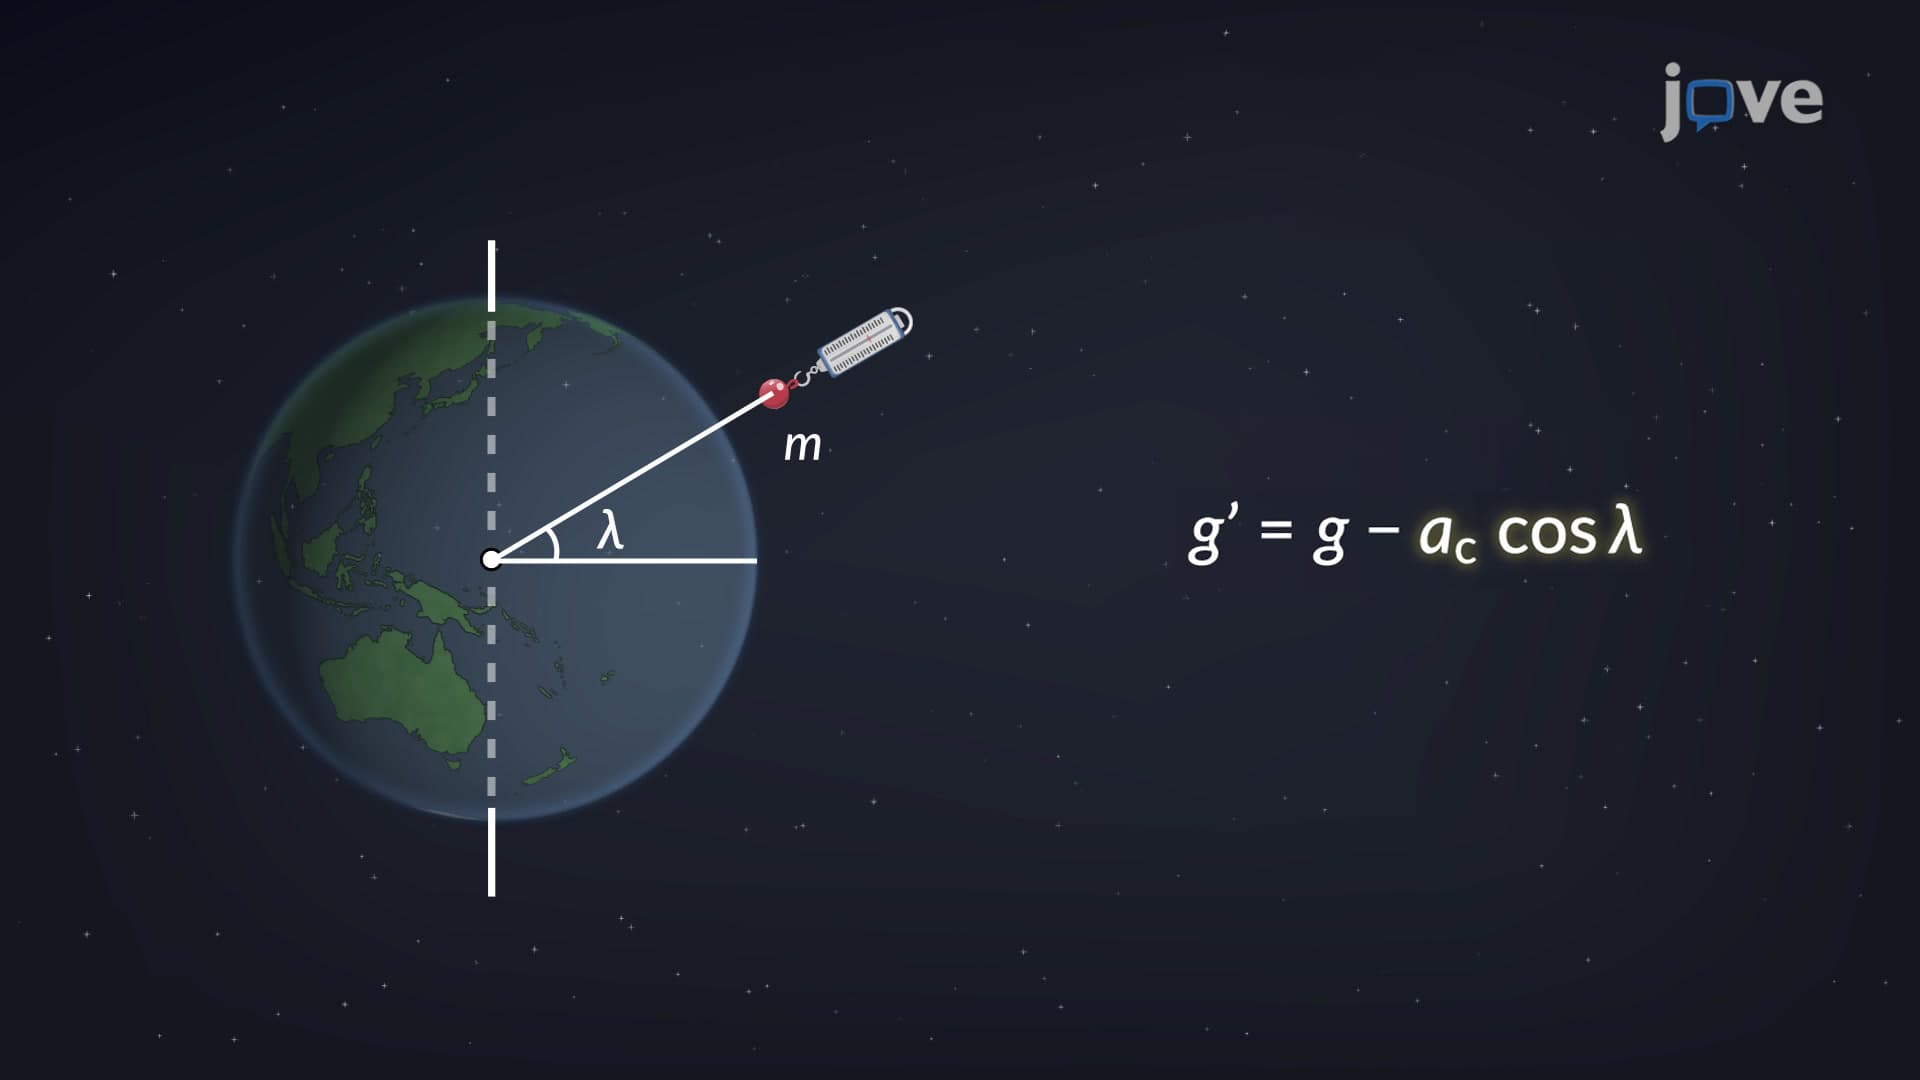
Variation in Acceleration due to Gravity near the Earth's Surface
The difference between the true and apparent weights is proportional to the square of the Earth's angular speed. Since the...
 01:12
Measuring Acceleration Due to Gravity
A simple pendulum can be described as a point mass and a string. Meanwhile, a physical pendulum is any object whose oscillations are similar to a simple pendulum, but cannot be modeled as a point mass on a string because its mass is distributed over a larger area. The behavior of a physical pendulum can be modeled using the principles of...
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
 01:22
Relative Motion Analysis using Rotating Axes - Acceleration
Time differentiation is...