Related Experiment Video
Updated: Aug 29, 2026
Studying DNA Looping by Single-Molecule FRET
Published on: June 28, 2014
A kinematic view of loop closure
Evangelos A Coutsias1, Chaok Seok, Matthew P Jacobson
1Department of Mathematics and Statistics, University of New Mexico, Albuquerque, New Mexico 87131, USA.

Abstract:
We consider the problem of loop closure, i.e., of finding the ensemble of possible backbone structures of a chain segment of a protein molecule that is geometrically consistent with preceding and following parts of the chain whose structures are given. We reduce this problem of determining the loop conformations of six torsions to finding the real roots of a 16th degree polynomial in one variable, based on the robotics literature on the kinematics of the equivalent rotator linkage in the most general case of oblique rotators. We provide a simple intuitive view and derivation of the polynomial for the case in which each of the three pair of torsional axes has a common point. Our method generalizes previous work on analytical loop closure in that the torsion angles need not be consecutive, and any rigid intervening segments are allowed between the free torsions. Our approach also allows for a small degree of flexibility in the bond angles and the peptide torsion angles; this substantially enlarges the space of solvable configurations as is demonstrated by an application of the method to the modeling of cyclic pentapeptides. We give further applications to two important problems. First, we show that this analytical loop closure algorithm can be efficiently combined with an existing loop-construction algorithm to sample loops longer than three residues. Second, we show that Monte Carlo minimization is made severalfold more efficient by employing the local moves generated by the loop closure algorithm, when applied to the global minimization of an eight-residue loop. Our loop closure algorithm is freely available at http://dillgroup. ucsf.edu/loop_closure/.

Related Concept Videos
 01:18
Kinematic Equations - III
Using the kinematic equations,...
 01:17
Kinematic Equations - II
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
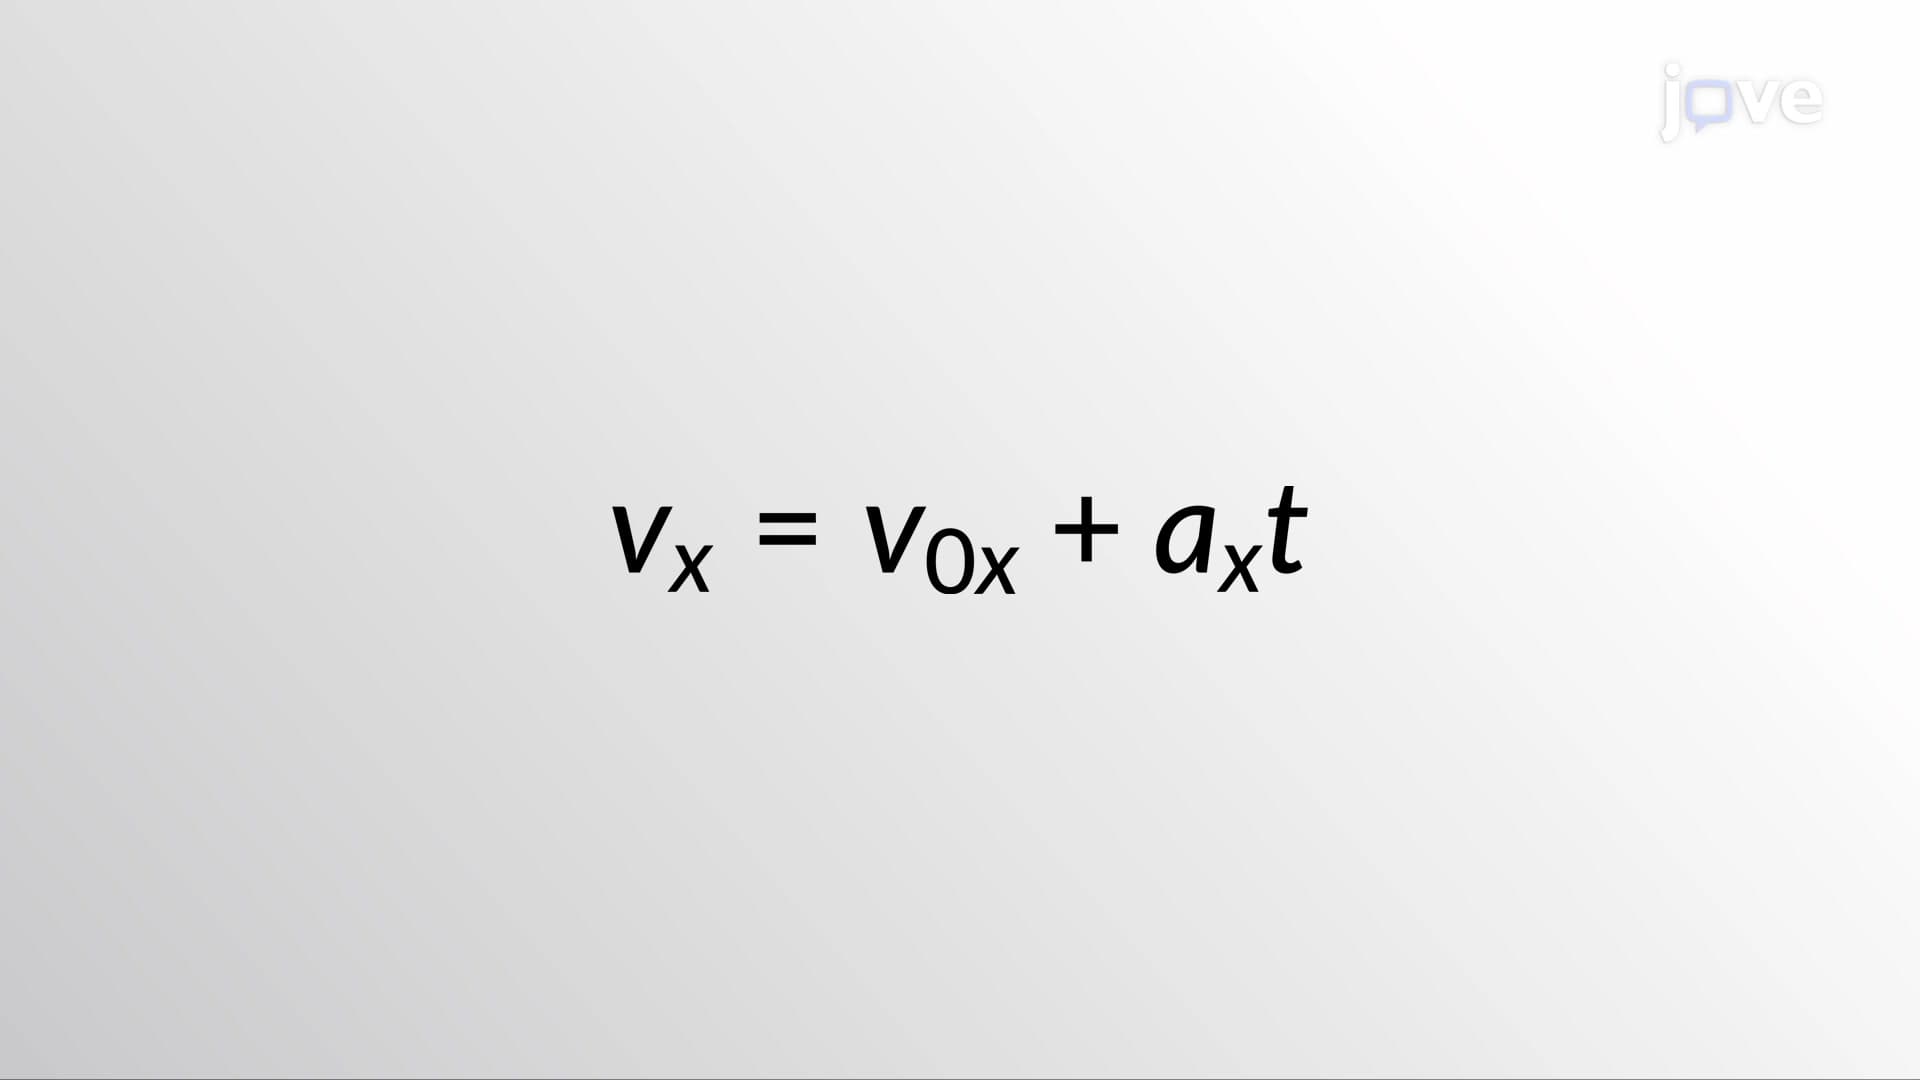 01:26
Kinematic Equations - I
 01:30
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
 01:15
Kinematic Equations: Problem Solving
 01:30
Dynamics of Circular Motion
Any acceleration must be produced by some force. Therefore, any force or combination of forces can cause centripetal acceleration. A few examples include the tension in the rope on a...