Skill acquisition and development: the roles of state-, parameter, and graph dynamics

E L Saltzman1, K G Munhall

  • 1Haskins Laboratories, New Haven Center for the Ecological Study of Perception and Action, University of Connecticut, Storrs 06511, USA.

Related Concept Videos

State Space Representation01:27

State Space Representation

The frequency-domain technique, commonly used in analyzing and designing feedback control systems, is effective for linear, time-invariant systems. However, it falls short when dealing with nonlinear, time-varying, and multiple-input multiple-output systems. The time-domain or state-space approach addresses these limitations by utilizing state variables to construct simultaneous, first-order differential equations, known as state equations, for an nth-order system.
Consider an RLC circuit, a...
Signal Flow Graphs01:18

Signal Flow Graphs

Signal-flow graphs offer a streamlined and intuitive approach to representing control systems, providing an alternative to traditional block diagrams. These graphs use branches to symbolize systems and nodes to represent signals, effectively illustrating the relationships and interactions within the system.
In a signal-flow graph, branches denote the system's transfer functions, while nodes represent the signals. The direction of signal flow is indicated by arrows, with the corresponding...
Modeling with Differential Equations01:25

Modeling with Differential Equations

Population dynamics can be described mathematically by considering the population size P(t) as a function of time. The rate of change of the population is then represented by the derivative of P(t). A simple assumption is that the rate of growth is proportional to the size of the population itself. This leads to an exponential growth model, where the population increases rapidly without bound. While this is a useful first approximation, it does not reflect realistic long-term...
Time-Domain Interpretation of PD Control01:07

Time-Domain Interpretation of PD Control

Proportional-Derivative (PD) control is a widely used control method in various engineering systems to enhance stability and performance. In a system with only proportional control, common issues include high maximum overshoot and oscillation, observed in both the error signal and its rate of change. This behavior can be divided into three distinct phases: initial overshoot, subsequent undershoot, and gradual stabilization.
Consider the example of control of motor torque. Initially, a positive...
Linear Approximation in Time Domain01:21

Linear Approximation in Time Domain

Nonlinear systems often require sophisticated approaches for accurate modeling and analysis, with state-space representation being particularly effective. This method is especially useful for systems where variables and parameters vary with time or operating conditions, such as in a simple pendulum or a translational mechanical system with nonlinear springs.
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length, the...
Graphs of Functions01:30

Graphs of Functions

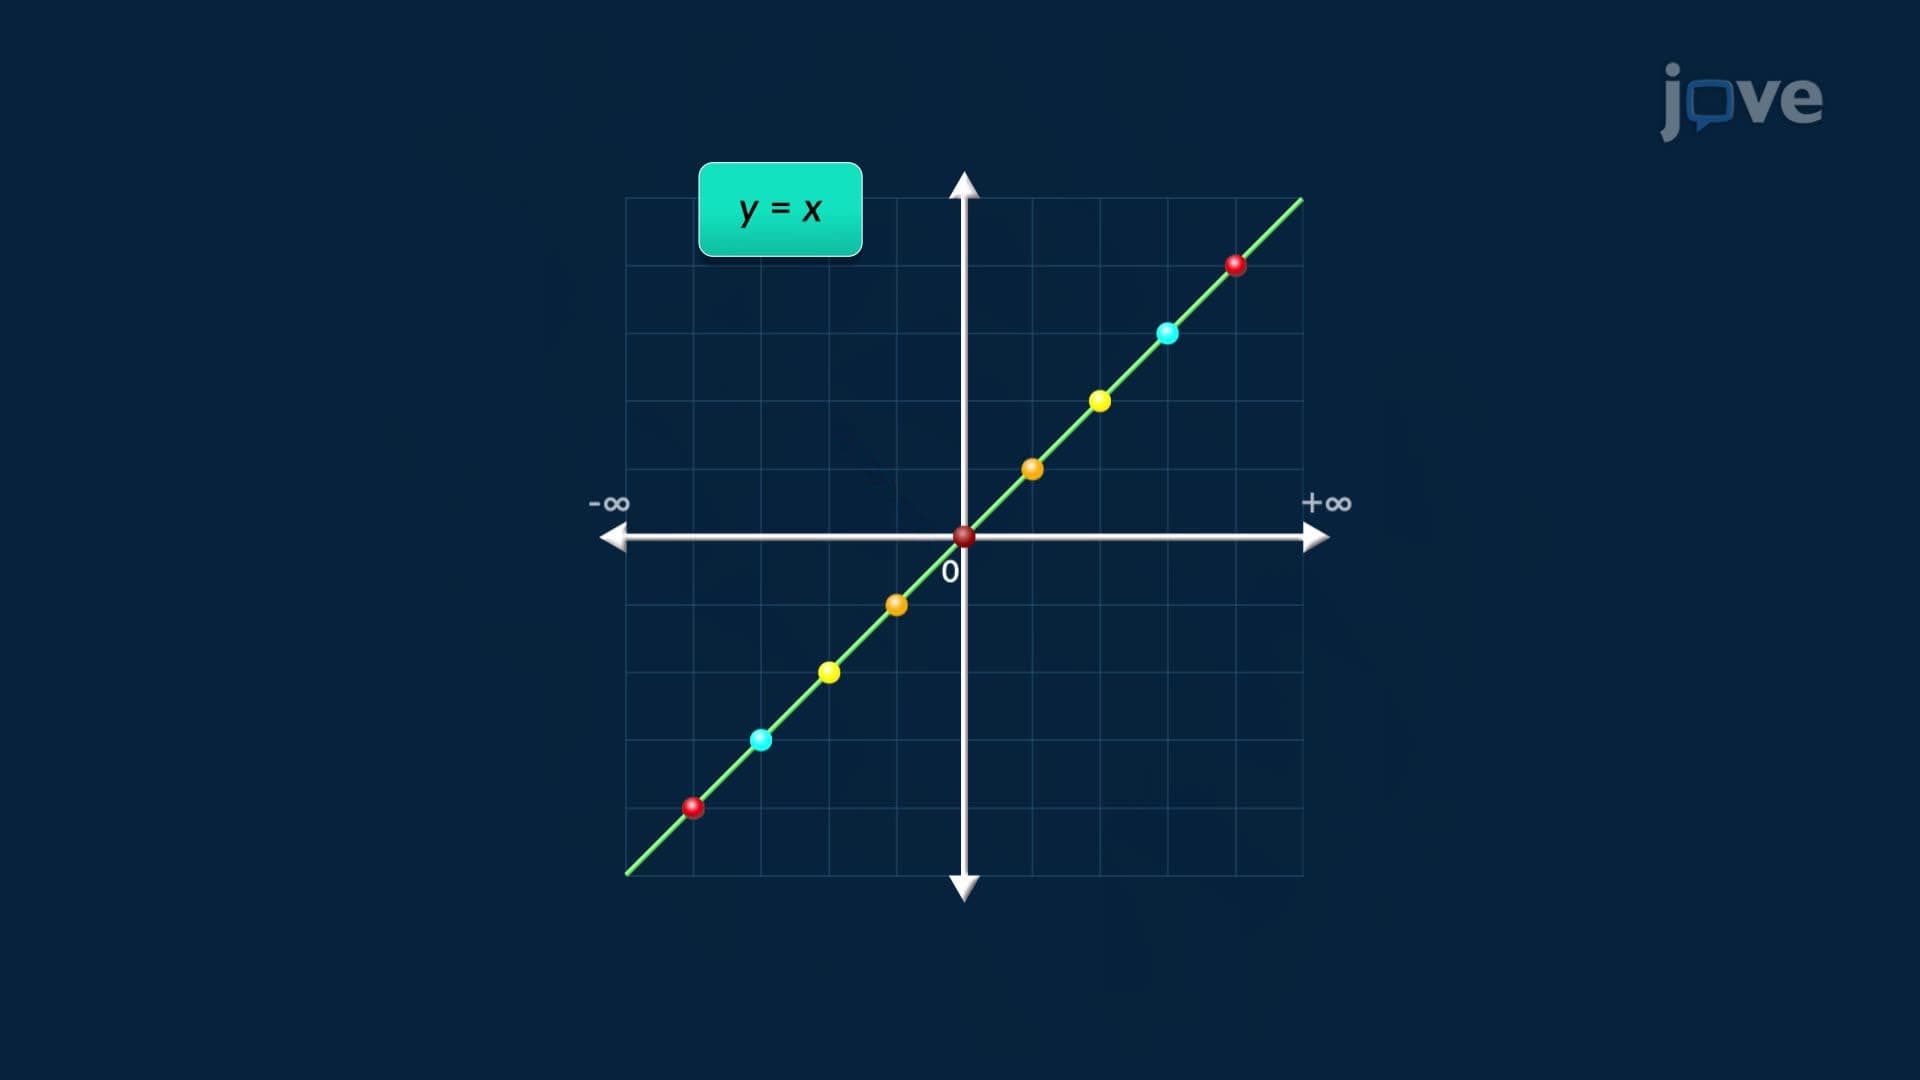
Graphs of functions provide a visual representation of how output values change in response to varying inputs. Each point on the graph corresponds to an ordered pair, where the x-coordinate (independent variable) determines the horizontal position and the y-coordinate (dependent variable) determines the vertical position. Linear functions like y = x give a straight line, indicating a constant rate of change.Nonlinear functions display more complex behaviors. Even power functions generate...
