Is object texture a constraint on human prehension?: kinematic evidence
Related Experiment Video
Updated: Aug 29, 2026

Estimation of Contact Regions Between Hands and Objects During Human Multi-Digit Grasping
Published on: April 21, 2023
P L Weir1, C L MacKenzie, R G Marteniuk
1Department of Kinesiology, University of Waterloo.

Abstract:
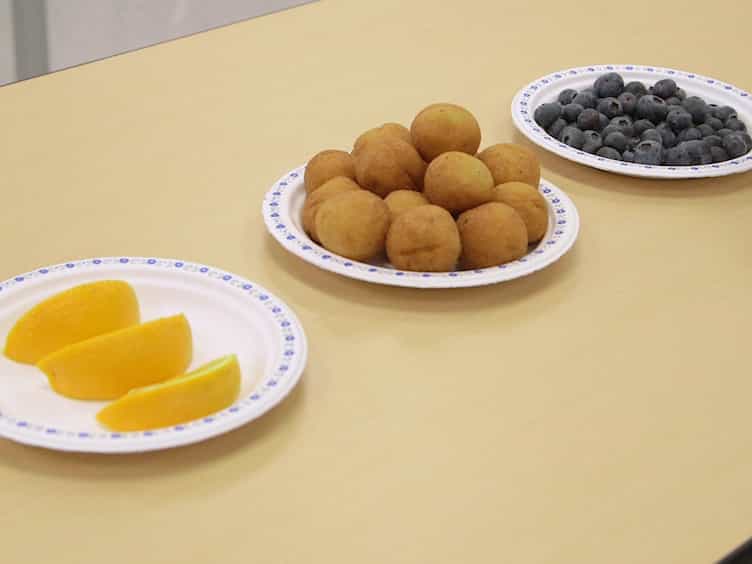
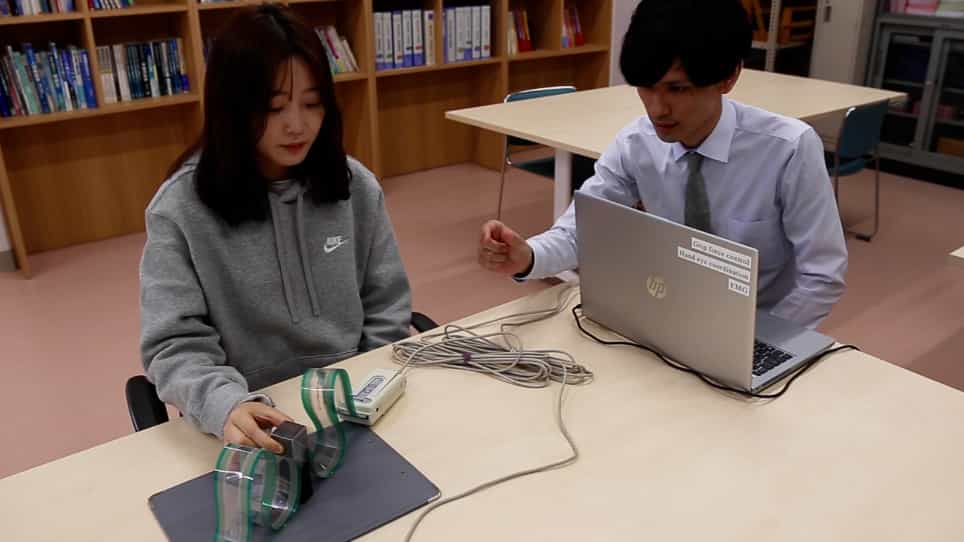
The present experiment determined whether object texture influenced the transport and grasp components of human prehension. Infrared markers placed on the index finger, thumb, and wrist were recorded using a WATSMART system. The test objects were cylindrical dowels (103 mm high, 25 mm diameter, and 150 g in weight) of various surface materials (plain metal, coated with Vaseline, and covered with coarse sandpaper). Only temporal kinematic measures were affected by texture: Movement time (ms), time after peak deceleration (ms), percentages of movement time following maximum aperture, velocity, and deceleration were all significantly greater for the slippery dowel than the normal and rough dowels. Results indicated that the increased time associated with the slippery dowel could be explained entirely by increased time between contact with the dowel and dowel lift. Thus, these results are like those of Weir, MacKenzie, Marteniuk, Cargoe, and Frazer (1991), in which object weight was shown not to affect the free-motion phase, which includes the transport and grasp components of prehension. It appears that intrinsic object properties like weight and texture affect only the finger-object interaction phase of prehension; subsequent research is needed to dissociate inertial and surface friction effects while in contact with objects
Related Concept Videos
 01:26
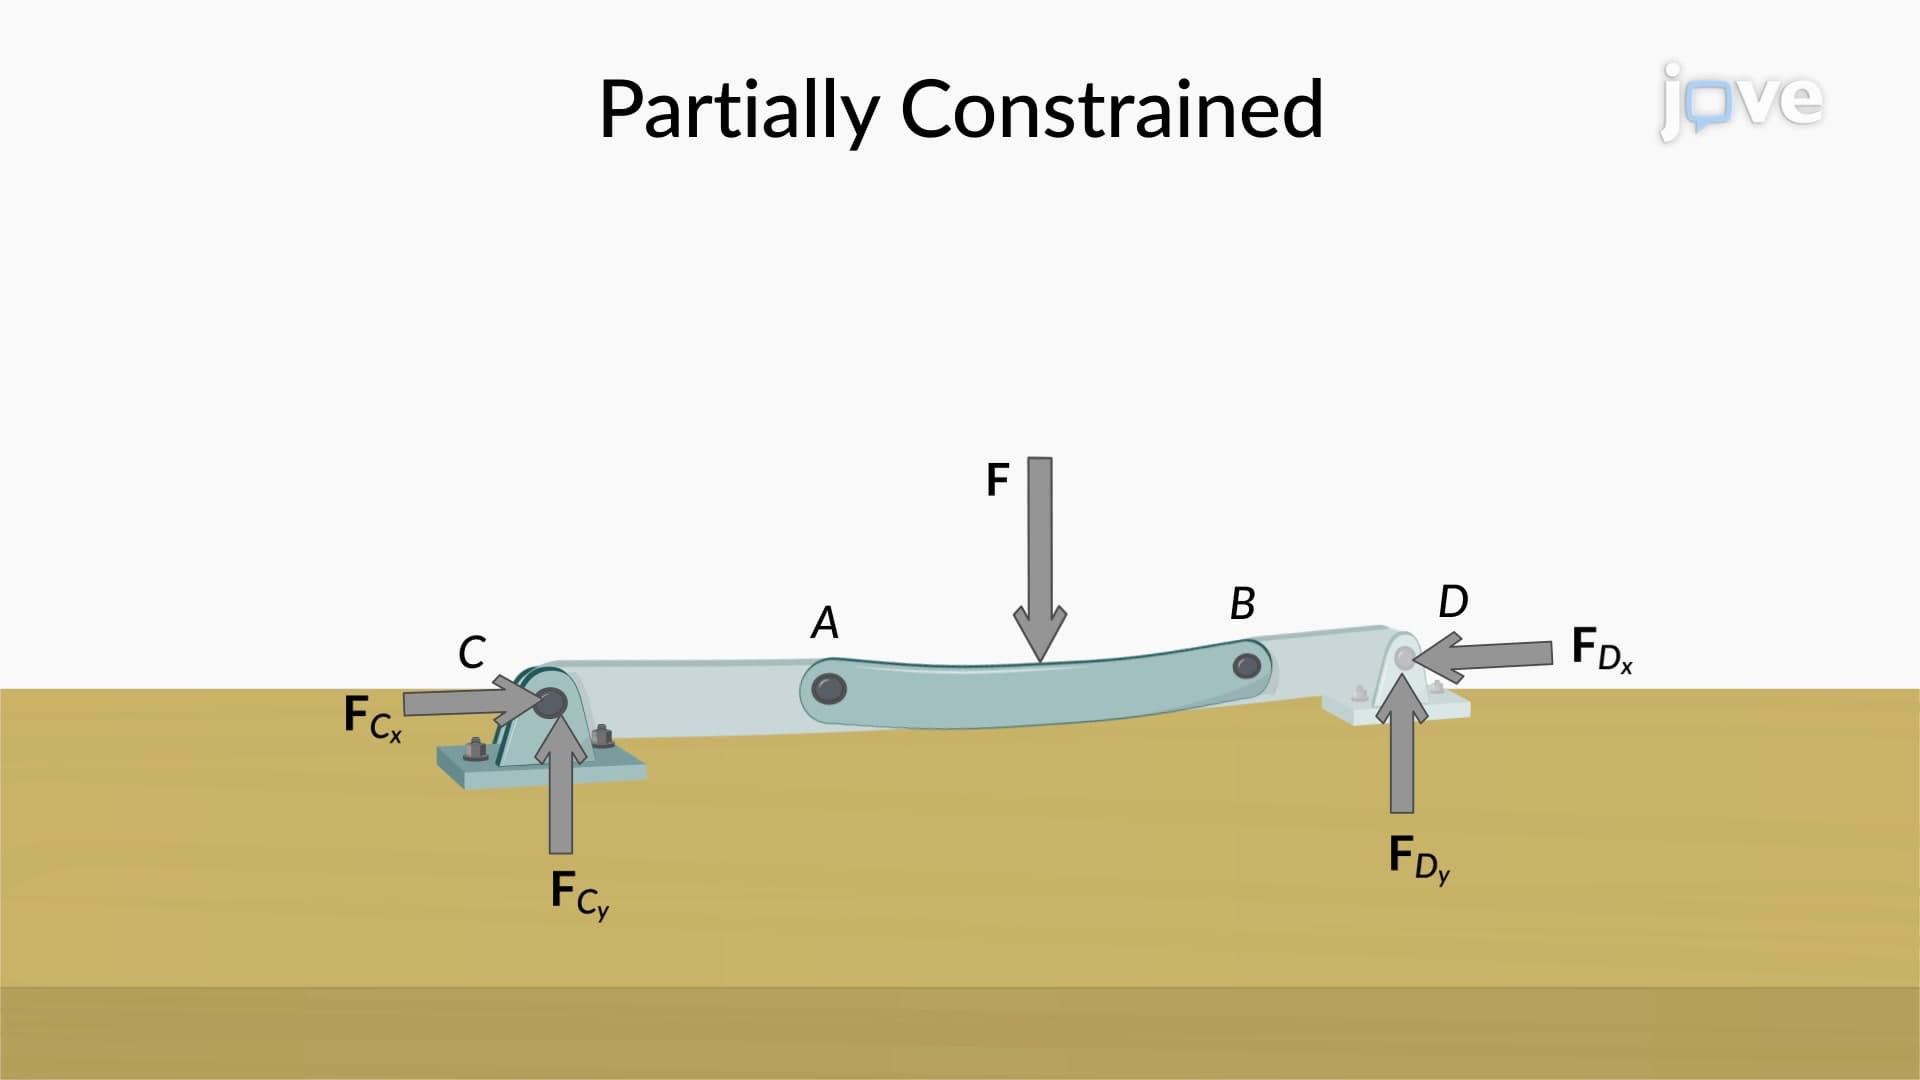
Constraints and Statical Determinacy
 01:28
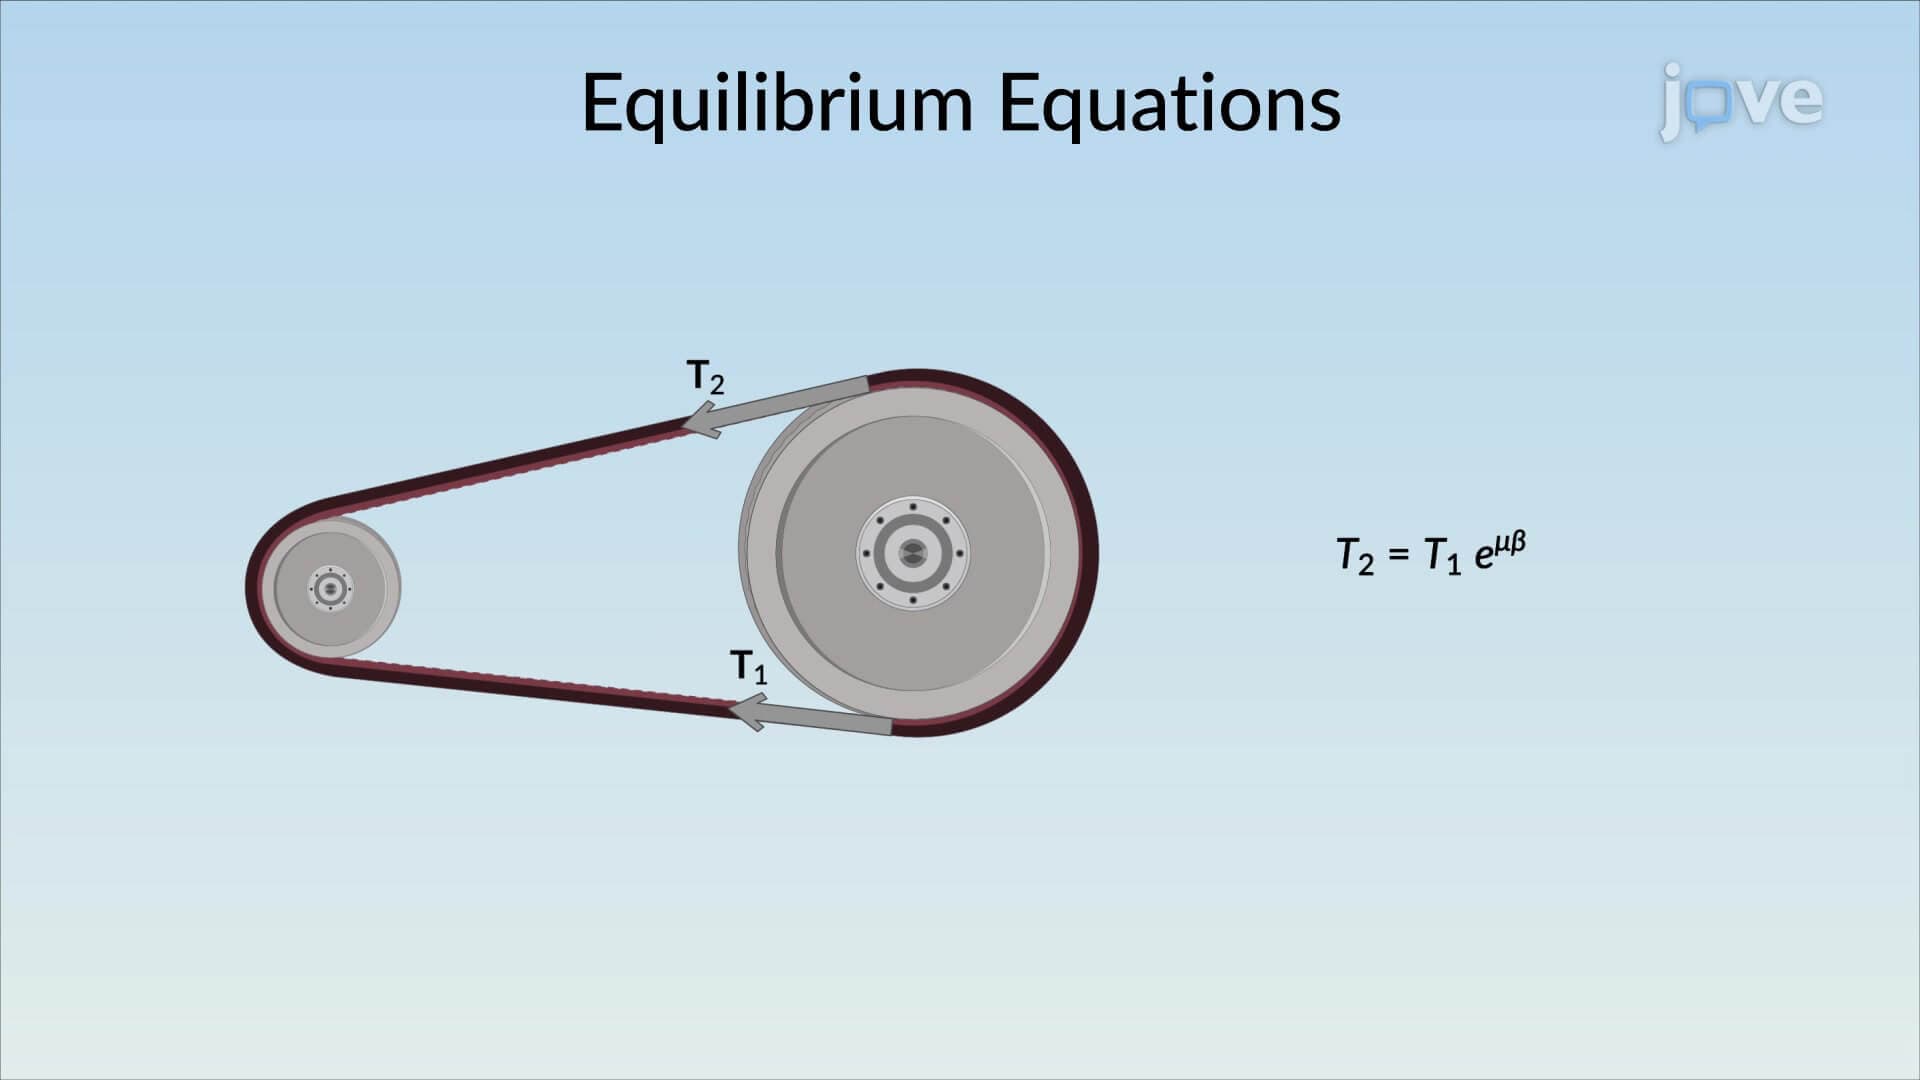
Frictional Forces on Flat Belts
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:21
Rigid Body Equilibrium Problems - II
Consider two children sitting on a seesaw, which has negligible mass. The first child has a mass (m1) of 26 kg and sits at point A, which is 1.6 meters (r1) from the pivot point B; the second child has a mass (m2) of 32 kg and sits at point C. How far from the pivot point B should the second child sit (r2) to balance the seesaw?
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
 00:49
Rigid Body Equilibrium Problems - I