Related Experiment Video
Updated: Aug 26, 2026

An Analog Macroscopic Technique for Studying Molecular Hydrodynamic Processes in Dense Gases and Liquids
Published on: December 4, 2017
On nonoscillation and monotonicity of solutions of nonnegative and compartmental dynamical systems
VijaySekhar Chellaboina1, Wassim M Haddad, James M Bailey
1Mechanical and Aerospace Engineering, University of Missouri, Columbia, MO 65211, USA. ChellaboinaV@missouri.edu

Abstract:
Nonnegative and compartmental dynamical system models are widespread in biological, physiological, and ecological sciences and play a key role in understanding these processes. In the specific field of pharmacokinetics involving the study of drug concentrations (in various tissue groups) as a function of time and dose, nonnegative and compartmental models are vital in understanding system wide effects of pharmacological agents. Since drug concentrations are often assumed to monotonically decline after discontinuation of drug administration, standard pharmacokinetic modeling may ignore the possibility of system oscillation. However, nonnegative and compartmental system models may exhibit nonmonotonic solutions resulting in differences between model predictions and experimental data. In this paper, we present necessary and sufficient conditions for identifying nonnegative and compartmental systems that only admit nonoscillatory and monotonic solutions.
Related Concept Videos
 01:19
Limits with Oscillating Discontinuities
 01:24
BIBO stability of continuous and discrete -time systems
To determine the BIBO stability, the convolution integral is utilized when a bounded continuous-time input is applied to a Linear Time-Invariant (LTI) system.
 01:07
Damped Oscillations
Although friction and other non-conservative...
 01:31
Classification of Systems-II
 01:18
Second Order systems II
If ζ...
 01:20
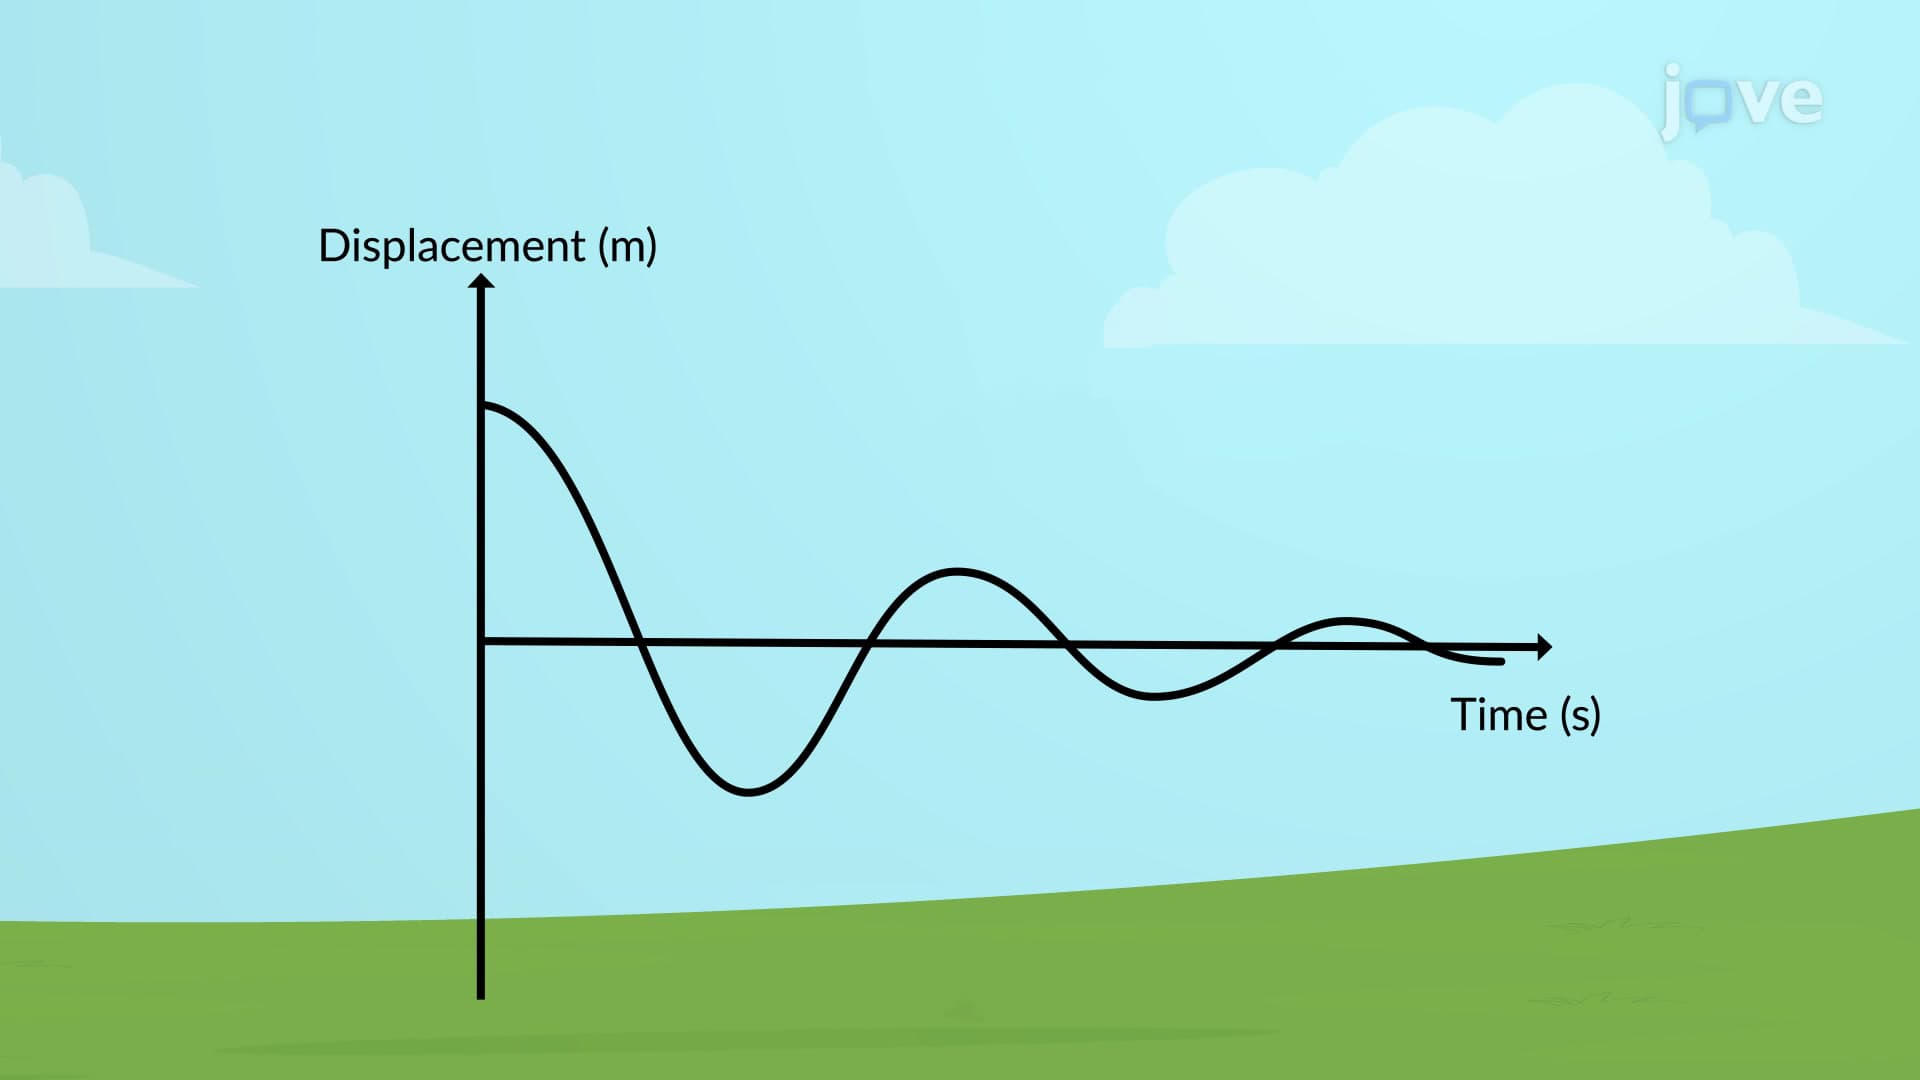
Types of Damping