Related Experiment Video
Updated: Aug 25, 2026
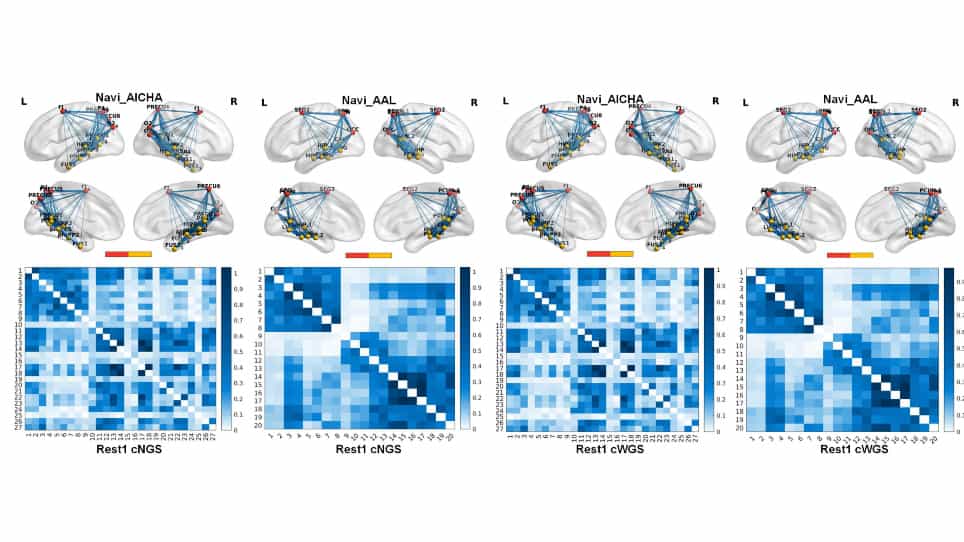

Modeling the Functional Network for Spatial Navigation in the Human Brain
Published on: October 13, 2023
Basic principles of the KIV model and its application to the navigation problem
Robert Kozma1, Walter J Freeman
1Division of Computer Science, The University of Memphis, Memphis, TN 38152, USA. rkozma@memphis.edu

Abstract:
EEG measurements indicate the presence of common-mode, coherent oscillations shared by multiple cortical areas. In previous studies the KIII model has been introduced, which interprets the experimental observations as nonlinear, spatially distributed dynamical oscillations of locally coupled neural populations. KIII can account for the fast and robust classification and pattern recognition in sensory cortices. In order to describe selection of action, planning, and spatial orientation functions, in this paper we expand KIII into the KIV model. KIV approximates the operation of the corticostriatal-hippocampal system. KIV consists of three KI, eight KII and three KIII components, including sensory and cortical systems, as well as the hippocampus, amygdala, and the septum. KIV implements various types of dynamic neural activities. The neural activity patterns determine the emergence of global spatial encoding to implement the orientation function of a simulated animal. Our results indicate the mechanisms, which we believe support the generation of cognitive maps in the hippocampus based on the sensory input-based destabilization of cortical spatio-temporal patterns. In this paper, we describe the conceptual design of the KIV model. We outline the biological background and motivation of the basic principles that are applied to design the KIV computational model. We use the KIV model to explain how the hippocampal neural circuitry functions are constructed and controlled by the corticostriatal-hippocampal loops, supplemented with specific subcortical units. In the second part, we implement these principles using the example of the hippocampal formation as a KIII unit. We demonstrate the learning and navigation principles using the Evolving Multi-module Mobile Agent (EMMA) in 2D software environment.
Related Concept Videos
 01:29
Mechanistic Models: Compartment Models in Algorithms for Numerical Problem Solving
In individual population analyses, different algorithms are employed, such as Cauchy's method, which uses a...
 01:29
Real-World Applications of Space Curves
 01:15
Kinematic Equations: Problem Solving
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:30
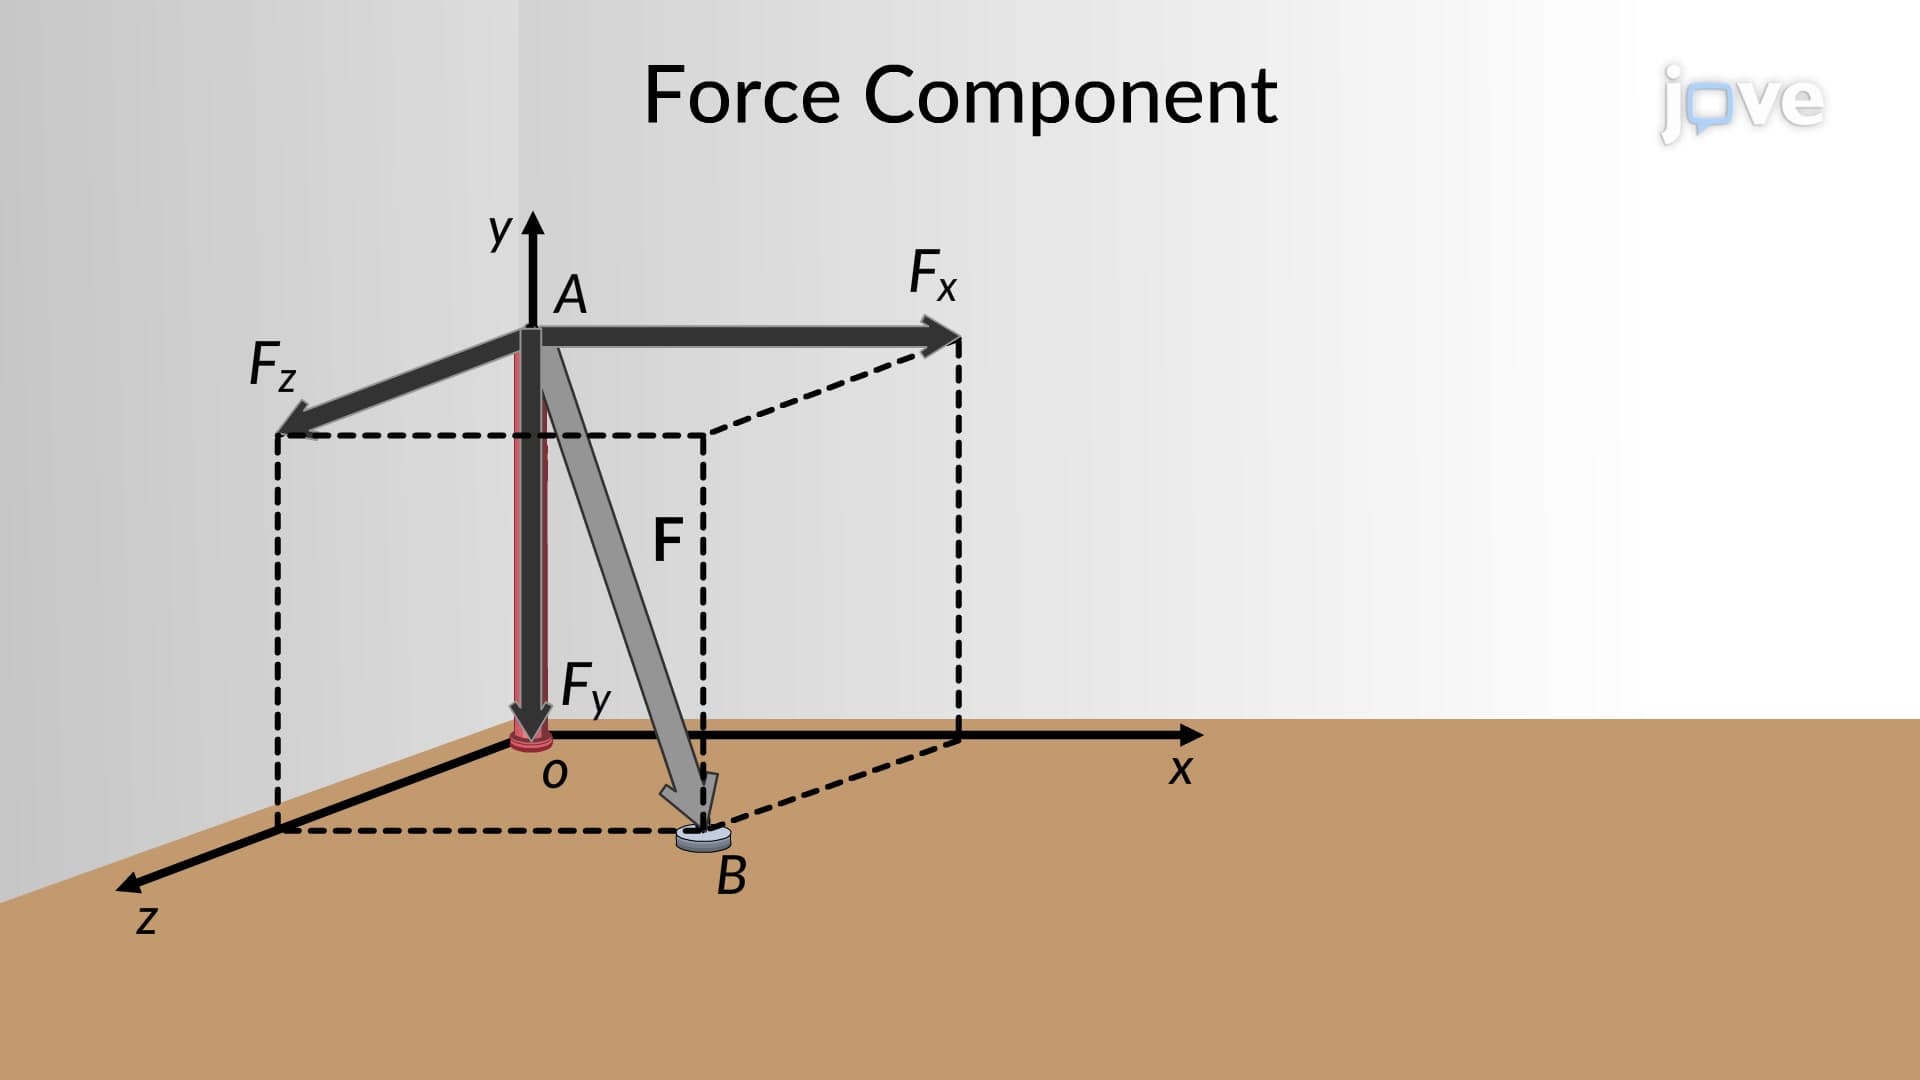
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
 01:30
Principle of Moments: Problem Solving
One such scenario involves a pole placed in a three-dimensional system with a cable attached. When a tension is applied to the cable, the moment about the z-axis passing through...