Related Experiment Video
Updated: Aug 25, 2026

Signal Attenuation as a Rat Model of Obsessive Compulsive Disorder
Published on: January 9, 2015
Optimal impedance control for task achievement in the presence of signal-dependent noise
Rieko Osu1, Naoki Kamimura, Hiroshi Iwasaki
1ATR Computational Neuroscience Labs., 2-2-2 Hikaridai, Seika-cho, Soraku-gun, Kyoto 619-0288, Japan.

Abstract:
There is an infinity of impedance parameter values, and thus different co-contraction levels, that can produce similar movement kinematics from which the CNS must select one. Although signal-dependent noise (SDN) predicts larger motor-command variability during higher co-contraction, the relationship between impedance and task performance is not theoretically obvious and thus was examined here. Subjects made goal-directed, single-joint elbow movements to either move naturally to different target sizes or voluntarily co-contract at different levels. Stiffness was estimated as the weighted summation of rectified EMG signals through the index of muscle co-contraction around the joint (IMCJ) proposed previously. When subjects made movements to targets of different sizes, IMCJ increased with the accuracy requirements, leading to reduced endpoint deviations. Therefore without the need for great accuracy, subjects accepted worse performance with lower co-contraction. When subjects were asked to increase co-contraction, the variability of EMG and torque both increased, suggesting that noise in the neuromotor command increased with muscle activation. In contrast, the final positional error was smallest for the highest IMCJ level. Although co-contraction increases the motor-command noise, the effect of this noise on the task performance is reduced. Subjects were able to regulate their impedance and control endpoint variance as the task requirements changed, and they did not voluntarily select the high impedance that generated the minimum endpoint error. These data contradict predictions of the SDN-based theory, which postulates minimization of only endpoint variance and thus require its revision.
Related Concept Videos
 01:27
Time and frequency -Domain Interpretation of PI Control
Acting as a low-pass filter, the PI controller slows the system's response and extends settling times. This requires careful...
 01:20
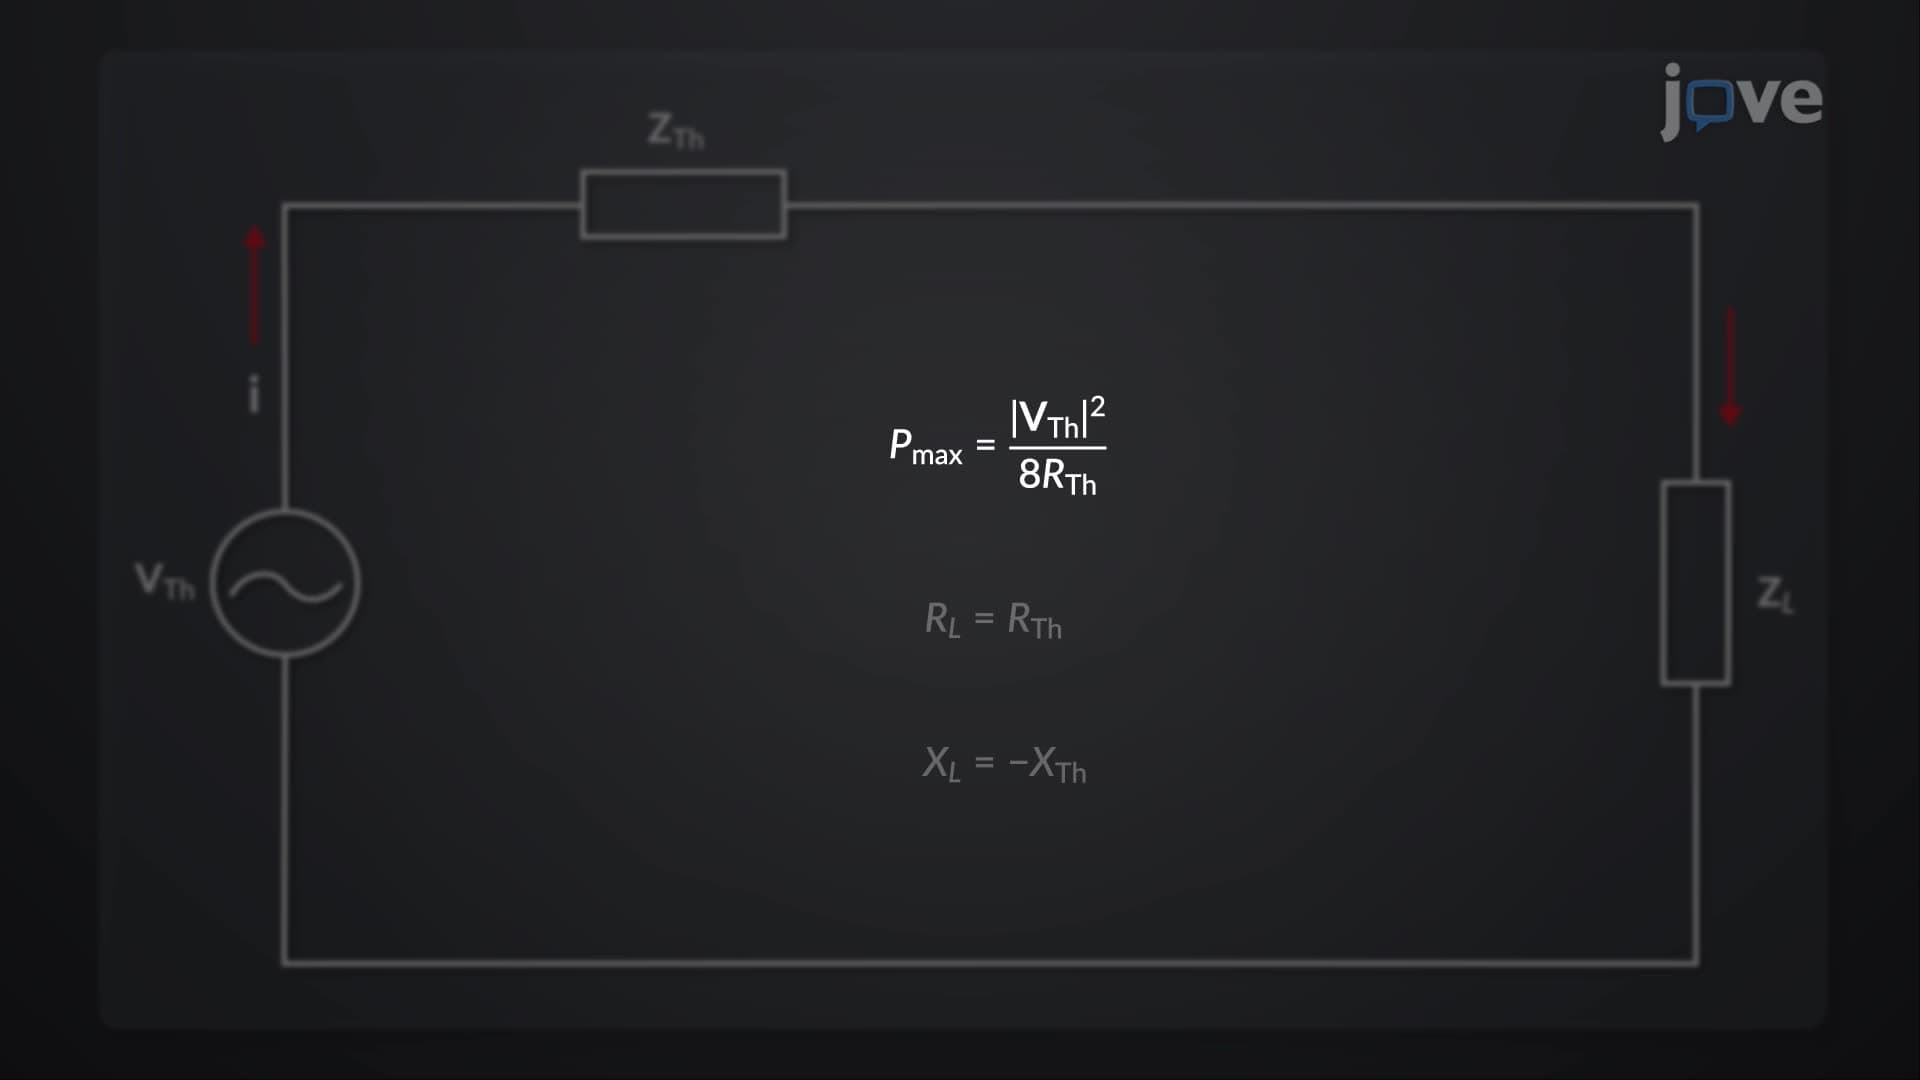
The Maximum Power Transfer Theorem
The load connected draws the current, and the circuit delivers the power to the load. The alternating current flowing through the load is determined using the rectangular form of voltages, currents, network impedance, and load impedance. The average power delivered to the load is obtained from the product of the square of current and load resistance.
 01:23
Optimal Arousal Theory
Inverted U-Shaped Performance Curve
The...
 01:24
Effects of feedback
Feedback significantly modifies the gain of a control system. The gain of a system without feedback is altered by a factor of one plus GH, where G represents...
 01:17
Properties of the z-Transform I
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...