Related Experiment Video
Updated: Aug 25, 2026

Eye Movements in Visual Duration Perception: Disentangling Stimulus from Time in Predecisional Processes
Published on: January 19, 2024
Determining movement onsets from temporal series
1Université Laval, Départment d'éducation Physique, PEPS, Laboratoire de Performance Motrice Humaine, Sainte-Foy, Québec G1K 7P4, Canada. 35019110@vml.ulaval.ca

Abstract:
With the advent of recent measurement techniques, kinematic and kinetic measures commonly are used to describe events over time. Often, the central and peripheral nature of the control processes involved are derived from these temporal series. For example, movement onset often arbitrarily defines the end of the central and the beginning of the peripheral processes. Because of its critical temporal location, we examined whether response dynamics (average movement velocity) affects the determination of movement onset. Interactive graphics and numerical methods of determining movement onsets from temporal series were evaluated on various kinematic signals. Variations in the initial rate of change in a given signal significantly affected the determination of movement onset. Consequently, measurements of component latency must be regarded with caution. A cursory description of related problems elucidated in previous research is discussed, and procedures that can minimize these artifacts are suggested.
Related Concept Videos
 01:16
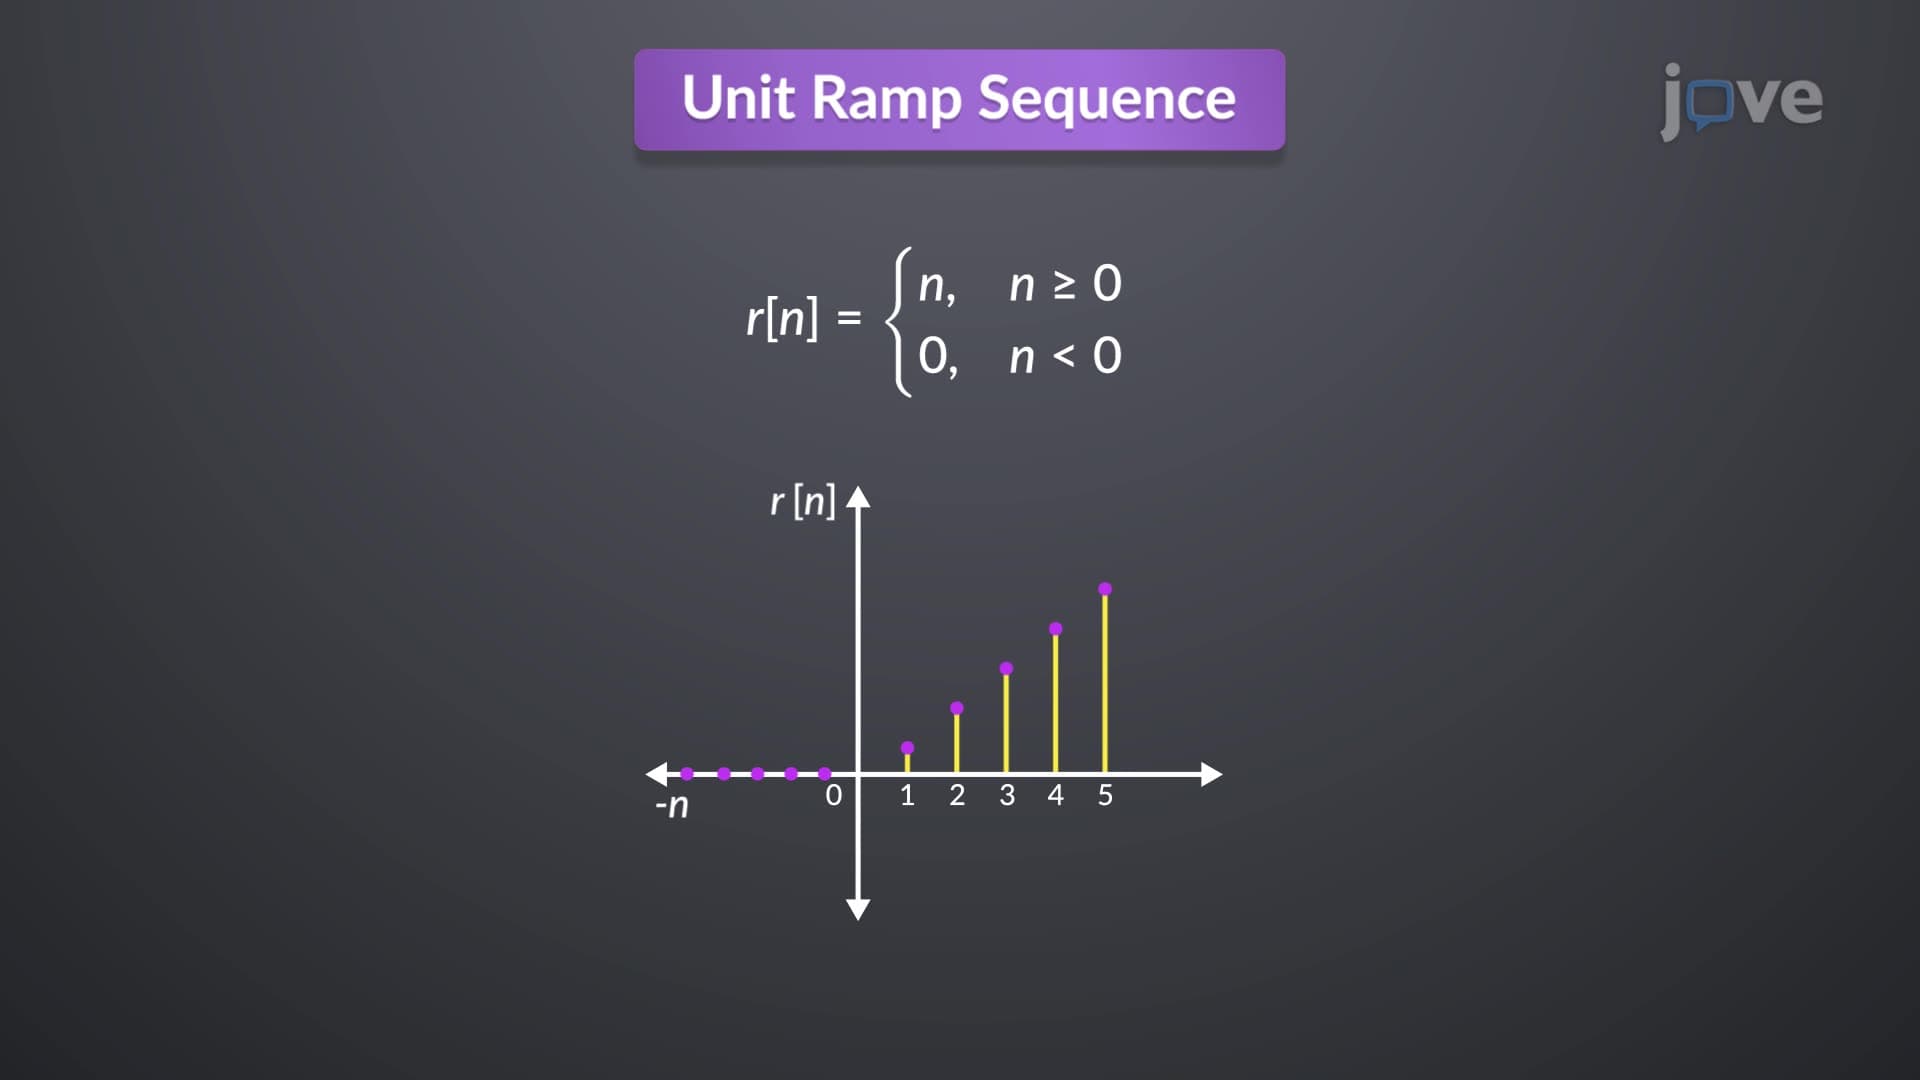
Basic Discrete Time Signals
The unit impulse or sample sequence is mathematically expressed as zero for all n values except at n=0, where it is one. The unit impulse sequence, denoted by δ(n), is the first difference of the unit step sequence, while the unit step sequence u(n) is the...
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the drone...
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
 01:24
Relative Motion Analysis - Velocity
When an external force is exerted, it sets the crank into a rotational movement. This, in turn, instigates the motion of the connecting rod, leading to what is referred to as a general plane motion. This process involves two key points - point A on the connecting rod...
 01:10
Relative Motion Analysis - Acceleration