Related Experiment Video
Updated: Aug 19, 2026
DNA Nanotubes as a Versatile Tool to Study Semiflexible Polymers
Published on: October 25, 2017
Algorithmic generation of freely jointed hard sphere chains and properties of their inertial tensors
1Department of Mathematics and Statistics, Wright State University, Dayton, Ohio 45435, USA. wwang@math.wright.edu

Abstract:
A statistical algorithm, capable of generating a large number of freely jointed hard sphere chains, is presented. This is the first of a series of algorithms being developed to model unfolded proteins by different modes of hard sphere chains. The aim of these studies is to systematically investigate the effects of different factors, such as atomic radii, bond angles, torsion angles, chain length, etc., on the conformation of unfolded proteins and other random polymers. As continuous models, various types of hard sphere chains enable one to isolate the aforementioned factors one at a time for investigation and thus are advantageous over discrete lattice models. In particular, the freely jointed hard sphere chain model allows one to evaluate the excluded volume effect. As a first step in this endeavor, the average determinant D(N, r) and the average trace T(N, r) of the inertial tensor A of the random chains were calculated at various sphere radii r and chain lengths N. It is found that both the average determinant D(N, r) and the average trace T(N, r) scale linearly with chain length N after logarithmic transformation. However, the critical exponent of D(N, r) increases with r faster than that of T(N, r) as a result of the non-commutativity between the det operator and the average operator < >. The significance of the algorithm and the results obtained on understanding random polypeptide chains are discussed.
More Related Videos
 11:42
Synthesis of Monodisperse Cylindrical Nanoparticles via Crystallization-driven Self-assembly of Biodegradable Block Copolymers
Published on: June 20, 2019
 09:03
Generating Spheroids from Various Chondrocytes using Low-Adhesive Conditions under Gravity and Homemade Mini-Bioreactors
Published on: January 31, 2025
Related Concept Videos
 01:10
First Law: Particles in One-dimensional Equilibrium
 01:18
First Law: Particles in Two-dimensional Equilibrium
Newton's first law tells us about the...
 01:14
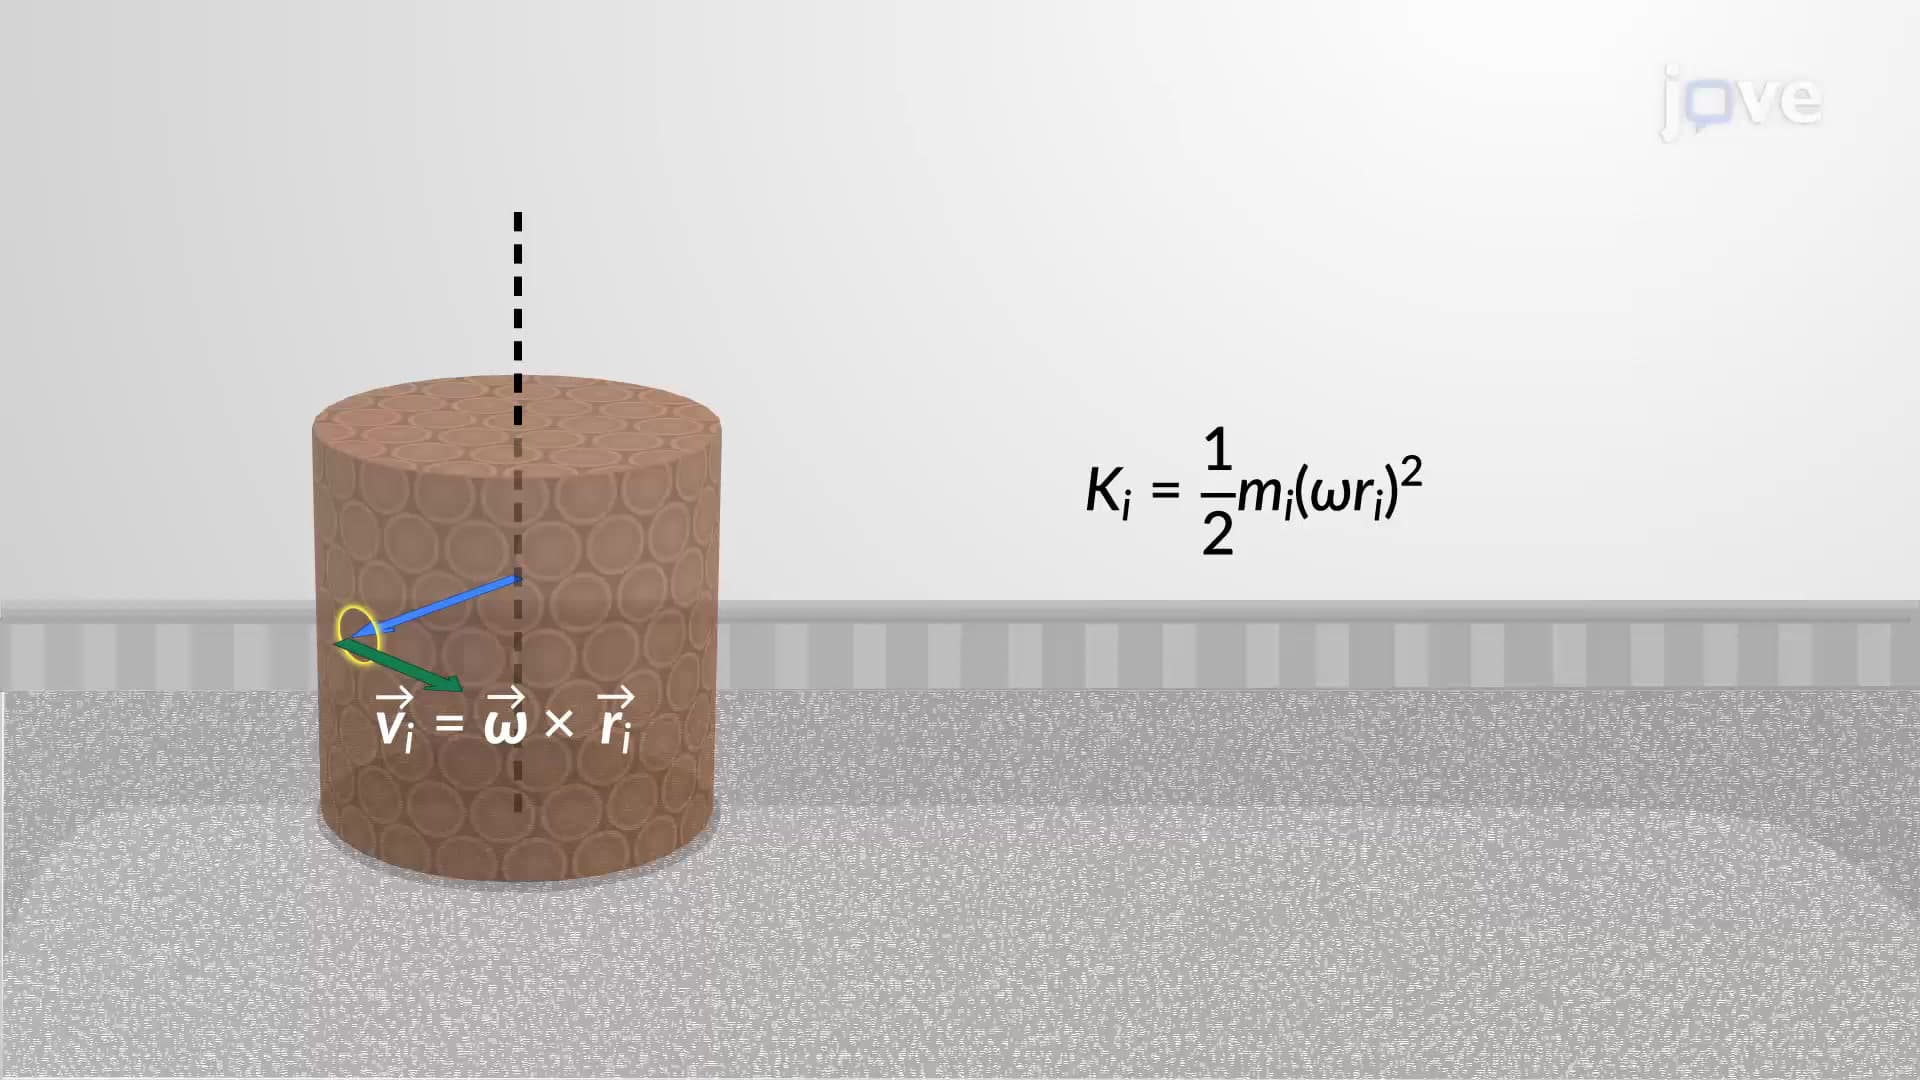
Moment of Inertia
If a rigid body is rotating about an axis but is not in translational motion, its translational kinetic energy is zero. However, since each particle undergoes rotational motion, it possesses non-zero velocity and kinetic energy. Thus, the kinetic energy of the rigid body, which is the sum of the...
 01:07
Moment of Inertia of Compound Objects
Consider a child of mass (mc) 25 kg standing at a distance (rc) of 1 m from the axis of a rotating...
 01:17
Radical Chain-Growth Polymerization: Chain Branching
 01:15
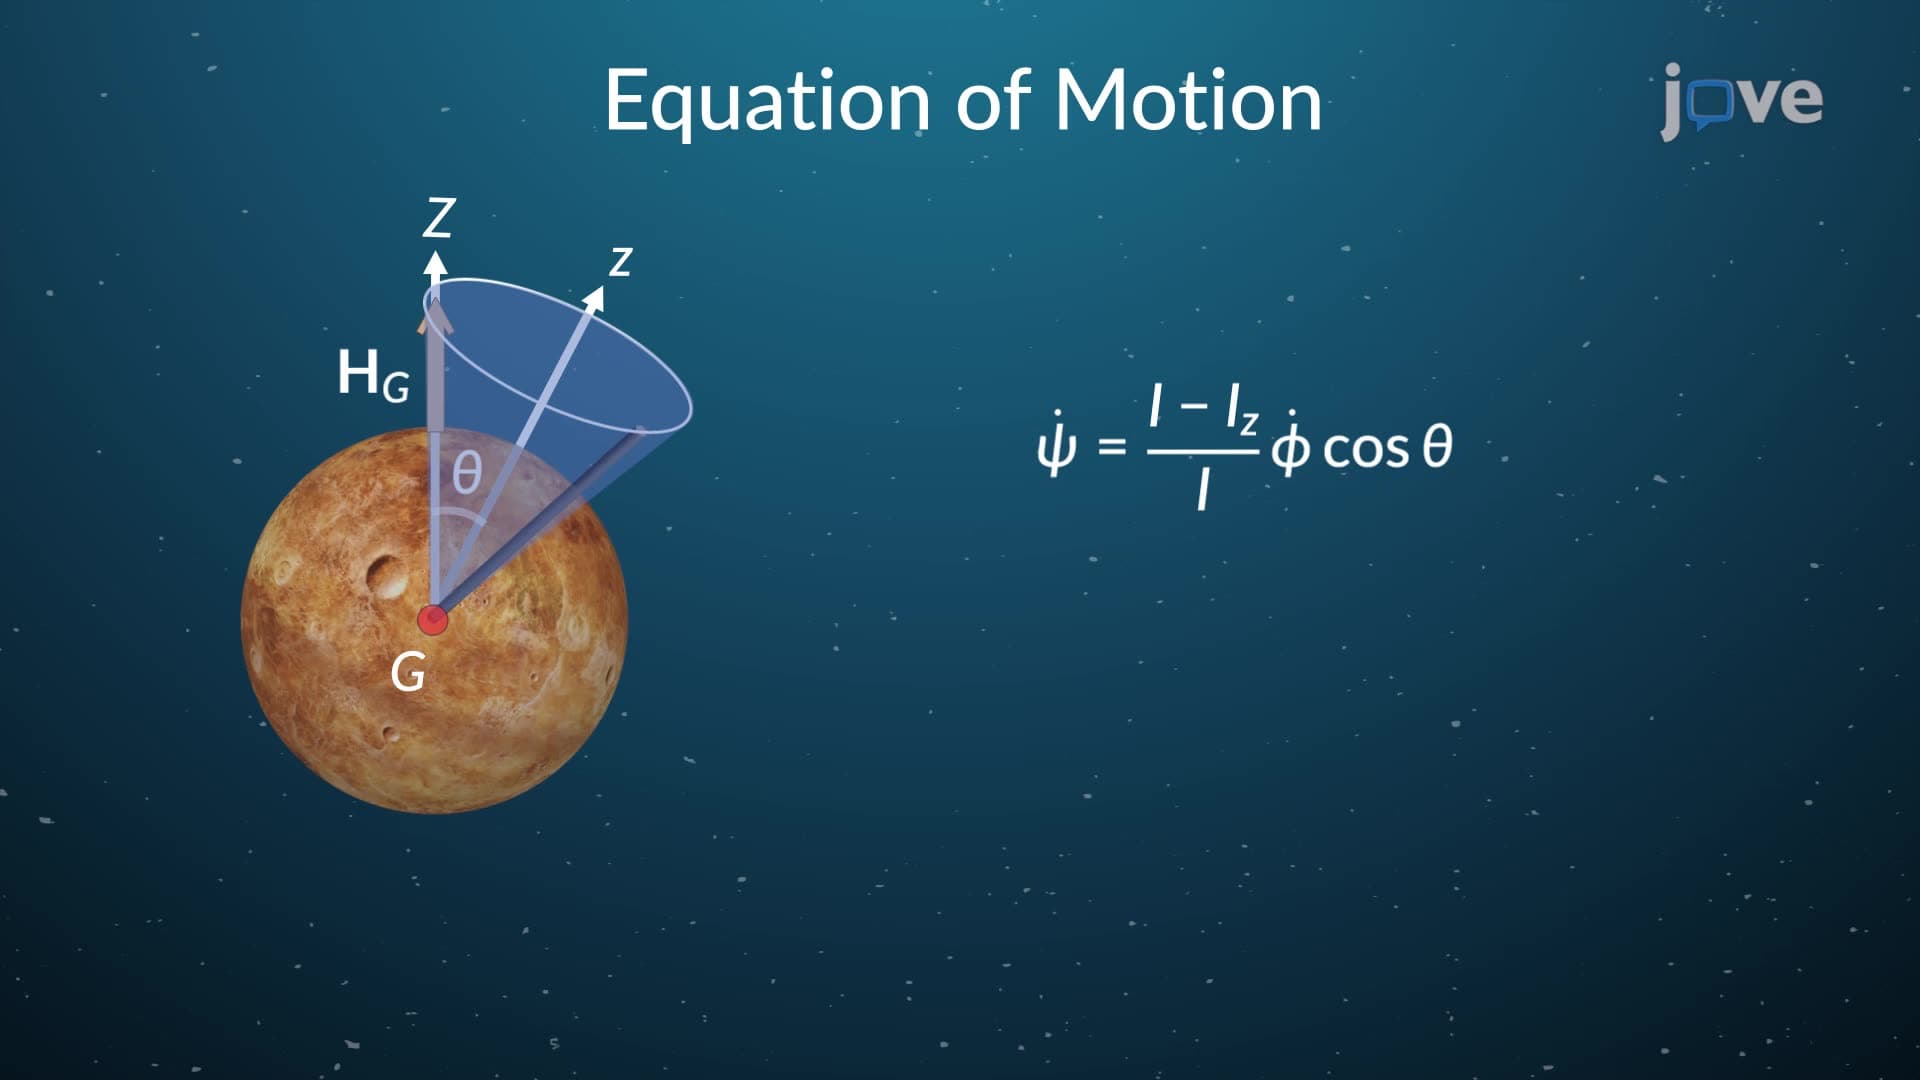
Torque Free Motion