Kinetic attraction during bimanual coordination
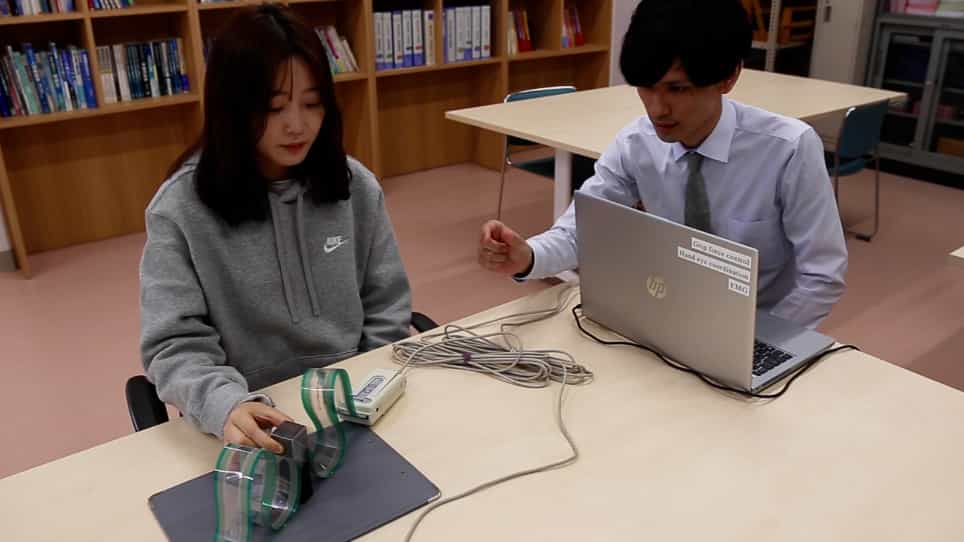
Related Experiment Video
Updated: Aug 24, 2026
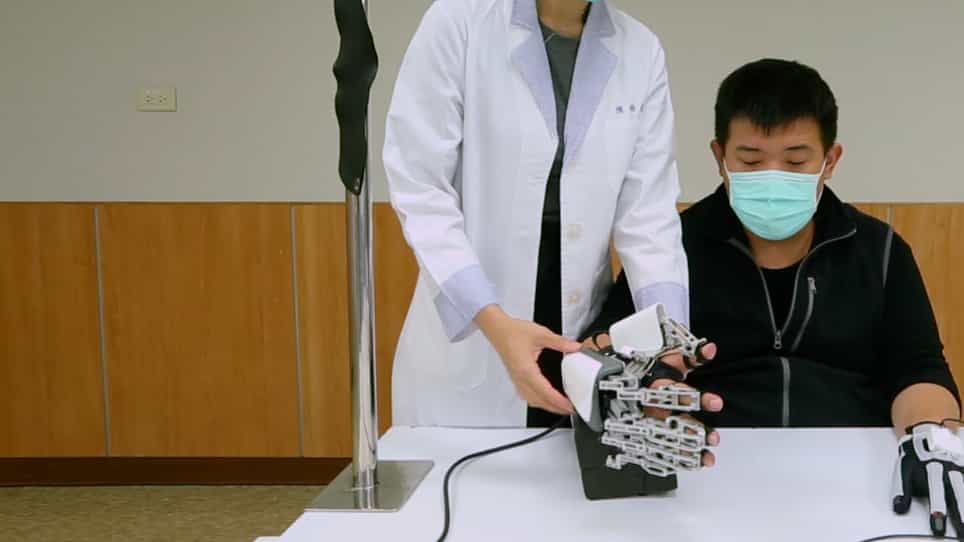
Development of a Novel Task-oriented Rehabilitation Program using a Bimanual Exoskeleton Robotic Hand
Published on: May 20, 2020
1Motor Control Laboratory M/C 194, Department of Physical Education, University of Illinois at Chicago, P.O.B. 4348, Chicago, IL 60680, USA.

Abstract:
Two experiments examined the effects of independent variations in kinetic and kinematic requirements on interlimb coupling during a bimanual task. The goal of the investigation was to provide preliminary evidence regarding one general class of physical variables that constrains discrete bimanual movements. Subjects attempted to execute a smooth unidirectional movement with the left arm, along with a three-segment reversal movement with the right arm. The first experiment manipulated the torque required to produce the reversal action, while movement duration and average angular velocity were held constant for both limbs. Several indications of increased interlimb coupling, due to the kinetic variation, were evident. The converse manipulation was used in the second experiment, with movement time and kinematics (velocity, acceleration) changed independently of joint torque requirements for the reversal limb. No clear effect of kinematics on coupling strength was noted. The results suggest that one variable influencing interlimb attraction toward common spatiotemporal trajectories may be kinetic in nature.

Related Concept Videos
 01:10
Second Law: Motion under Same Force
Let's imagine a person is standing on a weighing...
 01:13
Kinetic Energy for a Rigid Body
 01:24
Muscle Coordination and Action
Agonists
Agonist muscles, often called prime movers, are the primary muscles responsible for producing a specific movement.
 01:10
Relative Motion Analysis - Acceleration
 01:22
Relative Motion Analysis using Rotating Axes - Acceleration
Time differentiation is...
 01:26
Kinetic Friction