Understanding movement control in infants through the analysis of limb intersegmental dynamics
Related Experiment Video
Updated: Aug 24, 2026
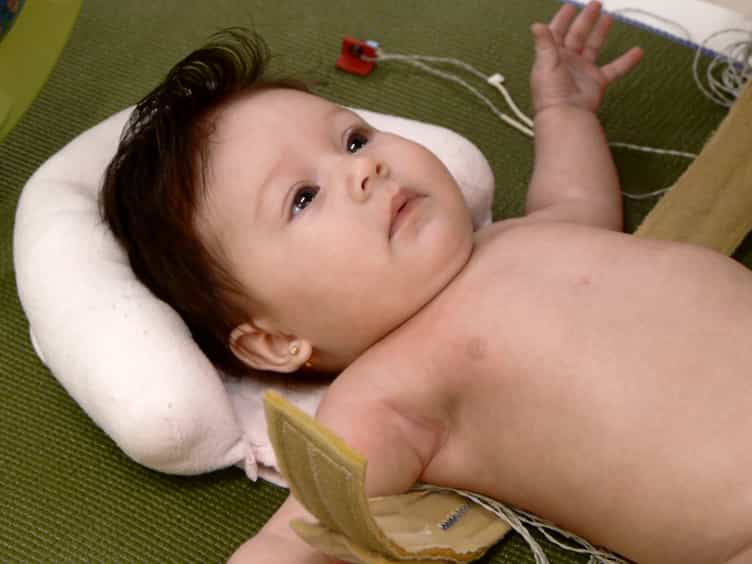
Quantifying Learning in Young Infants: Tracking Leg Actions During a Discovery-learning Task
Published on: June 1, 2015
K Schneider1, R F Zernicke, B D Ulrich
1University of California, USA.

Insights
Infants control kicking movements by adjusting muscle torques to counteract passive forces from gravity and limb motion. This neuromotor system ensures smooth leg trajectories despite varying movement intensity.
Area of Science:
- Neuroscience
- Biomechanics
- Developmental Motor Control
Background:
- Understanding limb movement control requires accounting for active muscle forces and passive forces like gravity and limb segment interactions.
- Infant motor development involves complex neuromotor strategies for generating movements.
Purpose of the Study:
- To investigate how the infant neuromotor system controls active and passive forces during spontaneous leg movements (kicking).
- To analyze limb intersegmental dynamics and joint torque contributions in 3-month-old infants.
Main Methods:
- Utilized inverse dynamics analysis on 3D limb kinematics of infant kicking movements.
- Calculated active (muscular) and passive (gravity, motion-dependent) torque components at hip, knee, and ankle joints.
- Employed a human body model for accurate anthropometric parameter estimation.
Main Results:
- Quantified the interplay of active and passive forces in infant kicking.
- In less vigorous kicks, gravity-opposed extensor torque initiated hip reversal.
- Muscle torques adjusted to counteract increasing motion-dependent and gravitational torques in more vigorous kicks.
Conclusions:
- Infant muscle torques dynamically adjust to balance passive forces, ensuring smooth movement trajectories.
- The neuromotor system effectively manages intersegmental dynamics for controlled, albeit involuntary, limb movements.
- This study elucidates the sophisticated control mechanisms underlying early infant motor behaviors.
Abstract:
One important component in the understanding of the control of limb movements is the way in which the central nervous system accounts for joint forces and torques that may be generated not only by muscle actions but by gravity and by passive reactions related to the movements of limb segments. In this study, we asked how the neuromotor system of young infants controls a range of active and passive forces to produce a stereotypic, nonintentional movement. We specifically analyzed limb intersegmental dynamics in spontaneous, cyclic leg movements (kicking) of varying intensity in supine 3-month-old human infants. Using inverse dynamics, we calculated the contributions of active (muscular) and passive (motion-dependent and gravitational) torque components at the hip, knee, and ankle joints from three-dimensional limb kinematics. To calculate joint torques, accurate estimates were needed of the limb's anthropometric parameters, which we determined using a model of the human body. Our analysis of limb intersegmental dynamics explicitly quantified the complex interplay of active and passive forces producing the simple, involuntary kicking movements commonly seen in 3-month-old infants. our results revealed that in nonvigorous kicks, hip joint reversal was the result of an extensor torque due to gravity, opposed by the combined flexor effect of the muscle torque and the total motion-dependent torque. The total motion-dependent torque increased as a hip flexor torque in more vigorous kicks; an extensor muscle torque was necessary to counteract the flexor influences of the total motion-dependent torque and, in the case of large ranges of motion, a flexor gravity torque as well. Thus, with changing passive torque influences due to motions of the linked segments, the muscle torques were adjusted to produce a net torque to reverse the kicking motion. As a consequence, despite considerable heterogeneity in the intensity, range of motion, coordination, and movement context of each kick, smooth trajectories resulted from the muscle torque, counteracting and complementing not only gravity but also the motion-dependent torques generated by movement of the linked segments.
Related Concept Videos
 01:07
Development of the Limb Synovial Joints
The mesenchymal stem cells differentiate into chondrocytes that form the hyaline cartilage, and later the cartilaginous model of the bone. This model further transforms into a bone. This process is known as endochondral ossification.
During development, the limbs...
 01:10
Relative Motion Analysis - Acceleration
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the drone...
 01:17
Kinematic Equations - II
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...