Related Experiment Video
Updated: Aug 24, 2026

Development of a Novel Task-oriented Rehabilitation Program using a Bimanual Exoskeleton Robotic Hand
Published on: May 20, 2020
Asymmetric division of labor in human skilled bimanual action: the kinematic chain as a model
1Unité de Neurosciences Cognitives, Laboratoire de Neurosciences Fonctionnelles, Centre National de la Recherche Scienctifique, Marseille Cedex 9, France.

Abstract:
This article presents a tentative theoretical framework for the study of asymmetry in the context of human bimanual action. It is emphasized that in man most skilled manual activities involve two hands playing different roles, a fact that has been often overlooked in the experimental study of human manual lateralization. As an alternative to the current concepts of manual preference and manual superiority-whose relevance is limited to the particular case of unimanual actions-the more general concept of lateral preference is proposed to denote preference for one of the two possible ways of assigning two roles to two hands. A simple model describing man's favored intermanual division of labor in the model are the following. 1) The two hands represent two motors, that is, decomplexity is ignored in the suggested approach. 2) In man, the two manual motors cooperate with one another as if they were assembled in series, thereby forming a kinematic chain: In a right-hander allowed to follow his or her lateral preferences, motion produced by the right hand tends to articulate with motion produced by the left. It is suggested that the kinematic chain model may help in understanding the adaptive advantage of human manual specialization.

Related Concept Videos
 02:15
The Contractile Ring
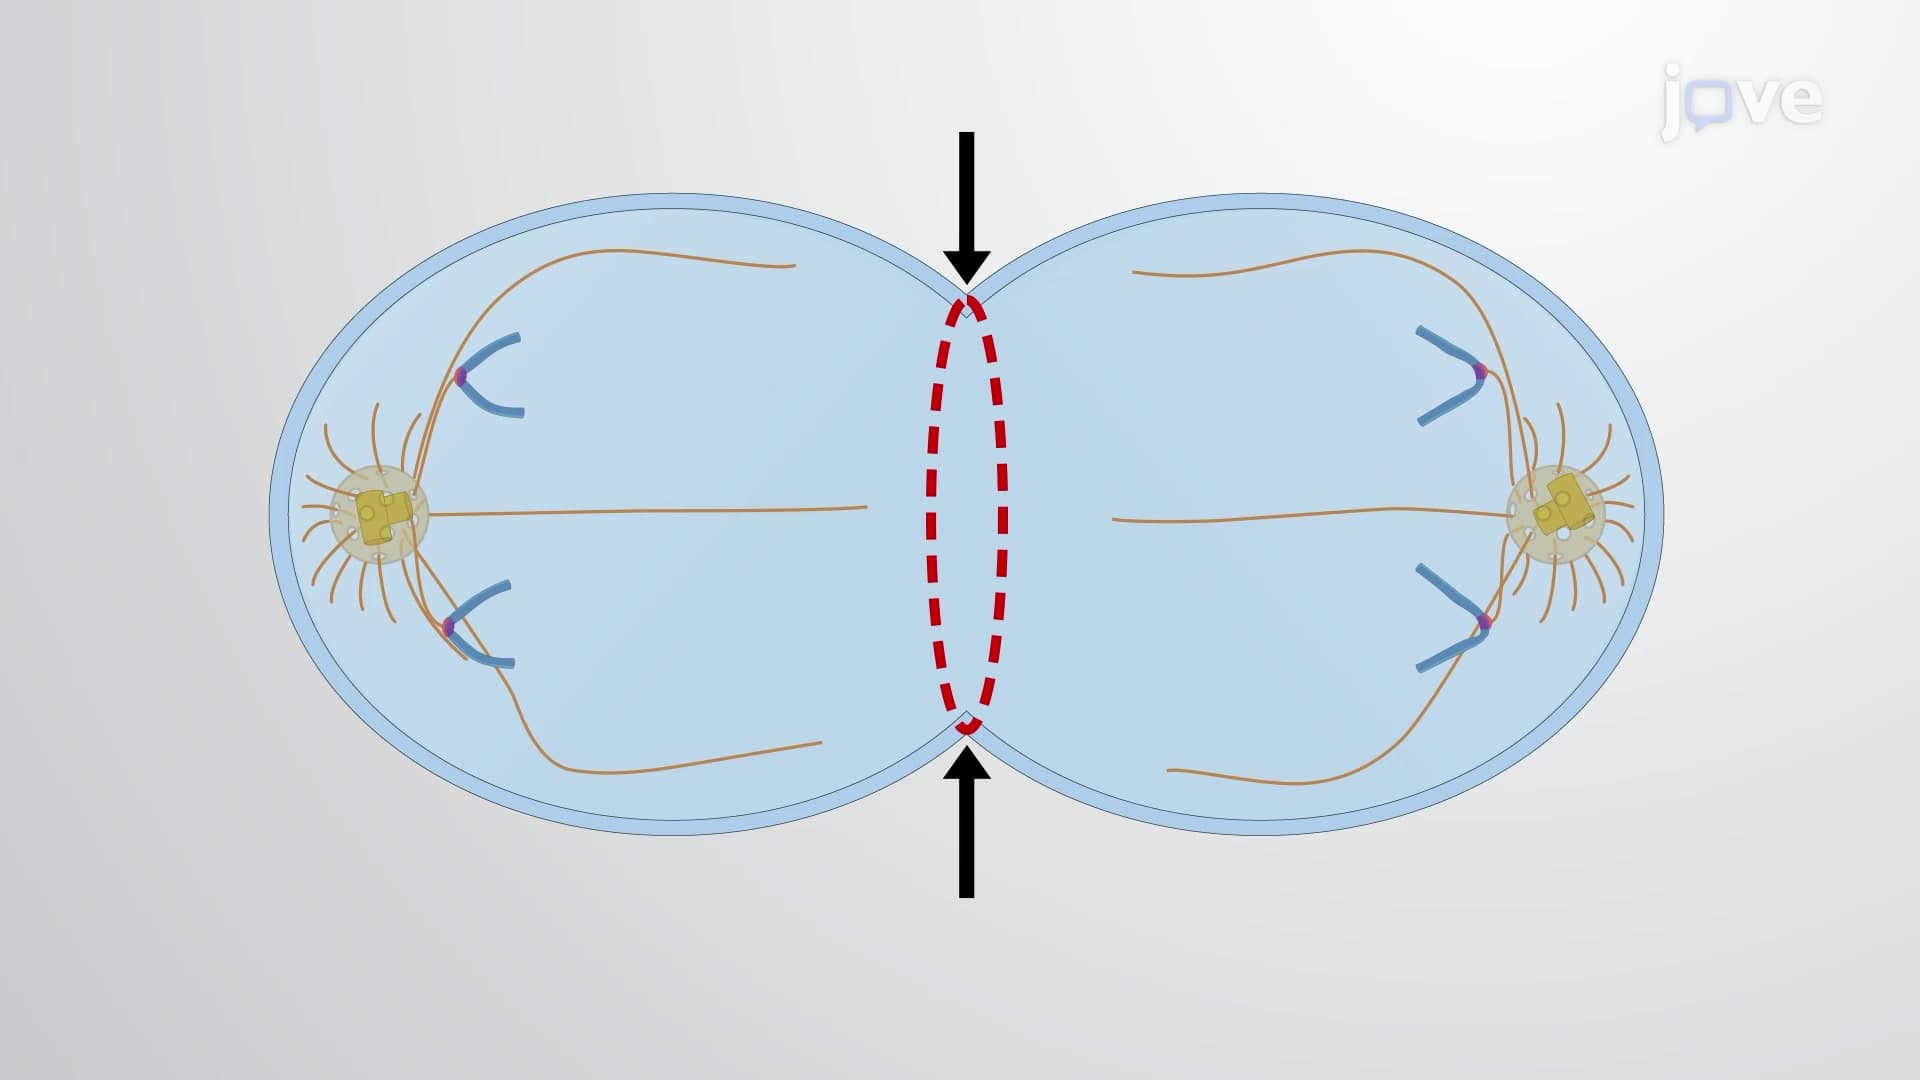
A small GTPase, RhoA, controls the function and assembly of the contractile ring. RhoA belongs to the Ras superfamily of proteins. The activation of formins by RhoA promotes...
02:15The Contractile Ring
A small GTPase, RhoA, controls the function and assembly of the contractile ring. RhoA belongs to the Ras superfamily of proteins. The activation of formins by RhoA promotes...
 01:10
Relative Motion Analysis - Acceleration
 01:30
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
 01:22
Machines: Problem Solving I
The toggle clamp system is a machine structure consisting of movable, pin-connected multi-force members that form a stabilized system to transmit forces. The...
 01:24
Relative Motion Analysis - Velocity
When an external force is exerted, it sets the crank into a rotational movement. This, in turn, instigates the motion of the connecting rod, leading to what is referred to as a general plane motion. This process involves two key points - point A on the connecting rod...