Related Experiment Video
Updated: Aug 24, 2026
Methods to Explore the Influence of Top-down Visual Processes on Motor Behavior
Published on: April 16, 2014
Once more on the equilibrium-point hypothesis (lambda model) for motor control
1Institute of Problems of Information Transmission, Academy of Sciences, Moscow.

Abstract:
The equilibrium control hypothesis (lambda model) is considered with special reference to the following concepts: (a) the length-force invariant characteristic (IC) of the muscle together with central and reflex systems subserving its activity; (b) the tonic stretch reflex threshold (lambda) as an independent measure of central commands descending to alpha and gamma motoneurons; (c) the equilibrium point, defined in terms of lambda, IC and static load characteristics, which is associated with the notion that posture and movement are controlled by a single mechanism; and (d) the muscle activation area (a reformulation of the "size principle")--the area of kinematic and command variables in which a rank-ordered recruitment of motor units takes place. The model is used for the interpretation of various motor phenomena, particularly electromyographic patterns. The stretch reflex in the lambda model has no mechanism to follow-up a certain muscle length prescribed by central commands. Rather, its task is to bring the system to an equilibrium, load-dependent position. Another currently popular version defines the equilibrium point concept in terms of alpha motoneuron activity alone (the alpha model). Although the model imitates (as does the lambda model) spring-like properties of motor performance, it nevertheless is inconsistent with a substantial data base on intact motor control. An analysis of alpha models, including their treatment of motor performance in deafferented animals, reveals that they suffer from grave shortcomings. It is concluded that parameterization of the stretch reflex is a basis for intact motor control. Muscle deafferentation impairs this graceful mechanism though it does not remove the possibility of movement.

Related Concept Videos
 01:04
Oscillations about an Equilibrium Position
 01:13
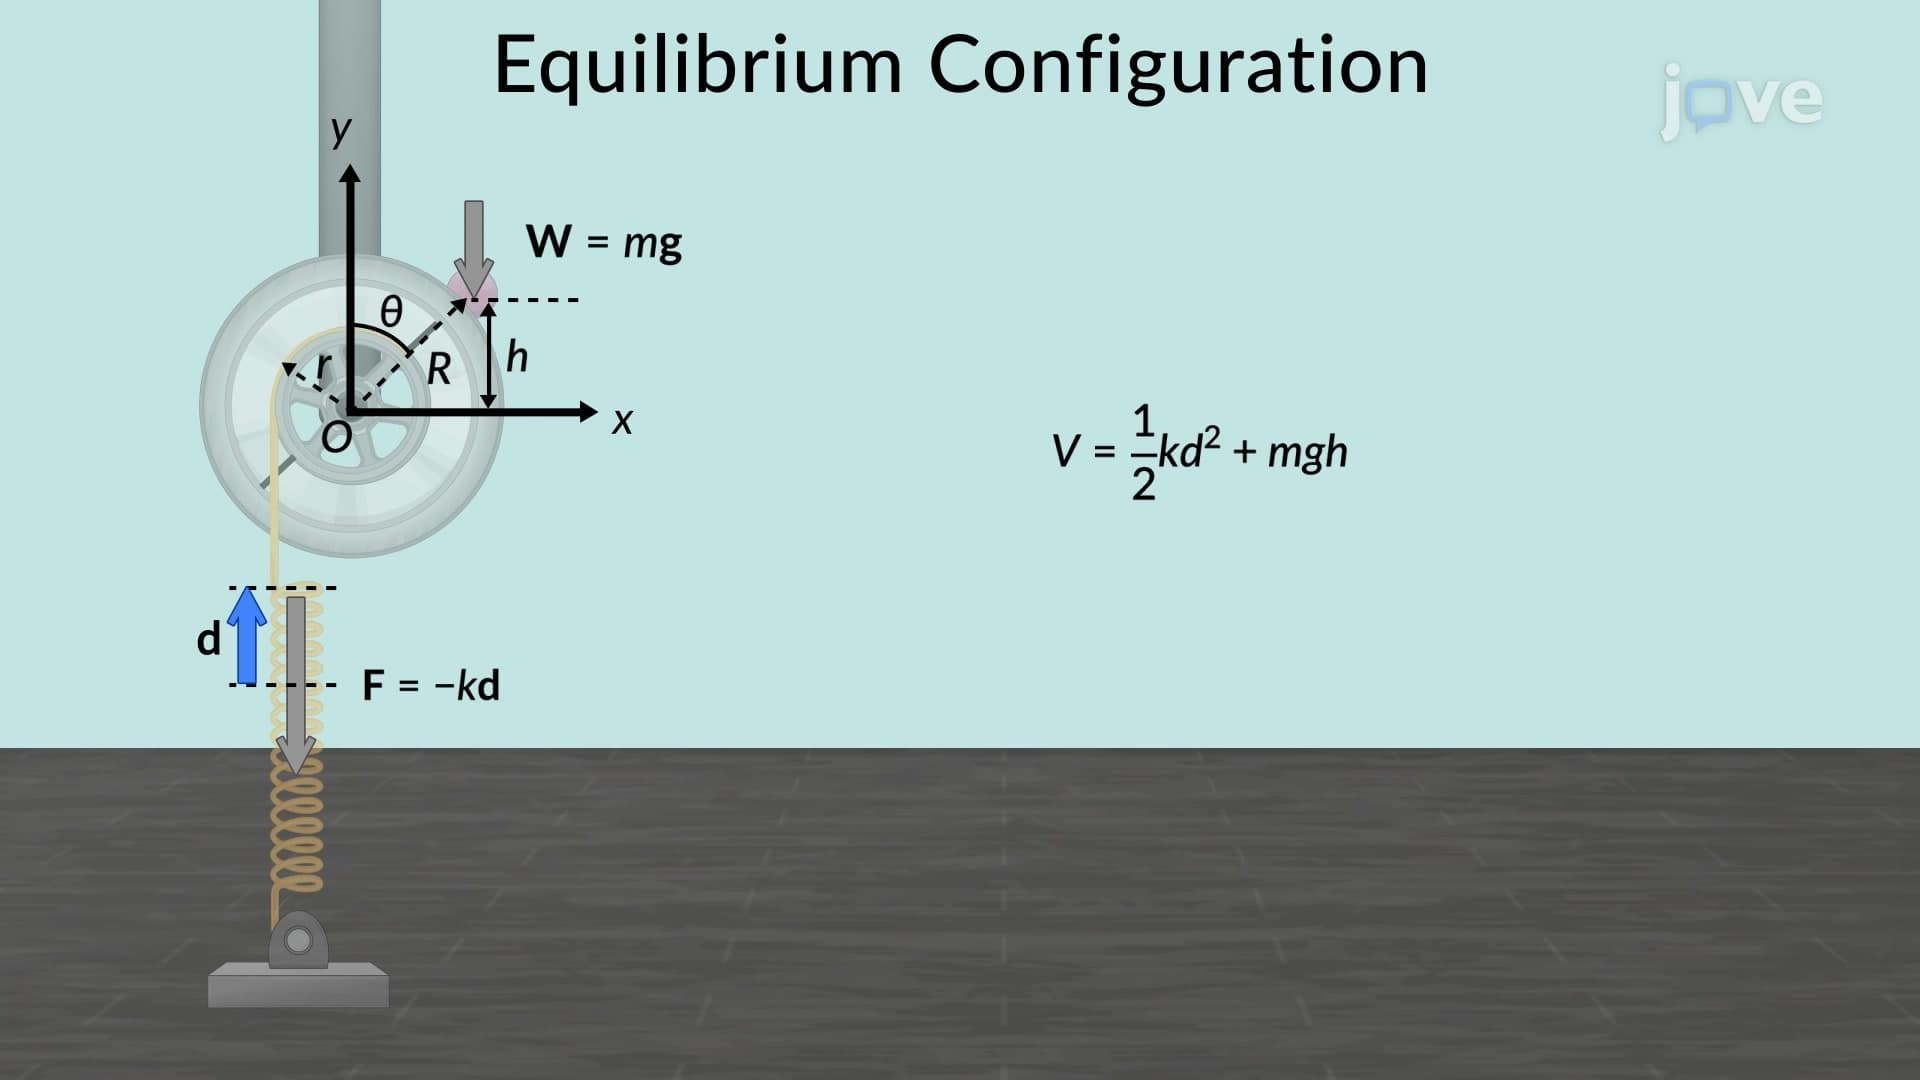
Stability of Equilibrium Configuration: Problem Solving
Problem-solving in the context of the stability of equilibrium configuration...
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length, the...
 01:23
Stability of Equilibrium Configuration
A stable equilibrium occurs when a system tends to return to its original position when given a small displacement, and the potential energy is at its minimum. An example of a stable equilibrium is when a cantilever beam is fixed at one end and a weight is attached to the other end. If the weight...
 00:49
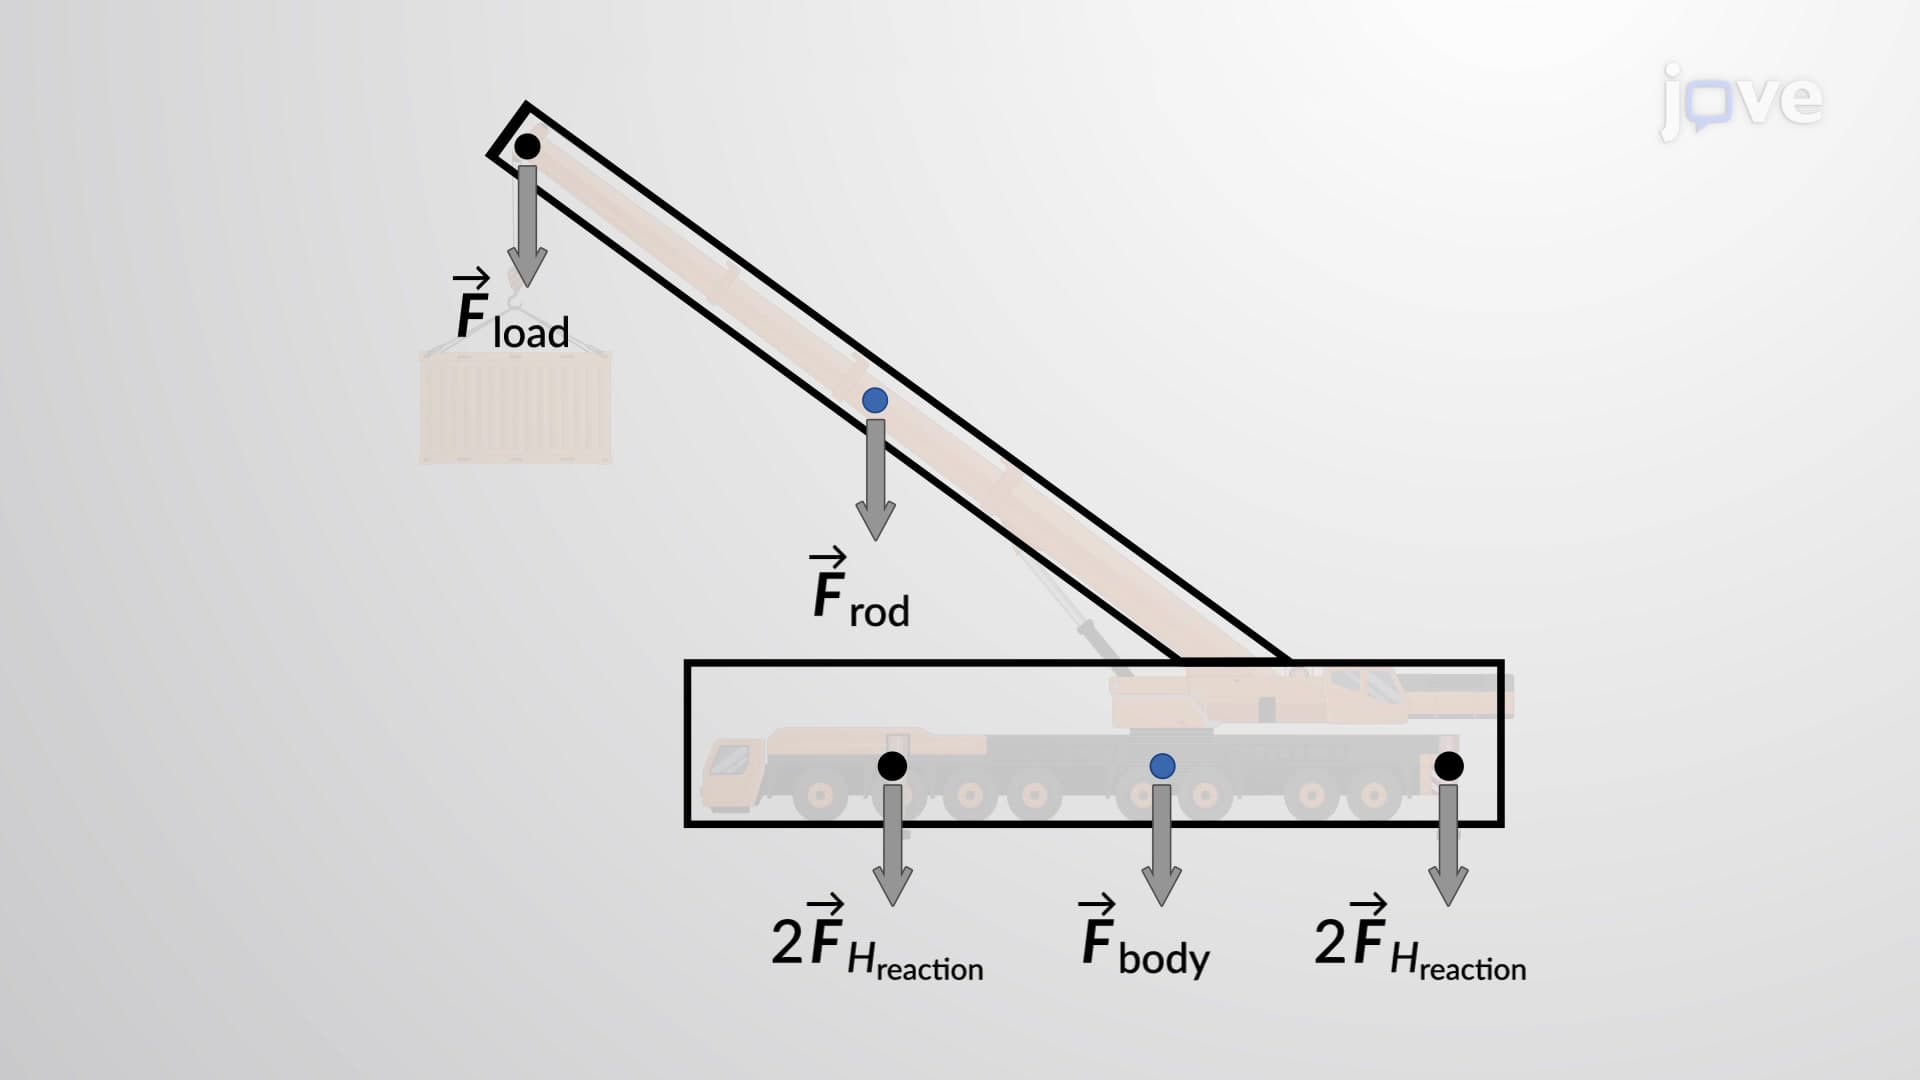
Rigid Body Equilibrium Problems - I
 01:21
Rigid Body Equilibrium Problems - II
Consider two children sitting on a seesaw, which has negligible mass. The first child has a mass (m1) of 26 kg and sits at point A, which is 1.6 meters (r1) from the pivot point B; the second child has a mass (m2) of 32 kg and sits at point C. How far from the pivot point B should the second child sit (r2) to balance the seesaw?