Related Experiment Video
Updated: Aug 24, 2026

Modeling and Experimental Analysis of the Single-Shaft Coaxial Motor-Pump Assembly in Electrohydrostatic Actuators
Published on: June 13, 2022
Force transfer model and characteristics of hybrid transducer type ultrasonic motors
Jifeng Guo1, Shujuan Gong, Haixun Guo
1College of Electrical Engineering, Zhejiang University, Yuquan, Hangzhou, China. gsj11@eyou.com

Abstract:
The characteristics of longitudinal-torsional hybrid transducer-type ultrasonic motors (HTUSM) are low speed and high torque. The discontinuous-surface-contact mode between the stator and the rotor is different from the many-point-contact mode of traveling wave motors, which is also an essential cause for high torque. Therefore, it is important to analyze its force transfer model between the rotor and the stator. In this paper, issues of using the method of equivalent circuit model are addressed. The relationships between the contact angle, preload, and physical parameters of frictional materials are given, according to the impulse conservation law axially. The equations describing output torque, amplitudes of longitudinal and torsional vibration, and parameters of the rotor are derived according to the principle that the work done by the load is equal to that by the driving force in one vibrating cycle. All factors that influence the mechanical characteristics are analyzed, and accuracy and suitability of the force transfer model are verified by comparison with the prototype motor. The formula for transfer efficiency on the stator/rotor interface is given, and the low-efficiency of this type motor is explained. The wide-working frequency range property of this type motor is shown with experimental results. Based on this study, the parameters of the rotor and preload are determined. The maximum torque of the prototype motor is up to 13.2 nm, and no-load speed of this type of motor is 12.5 rpm.

Related Concept Videos
 01:24
Wind Turbine Machine Models
Induction machines interact through the rotating magnetic field generated by the stator and the rotor. The key parameter is slip, which is the difference between synchronous speed and rotor speed relative to synchronous speed. Slip is...
 01:19
Electro-mechanical Systems
A key component of the DC motor is the armature, a rotating circuit positioned within a magnetic field. As an electric current passes through the...
 01:22
Mechanical Systems
 01:25
Introduction to force
 01:17
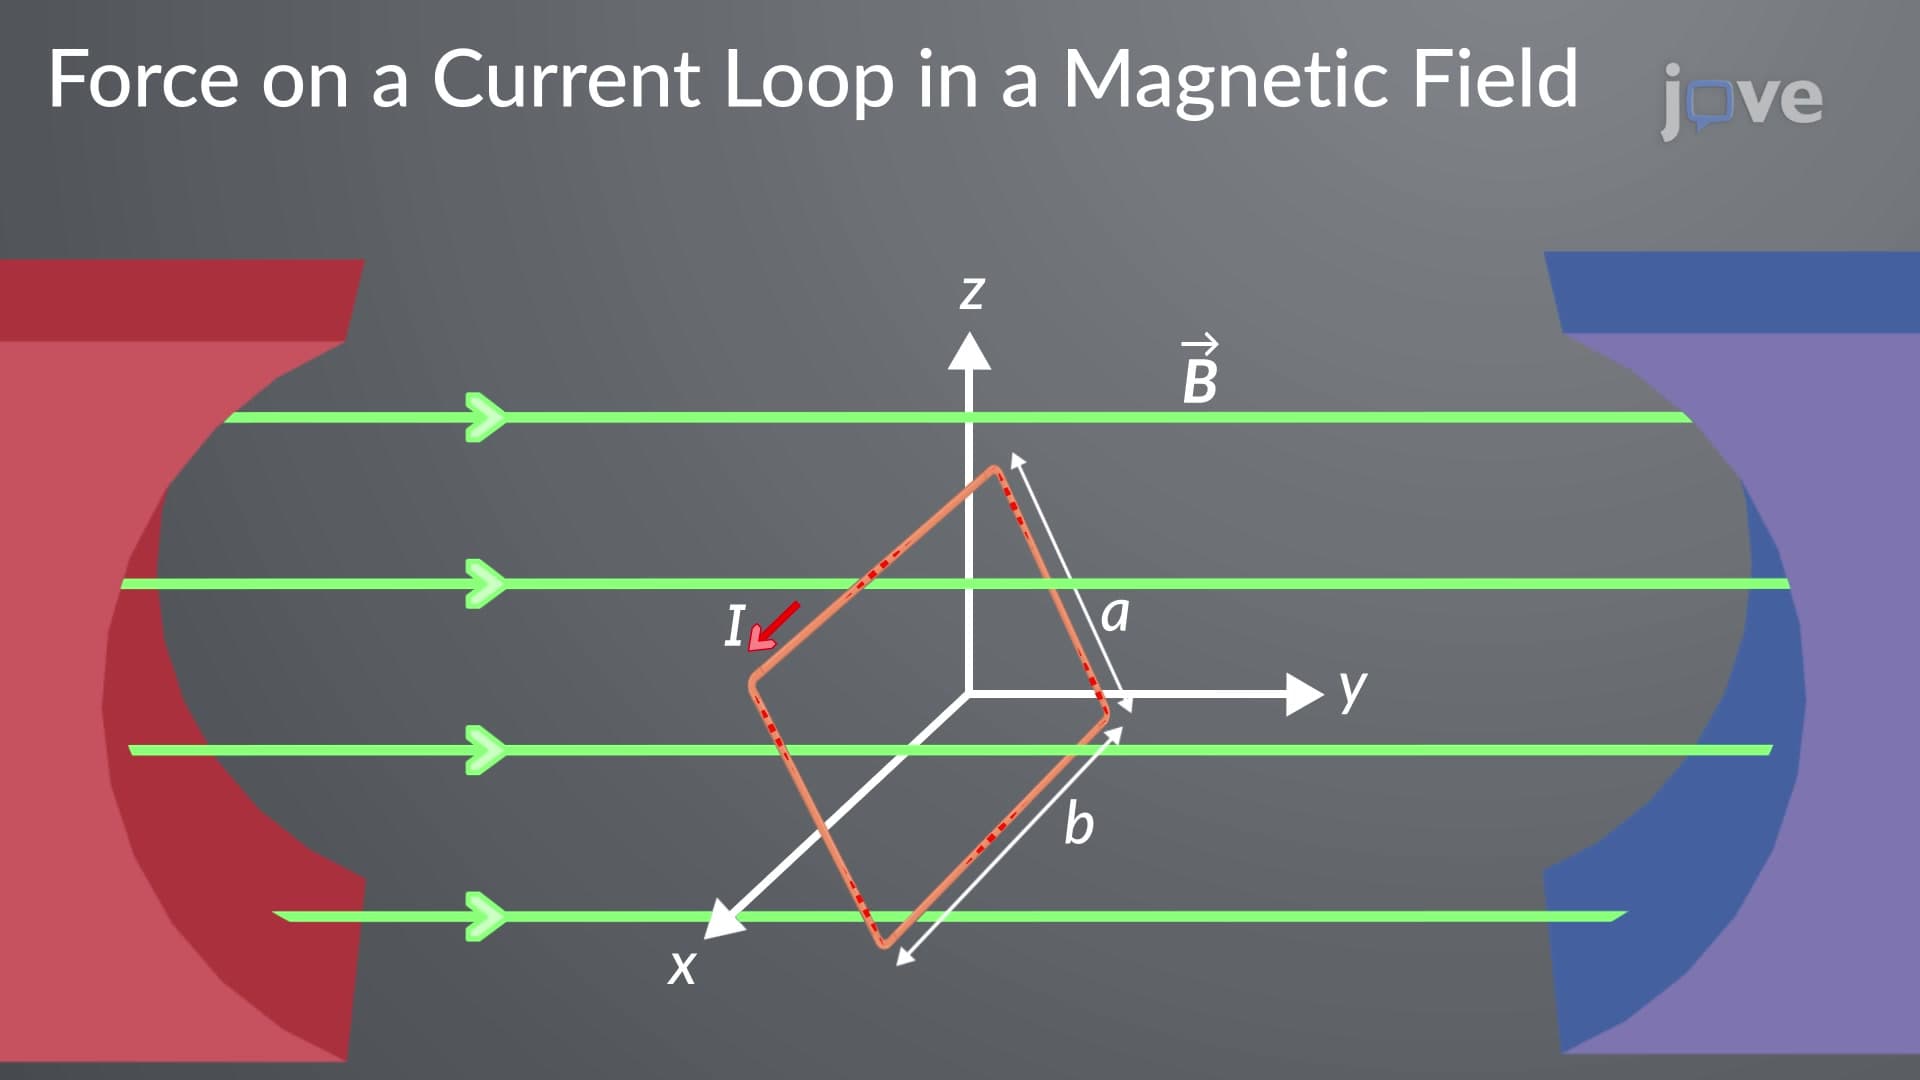
Force On A Current Loop In A Magnetic Field
 01:15
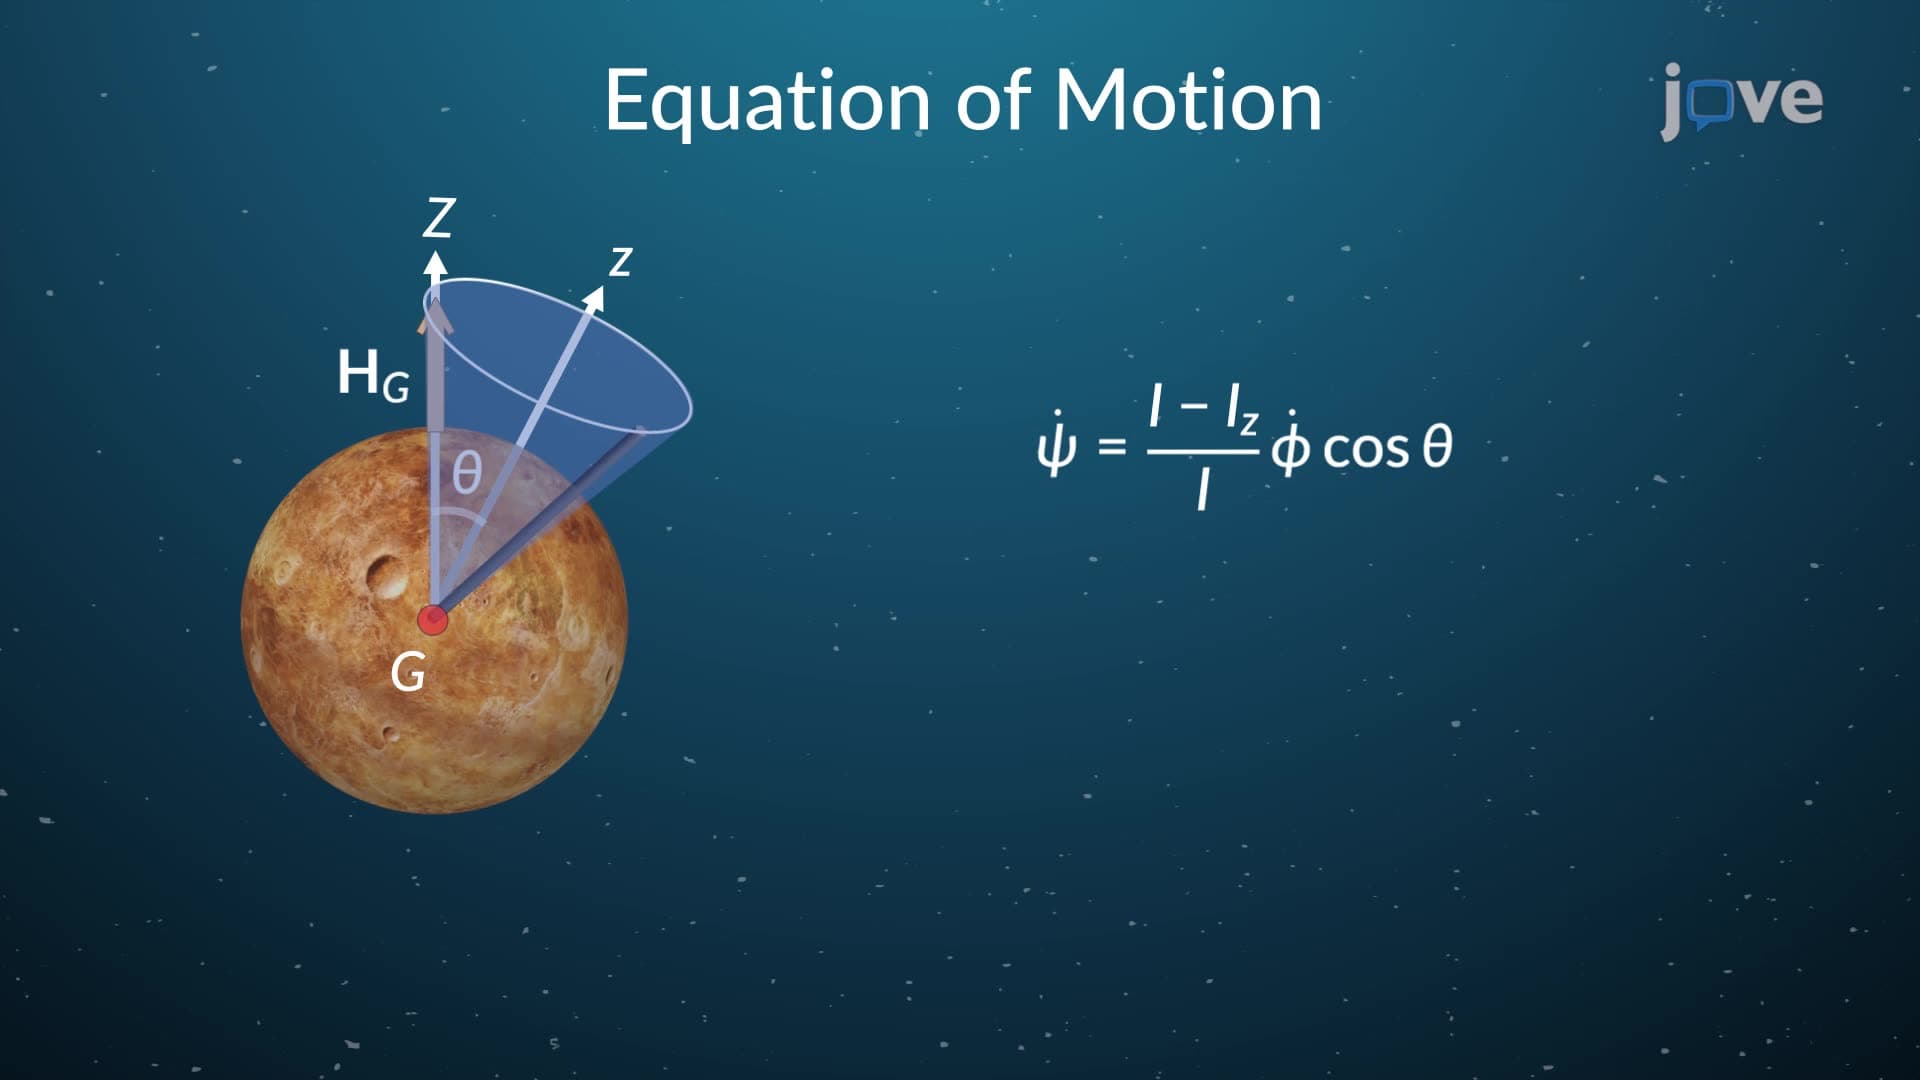
Torque Free Motion