Multiplicative nonlinearity in the perception of apparent motion
Related Experiment Video
Updated: Aug 24, 2026

MPI CyberMotion Simulator: Implementation of a Novel Motion Simulator to Investigate Multisensory Path Integration in Three Dimensions
Published on: May 10, 2012
1Department of Psychology, Vanderbilt University, Nashville, TN 37203, USA.

Abstract:
Evidence is reported indicating that the perception of apparent motion is better predicted by the multiplicative combination of luminance changes at two element locations than by the sum or squared-sum of the luminance changes, or by the motion energy in the stimulus. Because the results were obtained with a stimulus for which motion was specified by simultaneous luminance changes, they support a Reichardt-style motion detector model, but without the asymmetrical delay specified by current versions. Motion direction in the modified model relies on asymmetrical stimulus information rather than asymmetrical delay. That is, one subunit of the detector responds to changes in luminance toward the background luminance (the start of the motion path), and the other to changes in luminance away from the background luminance (the end of the motion path).
Related Concept Videos
 01:10
Relative Motion Analysis - Acceleration
 01:22
Relative Motion Analysis using Rotating Axes - Acceleration
Time differentiation is...
 01:15
Depth Perception and Spatial Vision
 01:23
Curvilinear Motion: Rectangular Components
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the time...
 01:24
Relative Motion Analysis - Velocity
When an external force is exerted, it sets the crank into a rotational movement. This, in turn, instigates the motion of the connecting rod, leading to what is referred to as a general plane motion. This process involves two key points - point A on the connecting rod...
 01:27
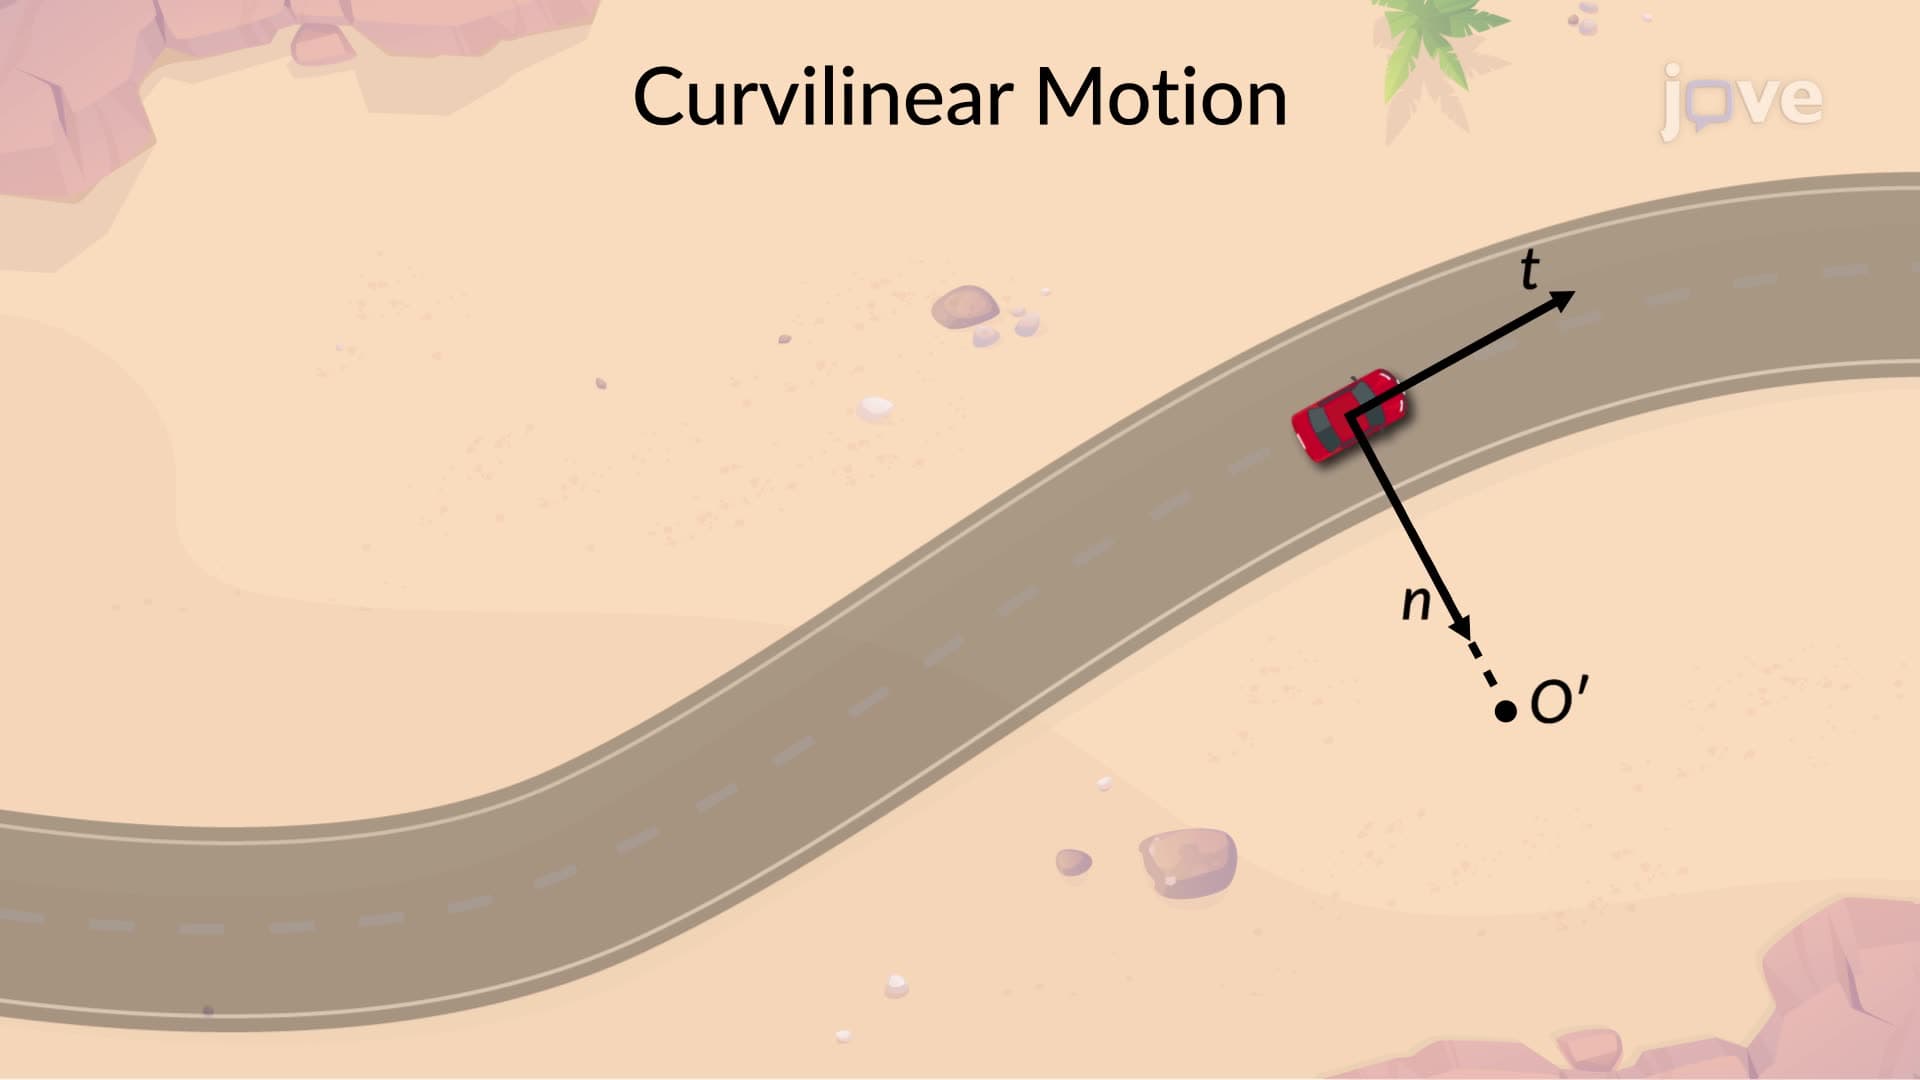
Curvilinear Motion: Normal and Tangential Components
The positive direction of the t-axis aligns with the increasing position of the car along the curved path, denoted by the unit vector ut. Simultaneously, the n-axis, perpendicular to the t-axis, dissects the curved path into differential arc segments, each forming the arc of a circle with a radius of...