Related Experiment Video
Updated: Aug 23, 2026
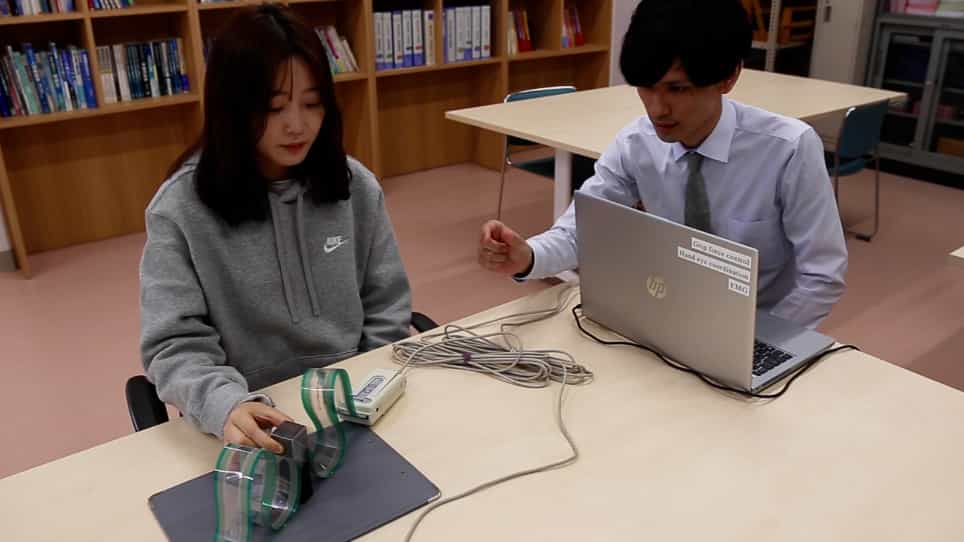

Measurement of Spatial Stability in Precision Grip
Published on: June 4, 2020
A comparison of the grip force distribution in natural hands and in prosthetic hands
Artem Kargov1, Christian Pylatiuk, Jan Martin
1Institute for Applied Computer Science (IAI), Forschungszentrum Karlsruhe GmbH, Eggenstein-Leopoldshafen, Germany. kargov@iai.fzk.de

Purpose:
The aim of this study is to analyse the grip force distribution for different prosthetic hand designs and the human hand fulfilling a functional task.
Method:
A cylindrical object is held with a power grasp and the contact forces are measured at 20 defined positions. The distributions of contact forces in standard electric prostheses, in a experimental prosthesis with an adaptive grasp, and in human hands as a reference are analysed and compared. Additionally, the joint torques are calculated and compared.
Results:
Contact forces of up to 24.7 N are applied by the middle and distal phalanges of the index finger, middle finger, and thumb of standard prosthetic hands, whereas forces of up to 3.8 N are measured for human hands. The maximum contact forces measured in a prosthetic hand with an adaptive grasp are 4.7 N. The joint torques of human hands and the adaptive prosthesis are comparable.
Conclusions:
The analysis of grip force distribution is proposed as an additional parameter to rate the performance of different prosthetic hand designs.

