Related Experiment Video
Updated: Aug 22, 2026

Investigating the Deployment of Visual Attention Before Accurate and Averaging Saccades via Eye Tracking and Assessment of Visual Sensitivity
Published on: March 18, 2019
Smooth pursuit tracking of an abrupt change in target direction: vector superposition of discrete responses
John F Soechting1, Leigh A Mrotek, Martha Flanders
1Department of Neuroscience, University of Minnesota, 6-145 Jackson Hall, 321 Church St. SE, Minneapolis, MN 55455, USA. soech001@umn.edu

Abstract:
The directional control of smooth pursuit eye movements was studied by presenting human subjects with targets that moved in a straight line at a constant speed and then changed direction abruptly and unpredictably. To minimize the probability of saccadic responses in the interval following the target's change in direction, target position was offset so as to eliminate position error after the reaction time. Smooth pursuit speed declined at a latency of 90 ms, whereas the direction of smooth pursuit began to change later (130 ms). The amplitude of the offset in target position did not affect the subsequent smooth pursuit response. In other experiments, the target's speed or acceleration was changed abruptly at the time of the change in direction. Step changes in speed elicited short-latency responses in smooth pursuit tracking but step changes in acceleration did not. In all instances, the earliest component of the response did not depend on the parameters of the stimulus. The data were fit with a model in which smooth pursuit resulted from the vector addition of two components, one representing a response to the arrest of the initial target motion and the other the response to the onset of target motion in the new direction. This model gave an excellent fit but further analysis revealed nonlinear interactions between the two vector components. These interactions represented directional anisotropies both in terms of the initial tracking direction (which was either vertical or 45 degrees ) and in terms of the cardinal directions (vertical and horizontal).
Insights
Smooth pursuit eye movements adjust speed within 90ms and direction at 130ms after target motion changes. This visual tracking response involves complex vector additions, revealing directional anisotropies.
Area of Science:
- Neuroscience
- Ophthalmology
- Human Motor Control
Background:
- Smooth pursuit eye movements are crucial for maintaining clear vision of moving objects.
- Understanding the precise neural mechanisms controlling smooth pursuit direction and speed is vital for diagnosing and treating visual disorders.
Purpose of the Study:
- To investigate the temporal dynamics and control mechanisms of smooth pursuit eye movements following abrupt changes in target direction.
- To analyze the influence of target motion parameters (speed, acceleration) on smooth pursuit responses.
- To model the vector components contributing to smooth pursuit initiation and adaptation.
Main Methods:
- Human subjects performed smooth pursuit eye movements tracking targets with unpredictable changes in direction.
- Target position was offset to minimize saccadic intrusions.
- Experiments manipulated target speed and acceleration changes at the point of directional shift.
- Data were analyzed using a vector addition model to represent pursuit responses.
Main Results:
- Smooth pursuit speed initiation occurred at 90 ms latency, while directional changes began at 130 ms.
- Target position offset amplitude did not influence the subsequent smooth pursuit.
- Step changes in target speed elicited short-latency smooth pursuit responses, unlike step changes in acceleration.
- A vector addition model accurately described smooth pursuit, but revealed nonlinear directional anisotropies.
Conclusions:
- Smooth pursuit eye movements involve distinct temporal components for speed and direction control.
- The initiation of smooth pursuit after directional changes is stimulus-invariant in its earliest phase.
- Nonlinear interactions and directional anisotropies influence the complex vector summation underlying smooth pursuit control.
Related Concept Videos
 01:30
Vector Functions and Motion: Problem Solving
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the drone...
 01:24
Relative Motion Analysis - Velocity
When an external force is exerted, it sets the crank into a rotational movement. This, in turn, instigates the motion of the connecting rod, leading to what is referred to as a general plane motion. This process involves two key points - point A on the connecting rod...
 01:10
Relative Motion Analysis - Acceleration
 01:12
Average and Instantaneous Velocity Vectors
 01:10
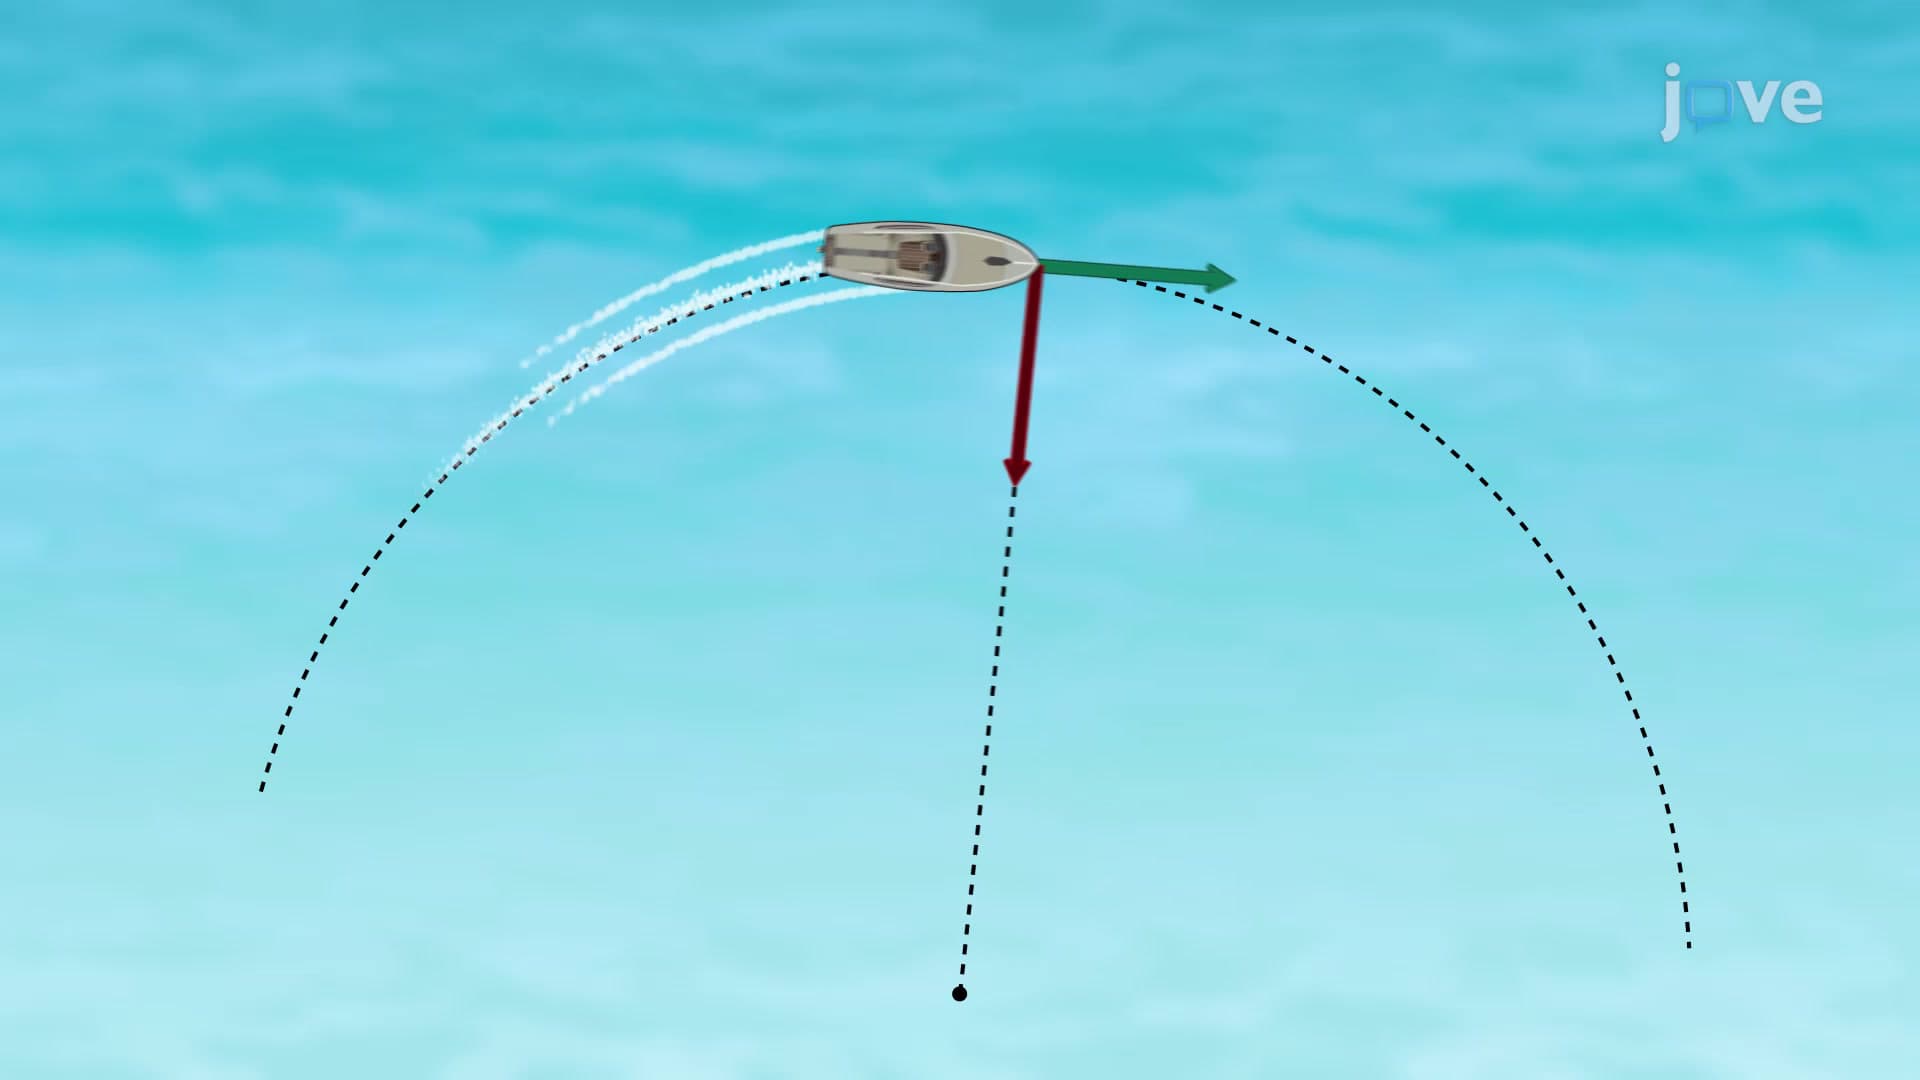
Direction of Acceleration Vectors