Altered inertial response of generic degrees of freedom

Simone Melchionna1

  • 1Dipartimento di Fisica and INFM, Universita "La Sapienza," P. le A. Moro 5, 00185 Rome, Italy.

Related Concept Videos

One-Degree-of-Freedom System01:24

One-Degree-of-Freedom System

In mechanical engineering, one-degree-of-freedom systems form the basis of a wide range of electrical and mechanical components. Using these models, engineers can predict the behavior of various parts in a larger system, which gives them insight into how different forces interact with each other.
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
Inertial Frames of Reference01:03

Inertial Frames of Reference

Newton’s first law is usually considered to be a statement about reference frames. It provides a method for identifying a special type of reference frame: the inertial reference frame. In principle, we can make the net force on a body zero. If its velocity relative to a given frame is constant, then that frame is said to be inertial. So, by definition, an inertial reference frame is a reference frame where Newton's first law holds valid. Newton's first law applies to objects with constant...
Equation of Motion for a Rigid Body01:12

Equation of Motion for a Rigid Body

The movement of a rigid object can be understood through the equations that explain both translational and rotational motion about the center of mass of the object, point G. This center of mass is the point where the equation of motion for translational motion comes into play, as per Newton's Second Law.
The combined moments generated about the center of mass of the object are equal to the rate of change of the angular momentum of the body. An external force, when applied at a different point...
Relative Motion Analysis - Acceleration01:10

Relative Motion Analysis - Acceleration
A slider-crank mechanism converts rotational motion from the crank into linear motion of the slider or vice versa. This mechanism consists of three main parts: the crank, the connecting rod, and the slider. The movement of the slider-crank is an example of general plane motion as the fluctuating angle between the crank and the connecting rod. Consider a segment AB where point A is at the end of the slider and point B is on the diametrically opposite end to point A, on a crack. The variance in...
Angular Momentum and Principle Axes of Inertia01:09

Angular Momentum and Principle Axes of Inertia

The concept of angular momentum for a solid structure is illustrated as the cumulative result of the cross-product of the position vector of the mass element and the cross-product of the body's angular velocity with the position vector.
To put this equation into simpler terms, it can be reconfigured using rectangular coordinates. This involves choosing an alternative set of XYZ axes that are arbitrarily inclined with respect to the reference frame. The process of deriving the rectangular...
Non-inertial Frames of Reference01:27

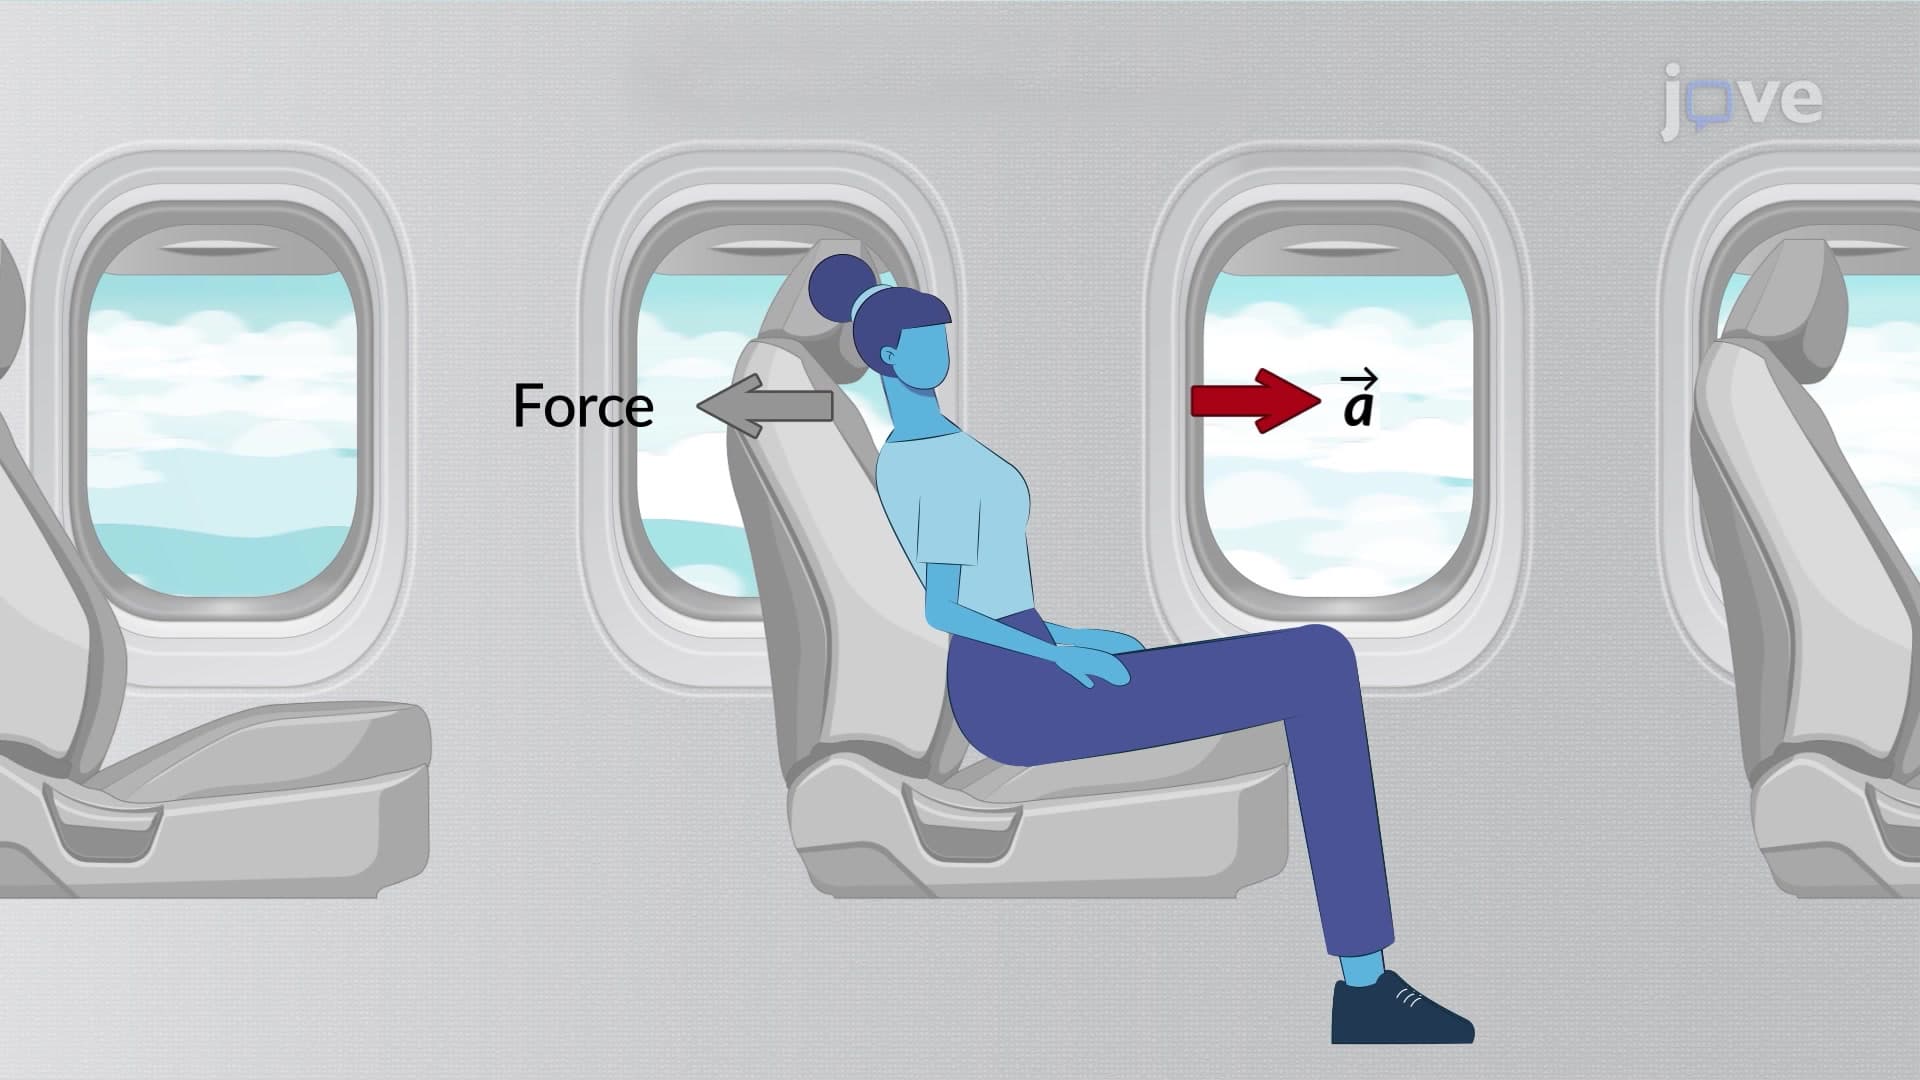
Non-inertial Frames of Reference

A reference frame accelerating or decelerating relative to an inertial frame is a non-inertial frame. To help understand this, consider what taking off in an airplane, turning a corner in a car, riding a merry-go-round, and the circular motion of a tropical cyclone all have in common. All these systems are accelerating, decelerating, or rotating relative to the Earth; hence, they all are non-inertial frames. All these systems exhibit inertial forces, which merely seem to arise from motion,...