Related Experiment Video
Updated: Aug 22, 2026
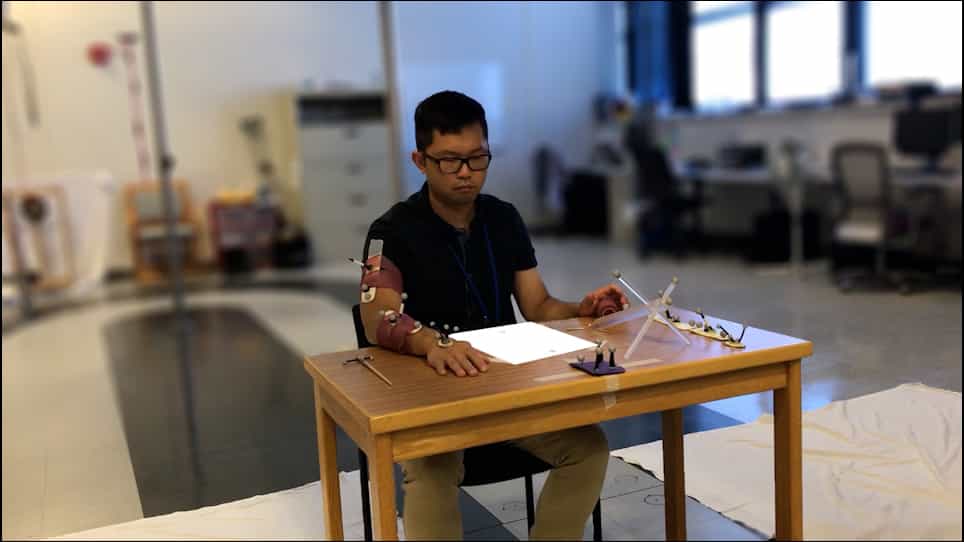

The Impact of Motor Task Conditions on Goal-Directed Arm Reaching Kinematics and Trunk Compensation in Chronic Stroke Survivors
Published on: May 2, 2021
Kinematic and kinetic constraints on arm, trunk, and leg segments in target-reaching movements
James S Thomas1, Daniel M Corcos, Ziaul Hasan
1Ohio University, School of Physical Therapy, W277 Grover Center, Athens, OH 45701, USA. thomasj5@ohiou.edu

Abstract:
We studied target reaching tasks involving not only the arms but also the trunk and legs, which necessitated some trunk flexion. Such tasks can be successfully completed using an infinite number of combinations of segment motions due to the inherent kinematic redundancy with the excessive degrees of freedom (DOFs). Sagittal plane motions of six segments (shank, thigh, pelvis, trunk, humerus, and forearm) and dynamic torques of six joints (ankle, knee, hip, lumbar, shoulder, and elbow) were analyzed separately by principal component (PC) analyses to determine if there was a commonality among the shapes of the respective waveforms. Additionally, PC analyses were used to probe for constraining relationships among the 1) relative magnitudes of segment excursions and 2) the peak-to-peak dynamic joint torques. In summary, at the kinematic level, the tasks are simplified by the use of a single common waveform for all segment excursions with 89.9% variance accounted for (VAF), but with less fixed relationships among the relative scaling of the magnitude of segment excursions (62.2% VAF). However, at the kinetic level, the time course of the dynamic joint torques are not well captured by a single waveform (72.7% VAF), but the tasks are simplified by relatively fixed relationships among the scaling of dynamic joint torque magnitudes across task conditions (94.7% VAF). Taken together, these results indicate that, while the effective DOFs in a multi-joint task are reduced differently at the kinematic and kinetic levels, they both contribute to simplifying the neural control of these tasks.

Related Concept Videos
 01:15
Kinematic Equations: Problem Solving
 01:18
Kinematic Equations - III
Using the kinematic equations,...
 01:17
Kinematic Equations - II
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
 01:26
Kinematic Equations - I
 01:30
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
 01:31
Muscles that Move the Arm
The pectoralis major has two origins. Its clavicular head originates on the medial half of the clavicle. In contrast, the sternocostal head originates on the costal cartilages of ribs 1-6, the sternum, and the aponeurosis of the external oblique of the...