Related Experiment Video
Updated: Aug 22, 2026

Quantifying Learning in Young Infants: Tracking Leg Actions During a Discovery-learning Task
Published on: June 1, 2015
Development of pendulum mechanism and kinematic coordination from the first unsupported steps in toddlers
Yuri P Ivanenko1, Nadia Dominici, Germana Cappellini
1Department of Neuromotor Physiology, IRCCS Fondazione Santa Lucia, via Ardeatina 306, 00179 Rome, Italy.

Insights
The inverted pendulum mechanism in walking is learned, not innate. Toddlers show immature pendulum behavior, which rapidly develops with walking experience, indicating a need for neural control.
Area of Science:
- Biomechanical analysis of human locomotion
- Developmental motor control
- Pediatric gait analysis
Background:
- Bipedal walking utilizes an inverted pendulum mechanism where the body's center of mass vaults over the stance leg.
- The innate versus learned nature of this fundamental walking mechanism remains unclear.
Purpose of the Study:
- To investigate whether the inverted pendulum mechanism is an innate ability or acquired through walking experience.
- To quantify the development of the pendulum mechanism from infancy to adulthood.
Main Methods:
- Kinematic analysis of the greater trochanter in toddlers, older children, and adults.
- Calculation of the correlation between kinetic and potential energy of the center of mass using force plate data.
- Measurement of mechanical energy recovery percentage during walking.
Main Results:
- Toddlers (around 1 year old) exhibited significantly different pendulum mechanism parameters compared to older children and adults.
- Mechanical energy recovery was substantially lower (approx. 50%) in toddlers compared to adults.
- Pendulum-like behavior and lower limb coordination rapidly matured within months of achieving independent walking.
Conclusions:
- The inverted pendulum mechanism is not present at the onset of unsupported locomotion but is acquired through walking experience.
- Independent walking experience serves as a critical trigger for developmental changes in gait.
- Mature pendulum behavior requires active neural control and coordinated inter-segmental movement patterns, rather than being a passive mechanical outcome.
Abstract:
The inverted pendulum model in which the centre of mass of the body vaults over the stance leg in an arc represents a basic mechanism of bipedal walking. Is the pendulum mechanism innate, or is it learnt through walking experience? We studied eight toddlers (about 1 year old) at their first unsupported steps, 18 older children (1.3-13 years old), and ten adults. Two infants were also tested repeatedly over a period of 4 months before the onset of independent walking. Pendulum mechanism was quantified from the kinematics of the greater trochanter, correlation between kinetic and gravitational potential energy of the centre of body mass obtained from the force plate recordings, and percentage of recovery of mechanical energy. In toddlers, these parameters deviated significantly (P<10(-5)) from those of older children and adults, indicating that the pendulum mechanism is not implemented at the onset of unsupported locomotion. Normalising the speed with the Froude number showed that the percentage of recovery of mechanical energy in children older than 2 years was roughly similar to that of the adults (less than 5% difference), in agreement with previous results. By contrast, the percentage of recovery in toddlers was much lower (by about 50%). Pendulum-like behaviour and fixed coupling of the angular motion of the lower limb segments rapidly co-evolved toward mature values within a few months of independent walking experience. Independent walking experience acts as a functional trigger of the developmental changes, as shown by the observation that gait parameters remained unchanged until the age of the first unsupported steps, and then rapidly matured after that age. The findings suggest that the pendulum mechanism is not an inevitable mechanical consequence of a system of linked segments, but requires active neural control and an appropriate pattern of inter-segmental coordination.
Related Concept Videos
 01:06
Physical Pendulum
When dealing with complicated systems, the mass moment of inertia is an important parameter, as it describes the mass...
 01:10
Simple Pendulum
The period of a simple pendulum depends on two factors: its length and the acceleration due to gravity. The period is completely independent of any other factors, such as mass or maximum displacement. For small displacements, a pendulum is...
 01:09
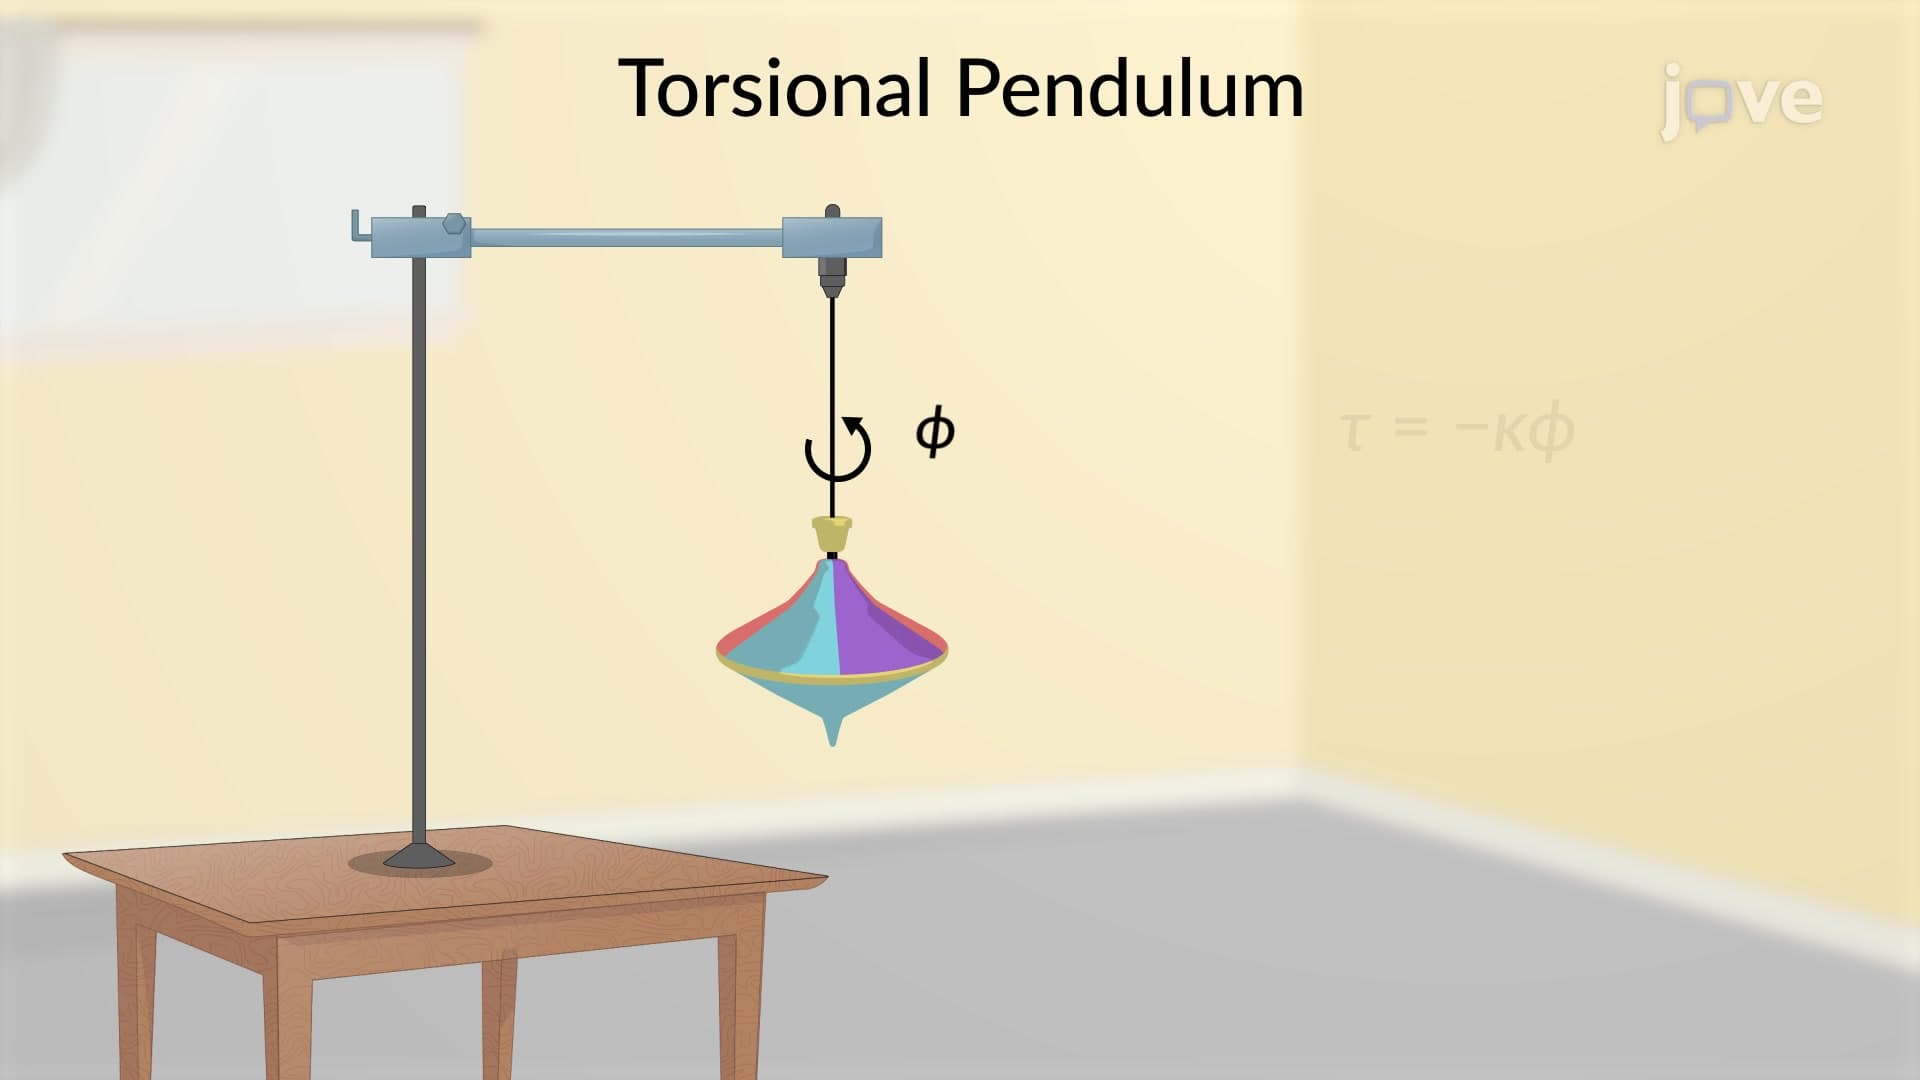
Torsional Pendulum
As long as the rigid body's angular displacement is small, its oscillation can be modeled as a linear angular oscillation. The amplitude of the oscillation is an angle. The role of mass is played by the...
 01:14
Piaget's Stage 1 of Cognitive Development
Exploration...
 01:09
Changes in the Appendicular Skeleton with Age
Initially, the limb buds consist of a core of mesenchyme covered by a layer of ectoderm. The ectoderm at the end of the limb bud thickens to form a narrow crest called the apical ectodermal ridge. This ridge stimulates the underlying...
 01:06
Forced Oscillations