A fast impulsive contact suite for rigid body simulation
Related Experiment Video
Updated: Aug 22, 2026

Subject-specific Musculoskeletal Model for Studying Bone Strain During Dynamic Motion
Published on: April 11, 2018
Harald Schmidl1, Victor J Milenkovic
1Department of Mathematics and Computer Science, North Carolina Central University, Robinson Science Bldg, Durham, NC 27707, USA. hschmidl@wpo.nccu.edu

Abstract:
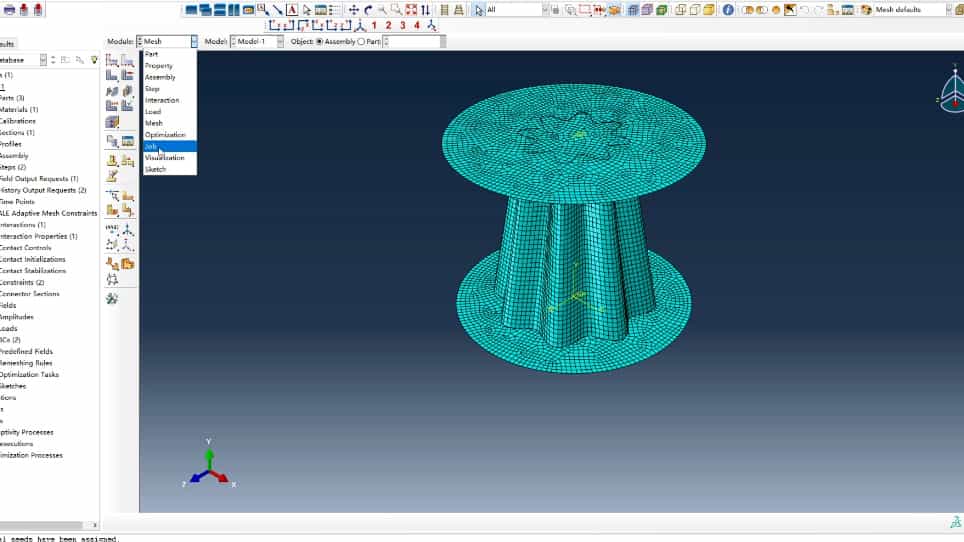
A suite of algorithms is presented for contact resolution in rigid body simulation under the Coulomb friction model: Given a set of rigid bodies with many contacts among them, resolve dynamic contacts (collisions) and static (persistent) contacts. The suite consists of four algorithms: 1) partial sequential collision resolution, 2) final resolution of collisions through the solution of a single convex QP (positive semidefinite quadratic program), 3) resolution of static contacts through the solution of a single convex QP, 4) freezing of "stationary" bodies. This suite can generate realistic-looking results for simple examples yet, for the first time, can also tractably resolve contacts for a simulation as large as 1,000 cubes in an "hourglass." Freezing speeds up this simulation by more than 25 times. Thanks to excellent commercial QP technology, the contact resolution suite is simple to implement and can be "plugged into" any simulation algorithm to provide fast and realistic-looking animations of rigid bodies.
Related Concept Videos
 01:06
Virtual Work for a System of Connected Rigid Bodies
Next,...
 01:13
Kinetic Energy for a Rigid Body
 01:22
Planar Rigid-Body Motion
Planar motion is typically divided into three distinct categories. The first is rectilinear translation, demonstrated by a subway train that moves along...
 01:30
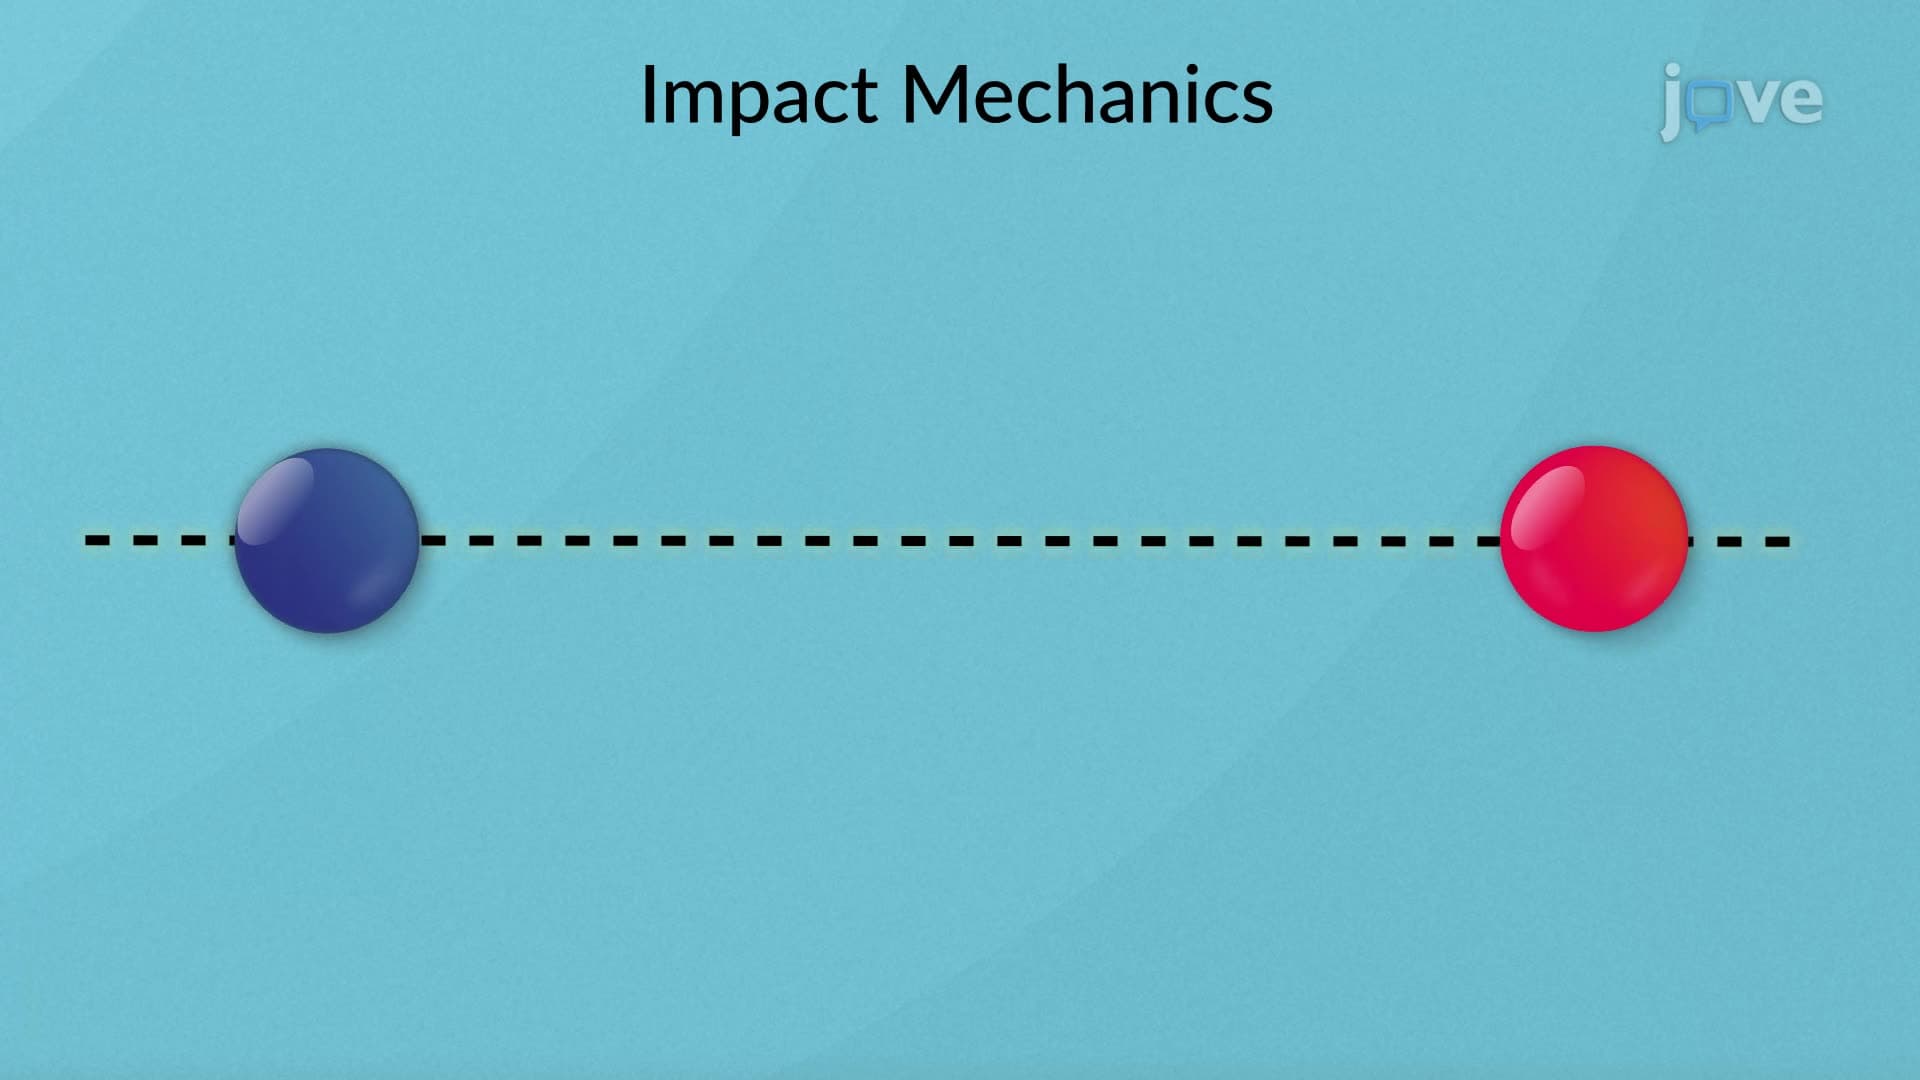
Impact
When particles with different initial velocities collide, they induce deformation by applying equal and opposite impulses. At the point of maximum deformation, the particles move together with...
 01:21
Rigid Body Equilibrium Problems - II
Consider two children sitting on a seesaw, which has negligible mass. The first child has a mass (m1) of 26 kg and sits at point A, which is 1.6 meters (r1) from the pivot point B; the second child has a mass (m2) of 32 kg and sits at point C. How far from the pivot point B should the second child sit (r2) to balance the seesaw?
 00:49
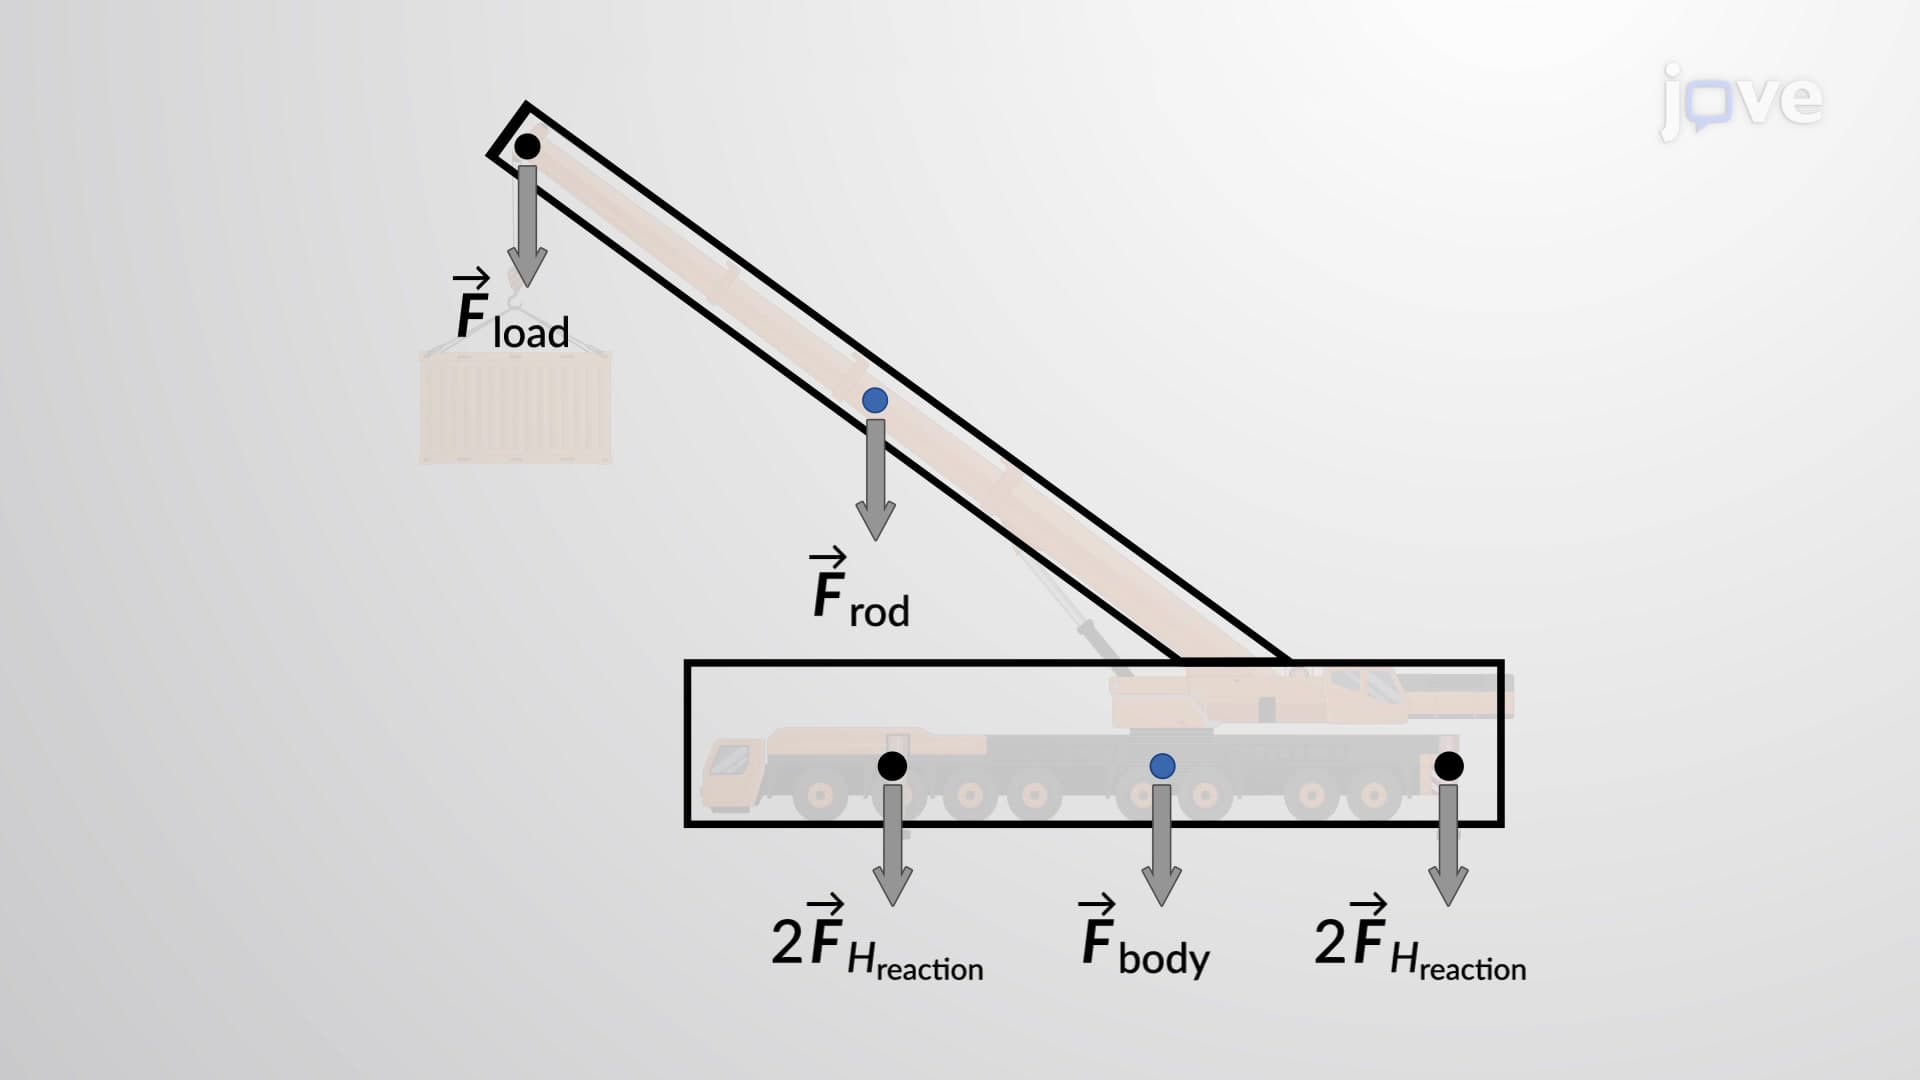
Rigid Body Equilibrium Problems - I