Related Experiment Video
Updated: Aug 22, 2026


An Inertial Measurement Unit Based Method to Estimate Hip and Knee Joint Kinematics in Team Sport Athletes on the Field
Published on: May 26, 2020
Sensitivity of the knee joint kinematics calculation to selection of flexion axes
1Orthopedic Bioengineering Laboratory, Massachusetts General Hospital, Harvard Medical School, 55 Fruit Street, GRJ 1215, Boston, MA 02114, USA.

Abstract:
Various flexion axes have been used in the literature to describe knee joint kinematics. This study measured the passive knee kinematics of six cadaveric human knee specimens using two widely accepted flexion axes; transepicondylar axis and the geometric center axis. These two axes were found to form an angle of 4.0 degrees +/- 0.8 degrees. The tibial rotation calculated using the transepicondylar axis was significantly different than the rotation obtained using the geometric center axis for the same knee motion. At 90 degrees of flexion, the tibial rotation obtained using the transepicondylar axis was 4.8 degrees +/- 9.4 degrees whereas the rotation recorded using the geometric center axis at the same flexion angle was 13.8 degrees +/- 10.2 degrees. At 150 degrees of knee flexion, the rotations obtained from the transepicondylar and the geometric center axes were 7.2 degrees +/- 5.7 degrees and 19.9 degrees +/- 6.9 degrees, respectively. The data suggest that a clear definition of the flexion axis is necessary when reporting knee joint kinematics.


Related Concept Videos
 01:30
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:23
Knee Joint
A total of seven ligaments support the knee joint. The patellar ligament, which is also attached to the quadriceps femoris group...
 01:15
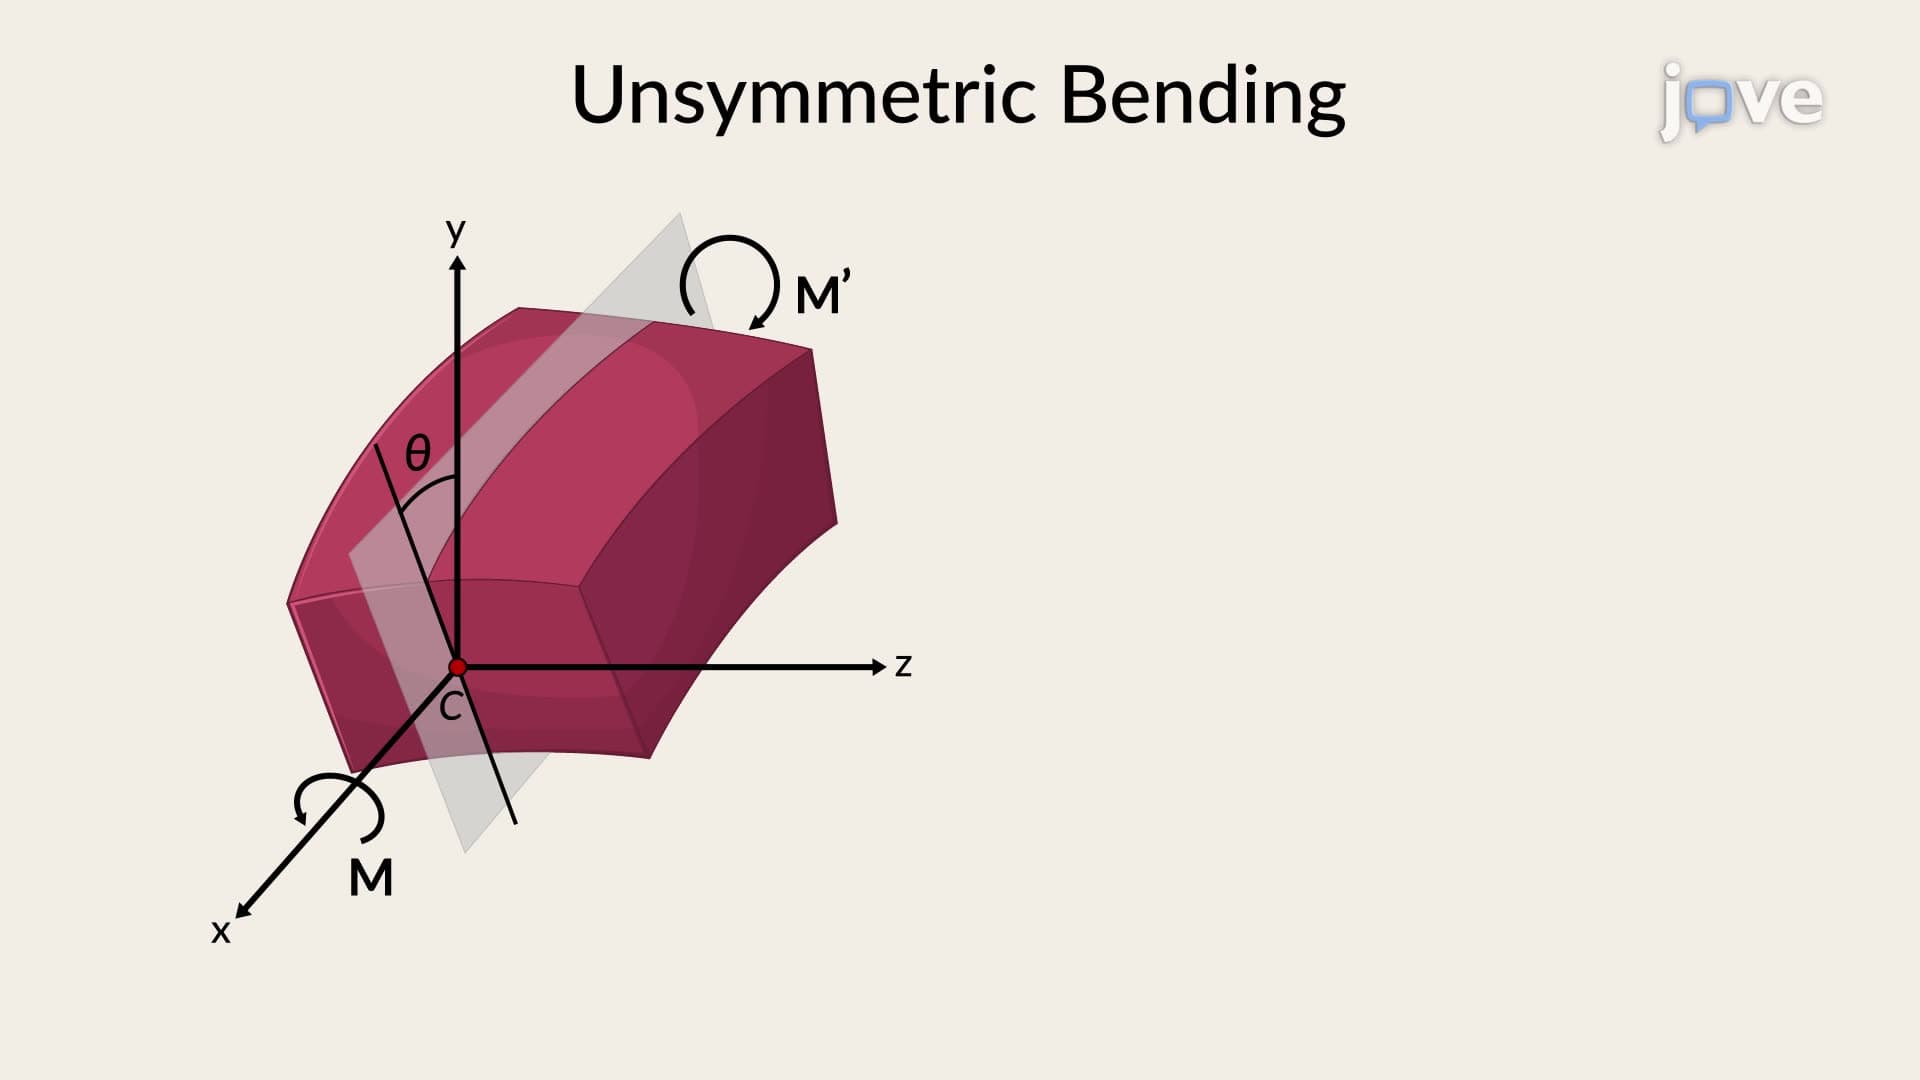
Unsymmetric Bending - Angle of Neutral Axis
When a bending moment is applied at an angle θ concerning the vertical axis of a symmetrical member, it can be resolved into components along the member's principal centroidal axes. The...
 01:15
Kinematic Equations: Problem Solving