Related Experiment Video
Updated: Aug 8, 2026
Measuring Sensitivity to Viewpoint Change with and without Stereoscopic Cues
Published on: December 4, 2013
Invariant fitting of two view geometry
1School of Mathematics and Computing, Oxford Brookes University, Wheatley, Oxford OX33 1HX, UK. philiptorr@brookes.ac.uk

Abstract:
This paper describes an extension of Bookstein's and Sampson's methods, for fitting conics, to the determination of epipolar geometry, both in the calibrated case, where the Essential matrix E is to be determined or in the uncalibrated case, where we seek the fundamental matrix F. We desire that the fitting of the relation be invariant to Euclidean transformations of the image, and show that there is only one suitable normalization of the coefficients and that this normalization gives rise to a quadratic form allowing eigenvector methods to be used to find E or F, or an arbitrary homography H. The resulting method has the advantage that it exhibits the improved stability of previous methods for estimating the epipolar geometry, such as the preconditioning method of Hartley, while also being invariant to equiform transformations.
More Related Videos
 14:14
Quantification of Strain in a Porcine Model of Skin Expansion Using Multi-View Stereo and Isogeometric Kinematics
Published on: April 16, 2017
 05:12
Robotized Testing of Camera Positions to Determine Ideal Configuration for Stereo 3D Visualization of Open-Heart Surgery
Published on: August 12, 2021
Related Concept Videos
 01:03
Inertial Frames of Reference
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:23
Curvilinear Motion: Rectangular Components
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the time...
 01:27
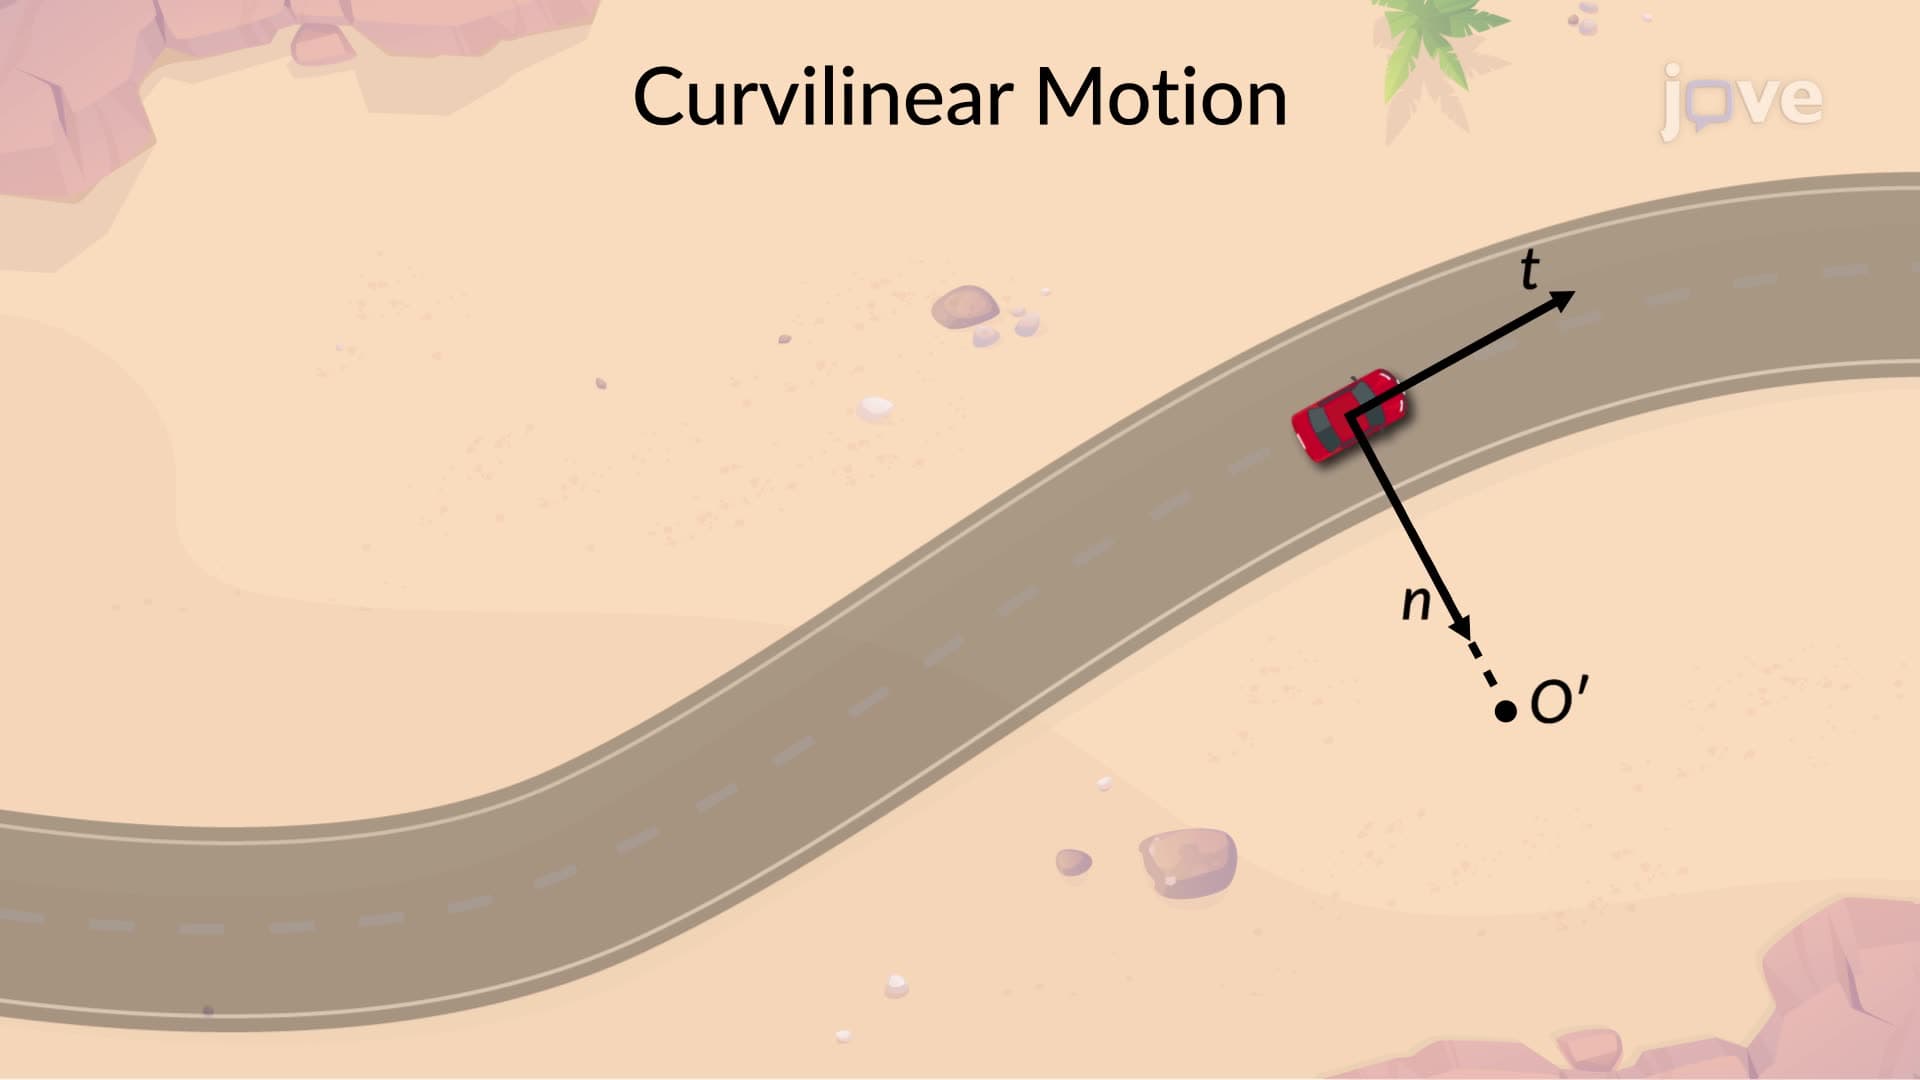
Curvilinear Motion: Normal and Tangential Components
The positive direction of the t-axis aligns with the increasing position of the car along the curved path, denoted by the unit vector ut. Simultaneously, the n-axis, perpendicular to the t-axis, dissects the curved path into differential arc segments, each forming the arc of a circle with a radius of...
 01:27
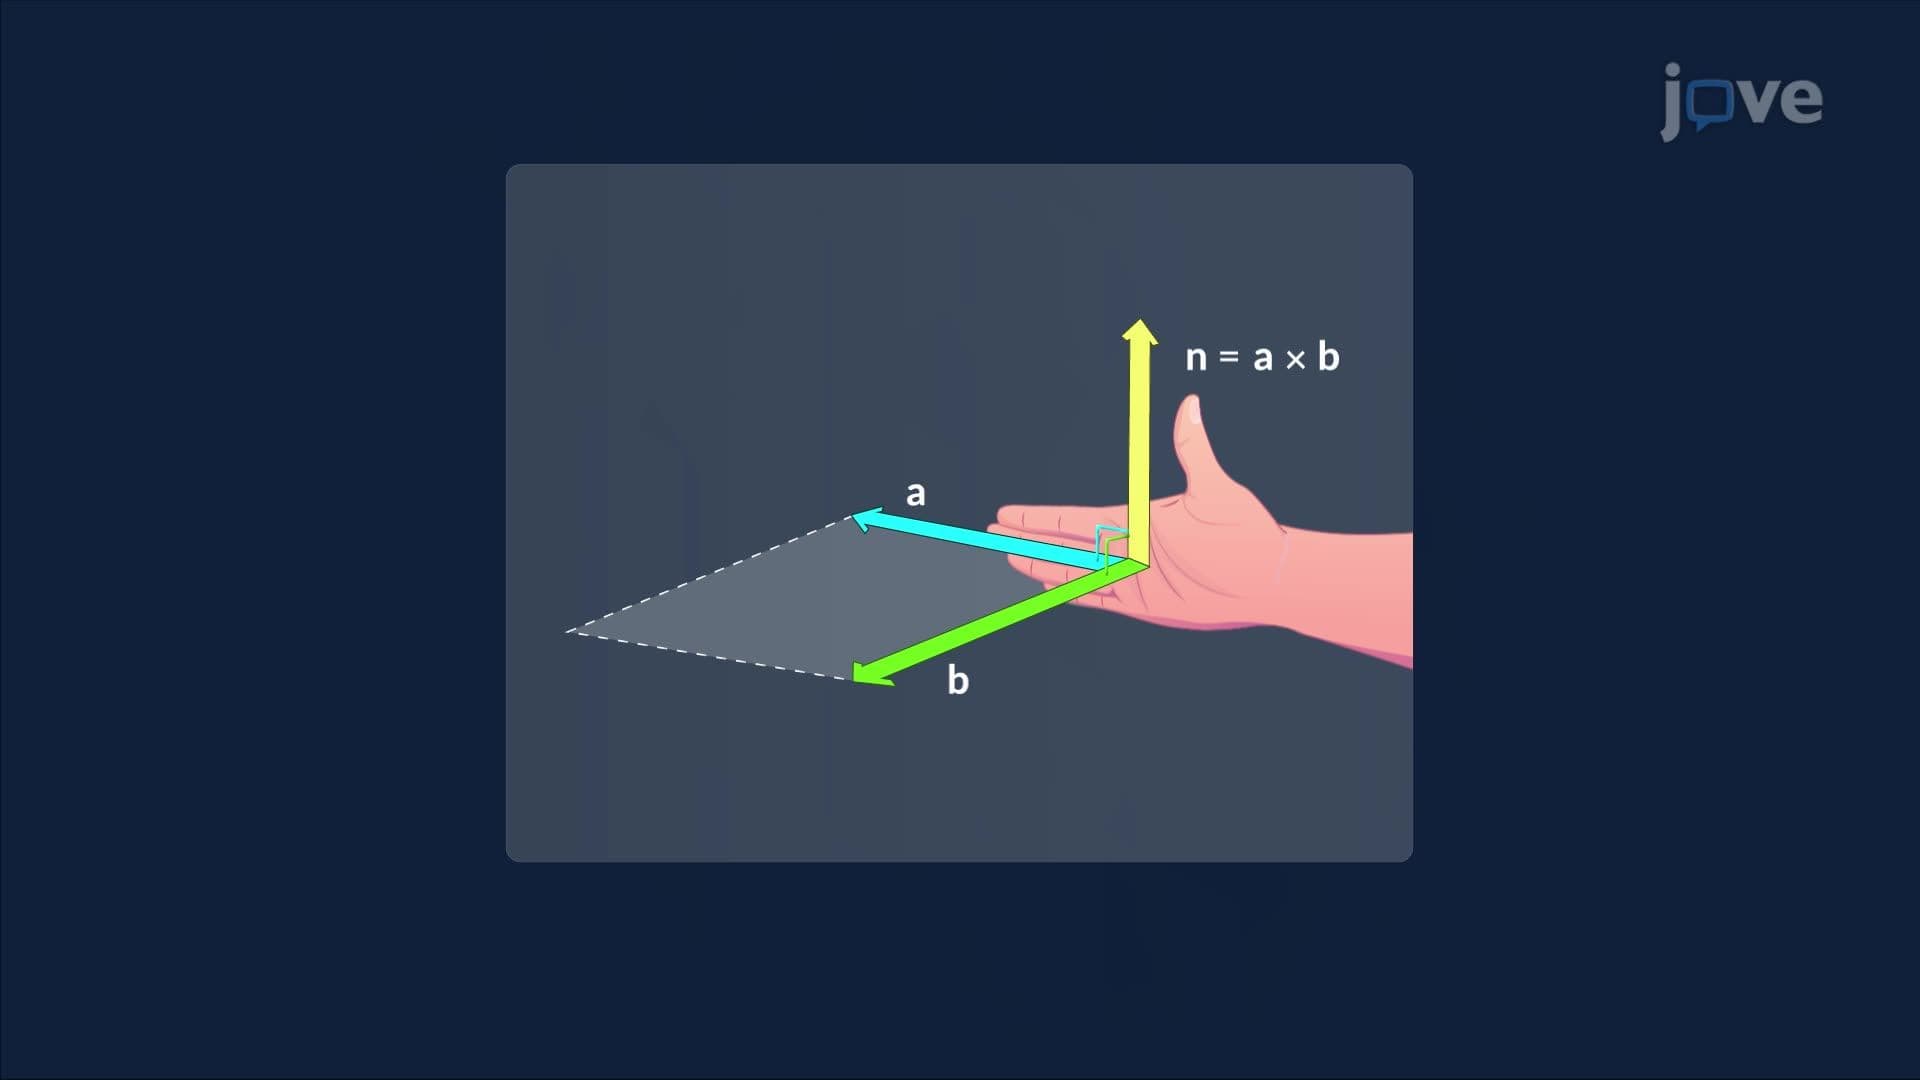
Cross Product and Its Geometry