Circumferential force production of the thumb
Related Experiment Video
Updated: Aug 21, 2026
Setup for the Quantitative Assessment of Motion and Muscle Activity During a Virtual Modified Box and Block Test
Published on: January 12, 2024
Zong-Ming Li1, Daniel A Harkness
1Hand Research Laboratory, Musculoskeletal Research Center, Departments of Orthopaedic Surgery of Bioengineering, E1641 Biomedical Science Tower, University of Pittsburgh, 210 Lothrop Street, Pittsburgh, PA 15213, USA. zmli@pitt.edu

Abstract:
We developed an apparatus to measure maximal continuous circumferential forces of a digit in the transverse plane that is perpendicular to the longitudinal axis. Subjects with asymptomatic hands were asked to produce maximal forces in all directions at the proximal phalanx of the thumb. The force components during circumferential trials were used to construct a force envelope for each subject. The force envelope enlarged as the number of trials increased, and converged to a stable pattern after several trials. The shape of the force envelope was asymmetric and oblique, skewed towards the flexion/adduction direction. Maximal force (112.1 +/- 14.8 N) was generated in the direction combining flexion and adduction. The lowest force produced was only 50.3% of the maximal force in a direction combining extension and abduction. The forces in the direction of adduction, extension, abduction, and flexion were 60.1%, 61.9%, 51.5%, and 92.9% of the maximal force, respectively. The forces generated by circumferential exertions were comparable to the forces by focused directional exertions except in the flexion direction. Our methods have the potential to identify deviations from the normative force output pattern and help detect underlying impairments resulting from neuromuscular disorders.
Related Concept Videos
 01:10
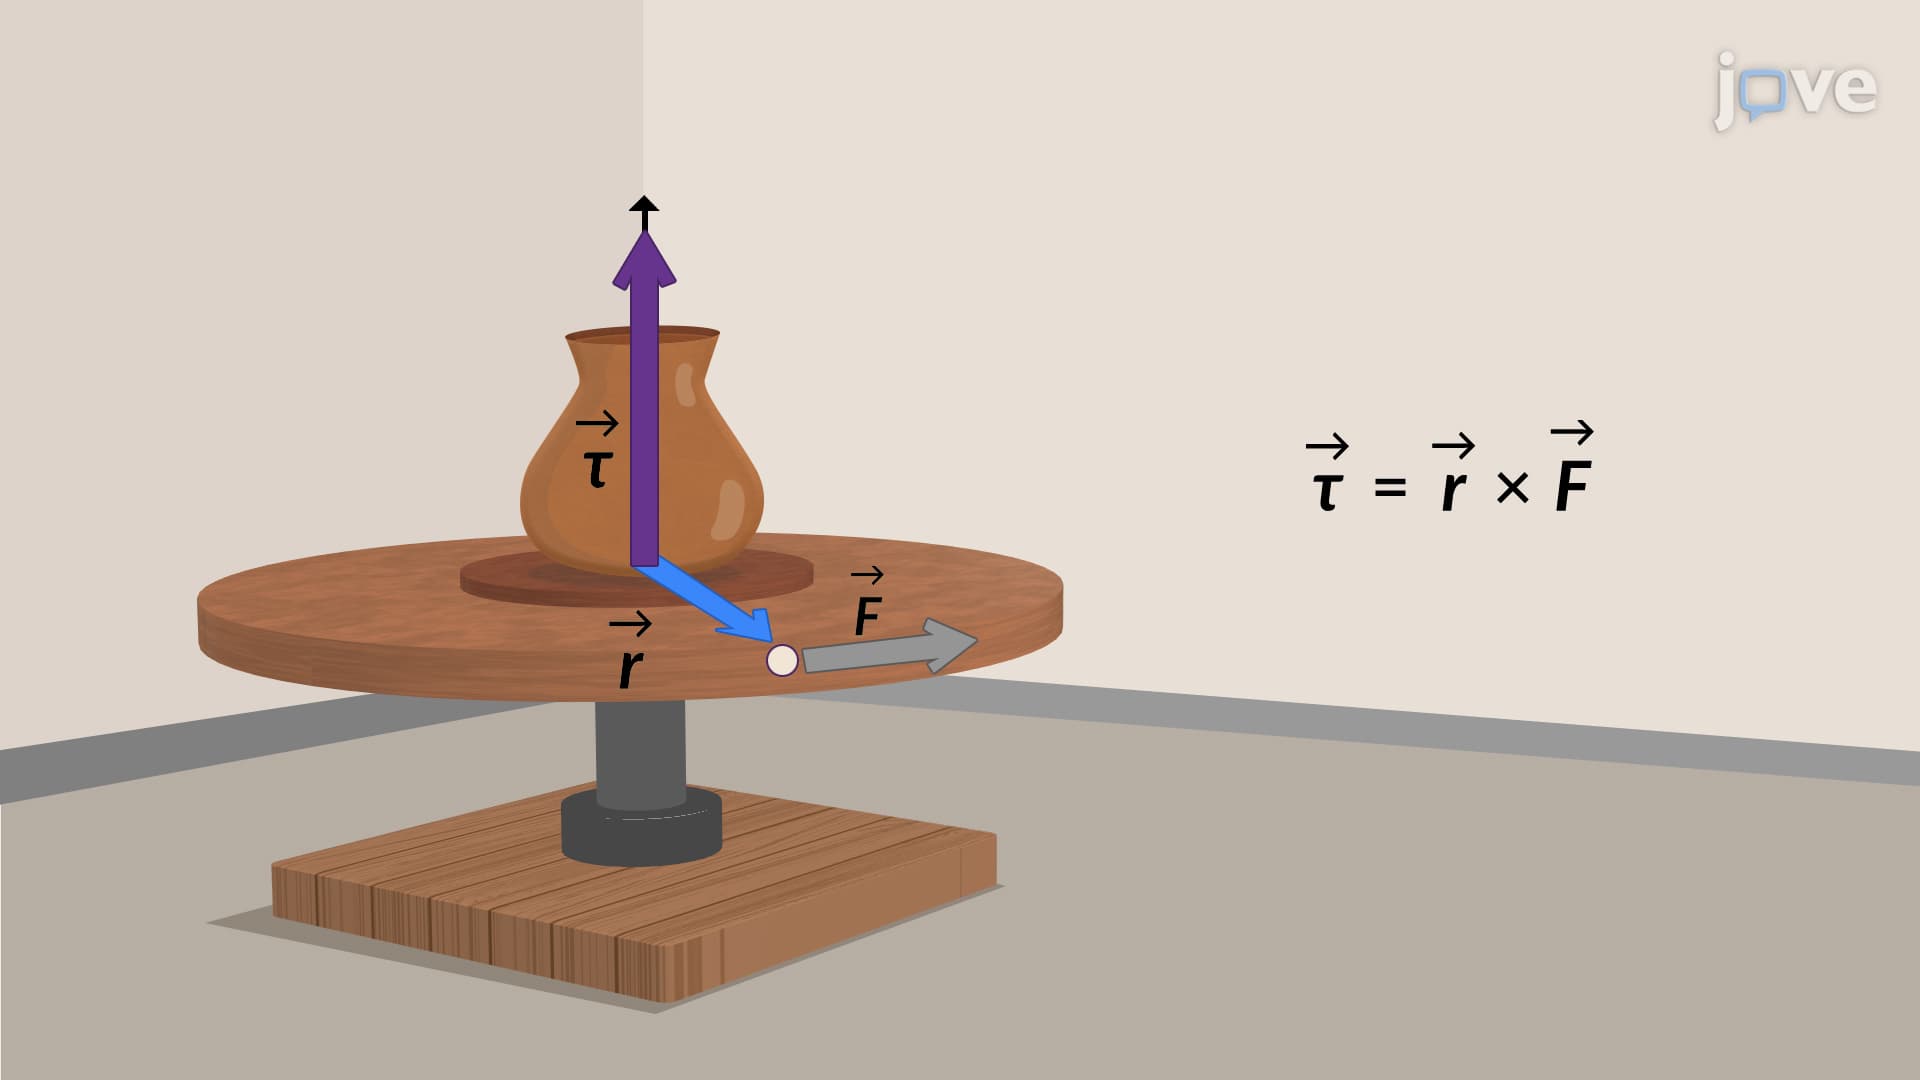
Torque
Torque can be considered as the rotational counterpart to force. Since forces change the translational...
 01:16
Muscles of the Forearm that Move the Hand and Fingers
Anterior Compartment
The anterior compartment muscles originate from the humerus. They primarily function as flexors and are also known as flexor muscles. They typically insert on the carpals, metacarpals, and phalanges. The superficial layer includes the flexor carpi radialis,...
 01:27
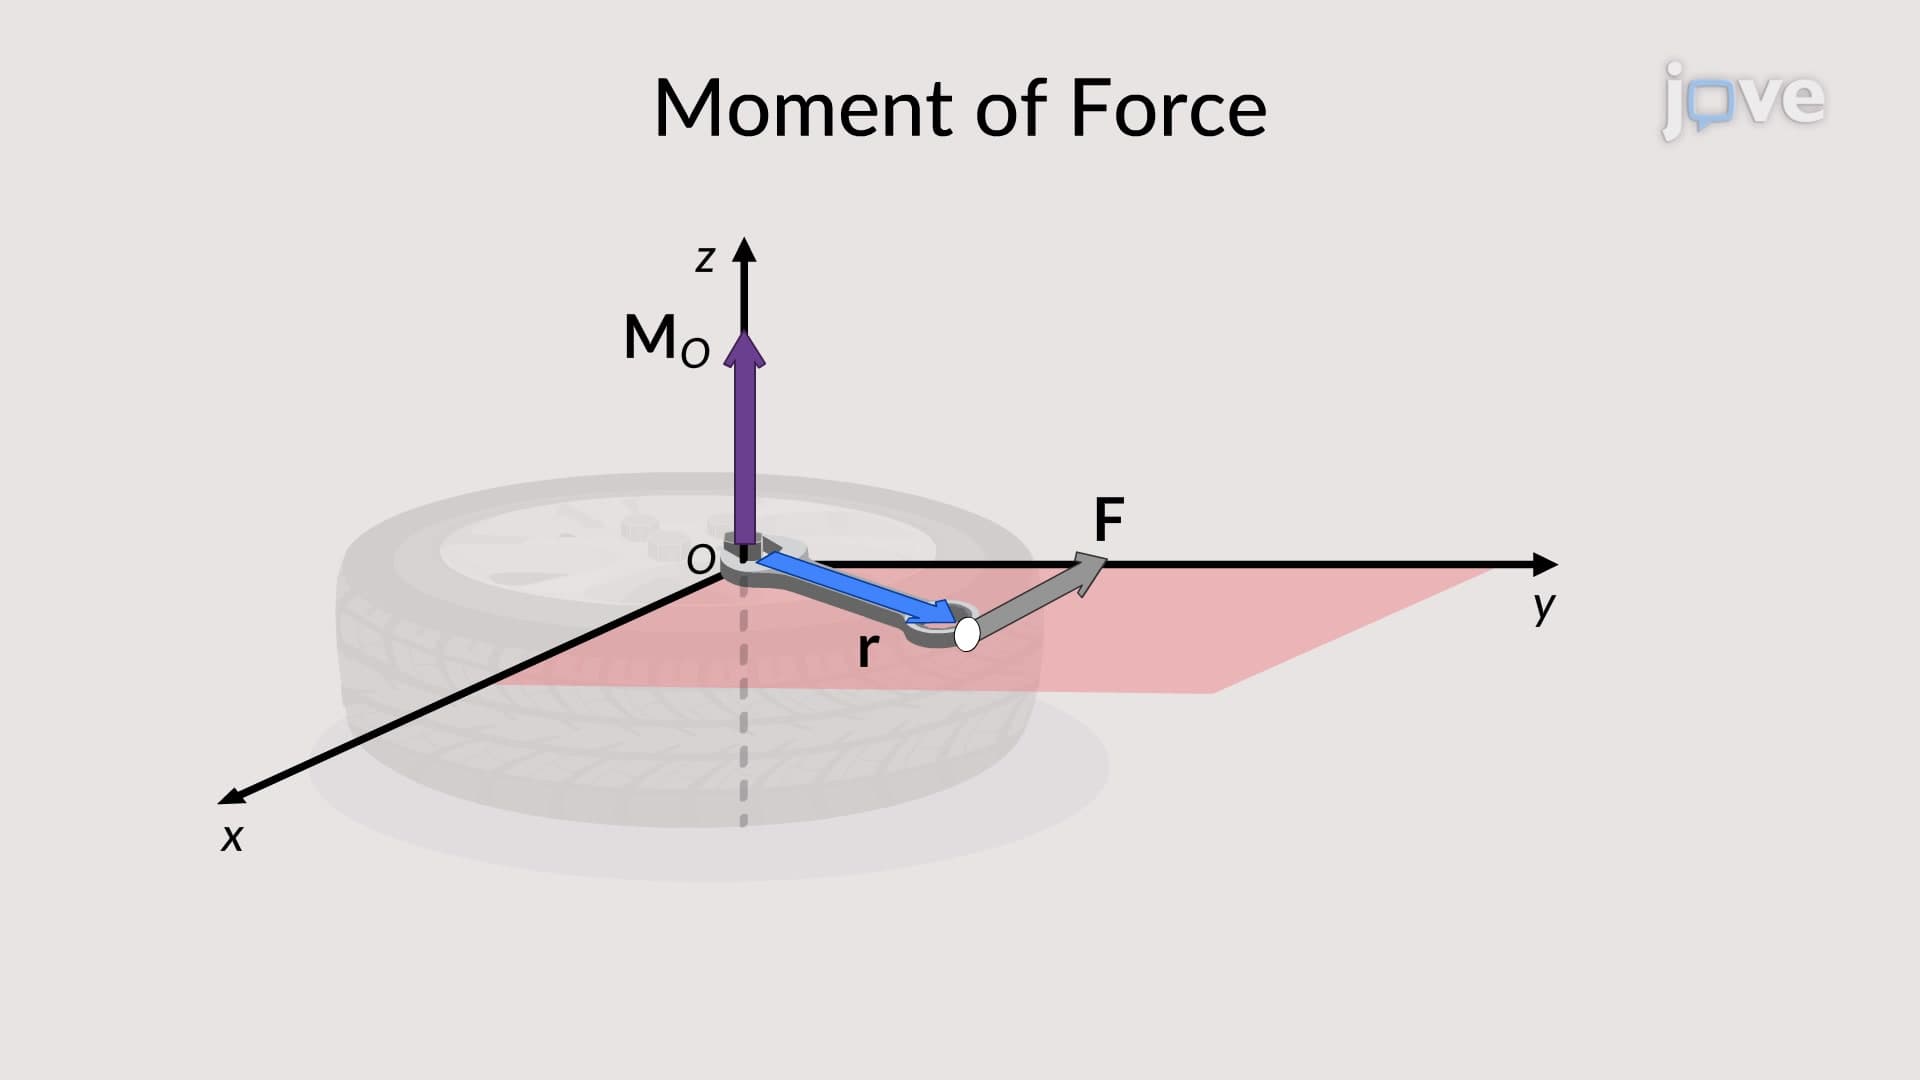
Moment of a Force: Vector Formulation
The vector formulation of the moment of force is the cross-product of the position and force vectors. The...
 01:31
Resultant Moment: Scalar Formulation
To determine the resultant moment, the moments caused by all the forces in a system in the x-y plane are considered. Positive moments are typically...
 01:22
Machines: Problem Solving I
The toggle clamp system is a machine structure consisting of movable, pin-connected multi-force members that form a stabilized system to transmit forces. The...
 01:29
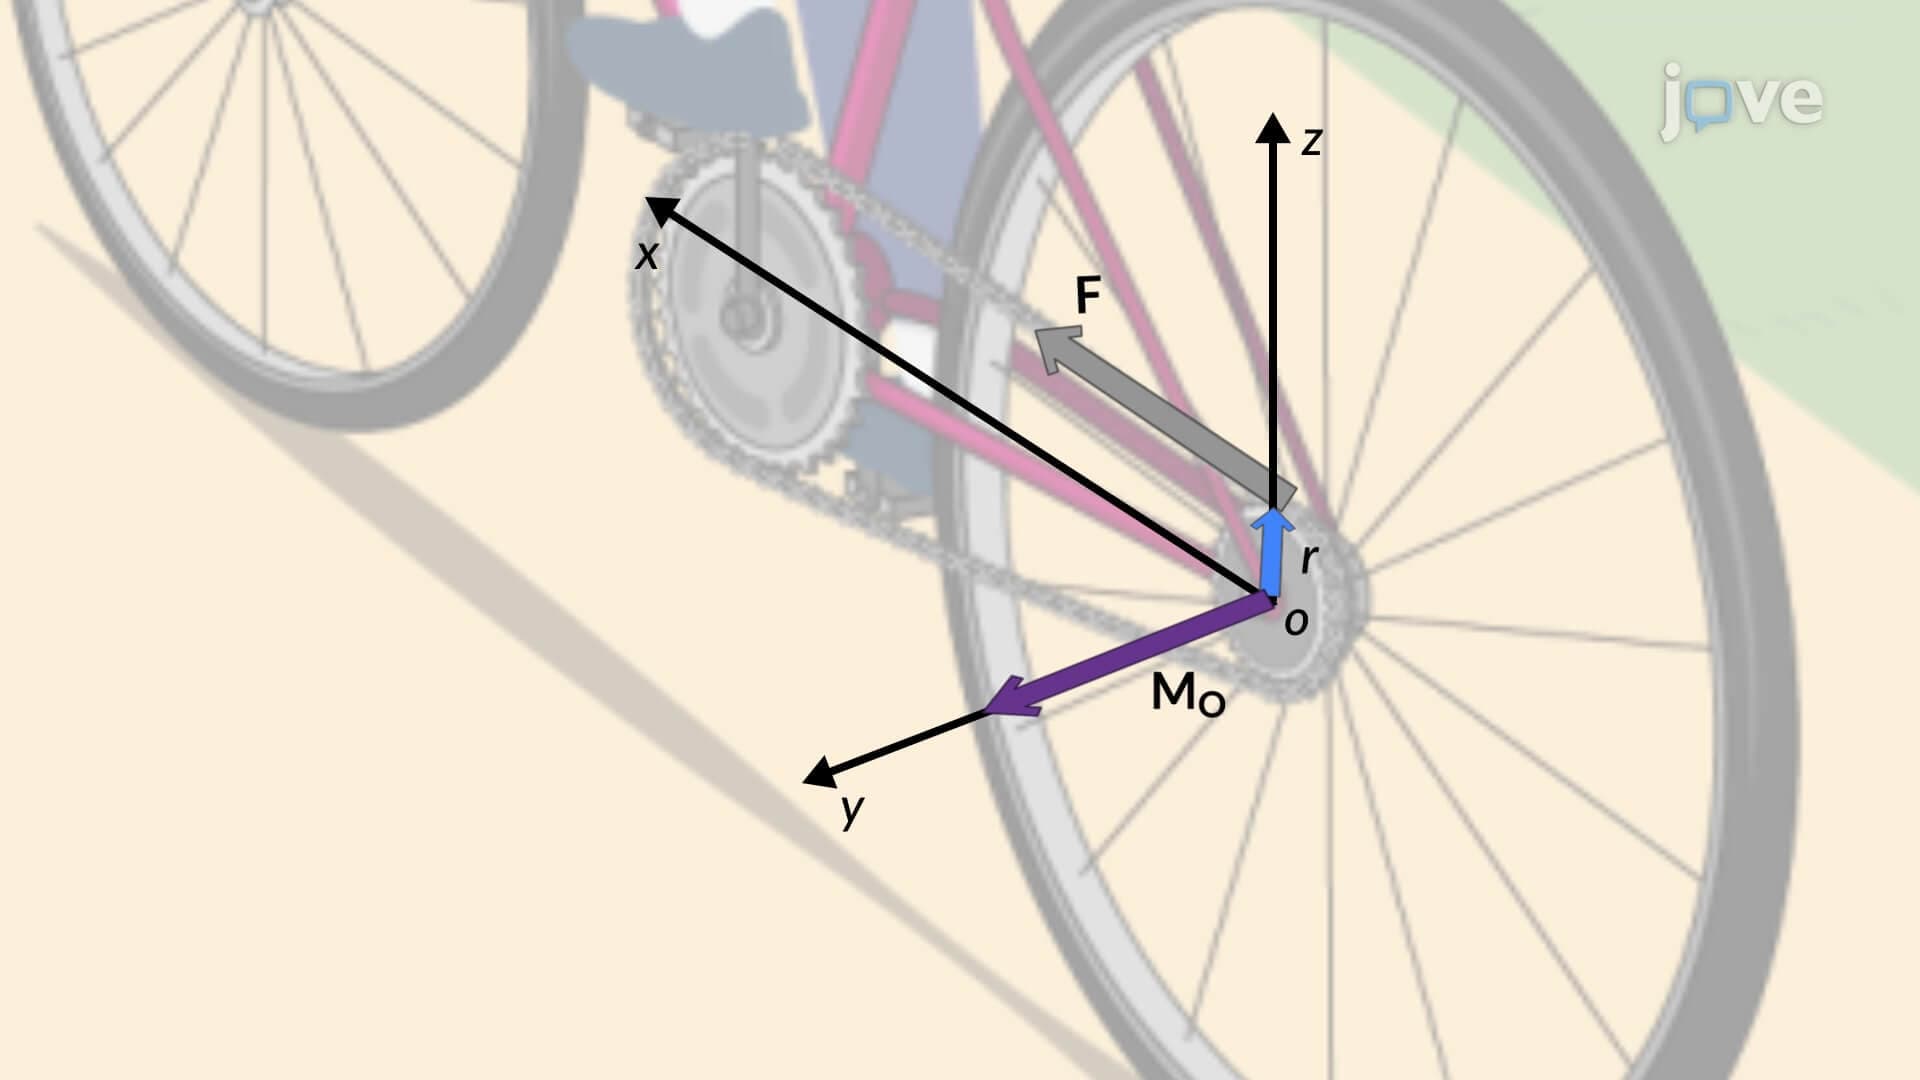
Moment of a Force About an Axis: Vector
First, establish a coordinate system to understand how the moment of a force works.