Related Experiment Video
Updated: Aug 21, 2026
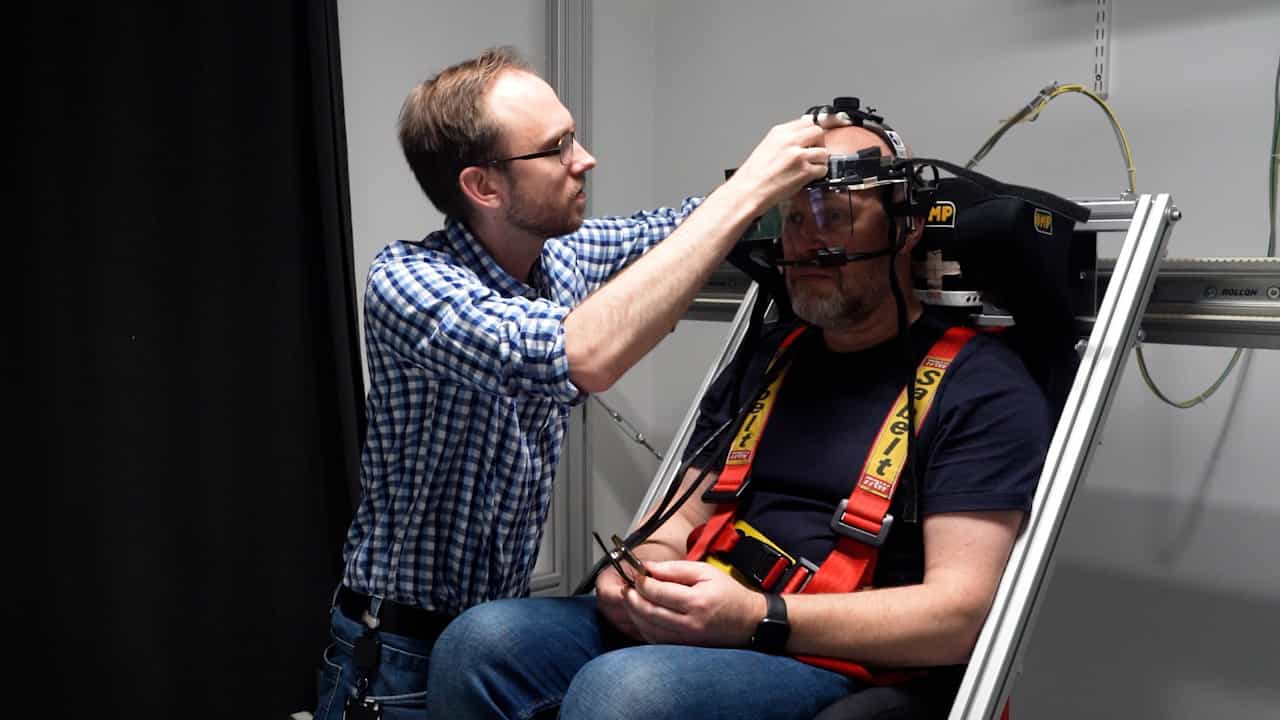
Using Eye-tracking to Assess the Relative Importance of Visual and Vestibular Input to Subcortical Motion Processing in the Roll Plane
Published on: August 22, 2025
Canal-otolith interactions after off-vertical axis rotations. II. Spatiotemporal properties of roll and pitch
Bernhard J M Hess1, Karin Jaggi-Schwarz, Hubert Misslisch
1Department of Neurology, University of Zürich, Zürich, Switzerland. bhess@neurol.unizh.ch

Abstract:
We have examined the spatiotemporal characteristics of postrotatory eye velocity after roll and pitch off-vertical axis rotations (OVAR). Three rhesus monkeys were placed in one of 3 orientations on a 3-dimensional (3D) turntable: upright (90 degrees roll or pitch OVAR), 45 degrees nose-up (45 degrees roll OVAR), and 45 degrees left ear-down (45 degrees pitch OVAR). Subjects were then rotated at +/-60 degrees /s around the naso-occipital or interaural axis and stopped after 10 turns, in one of 7 final head orientations, each separated by 30 degrees . We found that postrotatory eye velocity showed horizontal-vertical components after roll OVAR and horizontal-torsional components after pitch OVAR that varied systematically as a function of final head orientation. The quantitative analysis suggests that, in contrast to the analogous yaw OVAR paradigm, a system of up to 3 real, gravity-dependent eigenvectors and eigenvalues determines the spatiotemporal characteristics of the residual eye velocities after roll and pitch OVAR. One of these eigenvectors closely aligned with gravity, whereas the other 2 determined the orientation of the earth horizontal plane. We propose that the spatial characteristics of eye velocity after roll and pitch OVAR follow the physical constraints of stationary orientation in a gravitational field and reflect the brain's best estimate of head-in-space orientation within an internal representation of 3D space.
Related Concept Videos
 01:15
Equilibrium and Balance
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
 01:26
Rotational Motion about a Fixed Axis
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:29
The Vestibular System
 01:30
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...