Visual and motor constraints on trajectory planning in pointing movements
Related Experiment Video
Updated: Aug 21, 2026
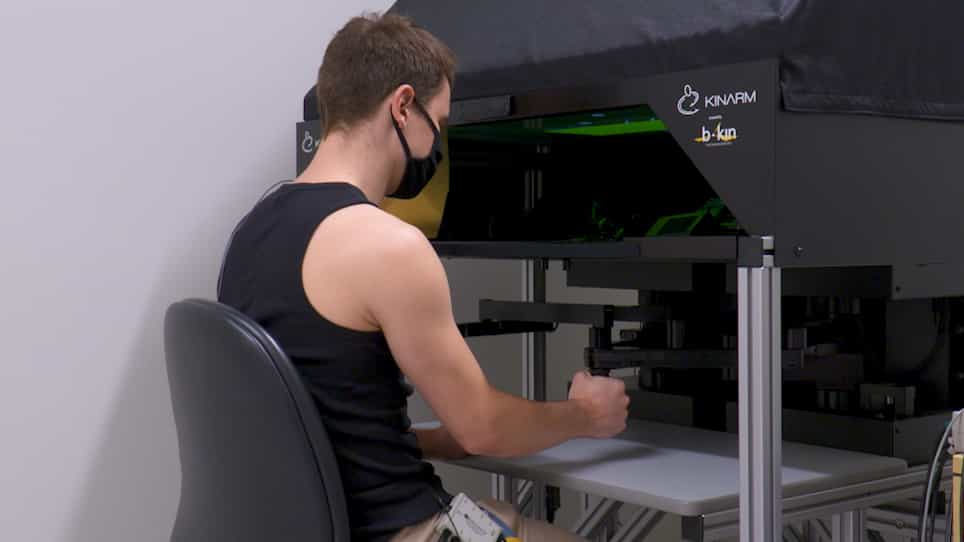
An Emerging Target Paradigm to Evoke Fast Visuomotor Responses on Human Upper Limb Muscles
Published on: August 25, 2020
R Palluel-Germain1, F Boy, J P Orliaguet
1Laboratoire de Psychologie et NeuroCognition CNRS UMR 5105, Université Pierre Mendes France, Grenoble II, 1251, Avenue Centrale-BP 47, 38040 Grenoble Cedex 9, France.

Abstract:
The aim of the present study was to show that planning and controlling the trajectory of a pointing movement is influenced not solely by physical constraints but also by visual constraints. Subjects were required to point towards different targets located at 20 degrees , 40 degrees , 60 degrees and 80 degrees of eccentricity. Movements were either constrained (i.e. two-dimensional movements) or unconstrained (i.e. three-dimensional movements). Furthermore, movements were carried out either under a direct or a remote visual control (use of a video system). Results revealed that trajectories of constrained movements were nearly straight whatever the eccentricity of the target and the type of visual control. A different pattern was revealed for unconstrained movements. Indeed, under direct vision the trajectory curvature increased as the eccentricity augmented, whereas under indirect vision, trajectories remained nearly straight whatever the eccentricity of the target. Thus, movements controlled through a remote visual feedback appear to be planned in extrinsic space as constrained movements.
Related Concept Videos
 01:26
Orthogonal Trajectories
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:30
Vector Functions and Motion: Problem Solving
 01:22
Planar Rigid-Body Motion
Planar motion is typically divided into three distinct categories. The first is rectilinear translation, demonstrated by a subway train that moves along...
 01:18
Hierarchy of Motor Control
 01:15
Kinematic Equations: Problem Solving